← Latest updates
Preprint · hardware experiments
SCRUB controls a body-mounted tool on a quadruped
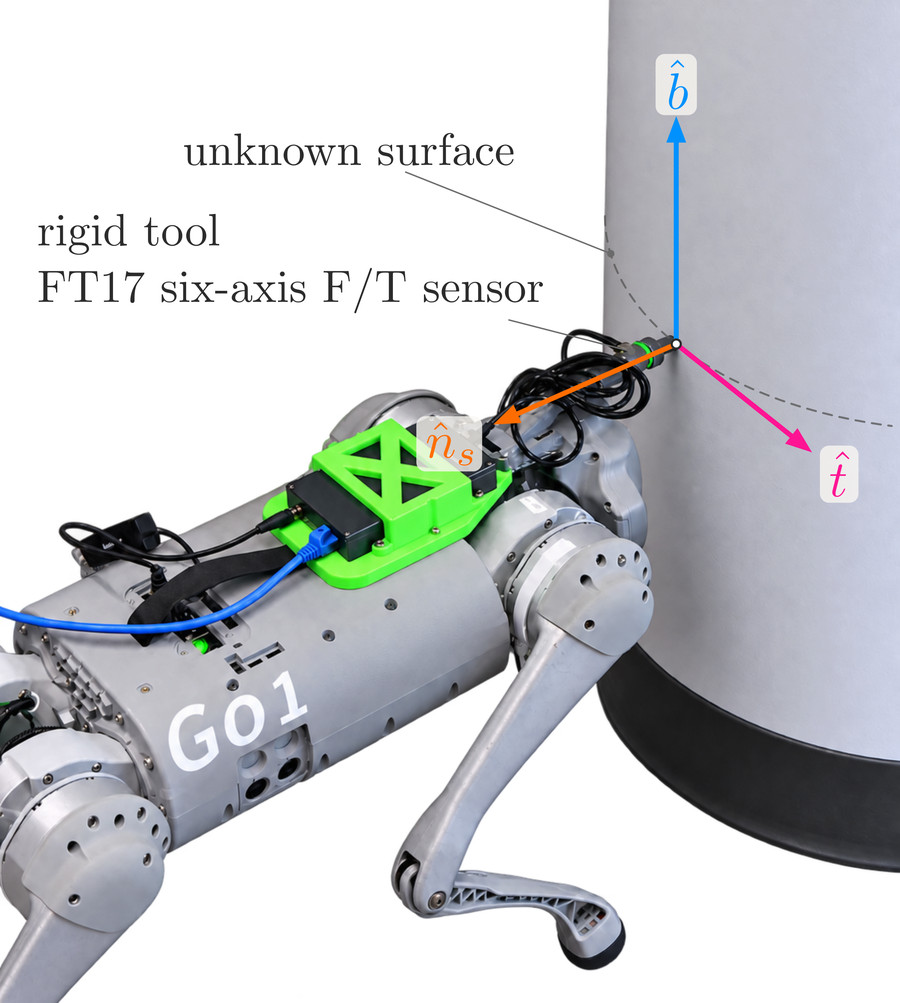
An armless quadruped estimates surface direction from force and velocity cues while sliding a body-mounted tool along near-vertical surfaces.
- Source published
- Sources checked
- 2026-11-09
What changed
- Unitree Go1 experiments cover wall traverses and column orbits with contact-based normal estimation.
- The controller removes commanded pressing motion and averages tool velocity over each gait cycle.
Relevance to constrained-space work
The method addresses maintaining tool contact while walking, relevant to wiping, sanding and contact inspection.
Compiled by OpenRuwei editorial