Through the opening.
Into the field.
The opening, internal path and task determine how a robot enters and which tools it can carry.
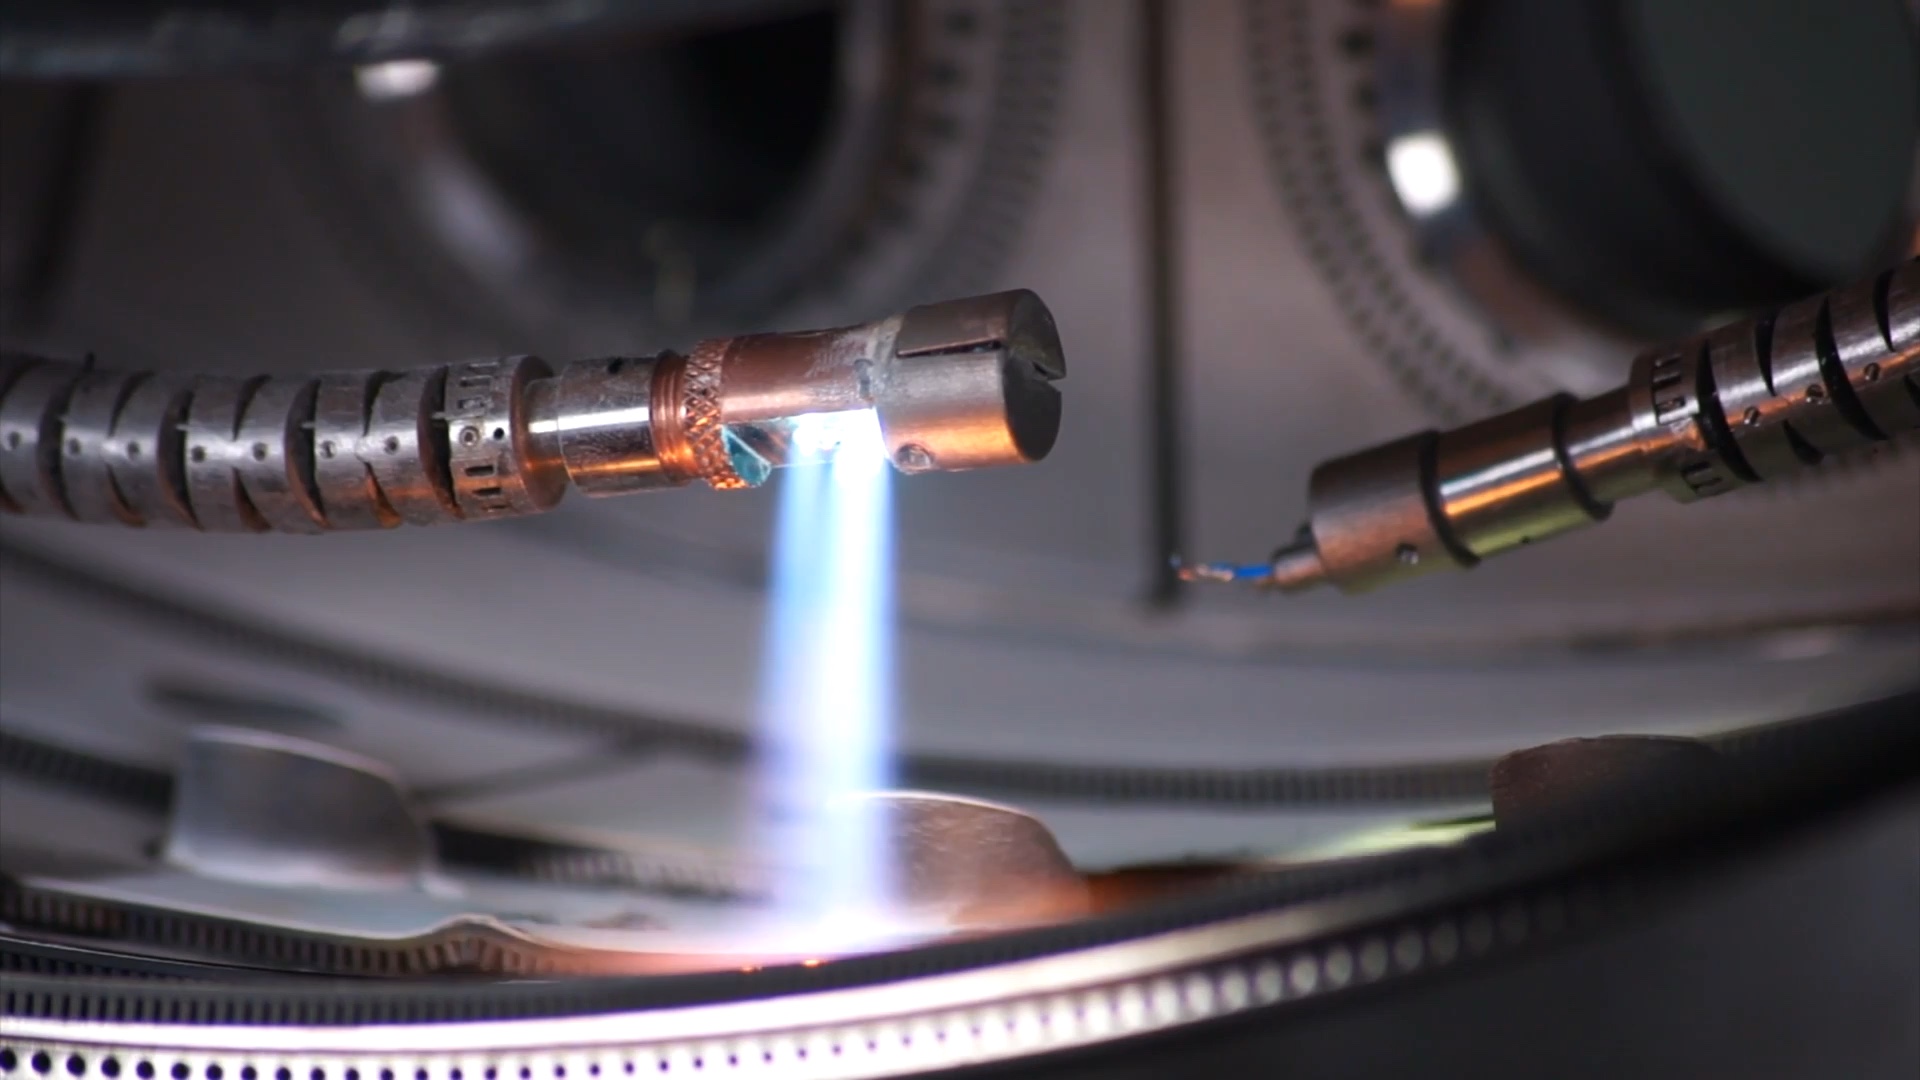
Working through inspection ports.
Snake arms enter through inspection ports; miniature robots move along blades and walls. Cases include Rolls-Royce probe and repair projects, Harvard electroadhesive crawling, continuum arms, K-Track and TRACE.
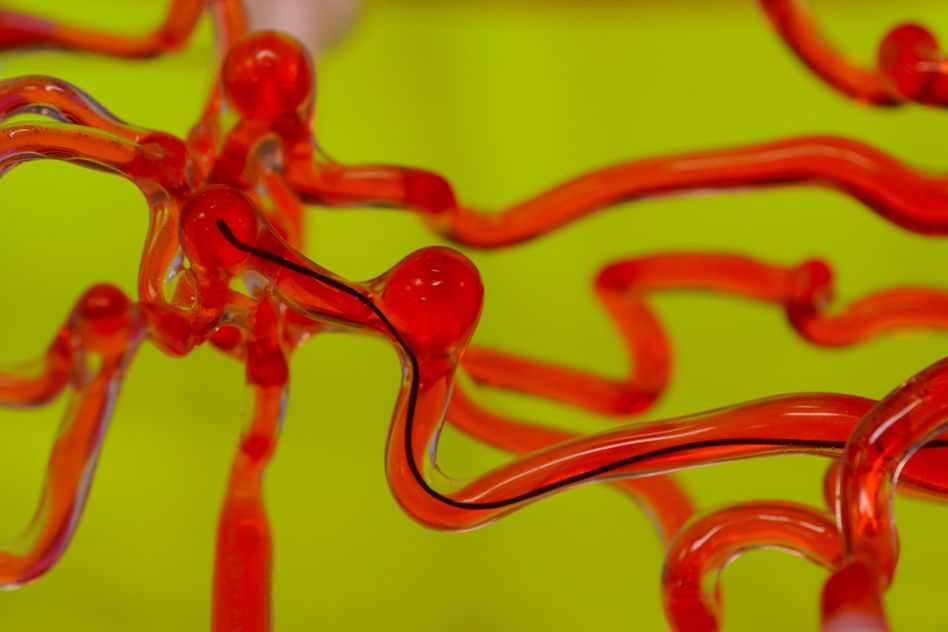
Navigating vessels and airways.
Blood vessels, airways and the digestive tract are narrow and deformable. Magnetic threads and flexible catheters navigate them while controlling steering, contact and tip position.
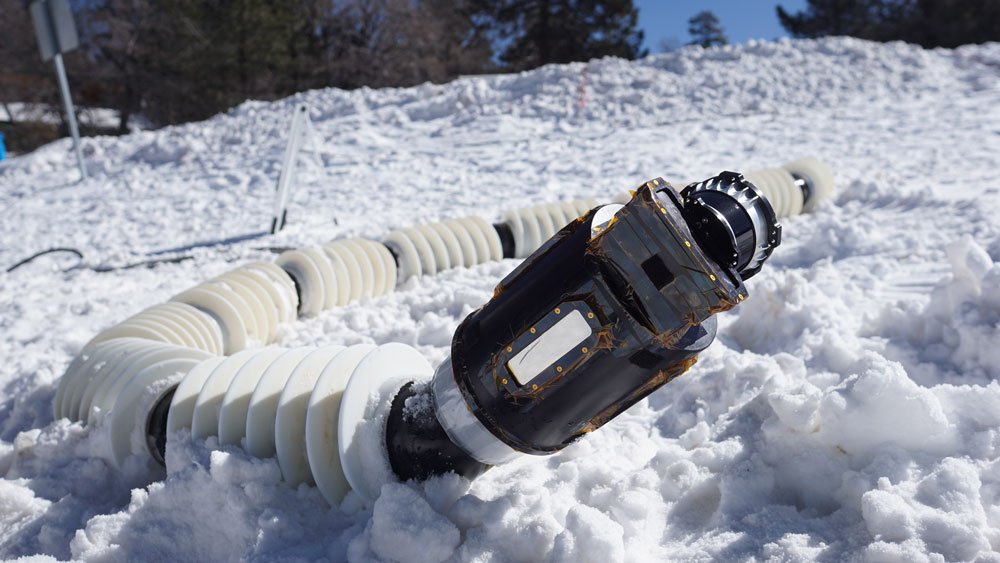
Rubble voids and passages through ice.
CMU snake robots entered earthquake rubble. JPL tests EELS on ice and snow, while ReachBot explores rock anchors with extendable booms and microspine grippers. Each faces irregular paths, remote observation and retrieval.
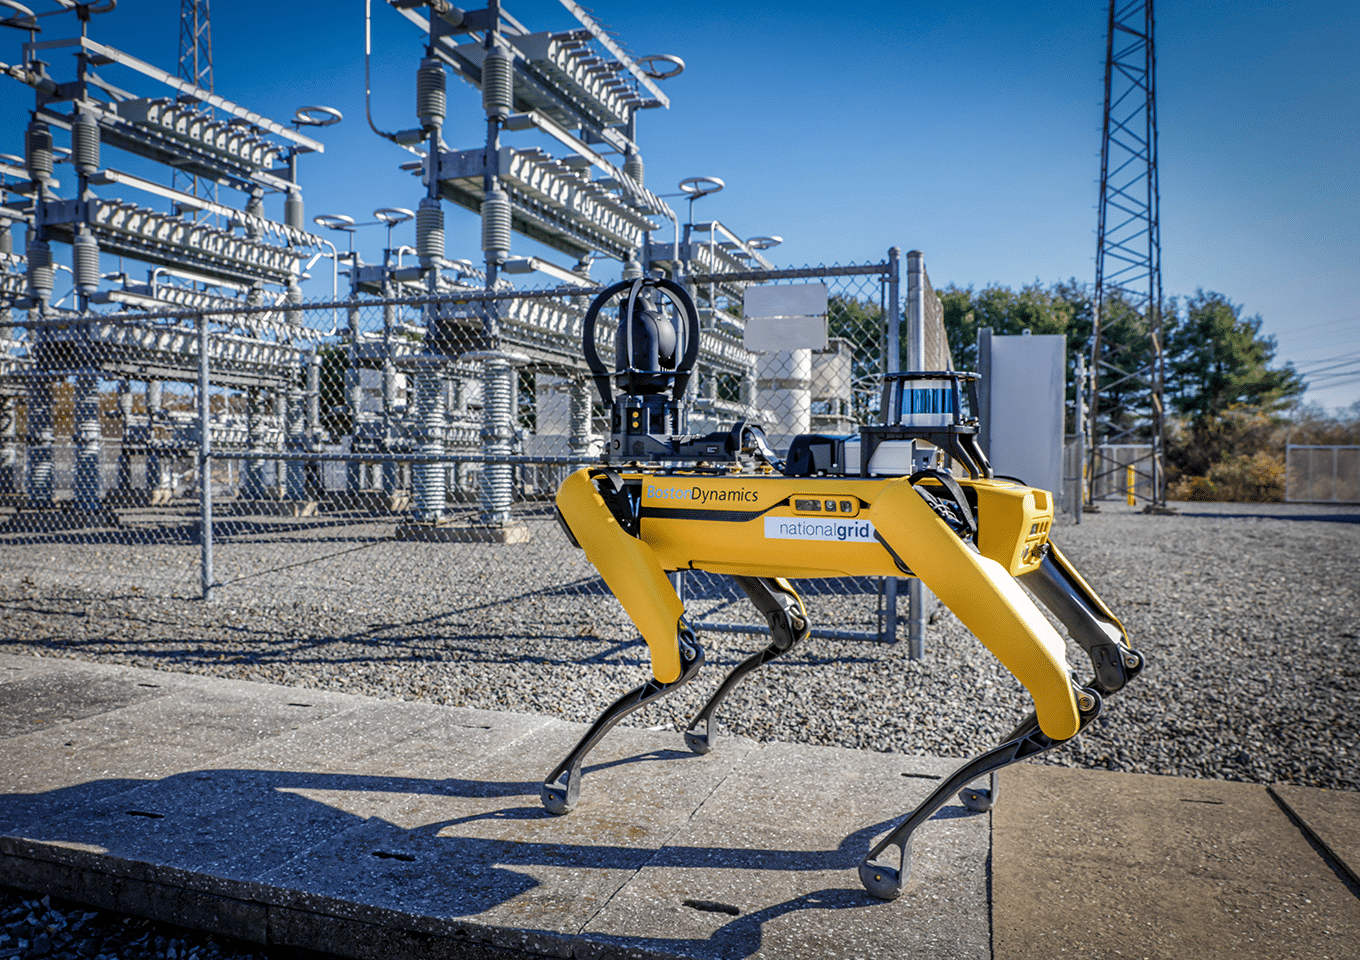
From pipe interiors to industrial inspection.
Tracked robots inspect pipe interiors, protected drones survey enclosed facilities, and quadrupeds traverse stairs, grating and equipment passages to collect thermal and gauge images in power and chemical plants.
Reach the surface. Work at the interface.
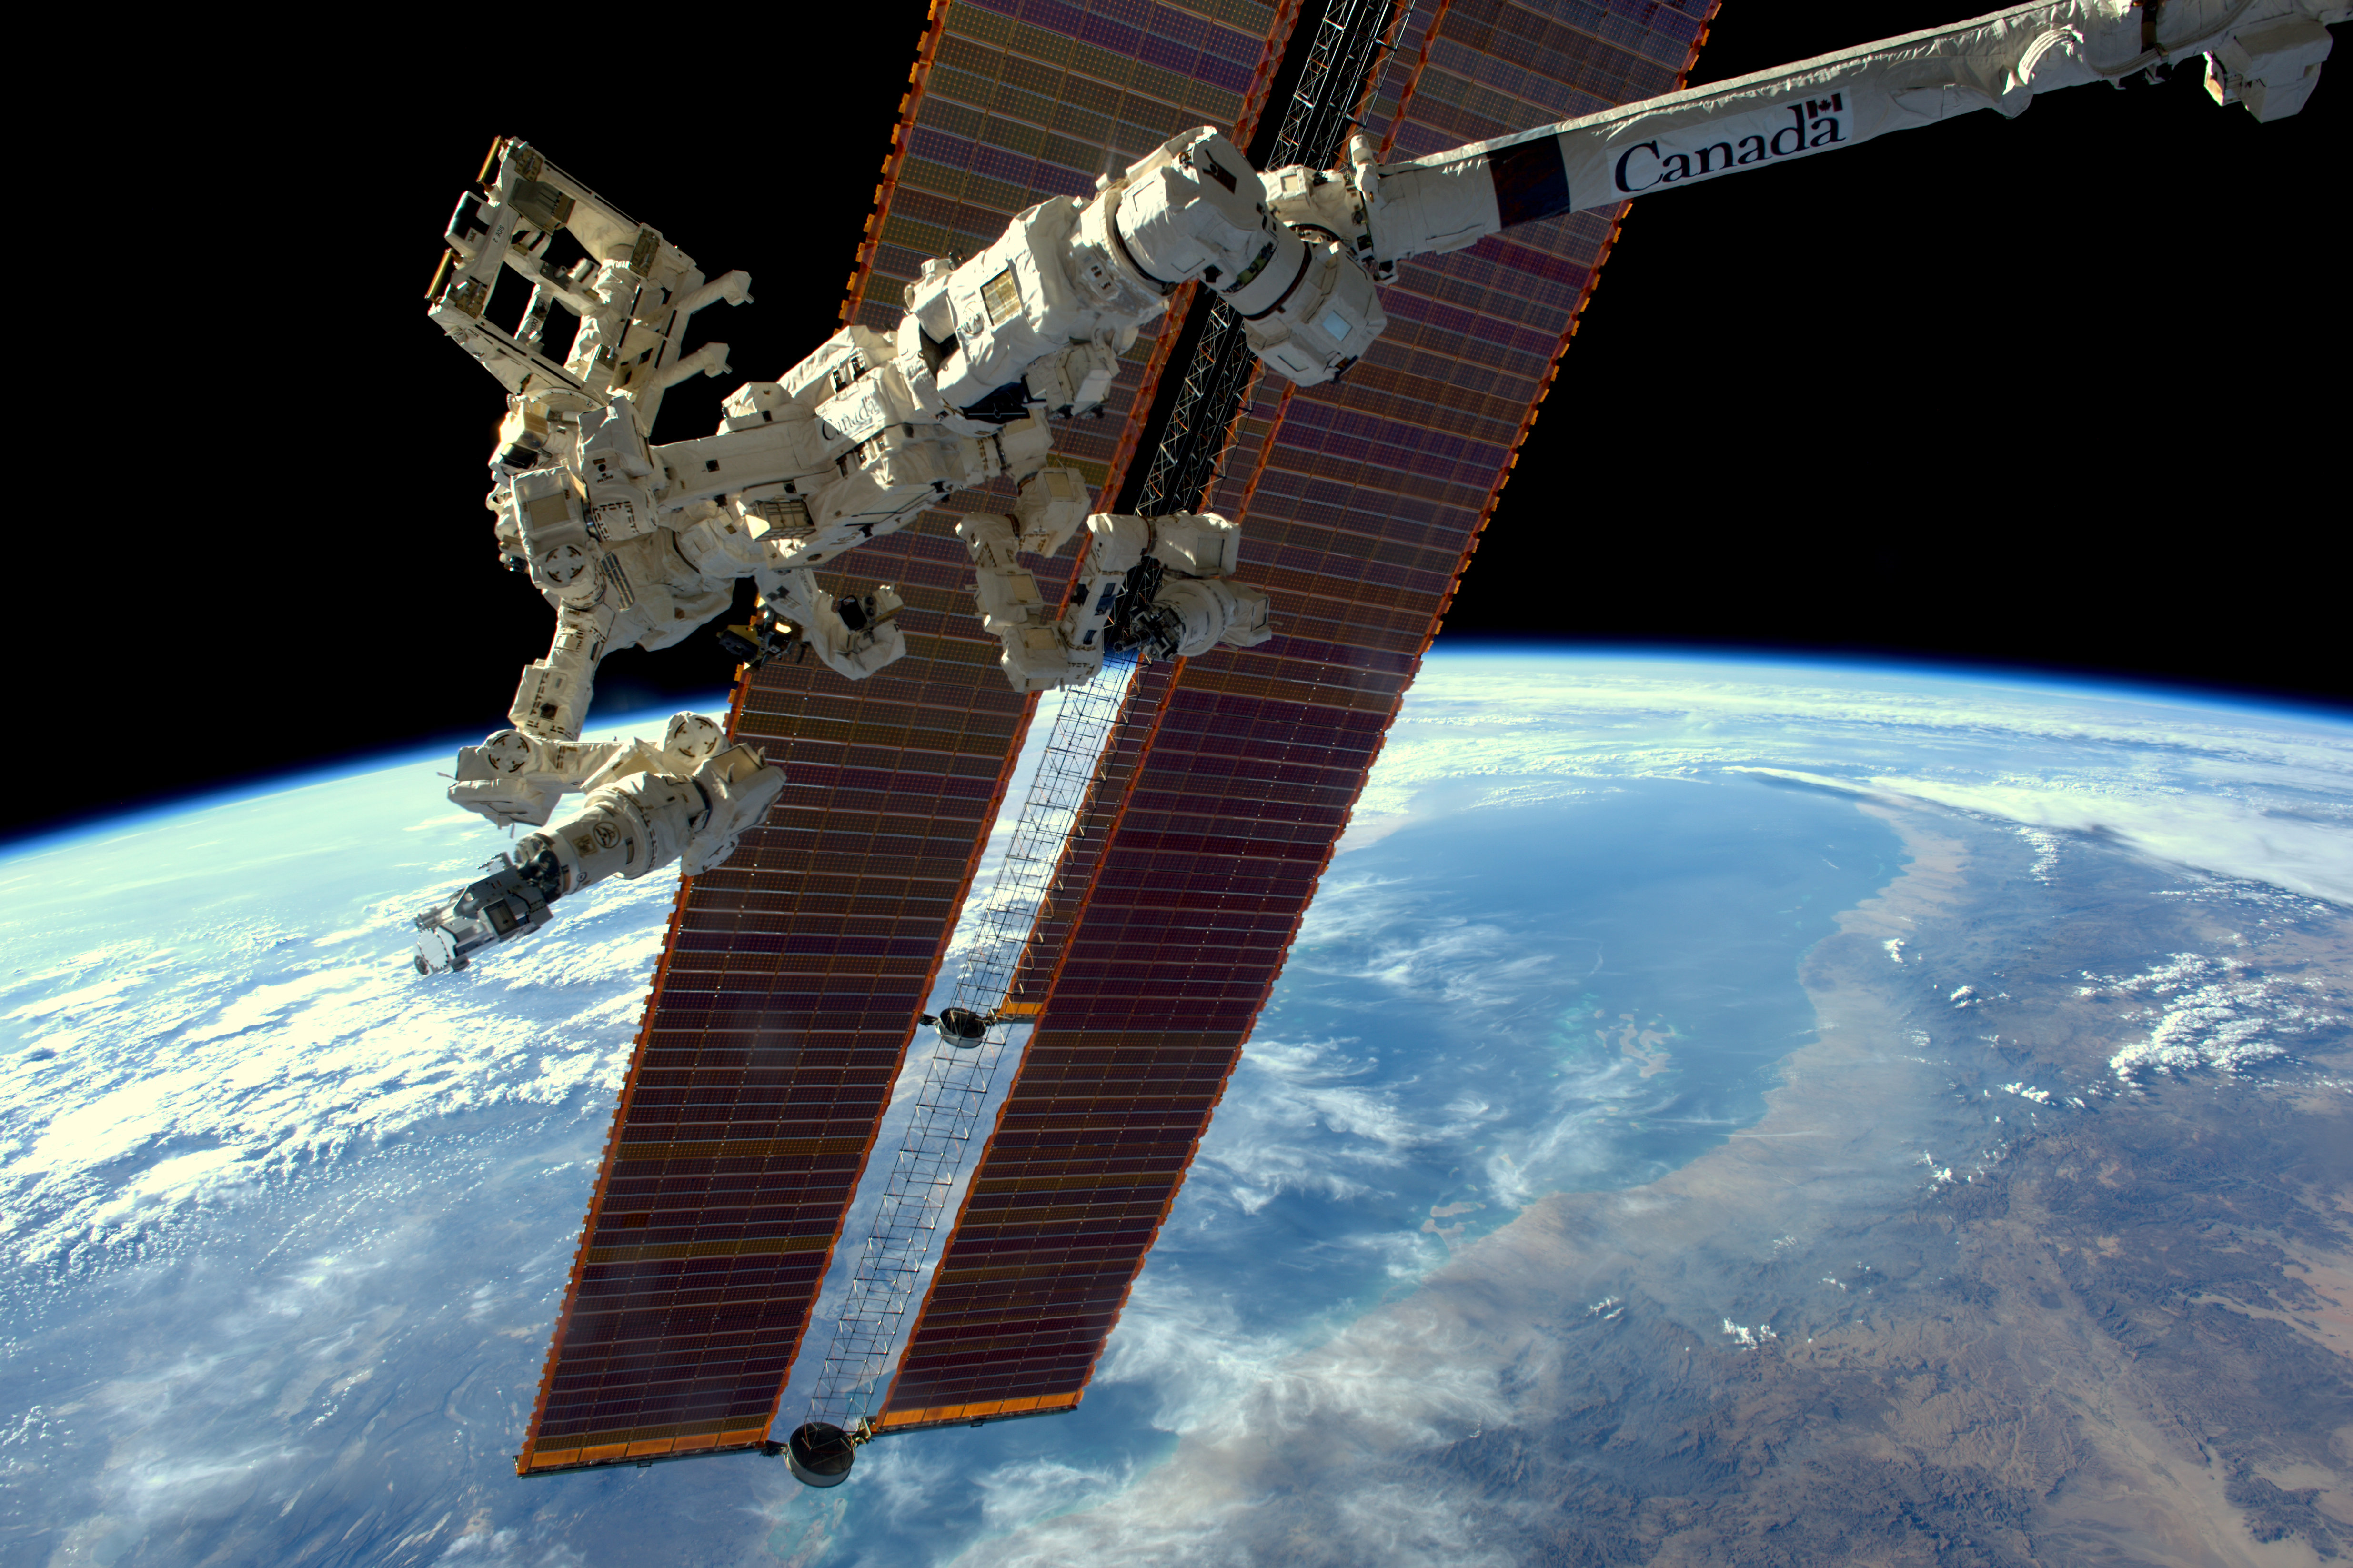
From adhesive crawling and refuelling interfaces to external station leak detection, these cases examine access, anchoring and manipulation in microgravity. Each record distinguishes ground tests, orbital experiments and documented orbital use.
Share your research and questions.
Send papers, experiment videos, open projects or application needs. Include a source link or describe the problem you are working on.