Watch the video
Paper-related demonstration: continuum-robot motion and experiments. · Yang et al. · 480p source video
01 / STUDY
Mechanism and experiments
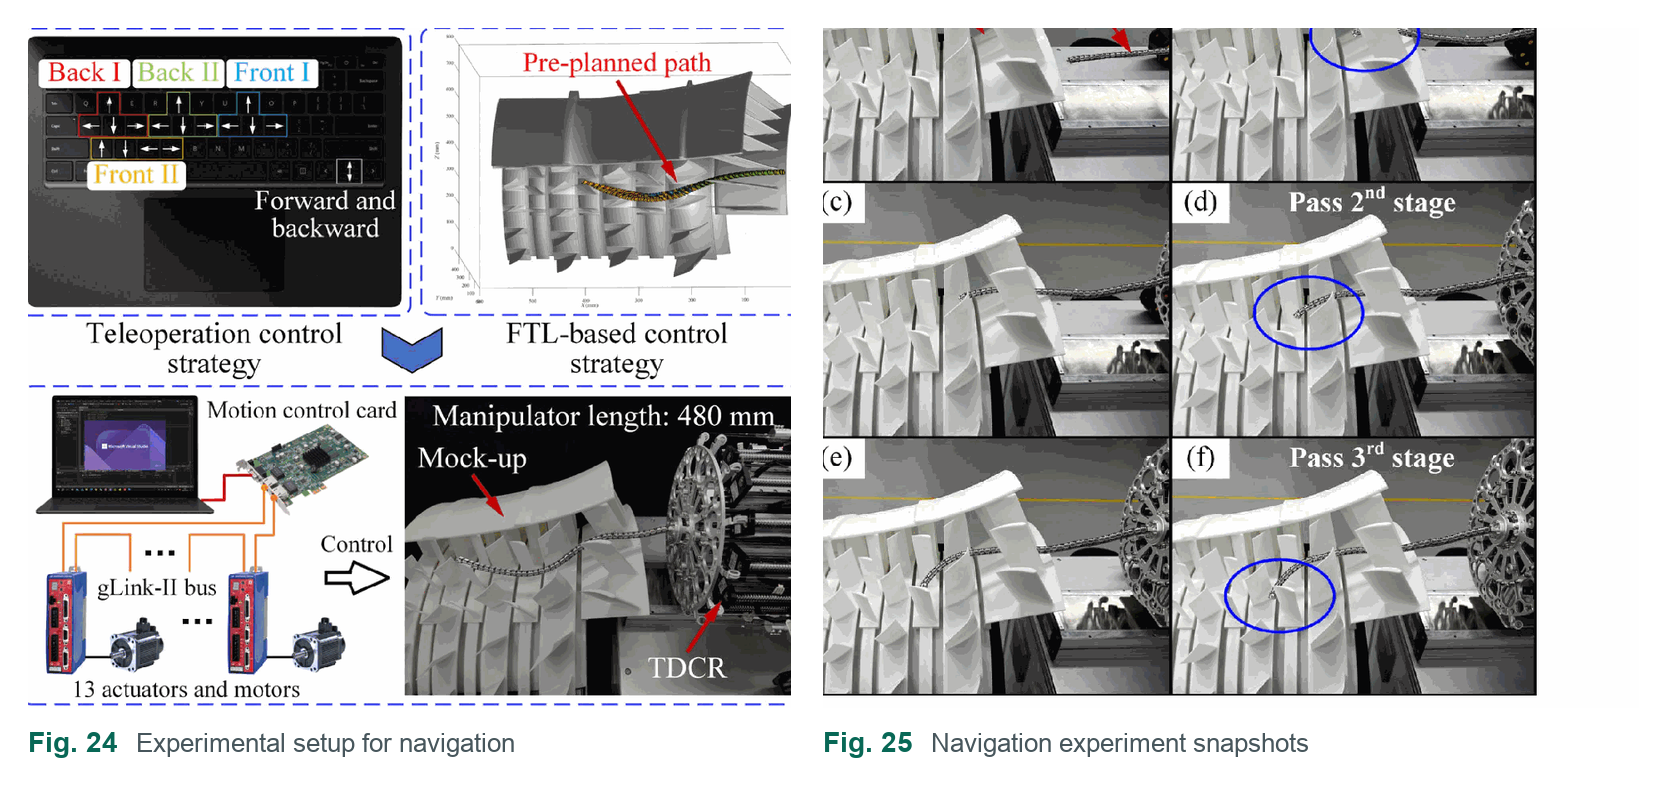
A slender manipulator must bend along the access path while supporting its body and tool loads. Internal contact-aided compliant mechanisms improve resistance to twisting and compression buckling. A static model accounts for friction and joint constraints; experiments validate shape estimation and navigation through an aero-engine blade mock-up.
02 / CONTEXT
Test conditions and scope
Blade-model experiments validated navigation and shape estimation. Loads, precision and reliability with maintenance tools need further testing.
03 / SOURCE