Back to cases
CASE 14 / Rescue & exploration

Snake robot in earthquake rubble

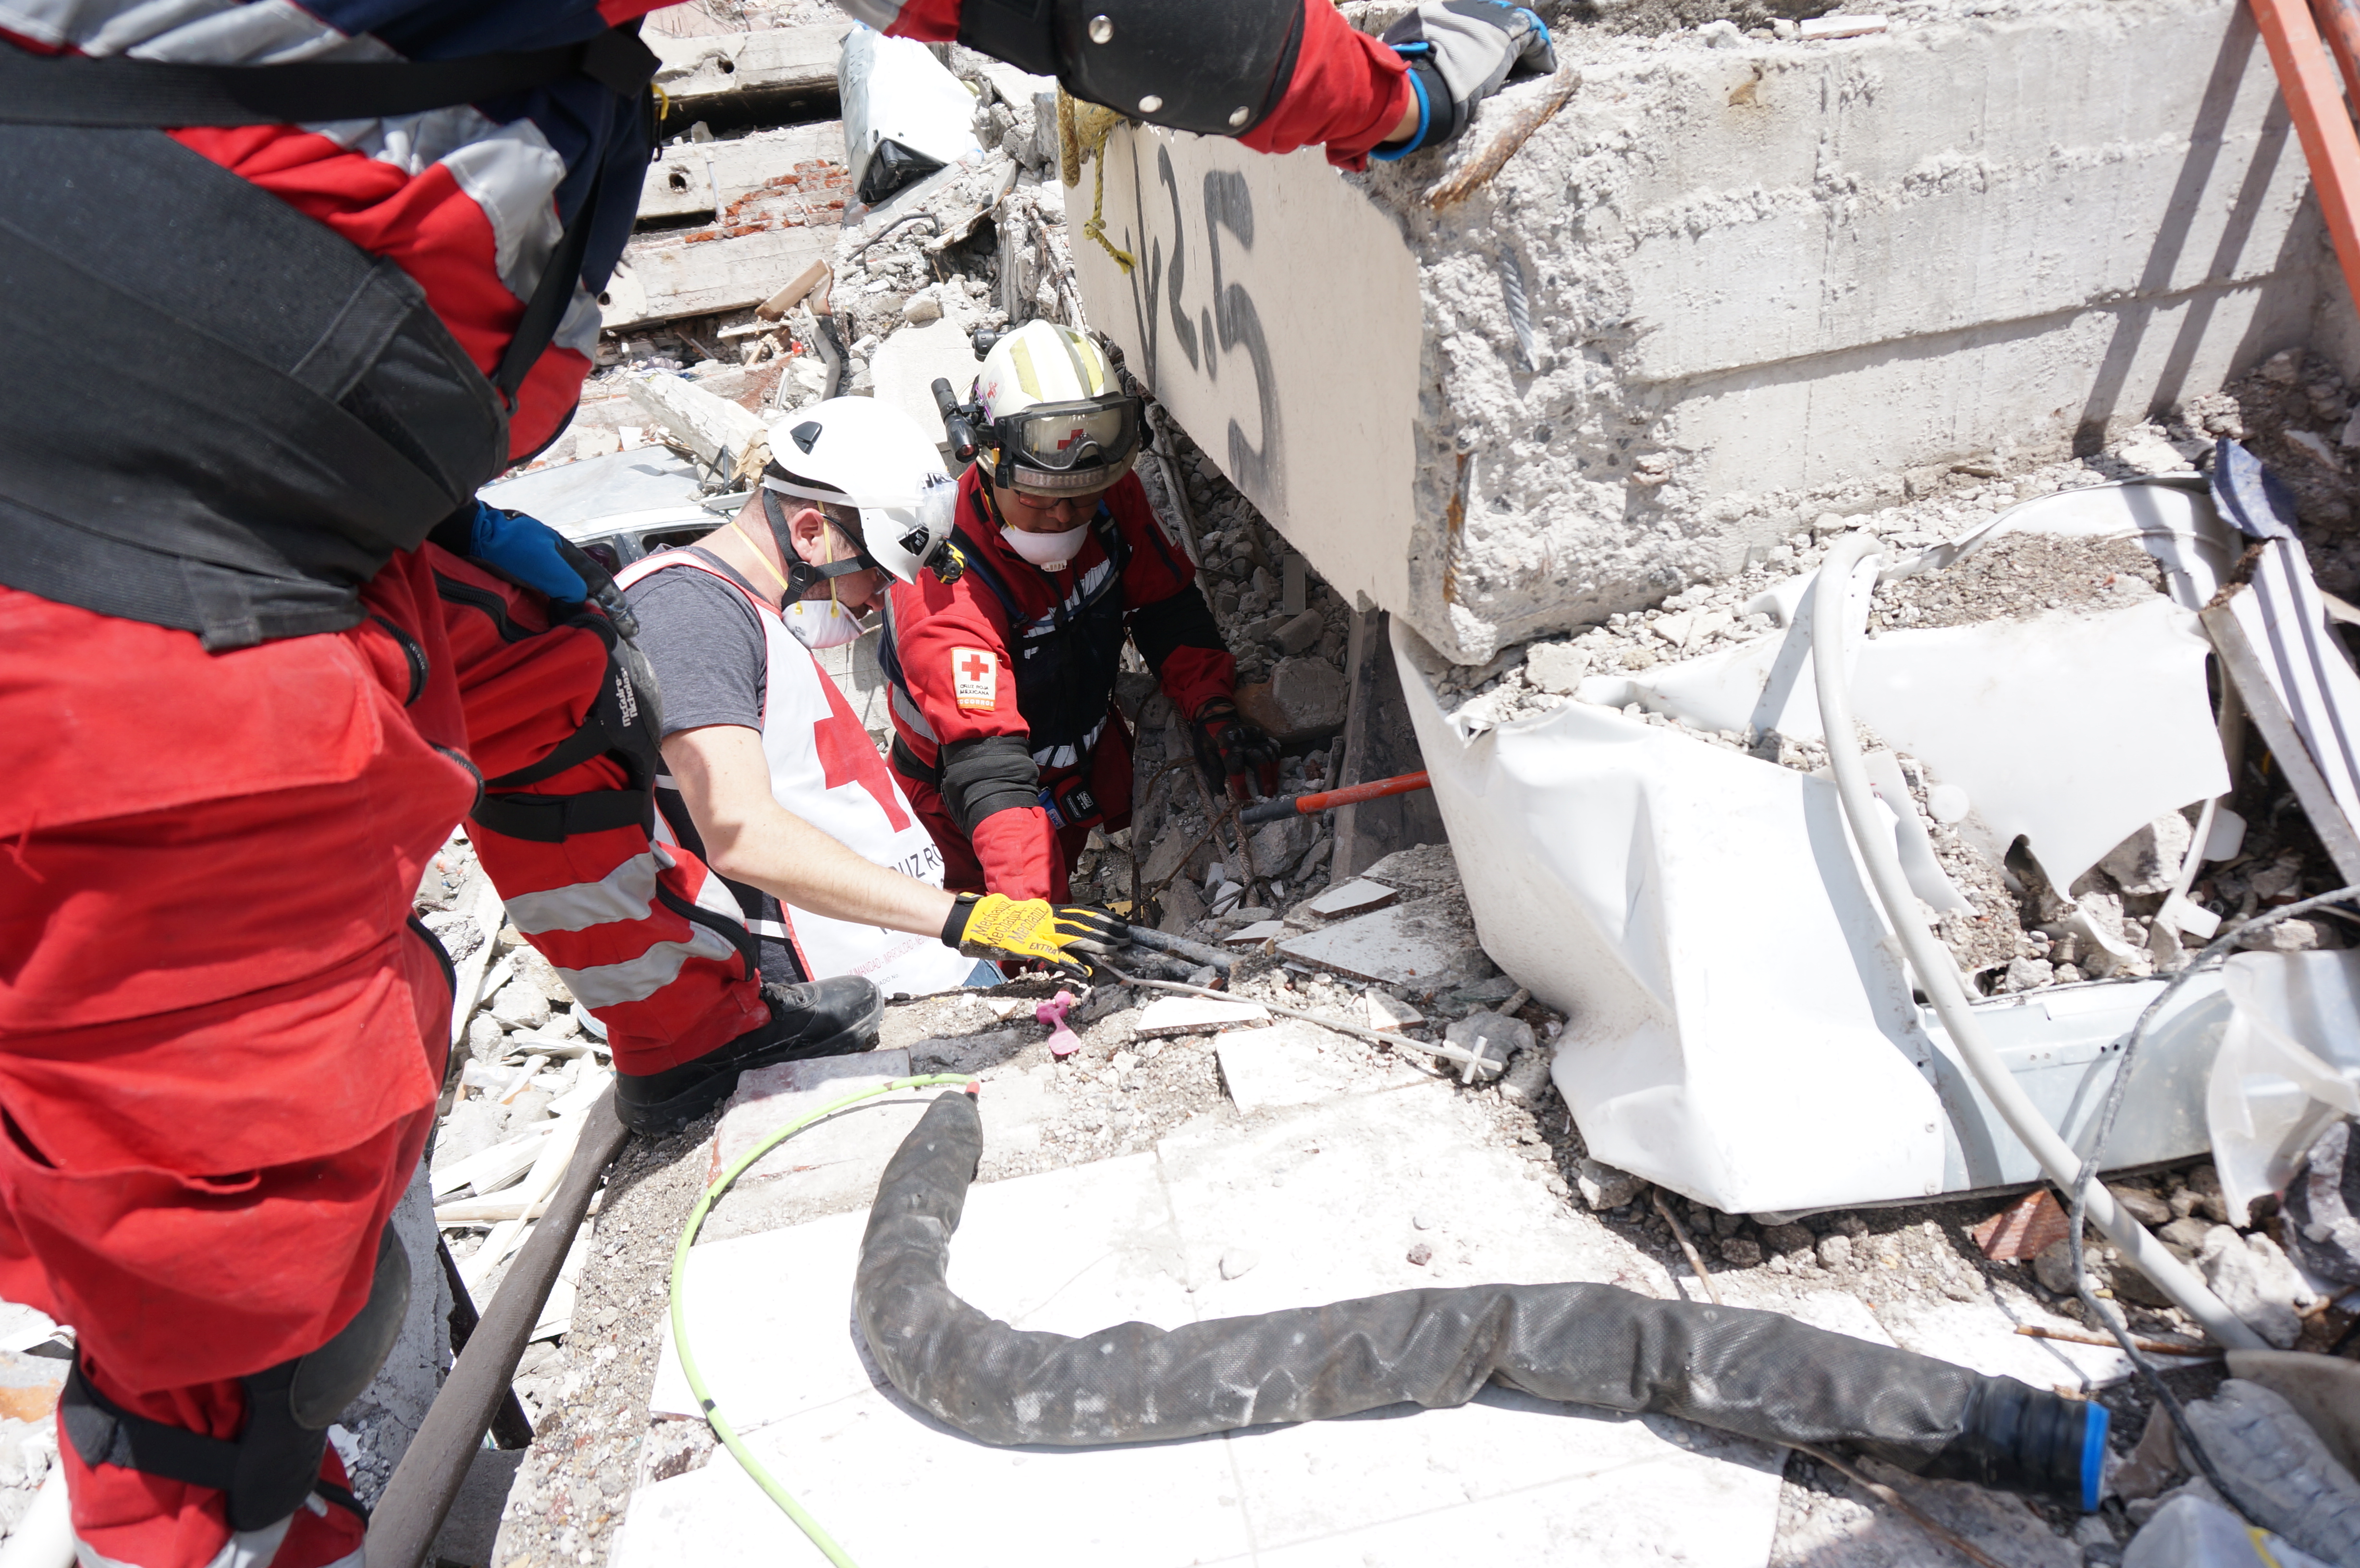
After the 2017 Mexico City earthquake, a snake robot provided camera views inside gaps inaccessible to conventional cameras.

CMU · Snake robot2018
Snake-robot deployment after the 2017 Mexico City earthquake.
Snake-robot deployment after the 2017 Mexico City earthquake.Carnegie Mellon University / Robotics Institute
01 / STUDY

Mechanism and experiments

After the 2017 Mexico City earthquake, the robot entered two voids in a damaged building that conventional cameras could not reach. Camera observations helped confirm that one was an unoccupied open space.

02 / CONTEXT

Test conditions and scope

Field work focused on camera observation. This deployment did not report finding or rescuing a trapped person.

03 / SOURCE

Papers and primary sources

Snake Robot Urban Search After the 2017 Mexico City Earthquake
Julian Whitman, Nico Zevallos, Matt Travers, Howie Choset
Carnegie Mellon University · 2018 publication