Back to cases
CASE 20 / Sensing

Torque touch and environment-in-the-loop manipulation

Torque, angle and pressure feedback support specific dexterous manipulation tasks without vision.

TAP2026
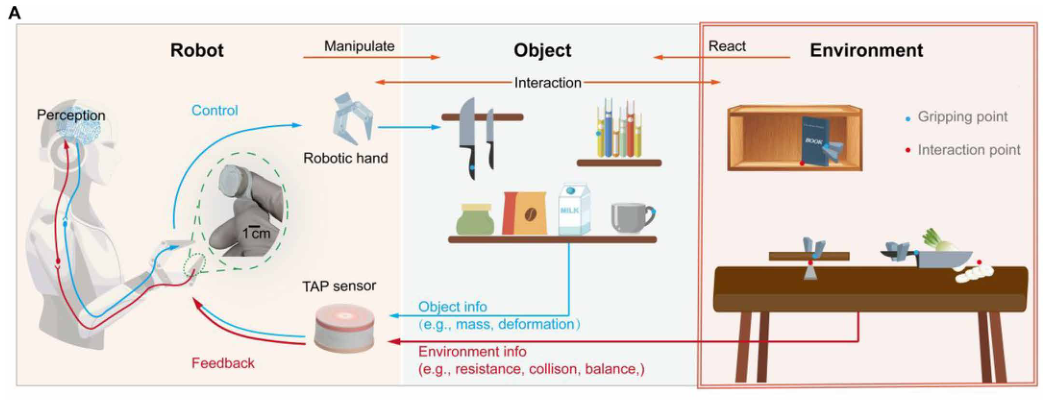
Wang et al., 2026, Fig. 1A: contact feedback for environment-in-the-loop manipulation.
Wang et al., 2026, Fig. 1A: contact feedback for environment-in-the-loop manipulation.Ling Wang, Yu Sun, Laihao Yang, Yuxuan Sun, Qingkai Guo, Yixue Liu, Xuefeng Chen, Yajing Shen

Watch the video

Paper-related demonstration: torque touch and manipulation tasks. · Wang et al. · 540p source video

01 / STUDY

Mechanism and experiments

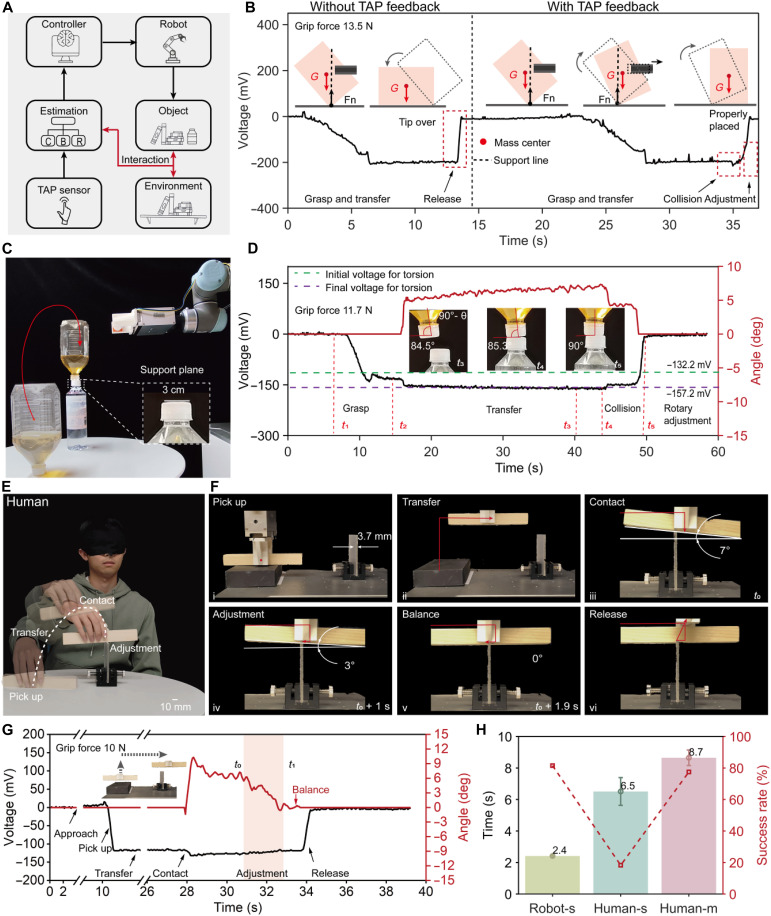
The TAP tactile sensor combines torque, angle and pressure for contact-state feedback. Demonstrations include stable placement, balance-beam stacking and adaptive cutting, offering research ideas for contact-rich manipulation in constrained spaces.

02 / CONTEXT

Test conditions and scope

Human-level comparisons in the paper concern the tested tasks. Maintenance use still needs validation of tool contact, loads and environmental compatibility.

03 / SOURCE

Papers and primary sources

Touching with torque enables human-level robotic dexterity
Ling Wang, Yu Sun, Laihao Yang, Yuxuan Sun, Qingkai Guo, Yixue Liu, Xuefeng Chen, Yajing Shen
Science Advances

EXPERIMENT / IMAGES

Experimental images
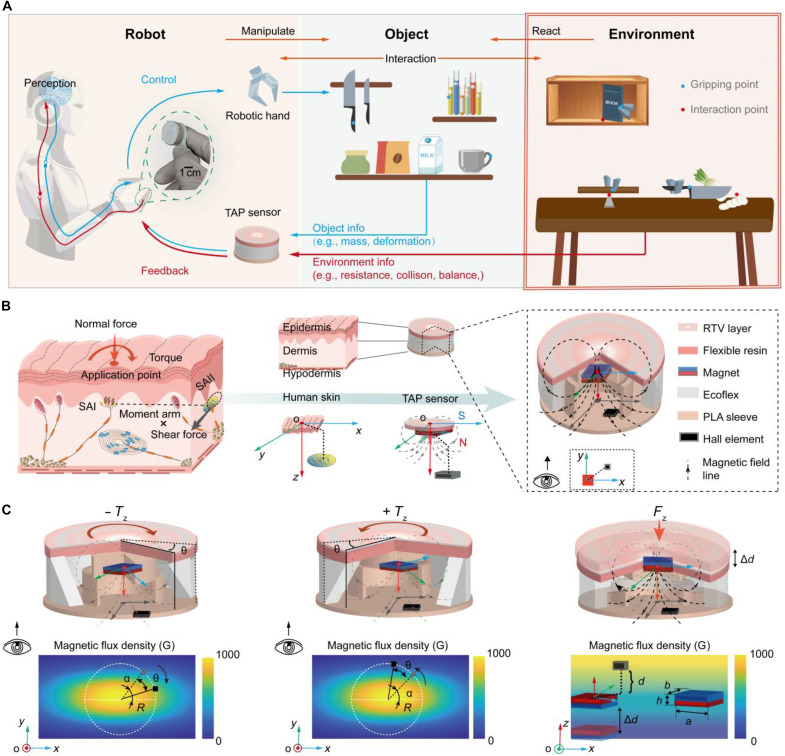
Wang et al., 2026, Fig. 1: feedback framework and TAP sensor structure.
Wang et al., 2026, Fig. 1: feedback framework and TAP sensor structure.Ling Wang, Yu Sun, Laihao Yang, Yuxuan Sun, Qingkai Guo, Yixue Liu, Xuefeng Chen, Yajing Shen · CC BY 4.0
Wang et al., 2026, Fig. 4: object placement and balance-beam experiments.
Wang et al., 2026, Fig. 4: object placement and balance-beam experiments.Ling Wang, Yu Sun, Laihao Yang, Yuxuan Sun, Qingkai Guo, Yixue Liu, Xuefeng Chen, Yajing Shen · CC BY 4.0