← Latest updates
Preprint · simulation and hardware
Coordinating a mobile base and continuum arm around obstacles
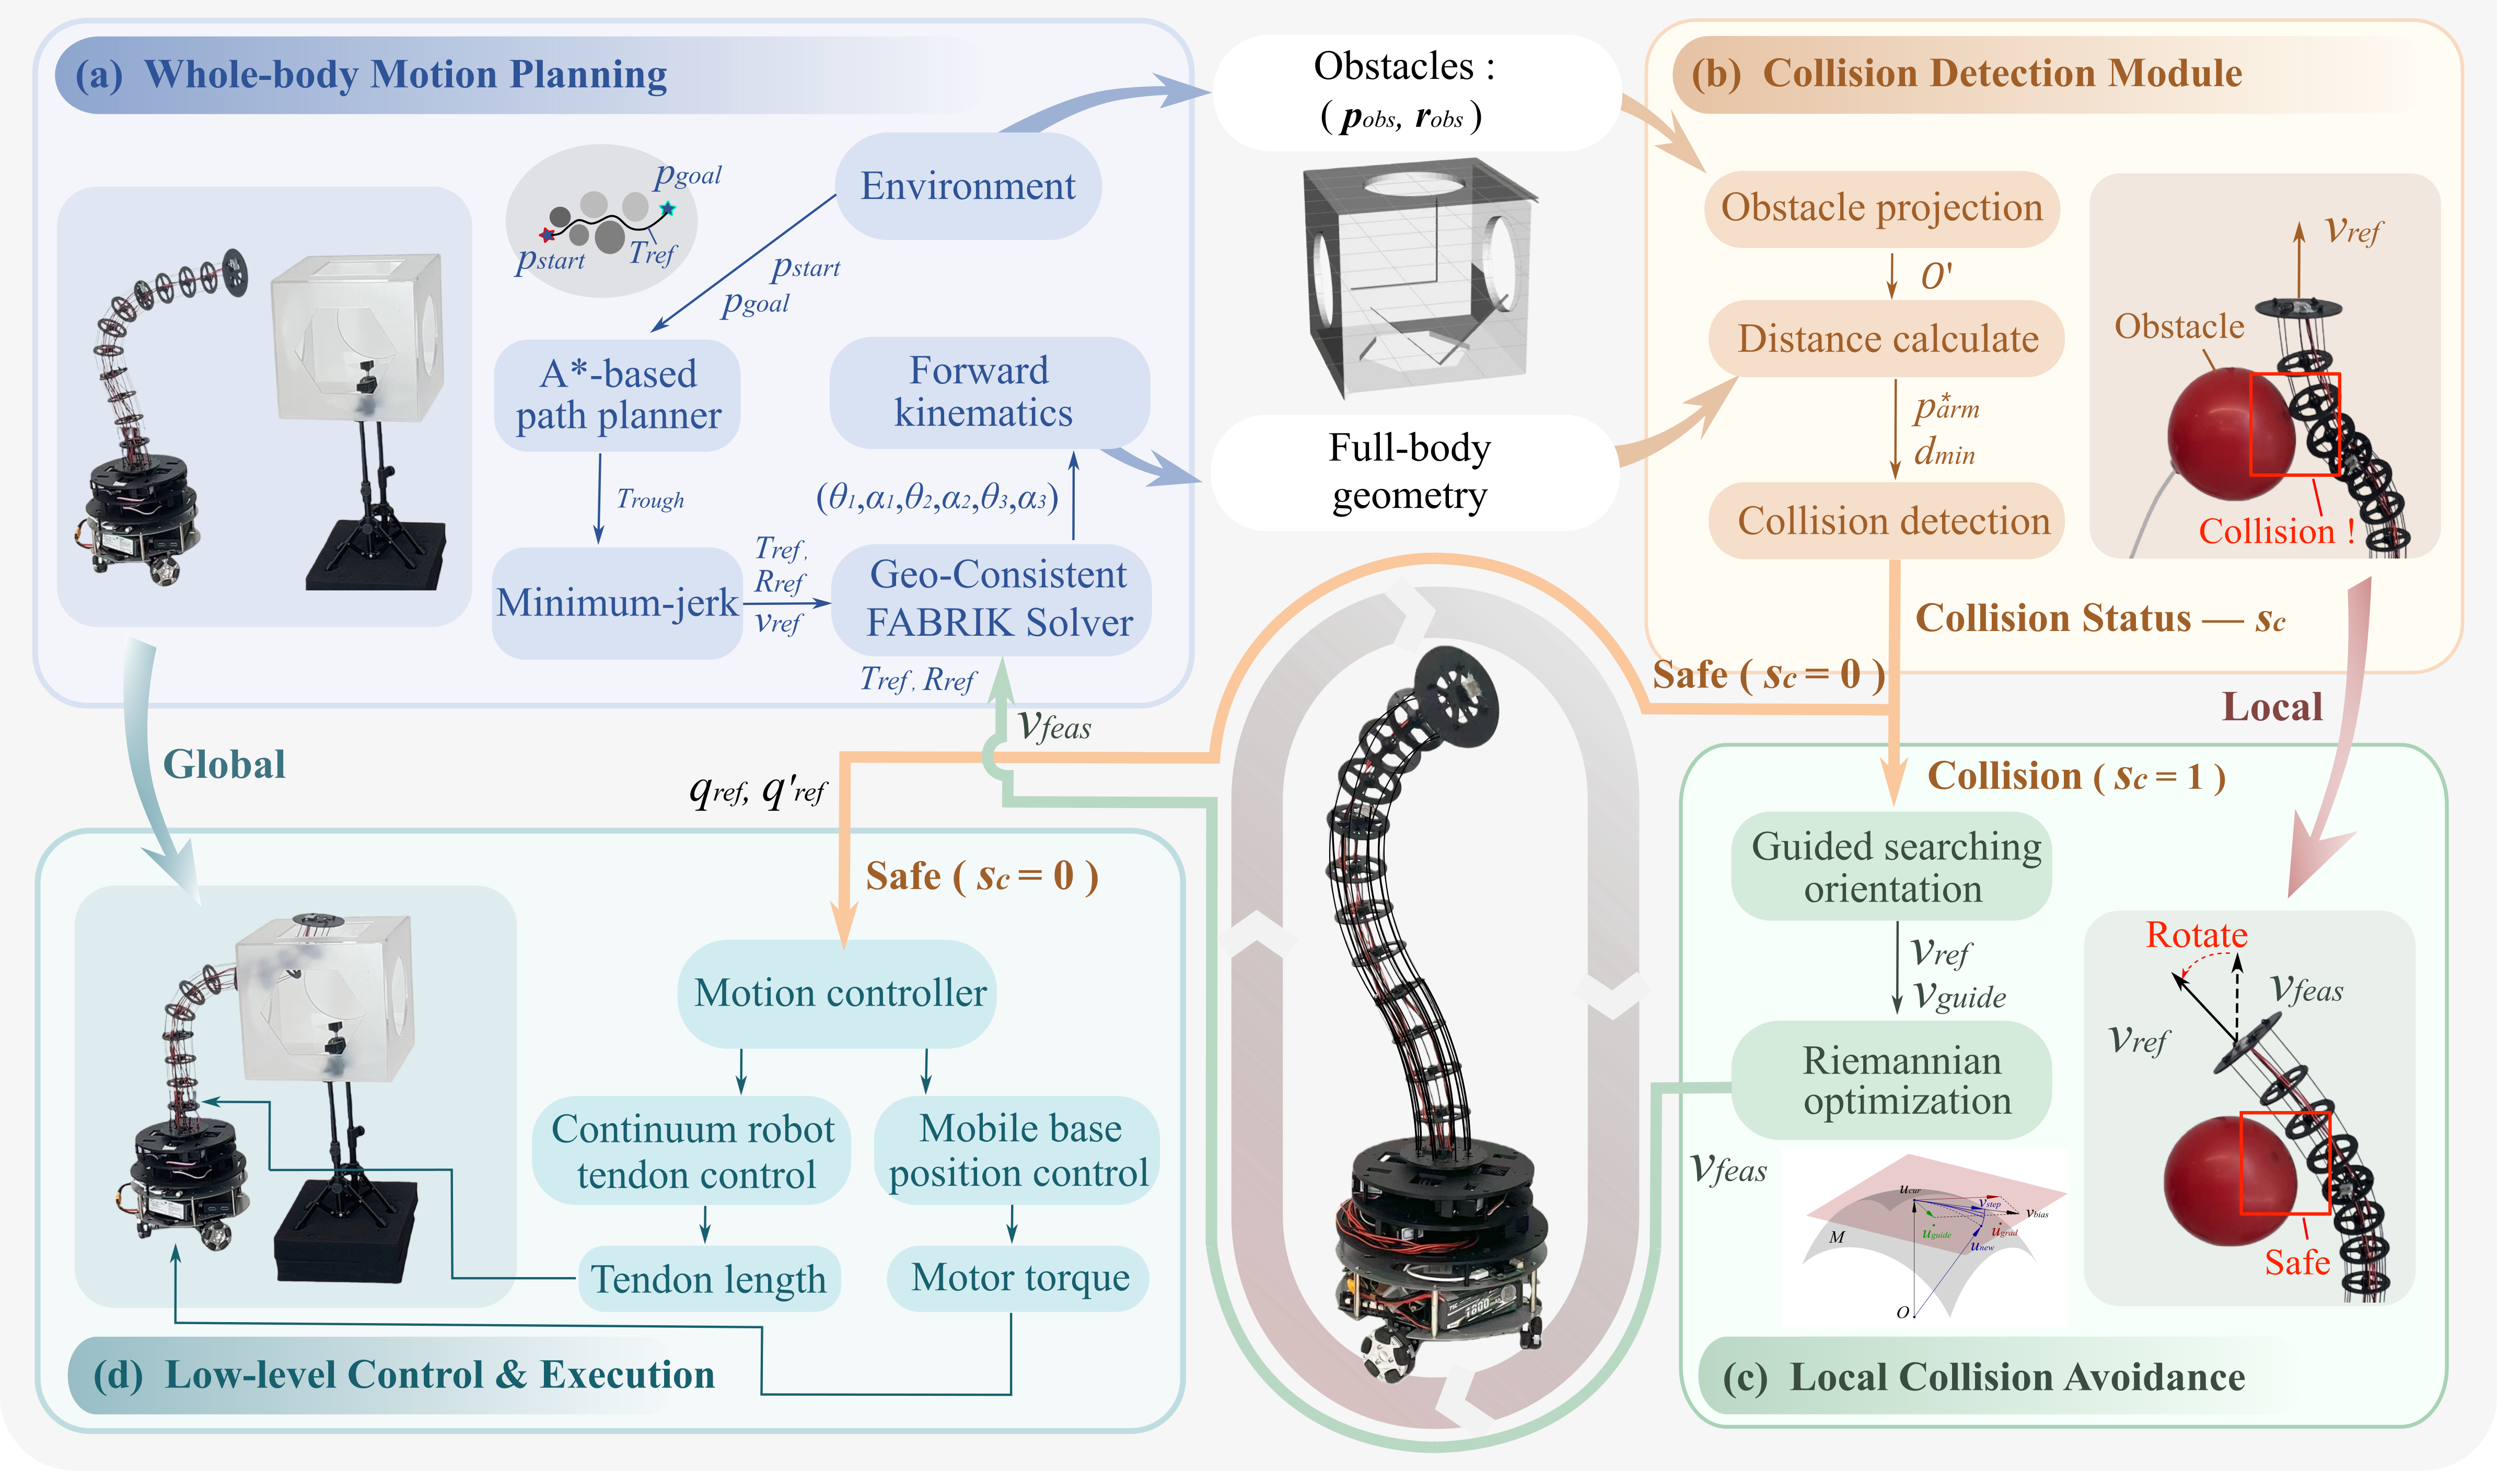
A unified framework combines long-horizon planning with local geometric refinement for coordinated base–arm motion in cluttered spaces.
- Source published
- Sources checked
- 2026-11-09
What changed
- A* and minimum-jerk planning provide references; inverse kinematics and Riemannian optimization coordinate base motion, arm shape and avoidance.
- The authors report pipe-traversal simulations and hardware trials among dense obstacles and in confined workspaces.
Relevance to constrained-space work
Feasibility concerns the base and the entire arm as well as the end-effector target.
Compiled by OpenRuwei editorial