 1080p
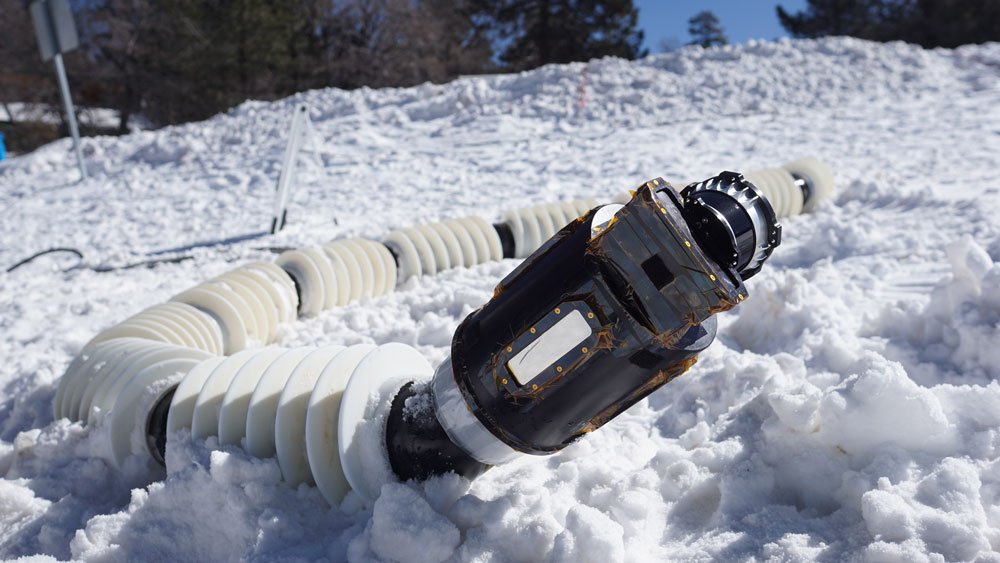
EELS: a snake robot for passages through ice
A segmented robot combines rotating screw propulsion with environmental mapping in ground tests on ice, snow, sand and glacier passages.
Ground prototypes and glacier testsRead case
Navigate winding paths to observe and manipulate within limited space.
NASA/JPL-Caltech1080pA segmented robot combines rotating screw propulsion with environmental mapping in ground tests on ice, snow, sand and glacier passages.
 1080p
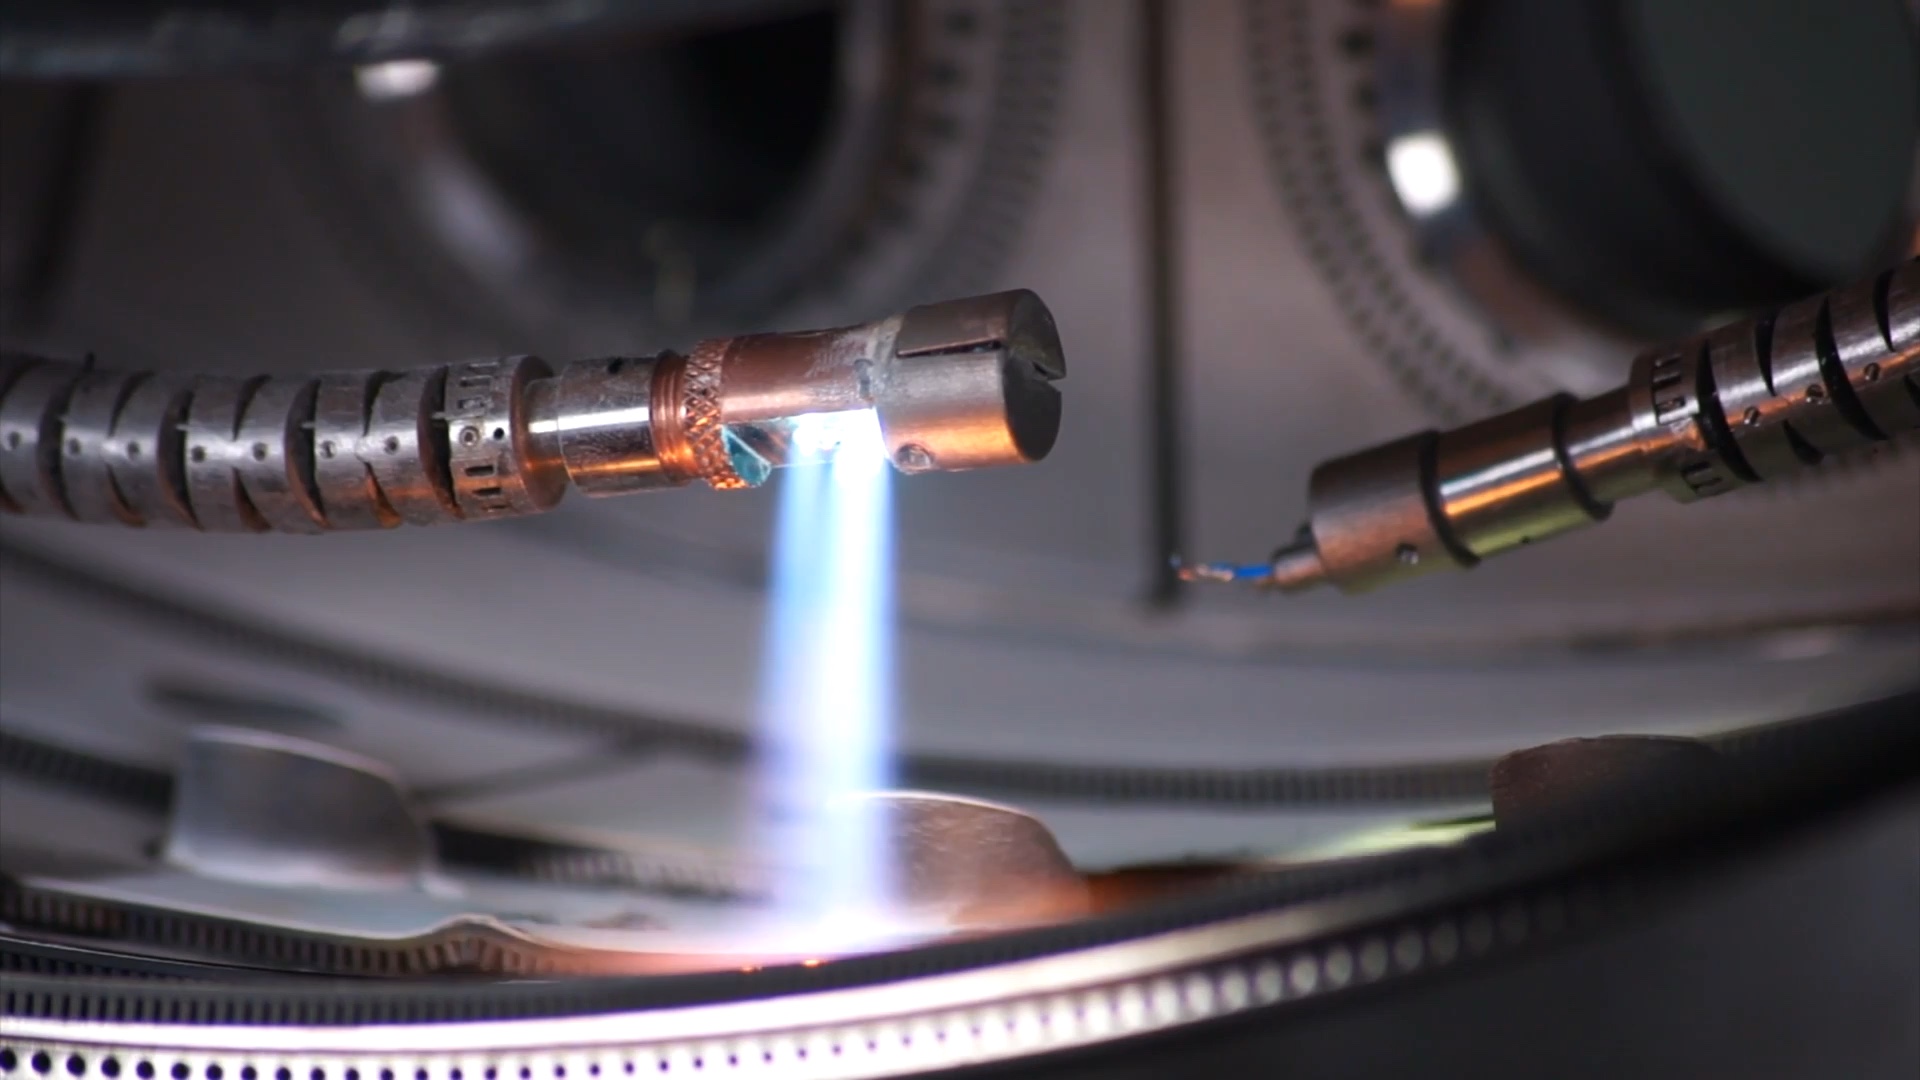
Two snake robots reach a combustor through limited access to observe and patch local thermal-barrier coating damage.
 1080p
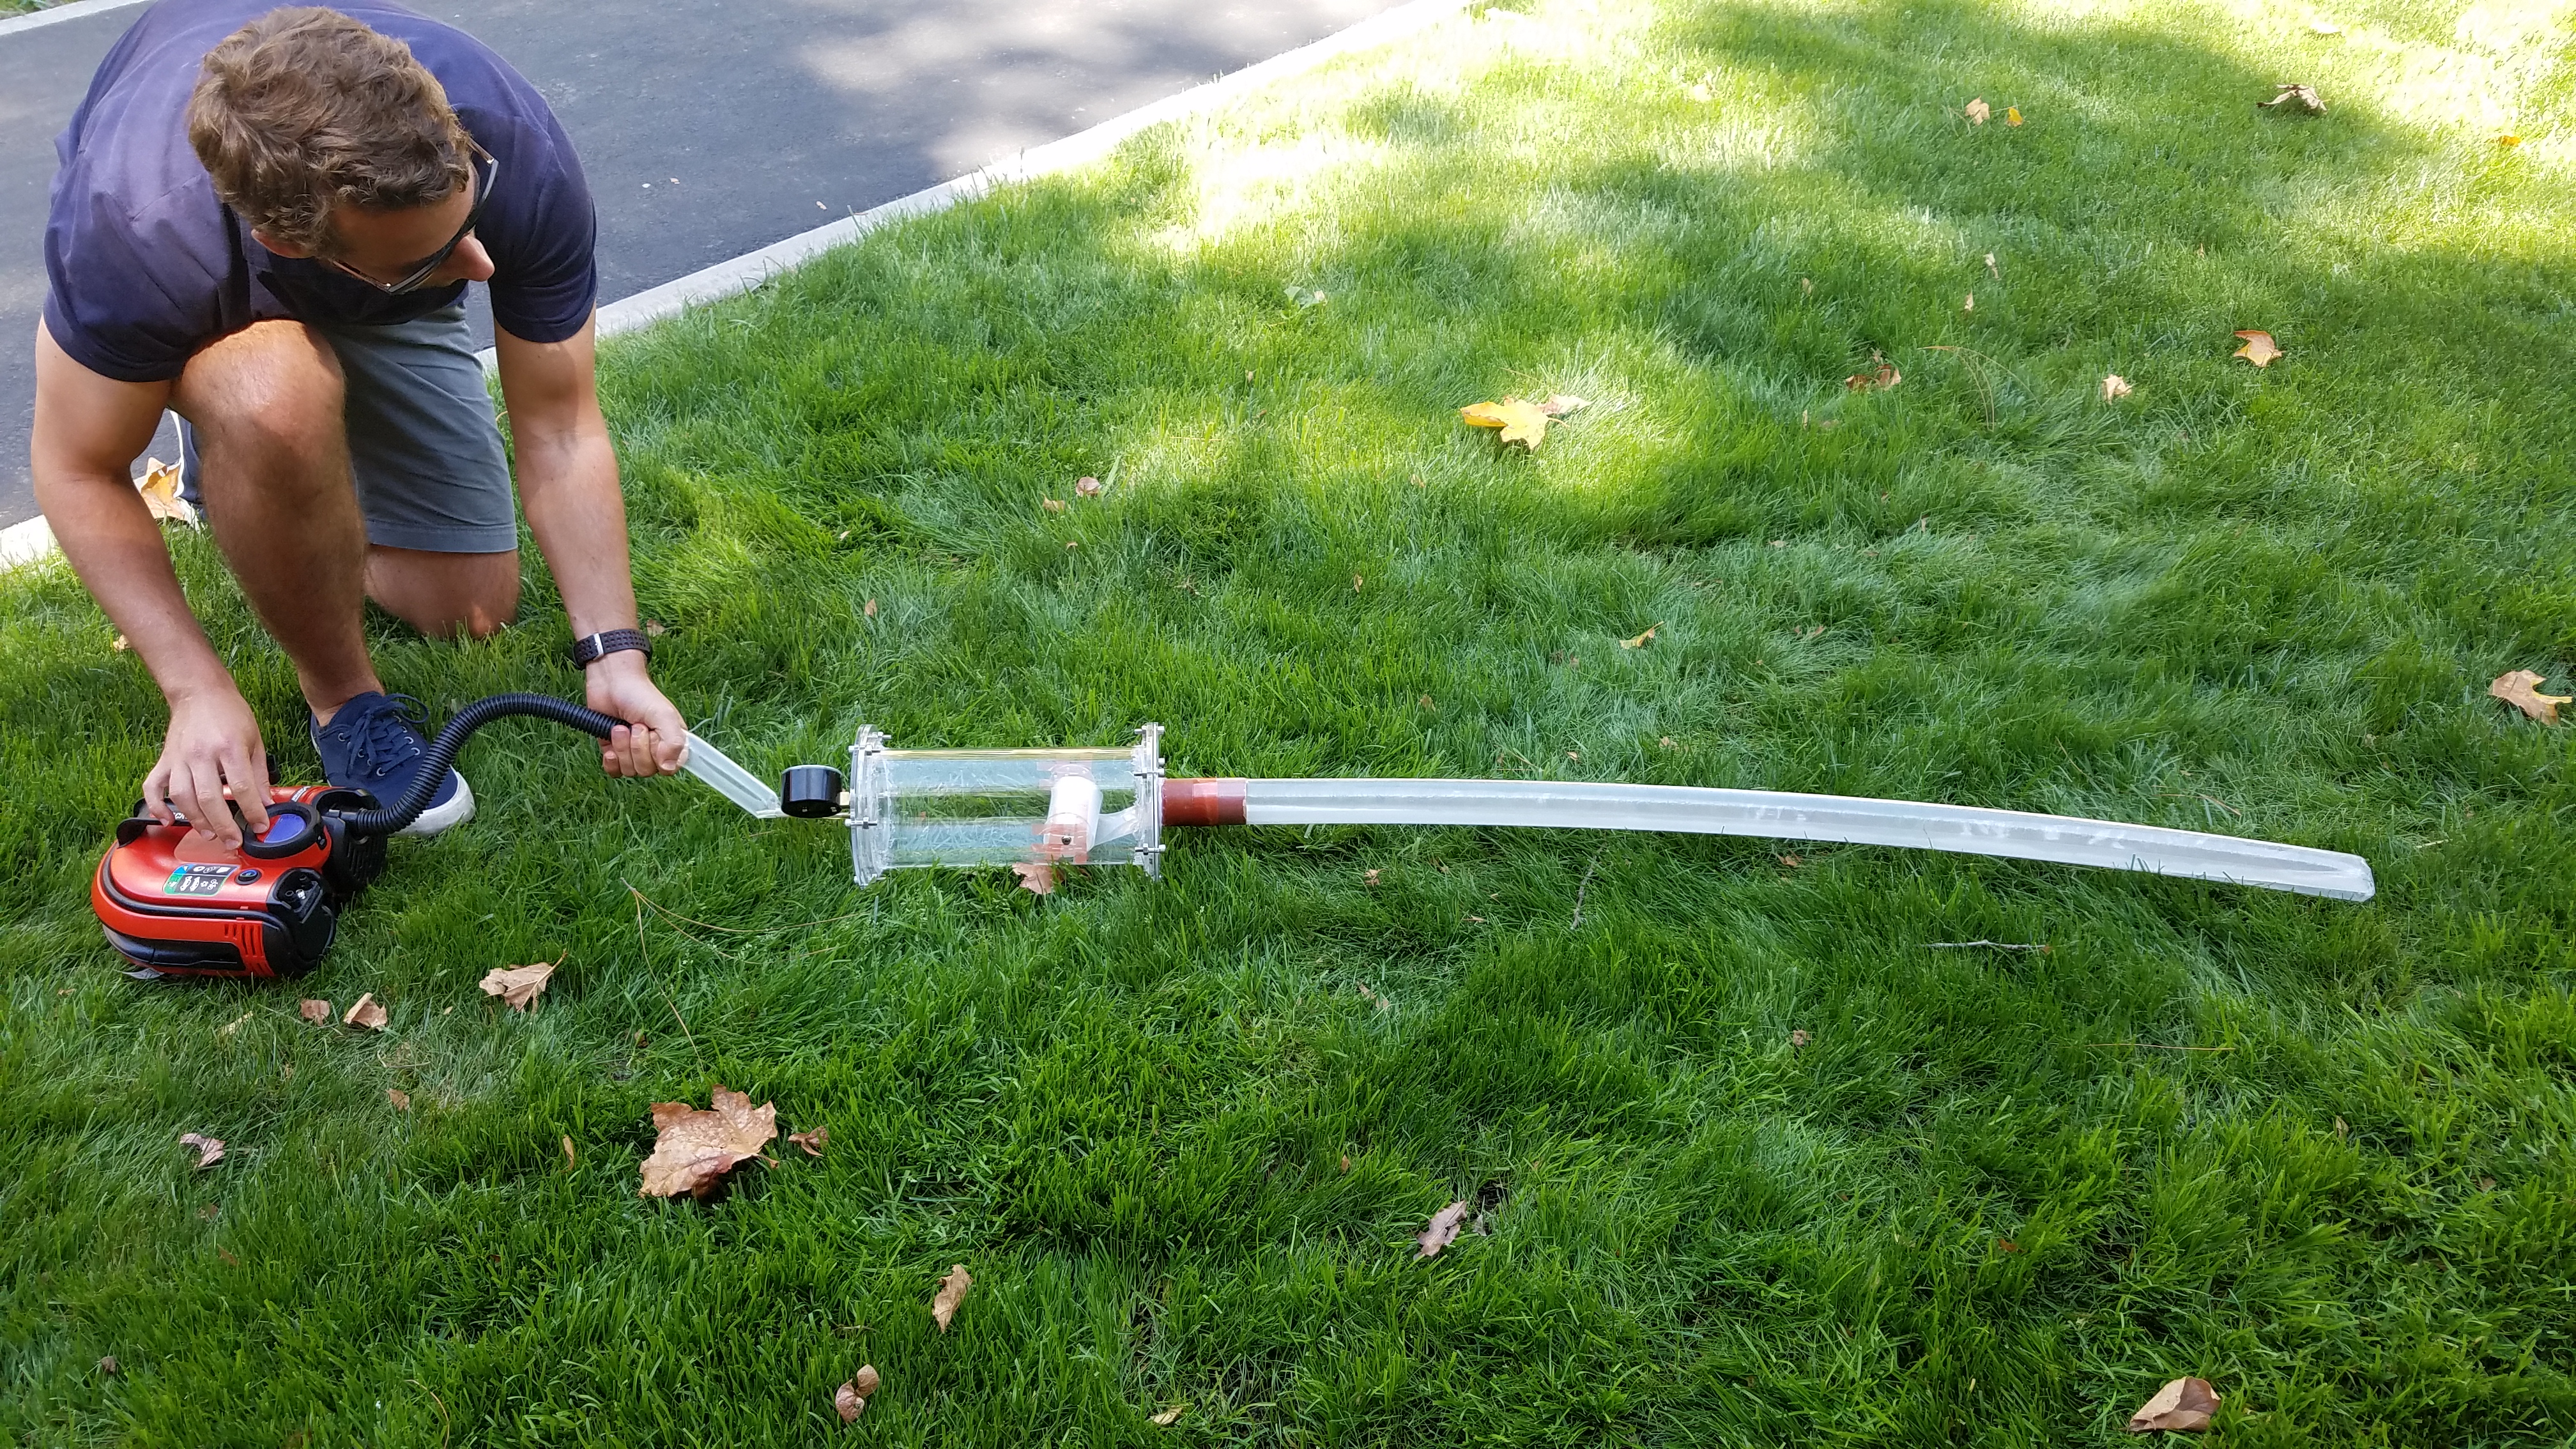
A flexible tube grows by eversion at its tip, offering another way to move around obstacles.
 4K
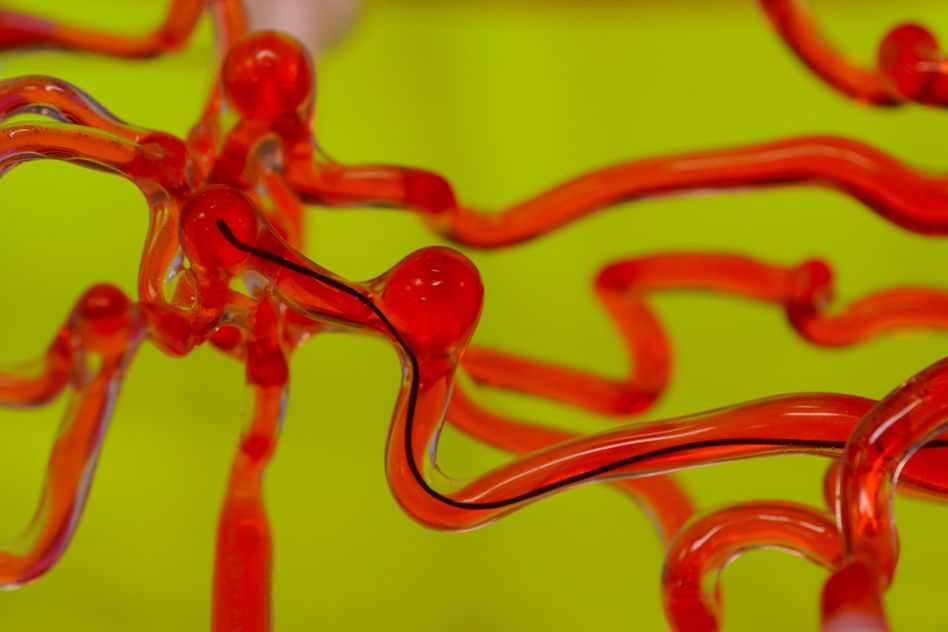
A magnetic field steers a slender thread, with a hydrogel coating to reduce friction.
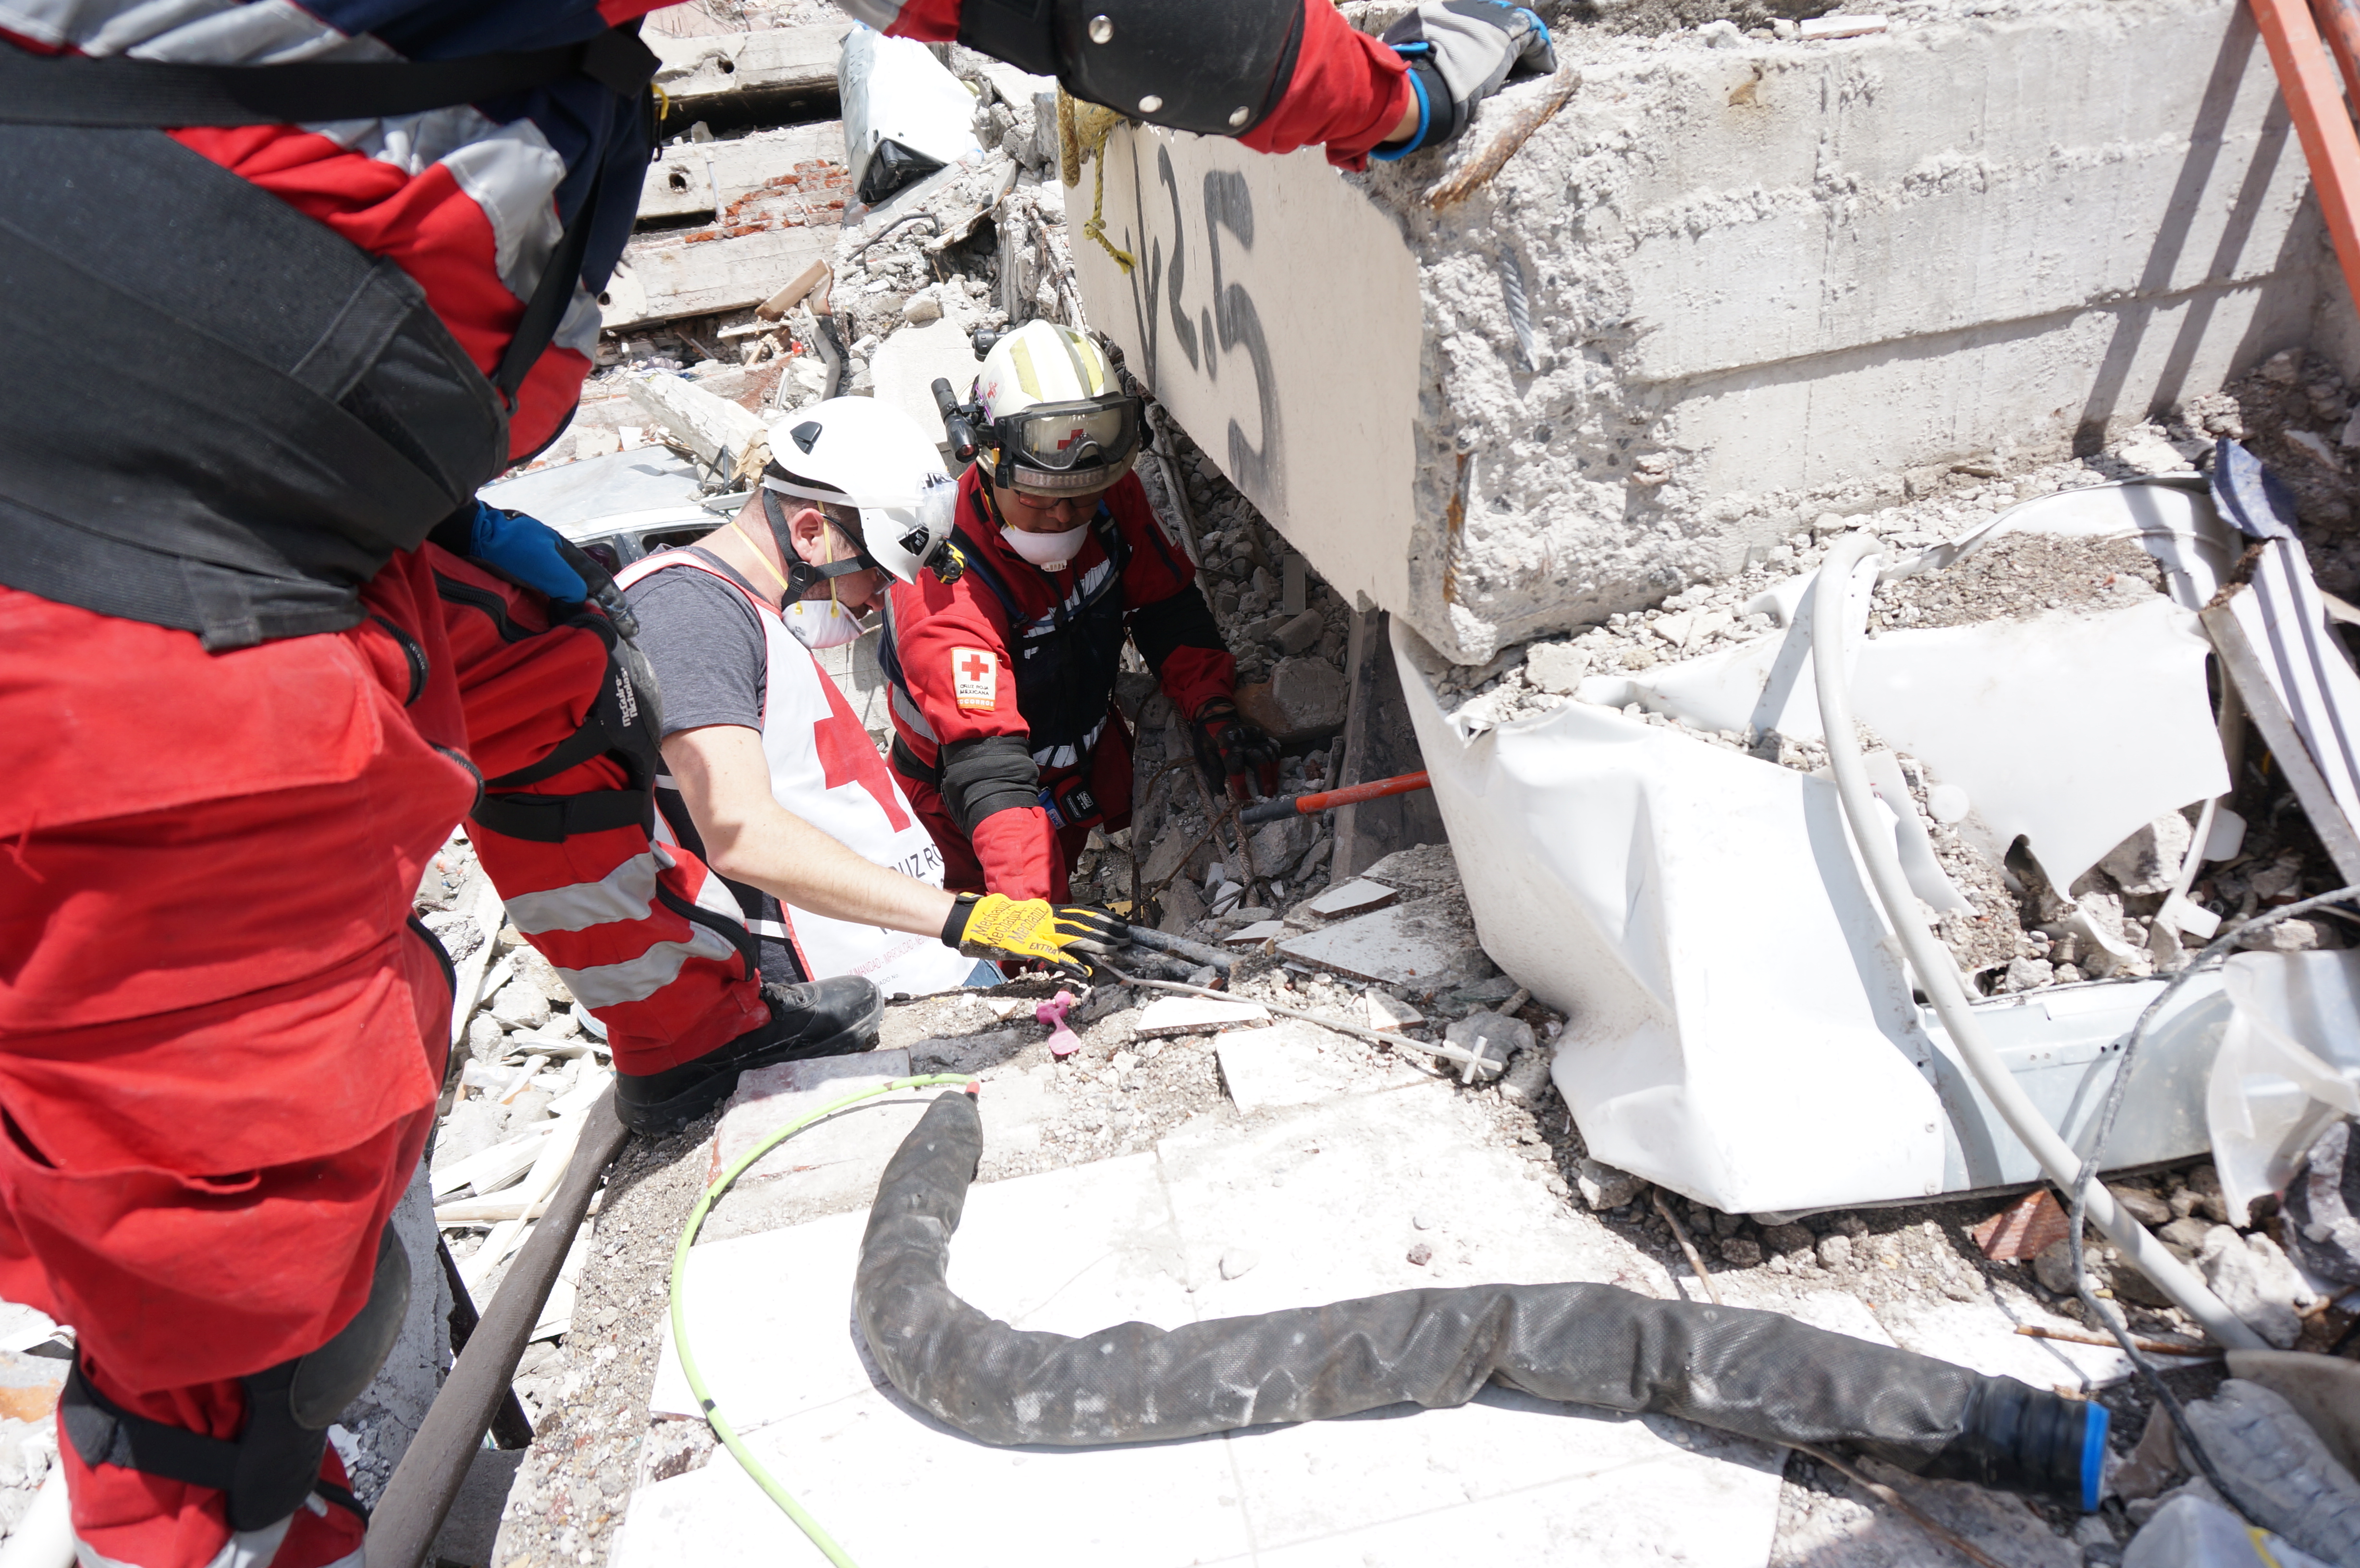
After the 2017 Mexico City earthquake, a snake robot provided camera views inside gaps inaccessible to conventional cameras.
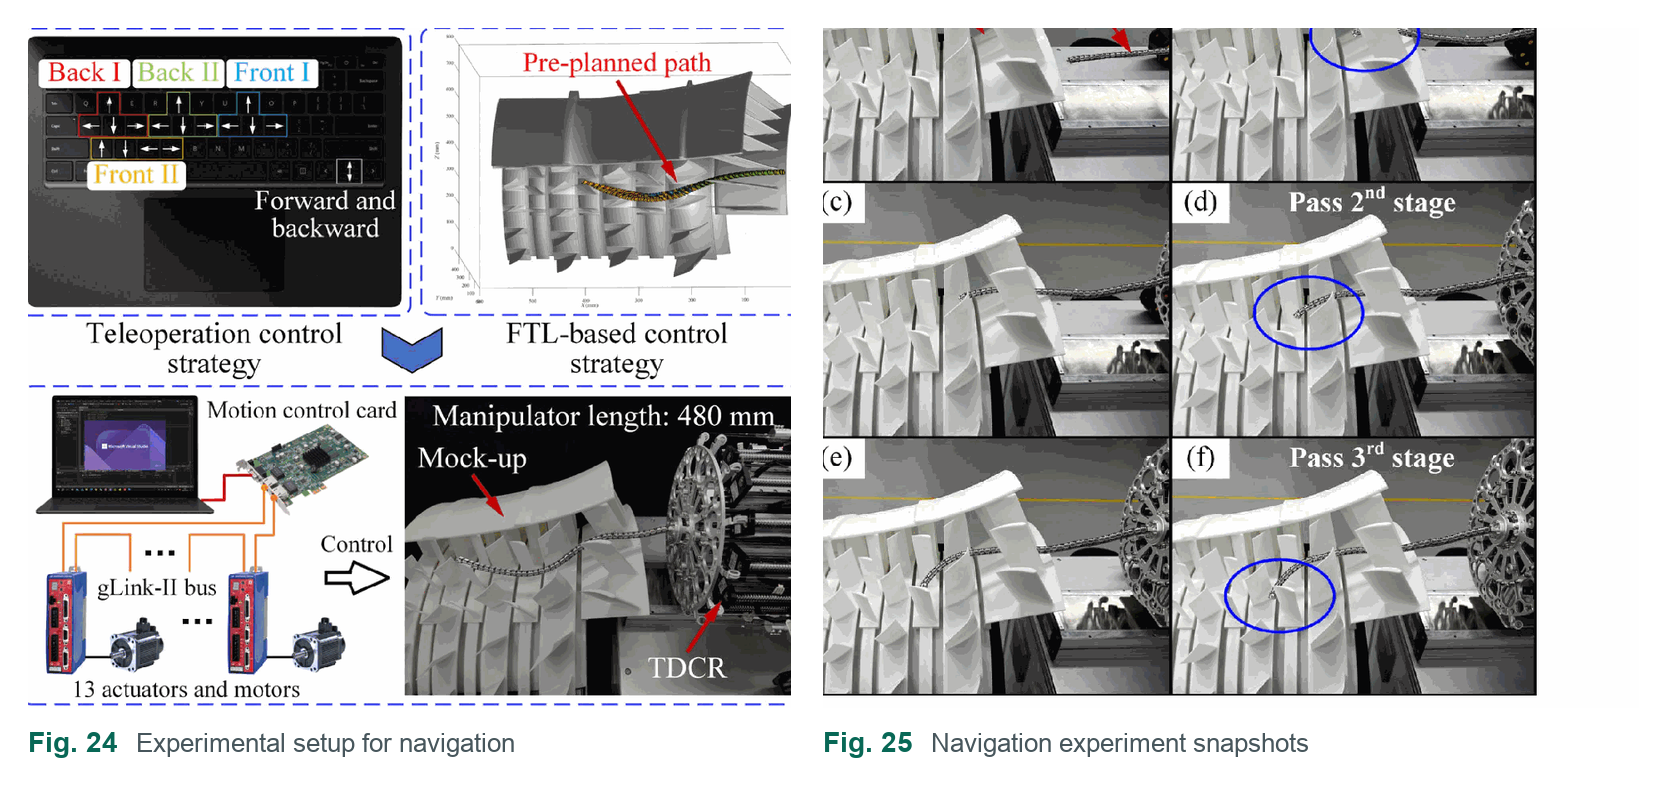 480p
Internal contact-aided compliant mechanisms improve a slender manipulator’s resistance to twisting and compression buckling.
Nested tendon-driven and concentric-tube structures use axial sliding to adjust a continuum robot’s configuration and stiffness.
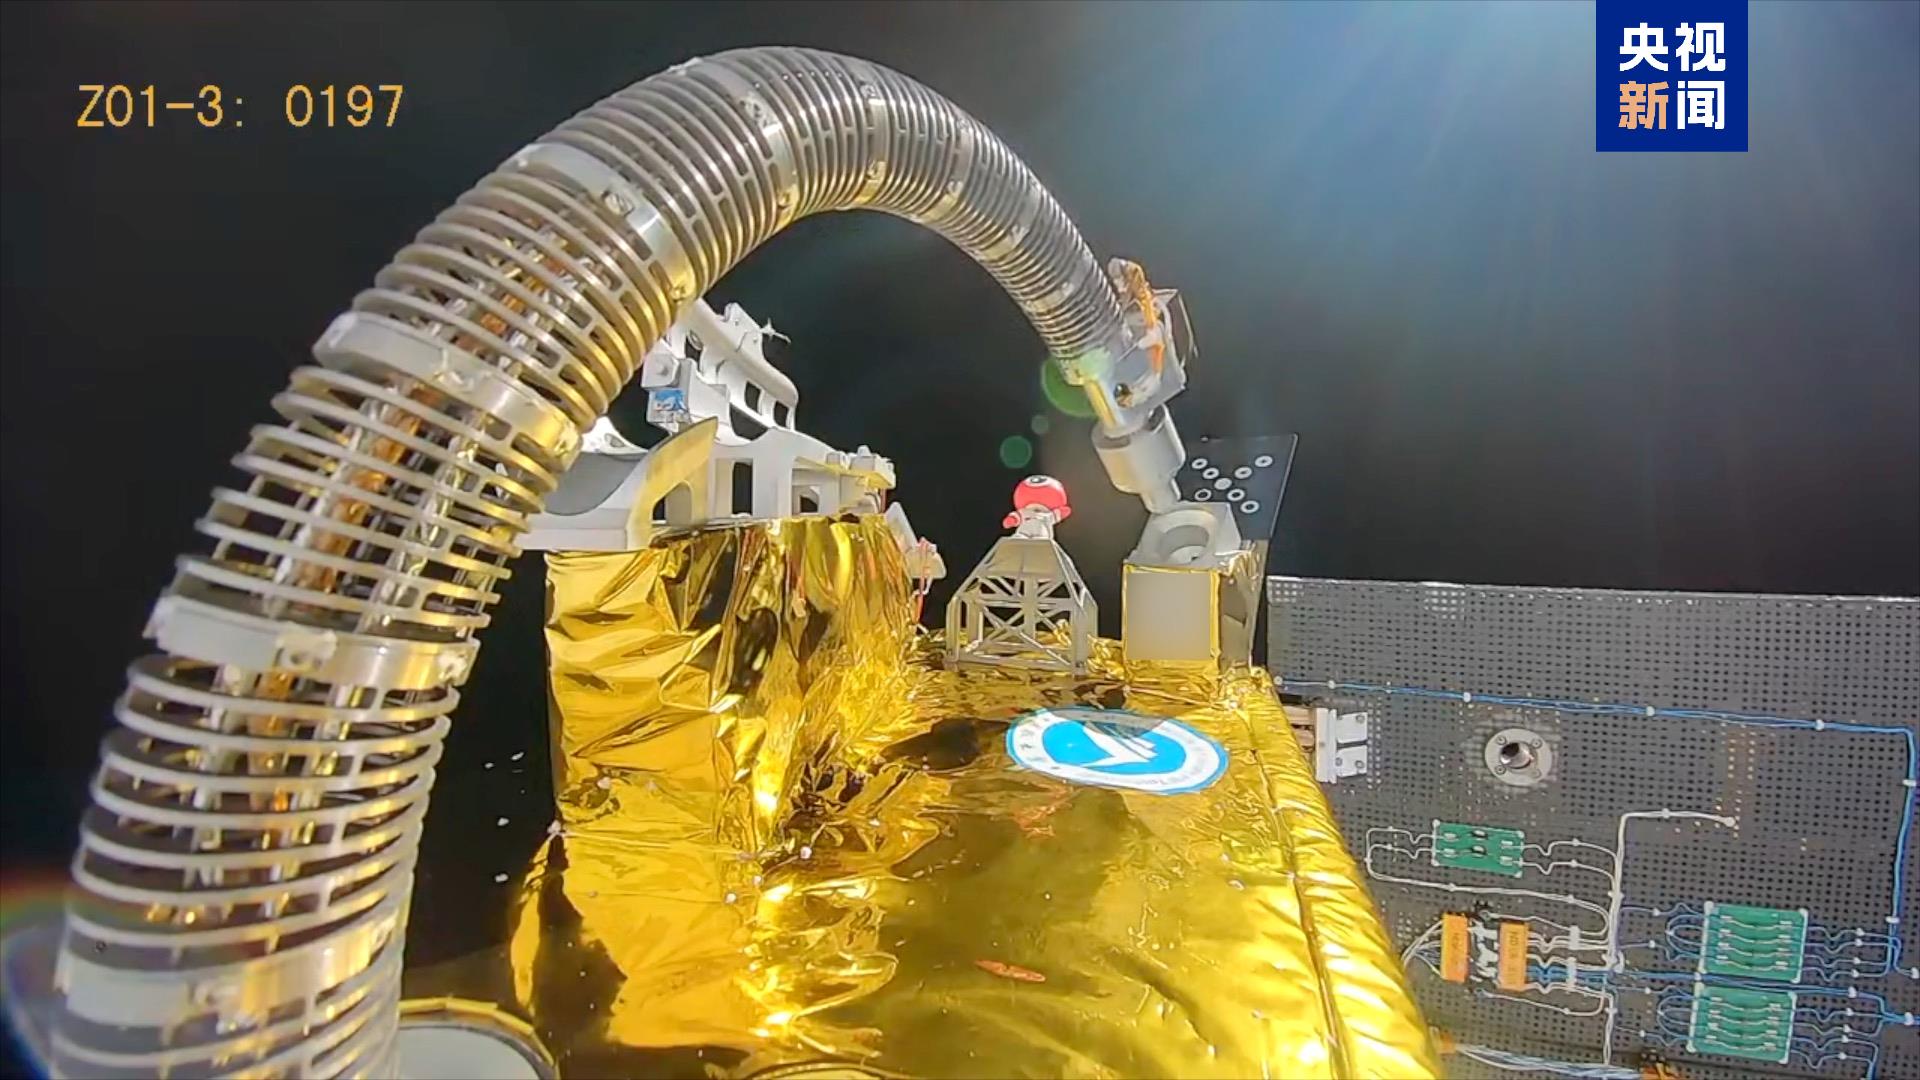 Video
Orbital tests aboard Xiyuan-0 examined simulated refuelling and compliant manipulation.
Field-record noteEELS brings locomotion, mapping and risk assessment into a single exploration task.
Snake-like form and continuum structure overlap, but are not interchangeable. Each case retains its specific mechanism description.
Working on a related study? Submit a project with its objectives, progress and resource access.
Visit community projects ↗