Watch the video
Biped locomotion experiment from the official project page. · Hybrid Robotics · UC Berkeley · 720p source video
01 / STUDY
Mechanism and experiments
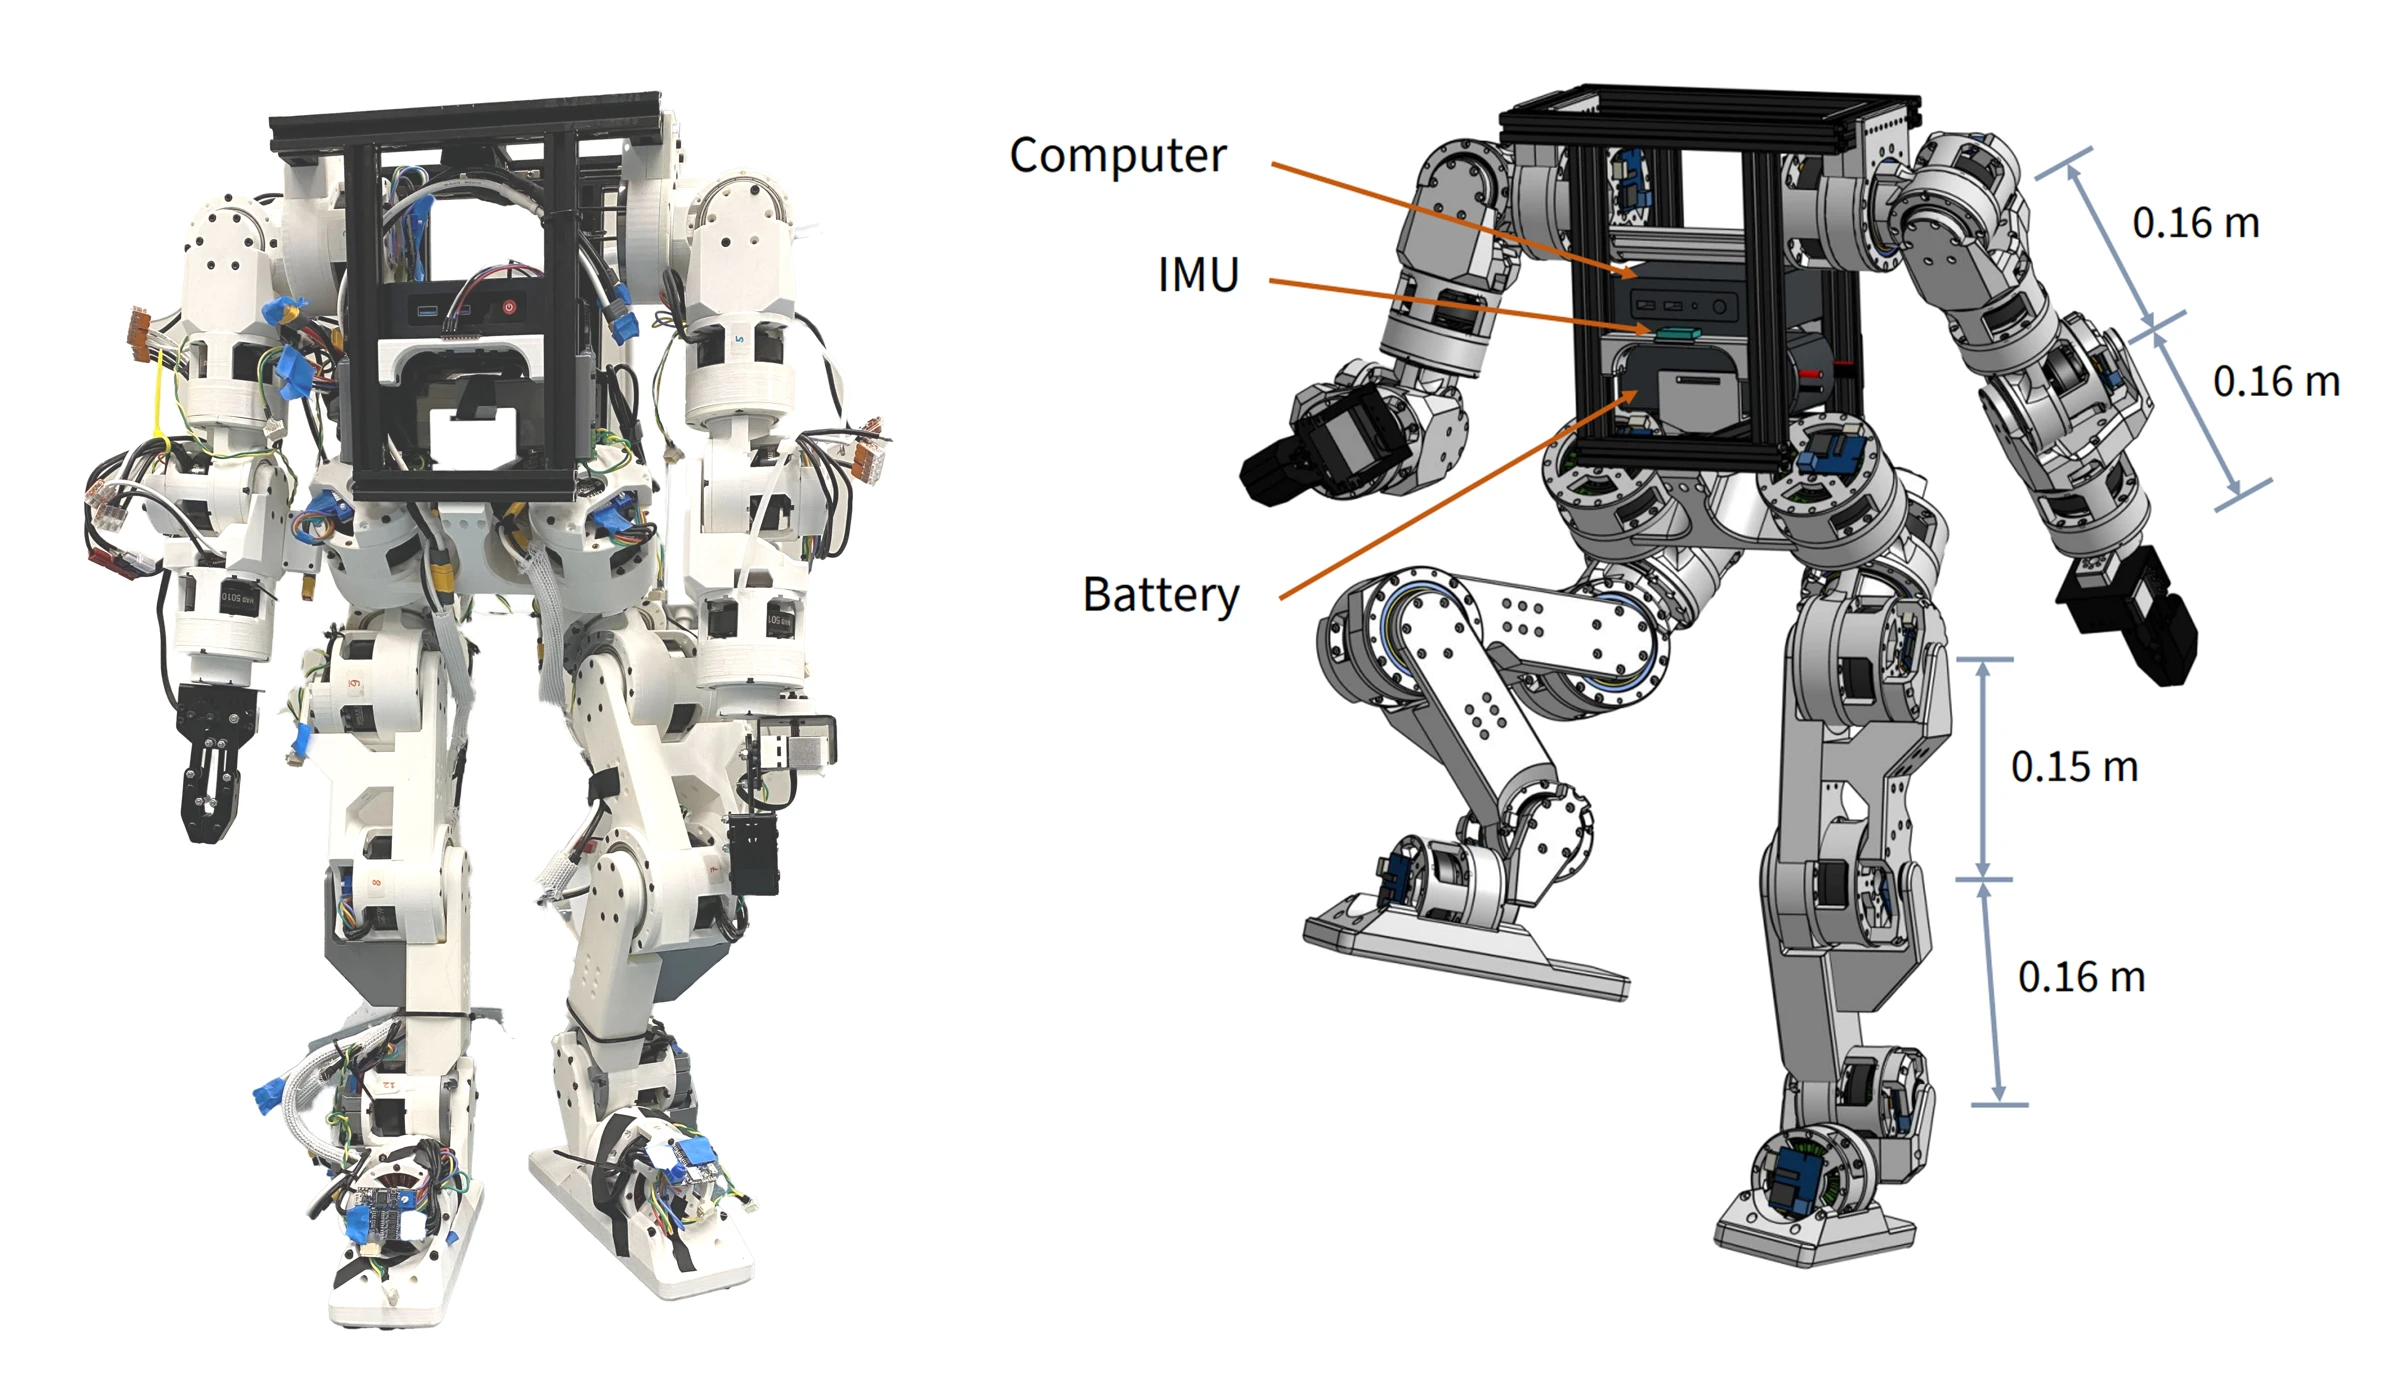
The modular platform uses 3D-printed cycloidal gearboxes. Demonstrations include arm manipulation and bipedal locomotion. A reinforcement-learning controller is trained in simulation and transferred to hardware. Official resources include hardware, embedded software, training and deployment code.
02 / CONTEXT
Test conditions and scope
Manipulation and walking are demonstrated in different configurations. Reproduction requires the matching mechanism, actuators and control version; tabletop demonstrations do not establish mobile manipulation or industrial servicing.
03 / SOURCE