01 / STUDY
Mechanism and experiments
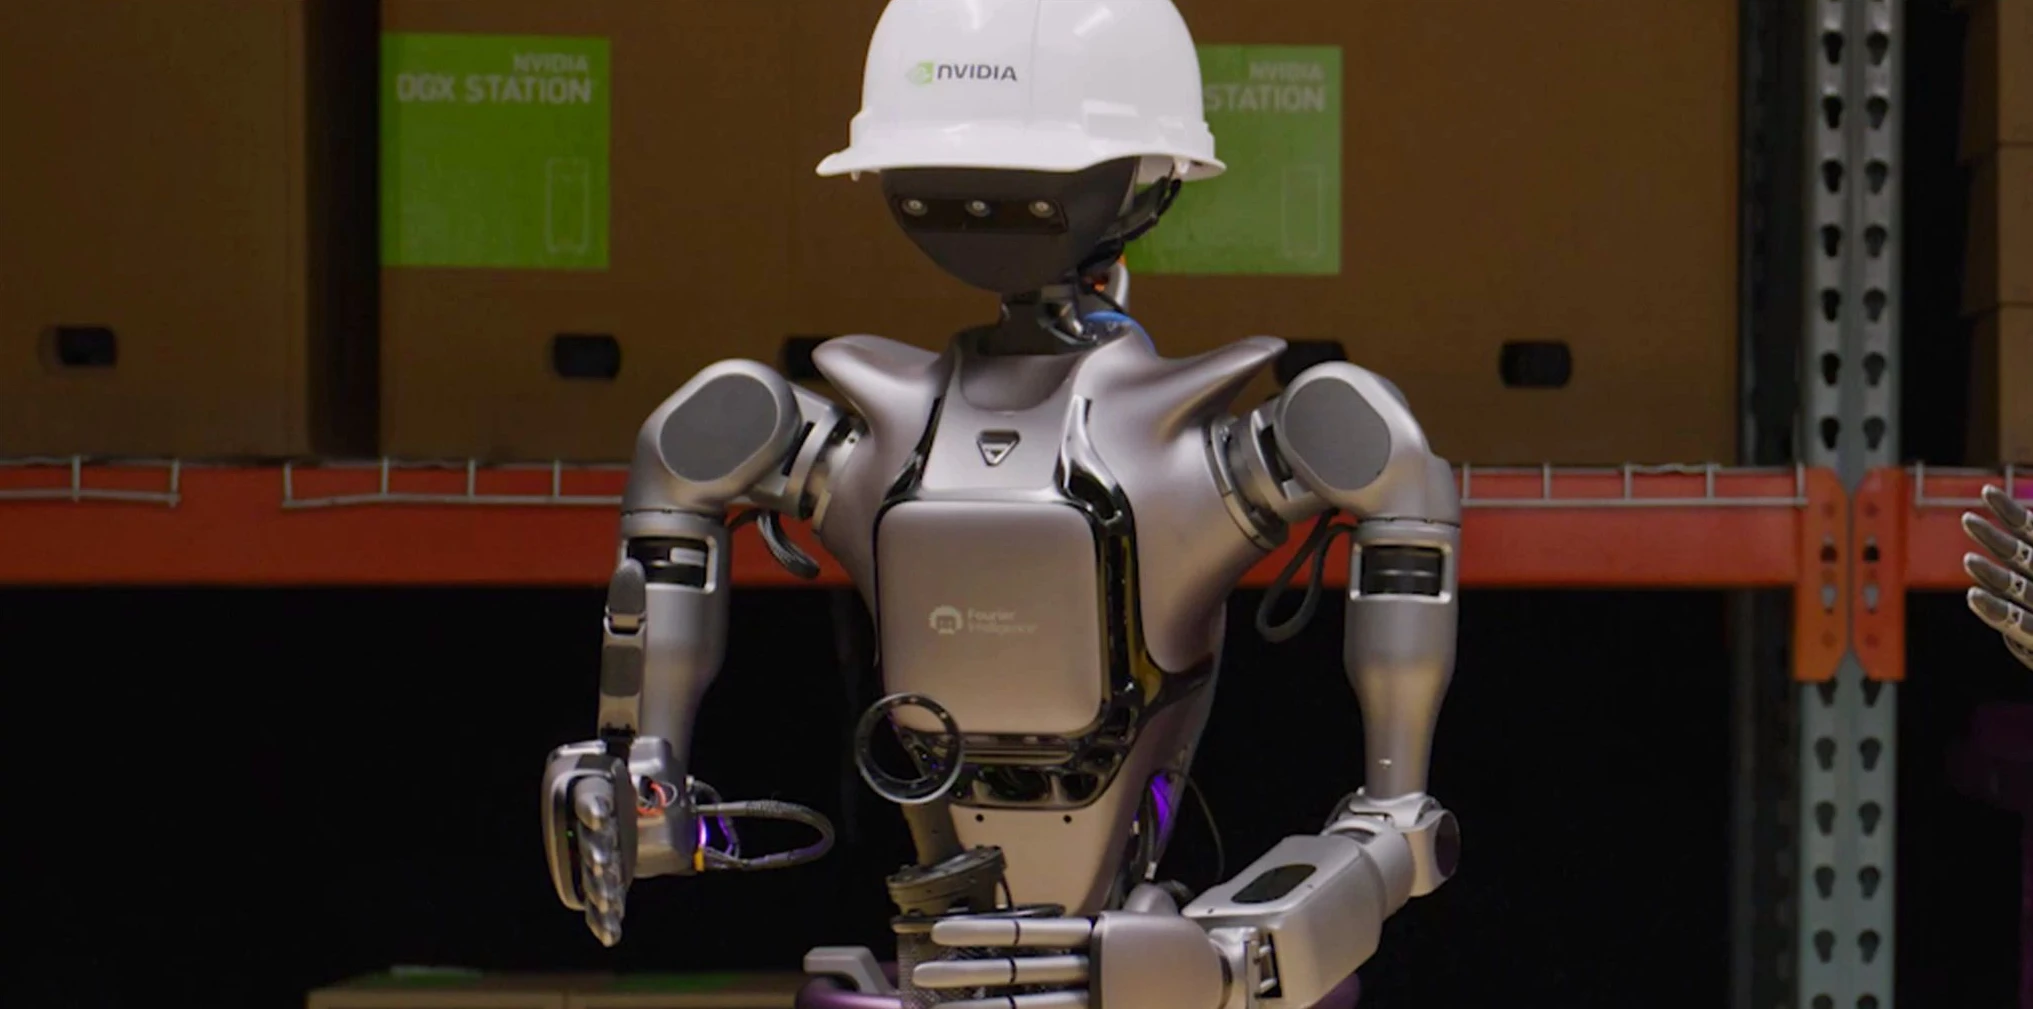
GR00T N1 maps images, language and robot state to continuous actions. The 2025 study tests bimanual manipulation on platforms including Fourier GR1 and releases model, training and inference resources. Isaac Lab tasks support data generation and policy evaluation; hardware recordings document outcomes on specific robots.
02 / CONTEXT
Test conditions and scope
This case documents the N1 experiments; Resources links to the evolving GR00T repository. Simulation and hardware results must be read separately, and an older demonstration does not establish current-model performance on arbitrary robots.
03 / SOURCE