Watch the video
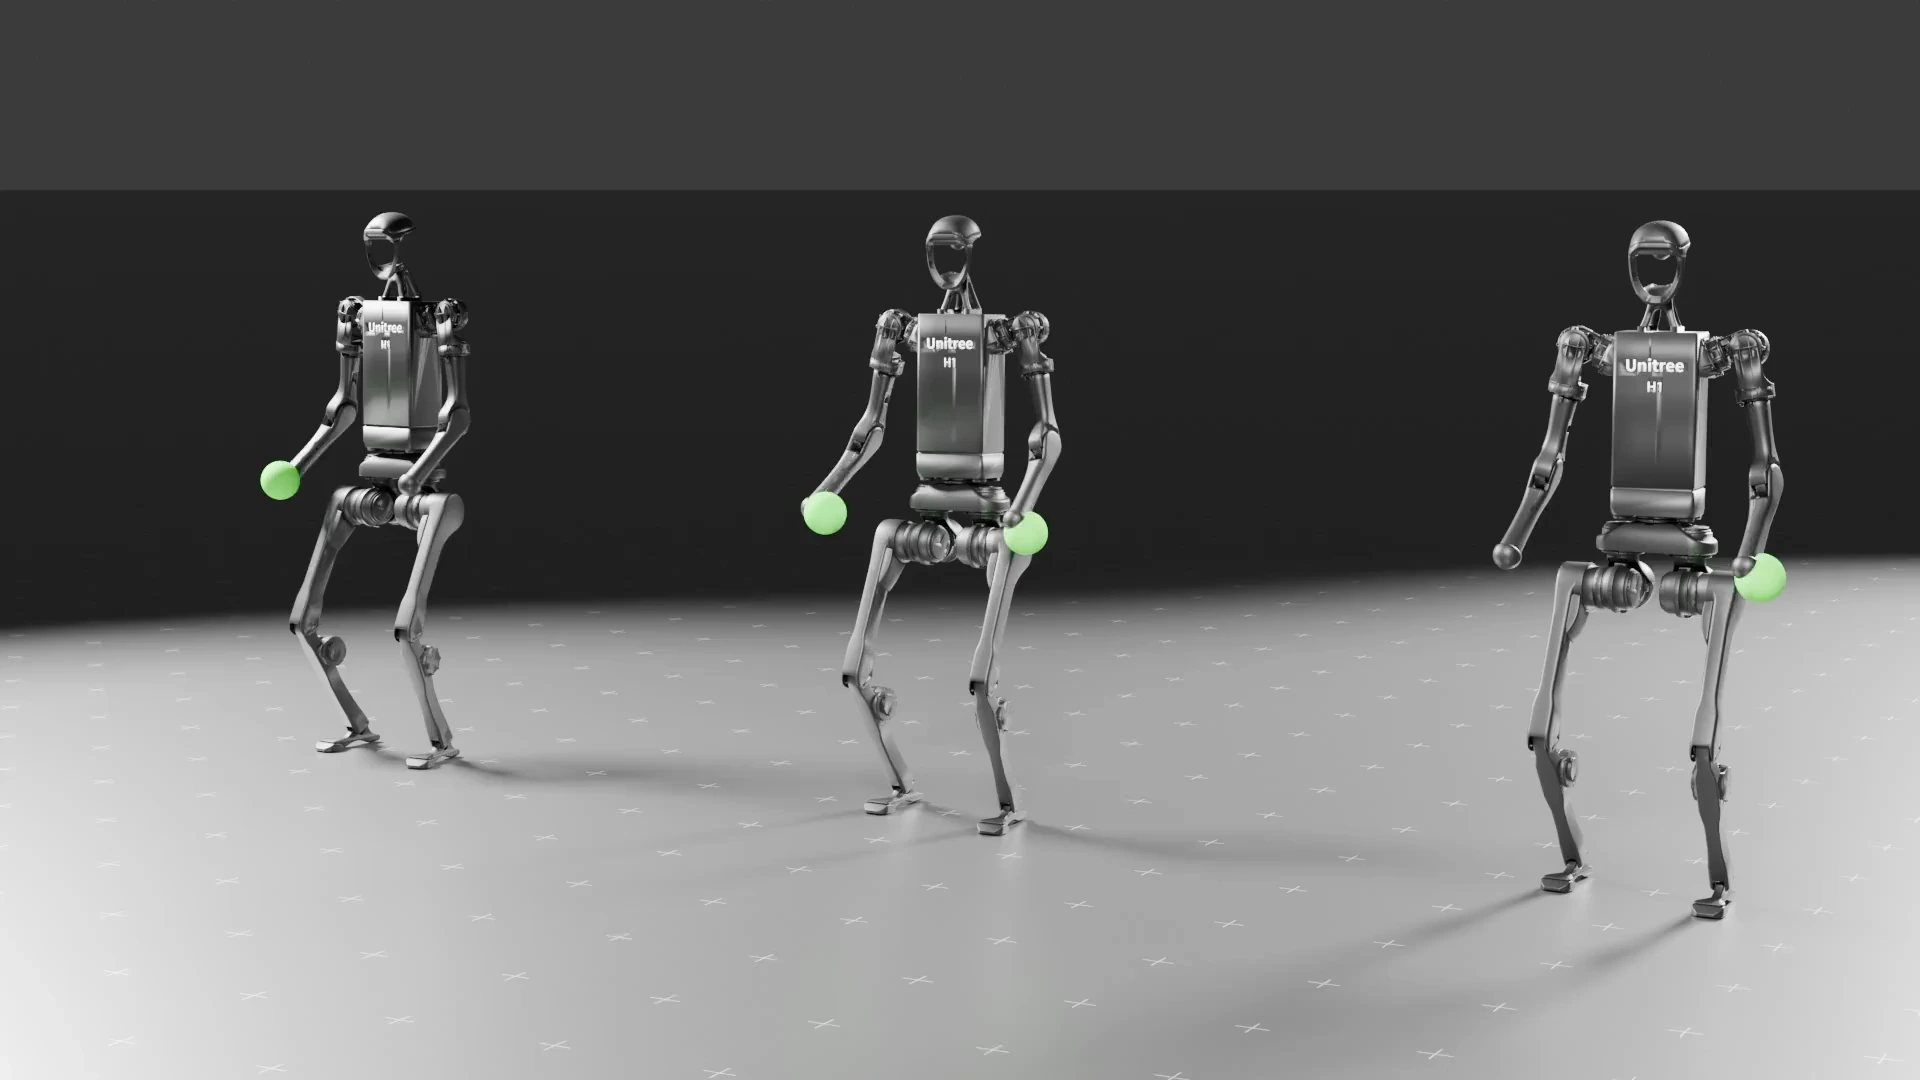
Left/right hand-position control on Unitree H1; comparisons between control inputs are on the project page. · HOVER research team · 1080p source video
01 / STUDY
Mechanism and experiments
HOVER distils several command spaces into one control policy. Official recordings show hand-position, joint-angle and root-motion control, including mode switches during execution. Experiments cover platforms including the Unitree H1 family and Fourier GR1T2. The paper and code are publicly available.
02 / CONTEXT
Test conditions and scope
The policy tracks supplied motion commands. Teleoperation and autonomous task planning are separate components; these experiments demonstrate whole-body control rather than independent selection of servicing tasks.
03 / SOURCE