← Latest updates
Preprint · hardware closed-loop control
Embedded sensing closes the loop inside enclosed spaces
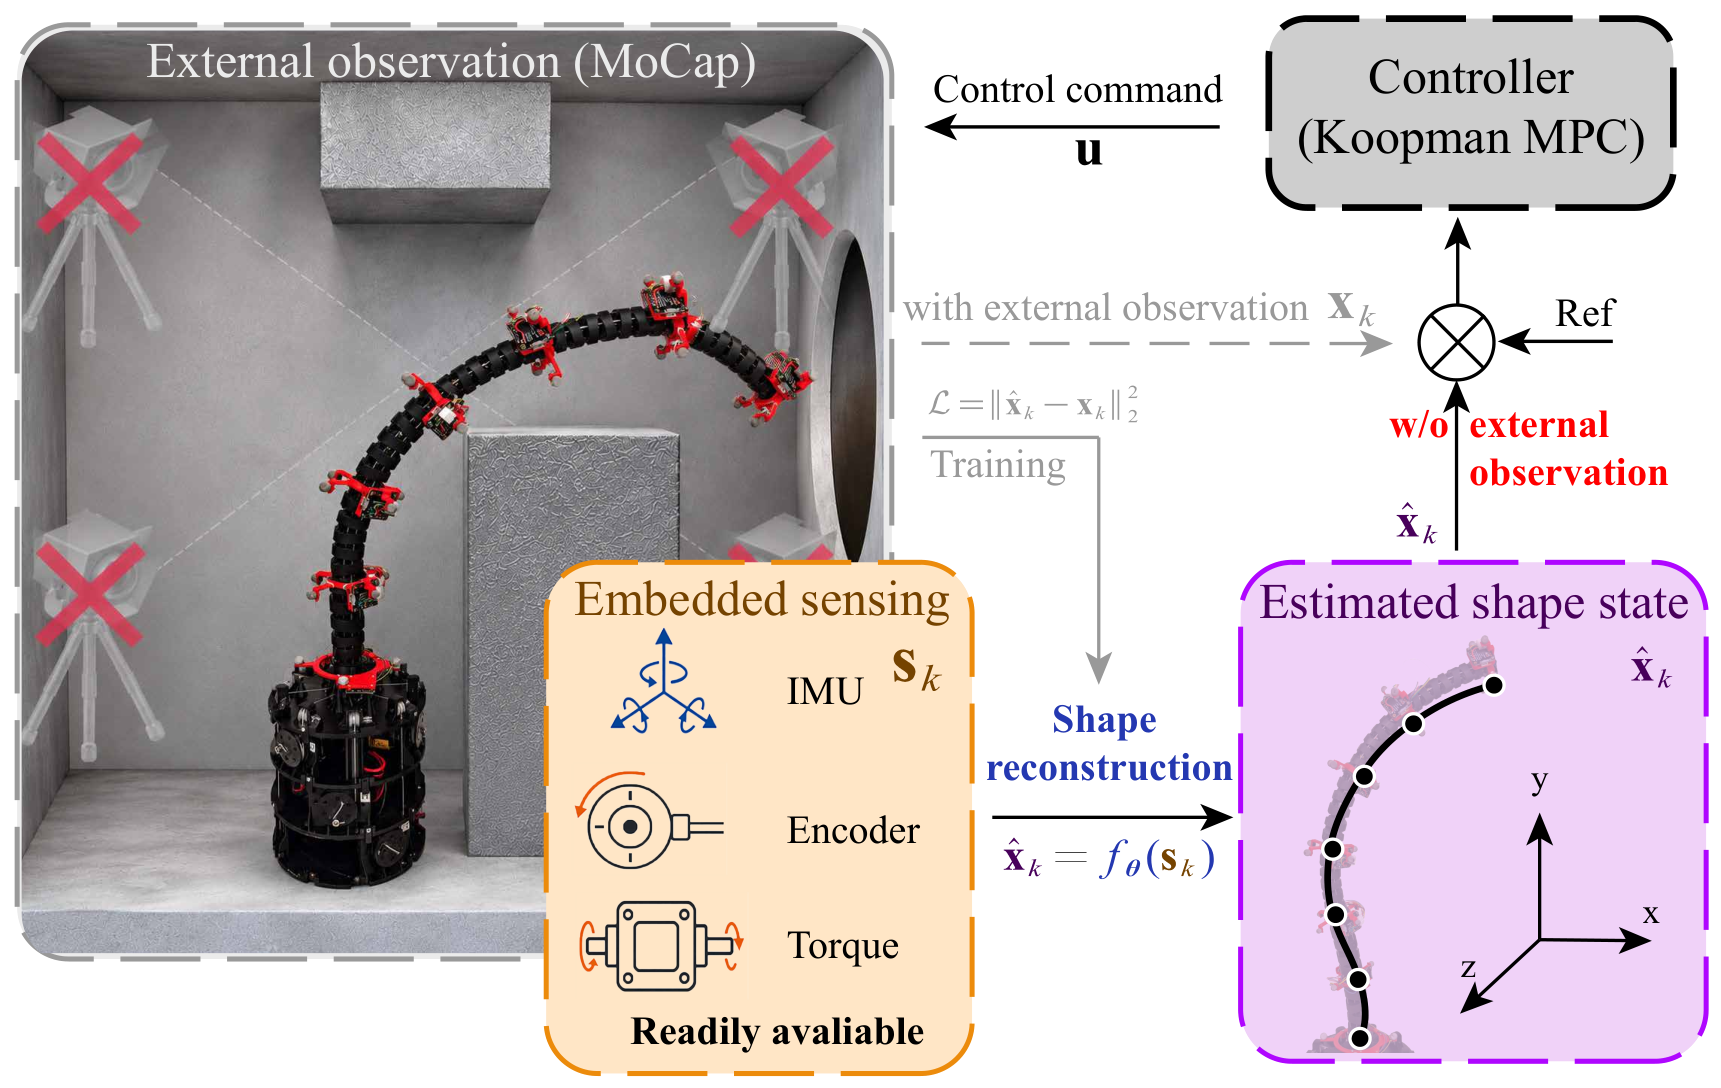
IMU and actuator measurements feed a neural shape estimator at 400 Hz, supporting closed-loop experiments without external observation during operation.
- Source published
- Sources checked
- 2026-11-09
What changed
- Global reconstruction errors are 0.9%L and 1.7%L for one- and three-segment robots, where L is robot length.
- Three-segment closed-loop shape error is 2.3%L. Reconstruction and control errors differ; training uses motion-capture ground truth.
Relevance to constrained-space work
The contribution connects shape reconstruction to feedback control in occluded environments.
Compiled by OpenRuwei editorial