 1080p
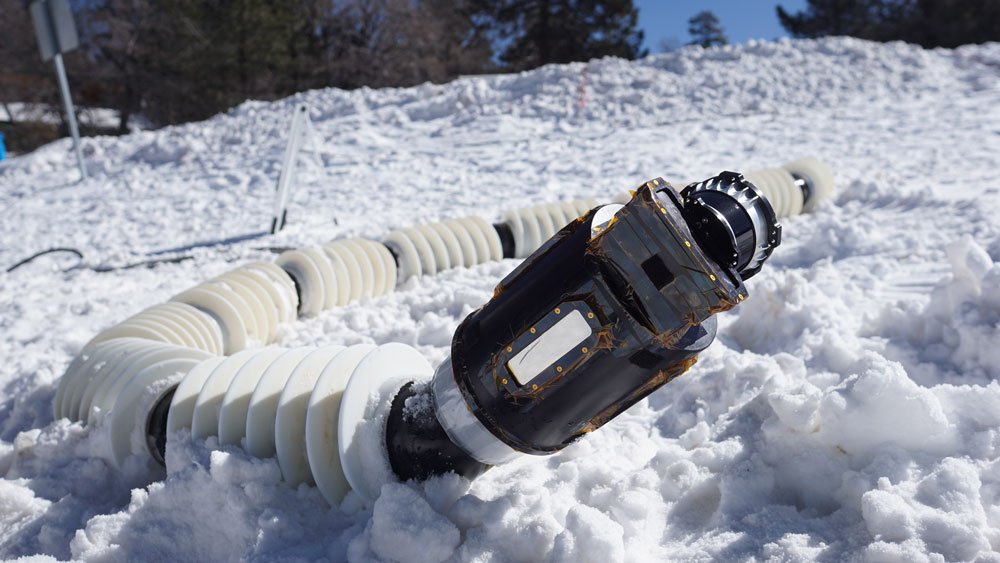
EELS: a snake robot for passages through ice
A segmented robot combines rotating screw propulsion with environmental mapping in ground tests on ice, snow, sand and glacier passages.
Ground prototypes and glacier testsRead case
Observe the environment and estimate shape, position and contact.
NASA/JPL-Caltech1080pA segmented robot combines rotating screw propulsion with environmental mapping in ground tests on ice, snow, sand and glacier passages.
 720p
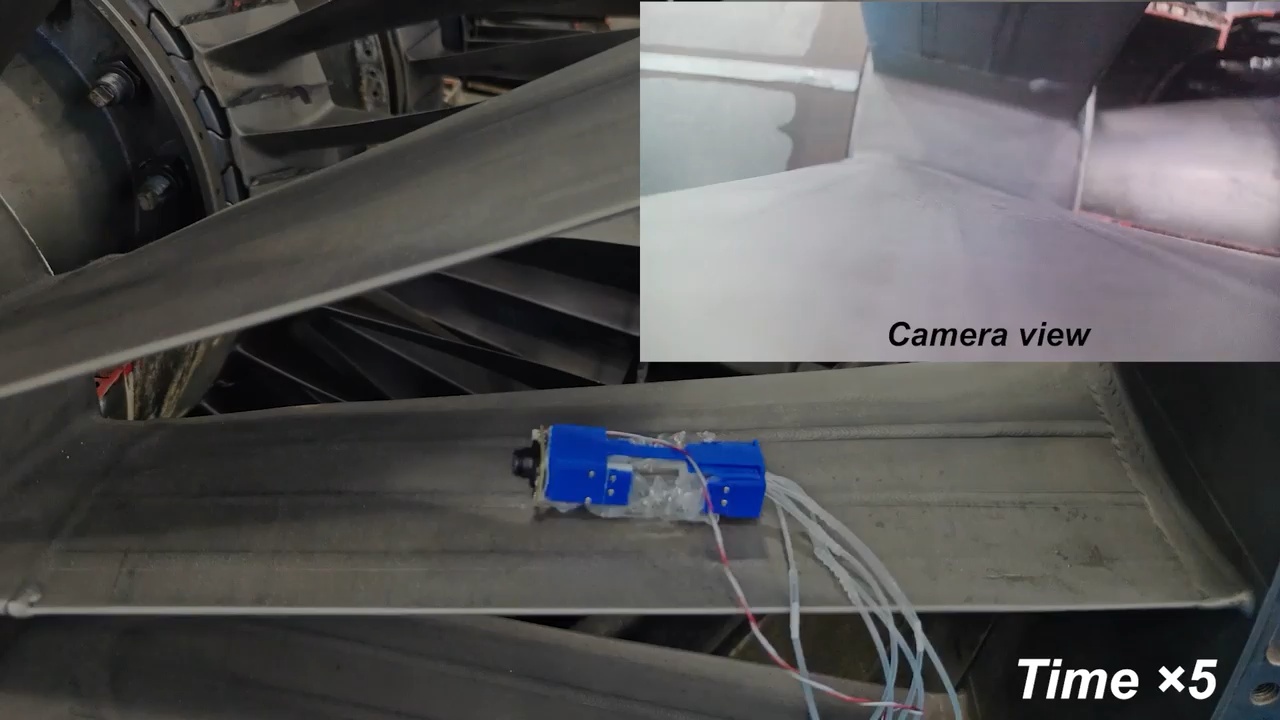
A unified active-compliance mechanism adapts to varied surfaces, with visual-inspection tests inside a decommissioned engine.
 720p
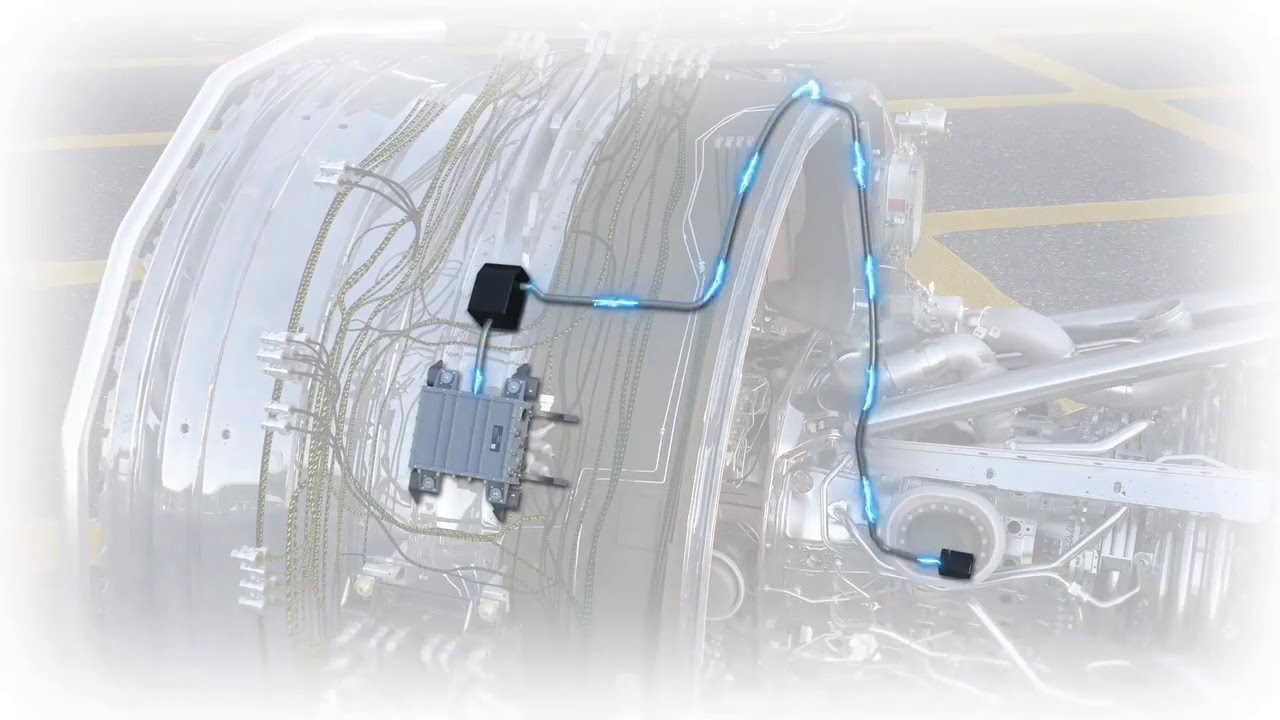
Retractable optical probes use borescope ports to observe adjacent compressor-blade edges during slow rotation.
 1080p
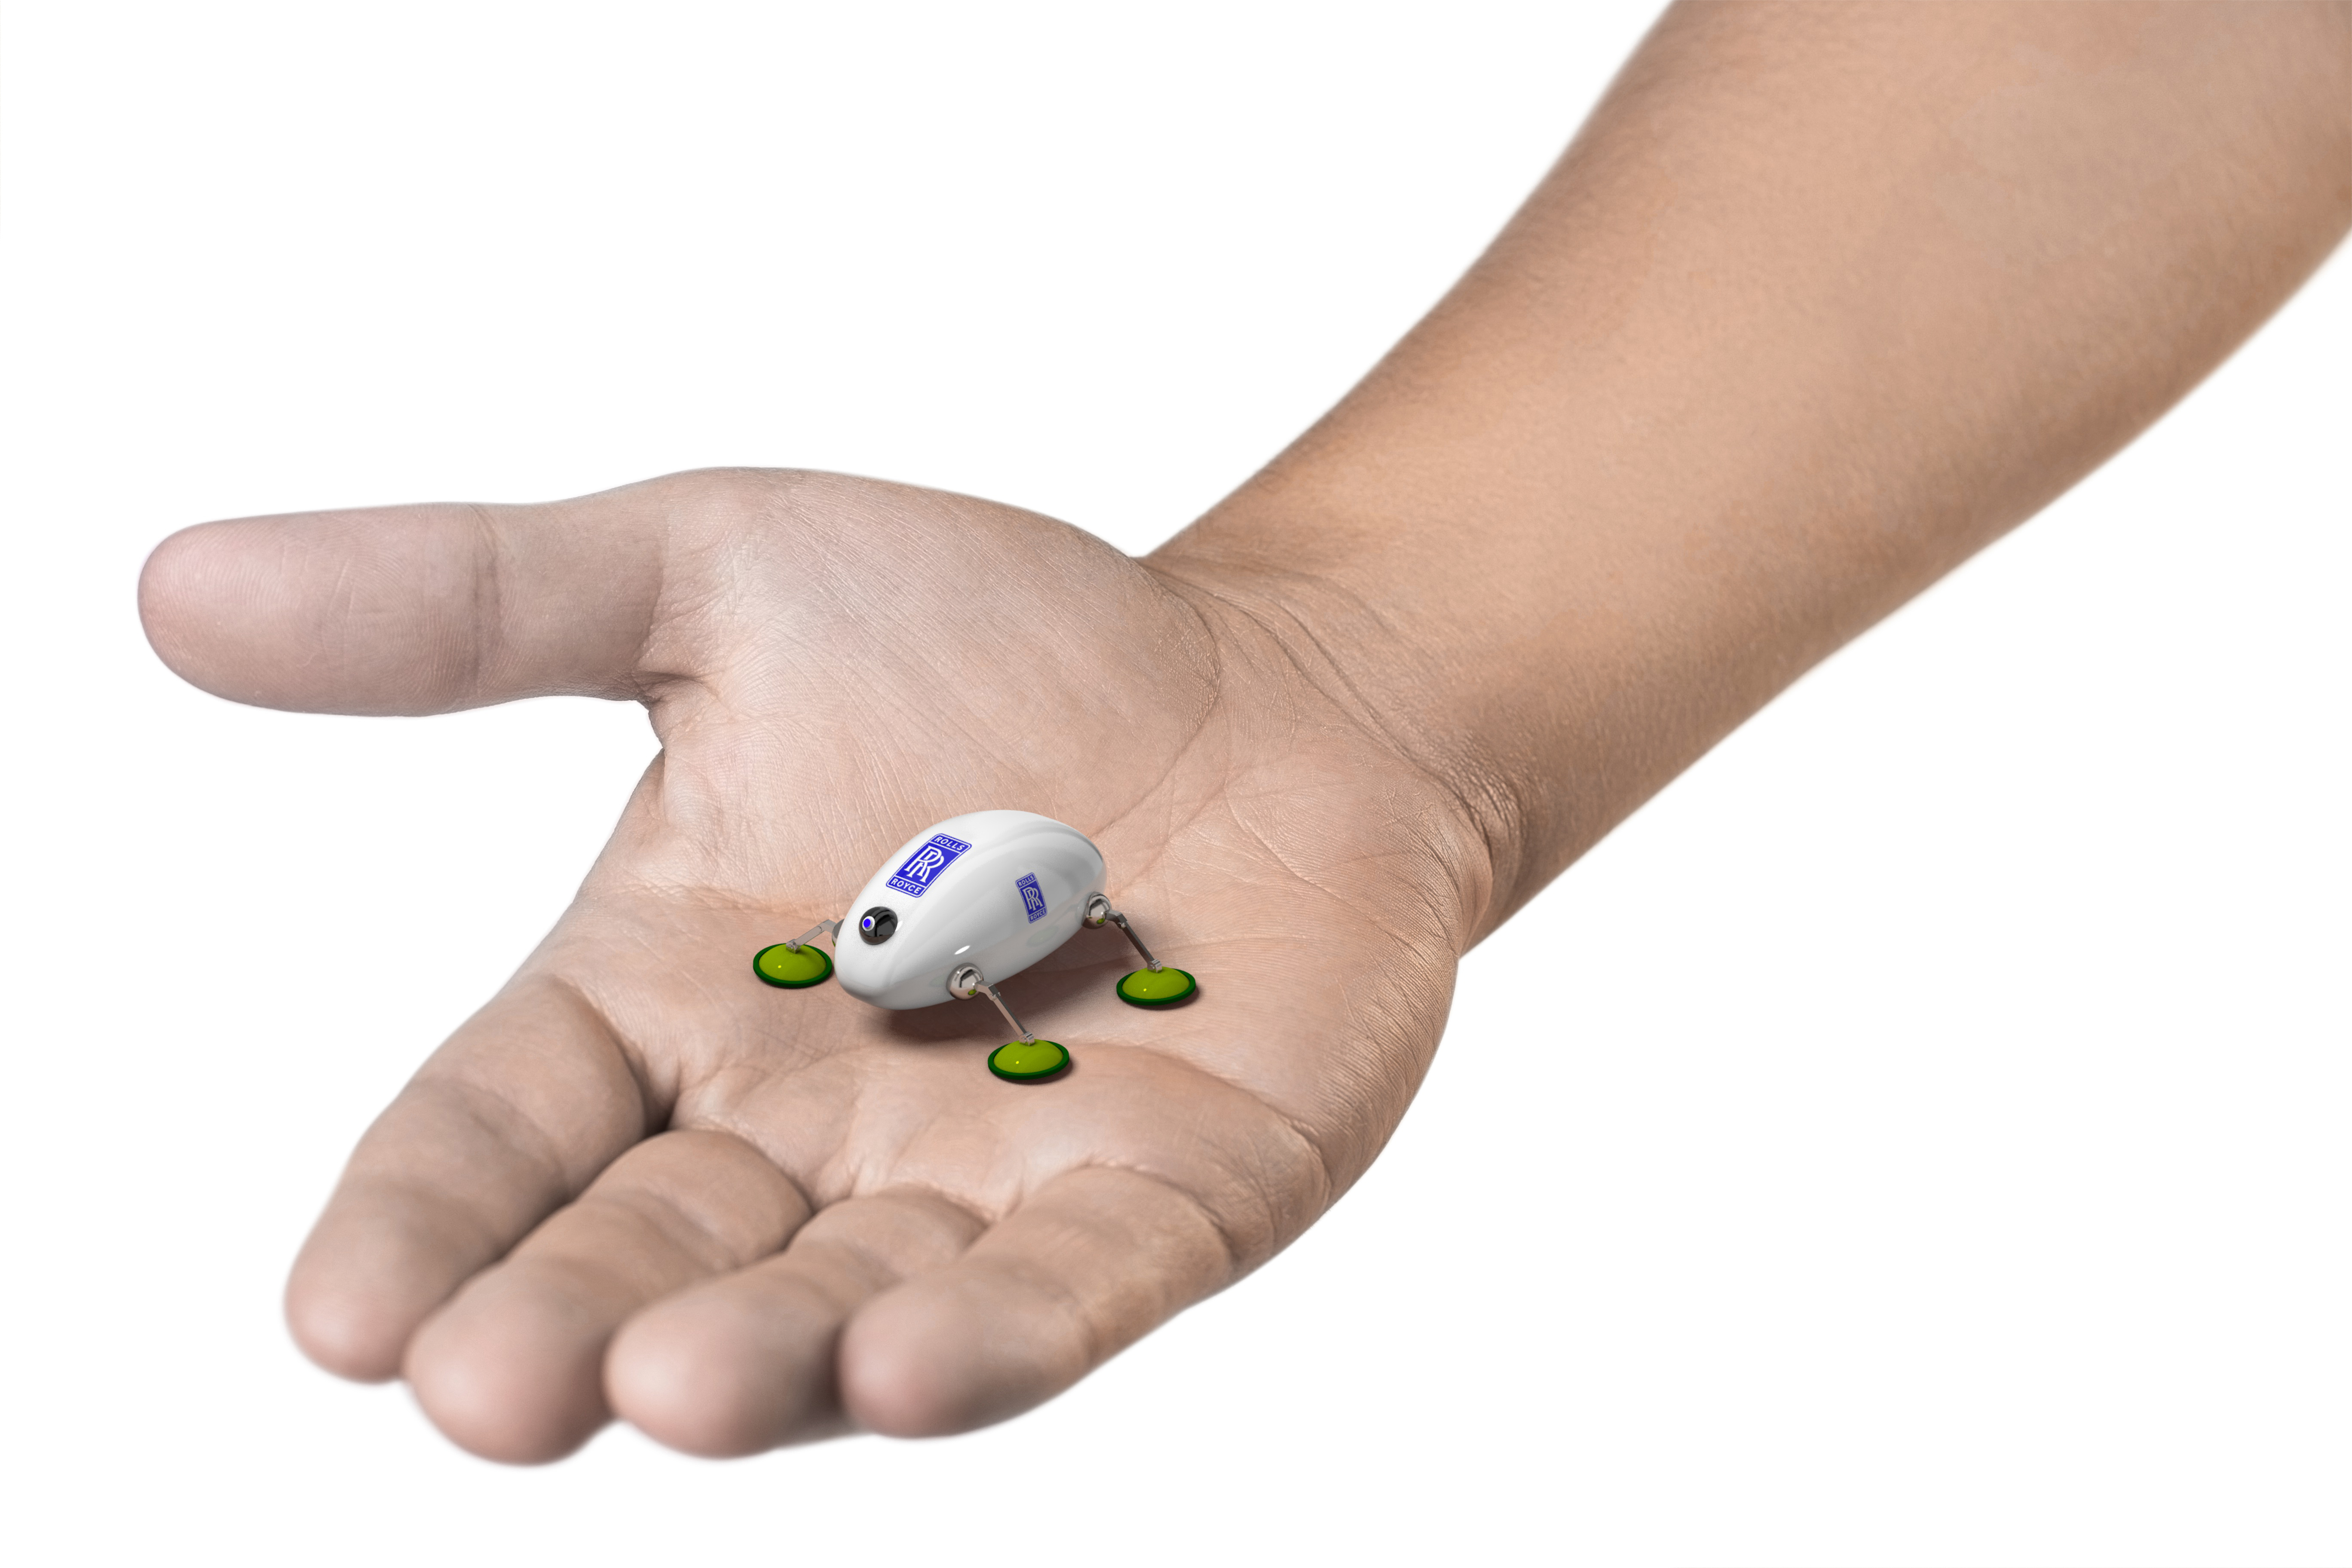
A proposed snake carrier would deploy and retrieve miniature crawlers to inspect surfaces beyond conventional borescope access.
 720p
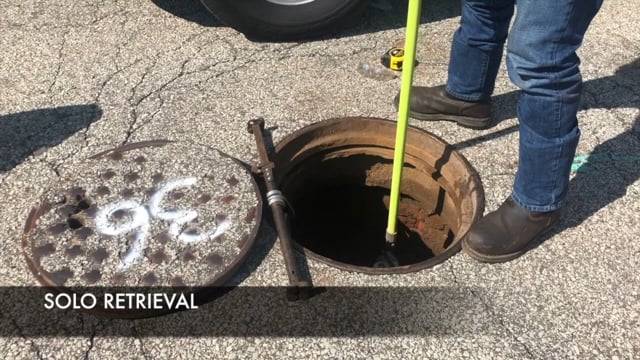
The tracked SOLO robot is deployed through a manhole to collect interior imagery for sewer assessment.
 1080p
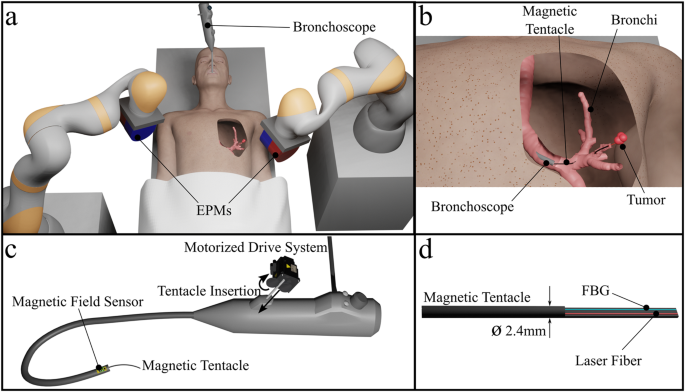
A 2.4 mm magnetic catheter integrates shape sensing and an optical fibre for peripheral-airway navigation and laser delivery.
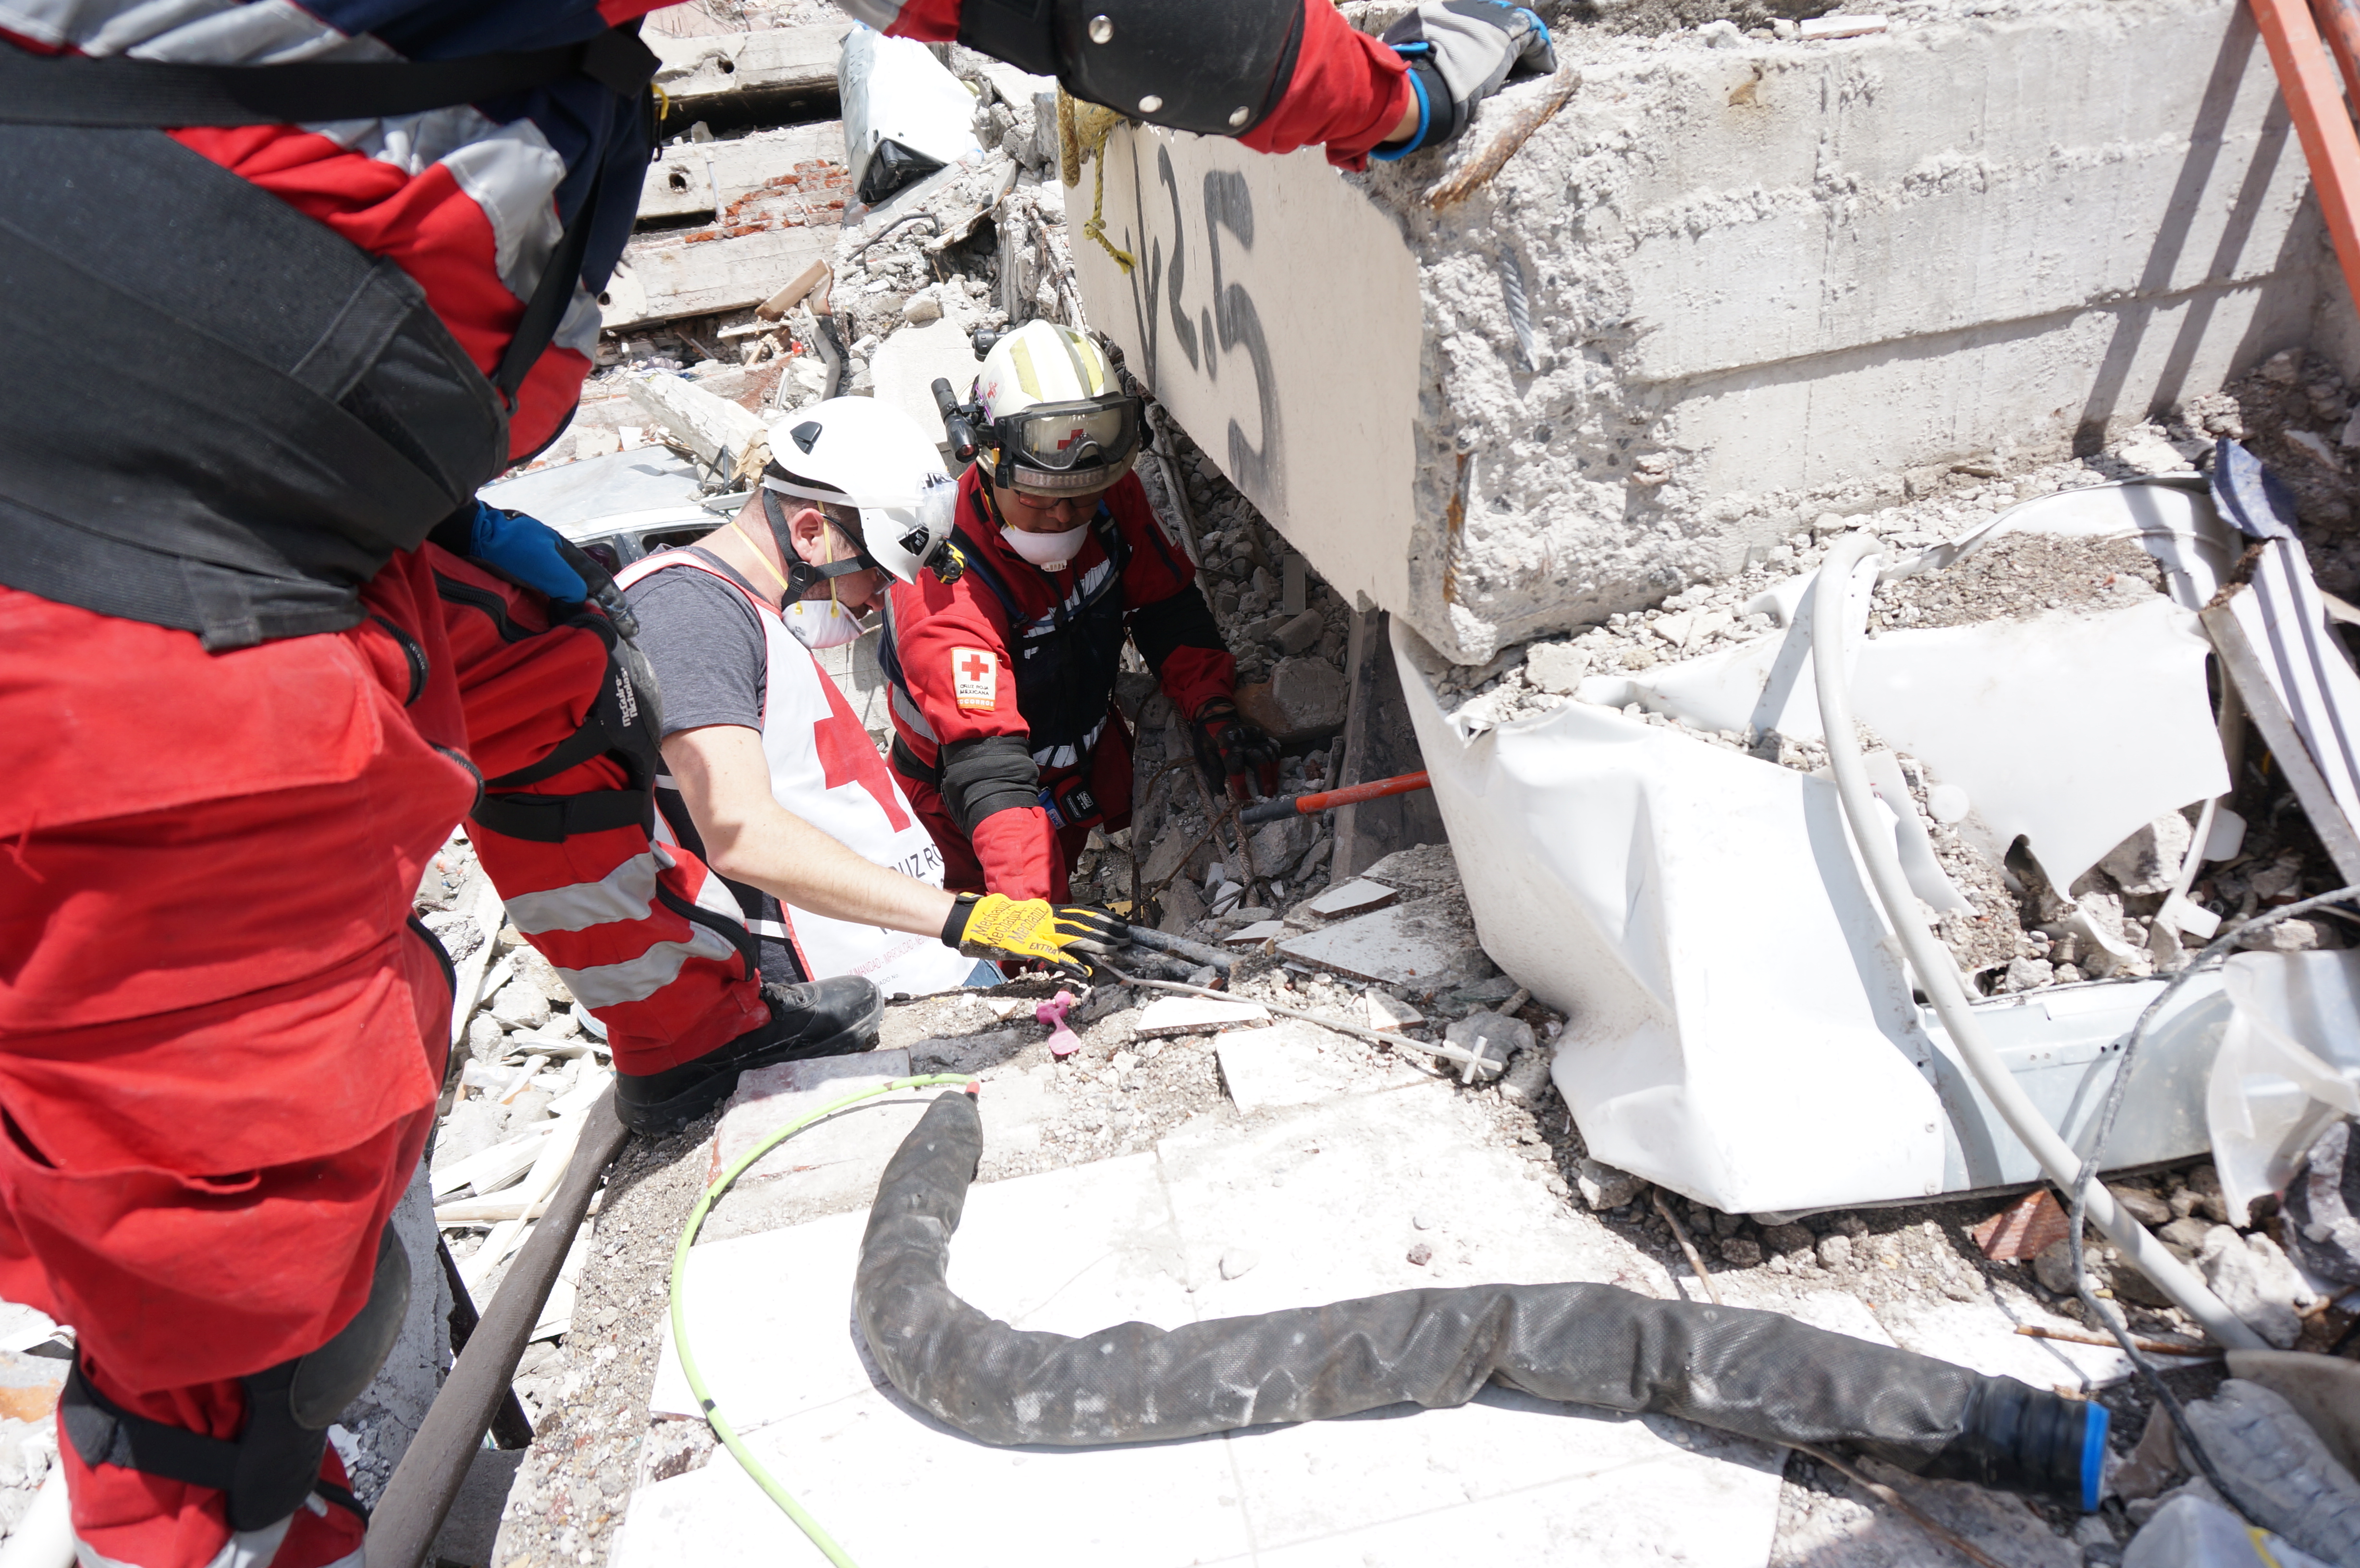
After the 2017 Mexico City earthquake, a snake robot provided camera views inside gaps inaccessible to conventional cameras.
A protective cage, visual imaging and lidar support aerial inspection and spatial mapping inside enclosed facilities.
 480p
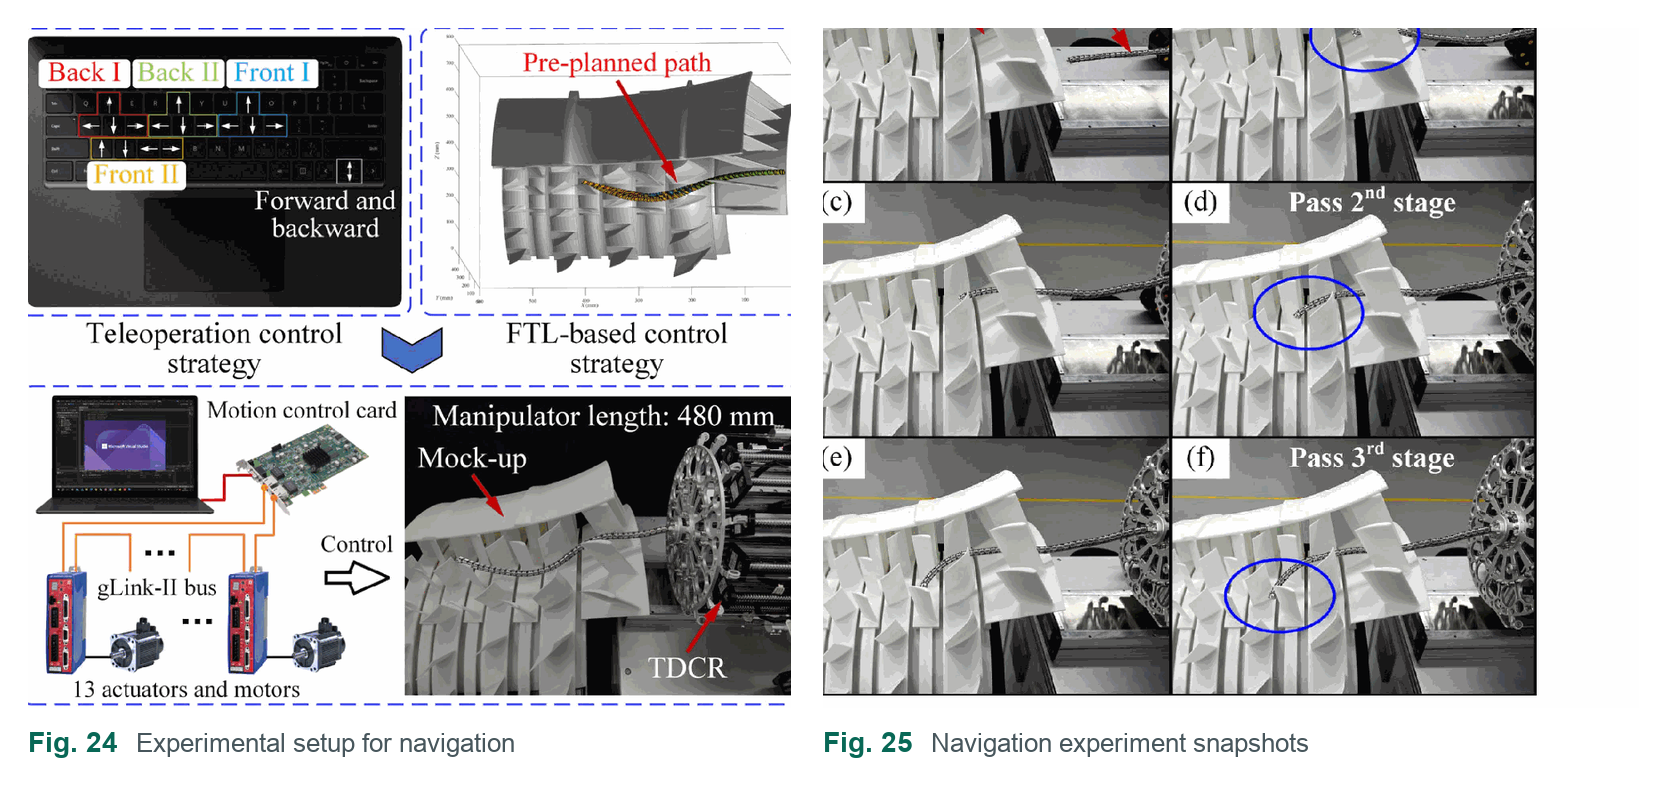
Internal contact-aided compliant mechanisms improve a slender manipulator’s resistance to twisting and compression buckling.
 540p
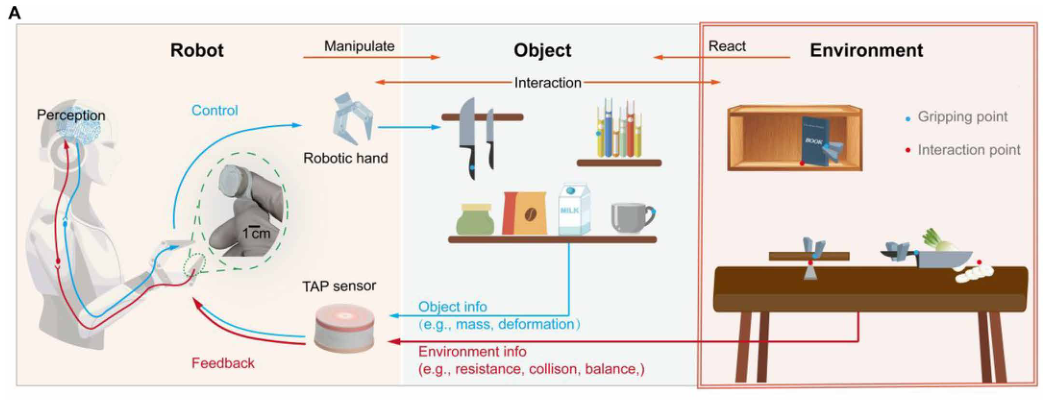
Combined tactile measurements provide contact-state feedback for placement, stacking and cutting experiments without vision.
 Video
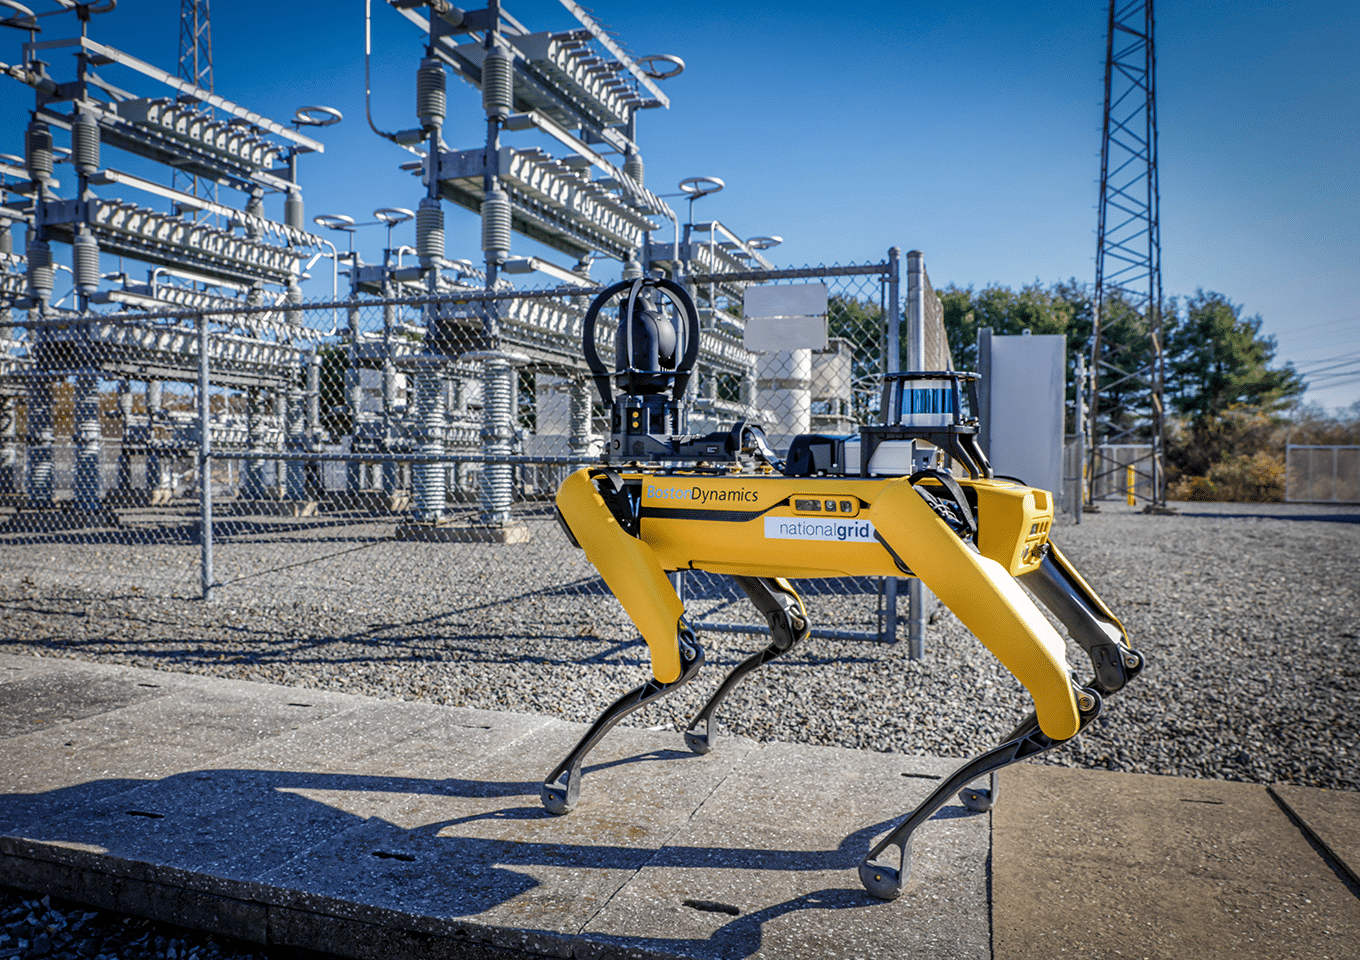
Visual and thermal inspection in an energised valve hall inaccessible to personnel.
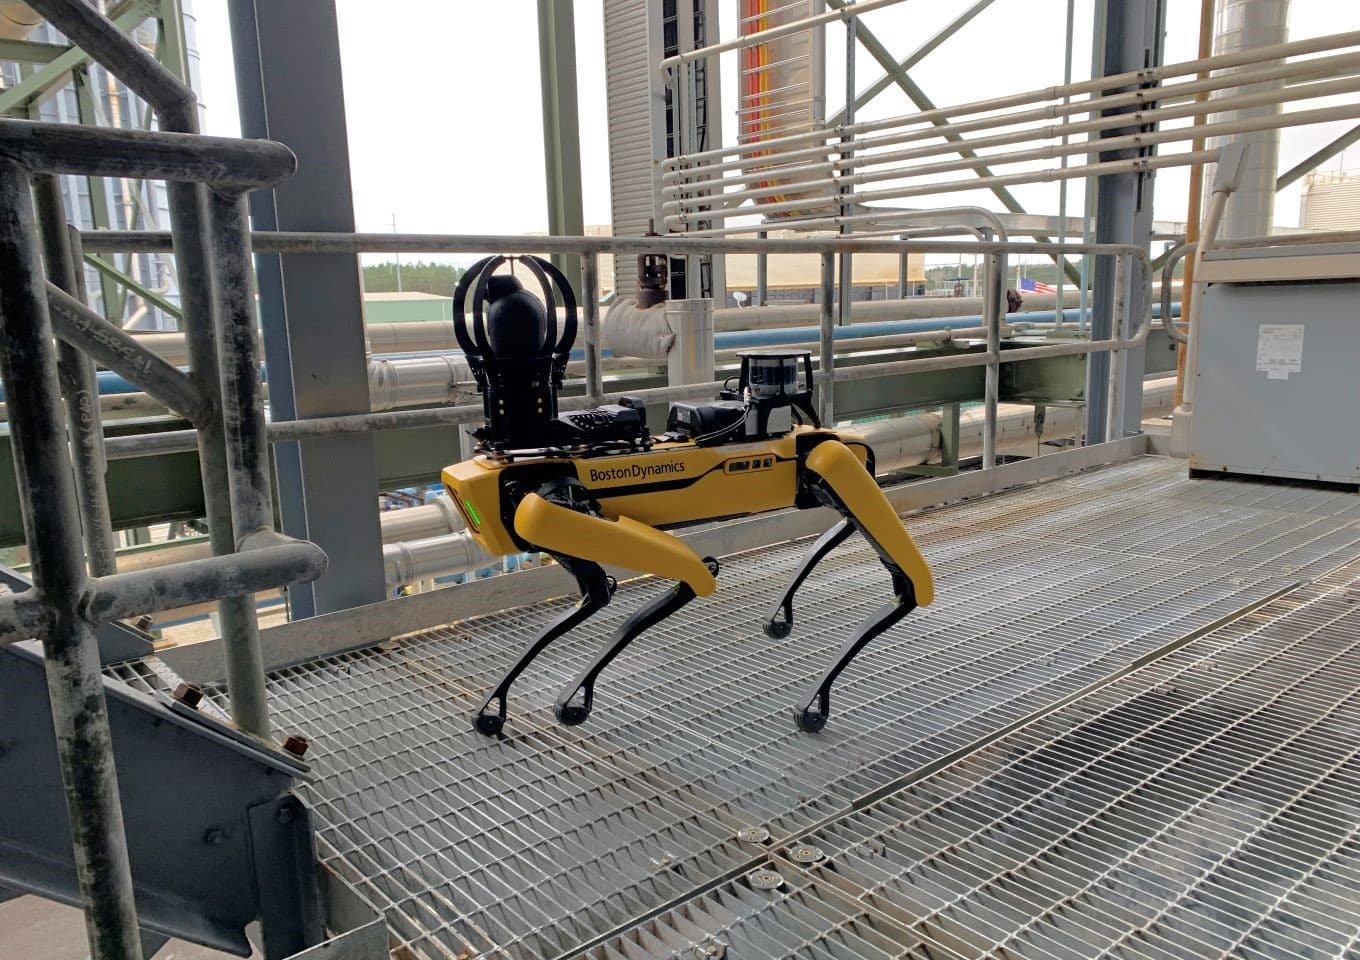
Collecting heat-recovery steam-generator thermograms and temperature-gauge images across industrial stairs and platforms.
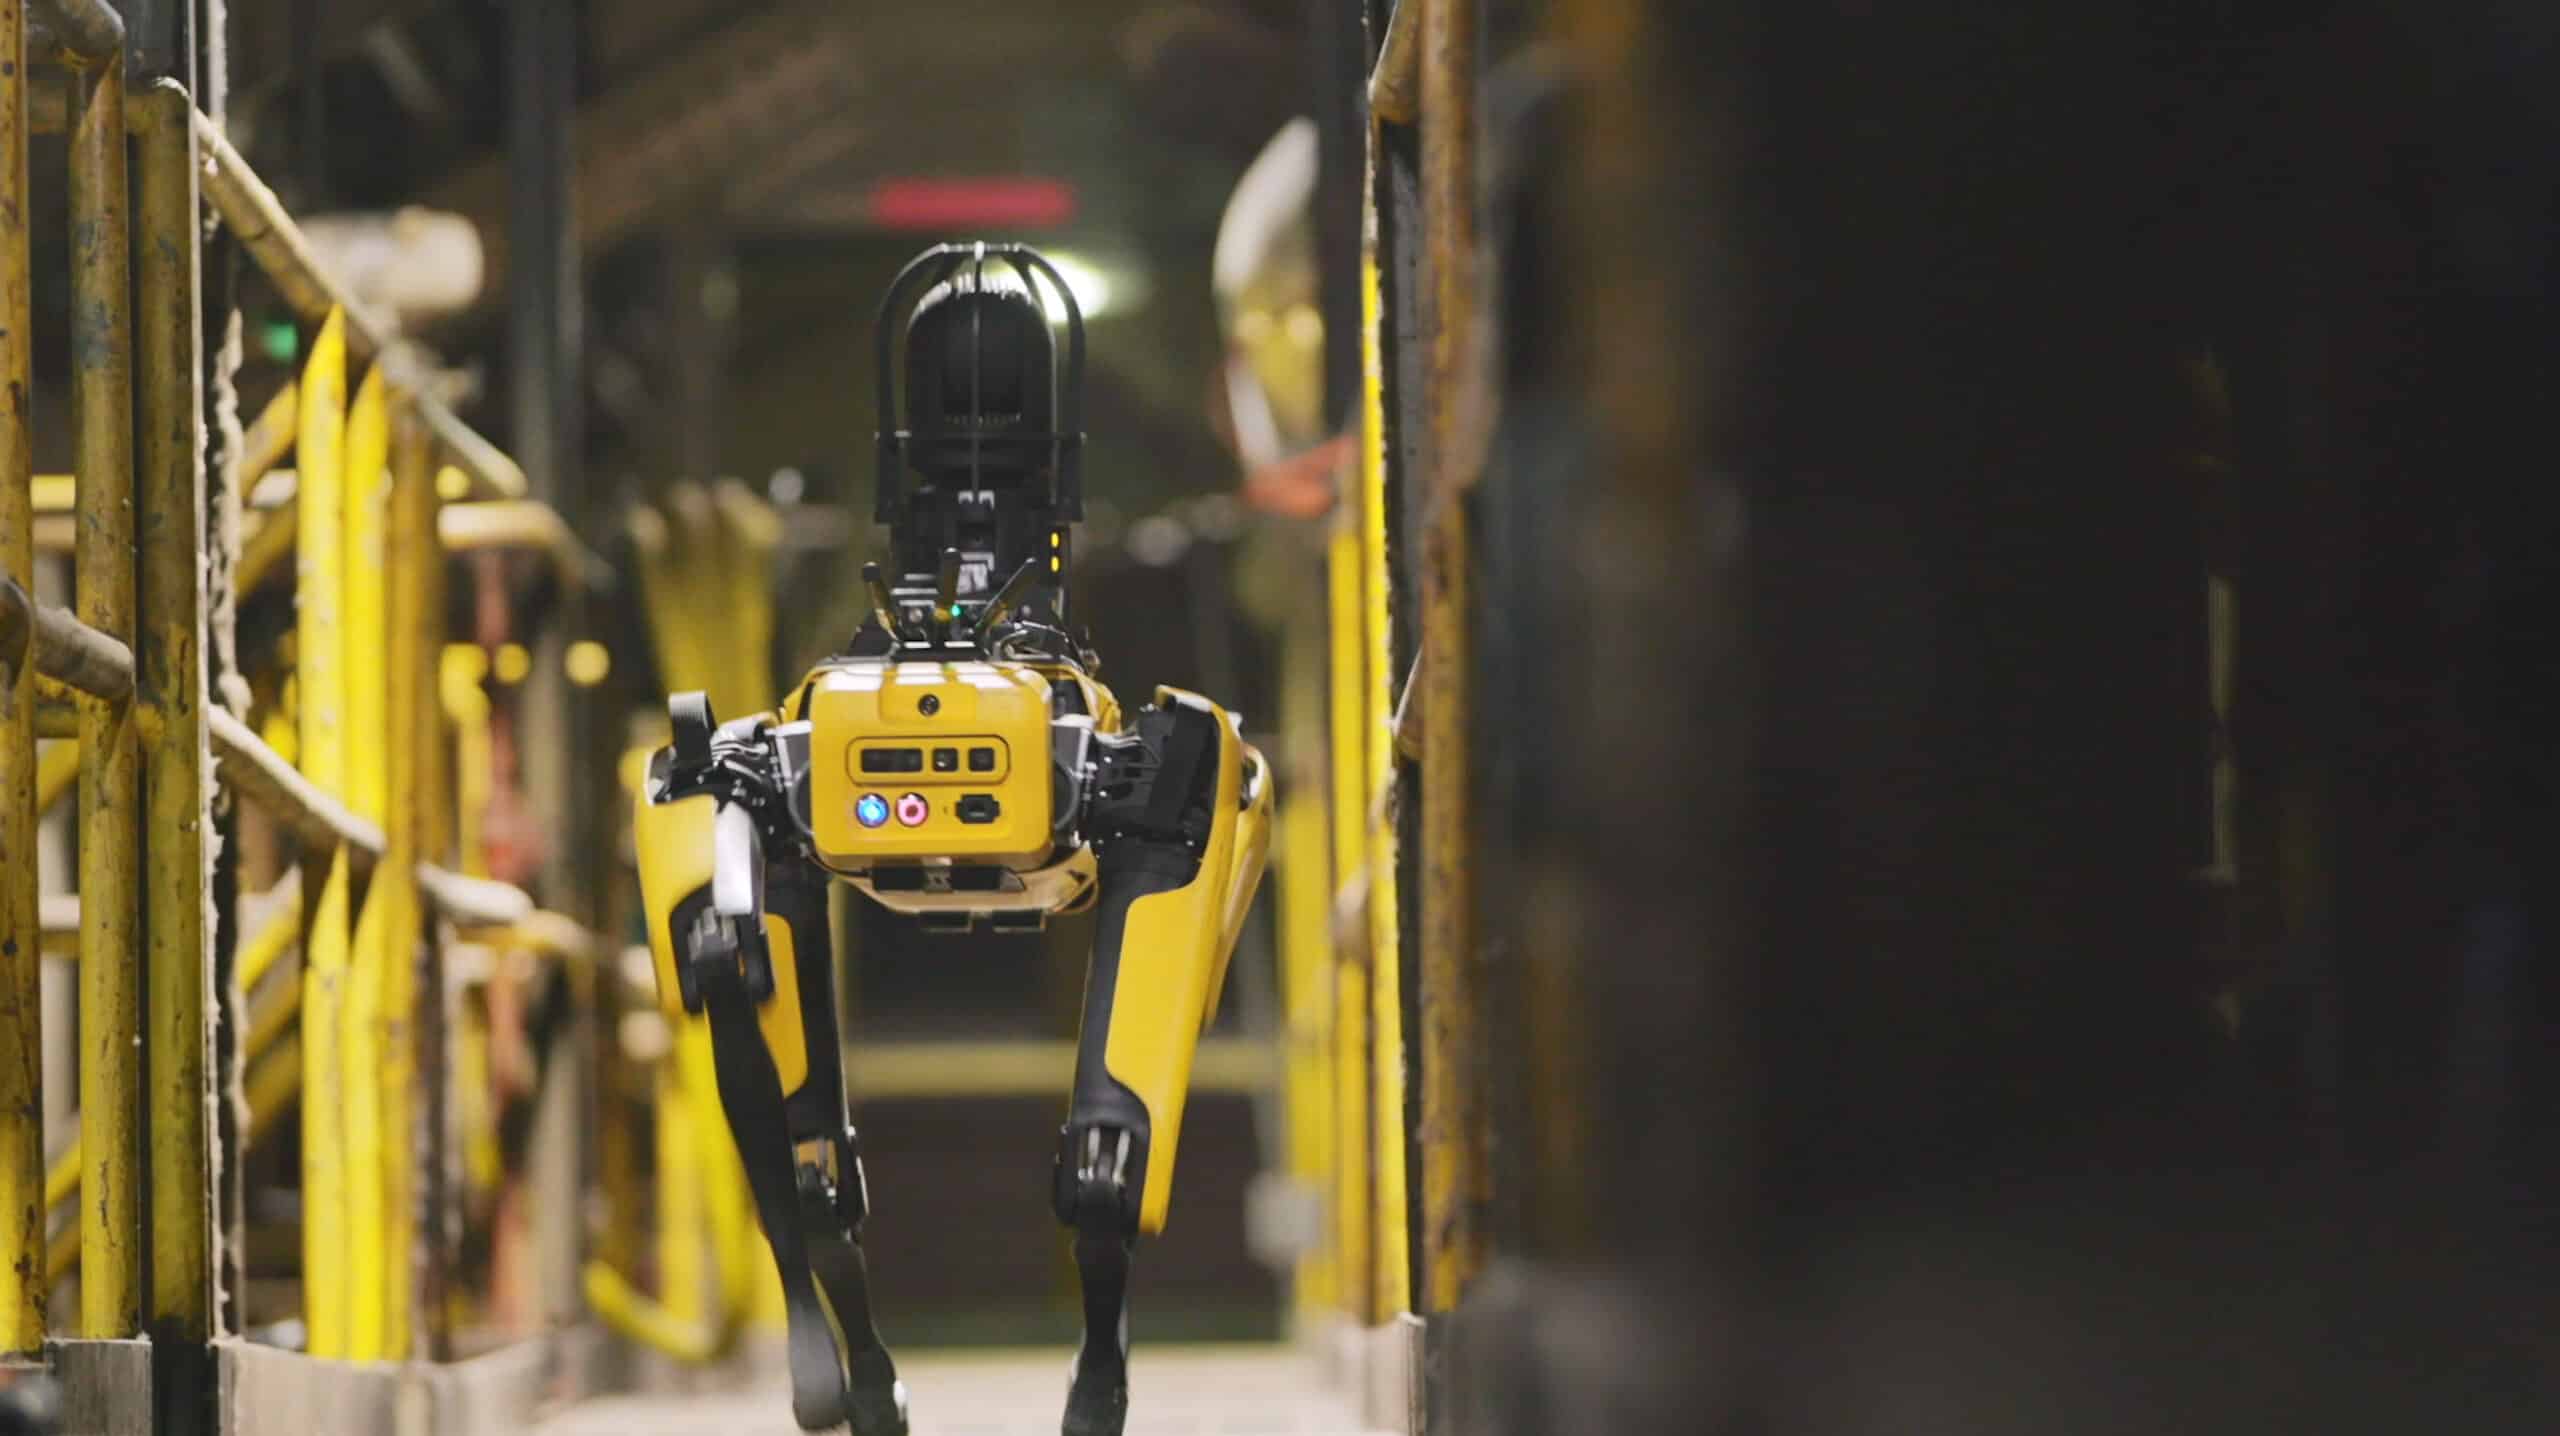
Trials at a simulated industrial site and Whiting refinery examined mobility through narrow passages, grating and stairs.
 Video
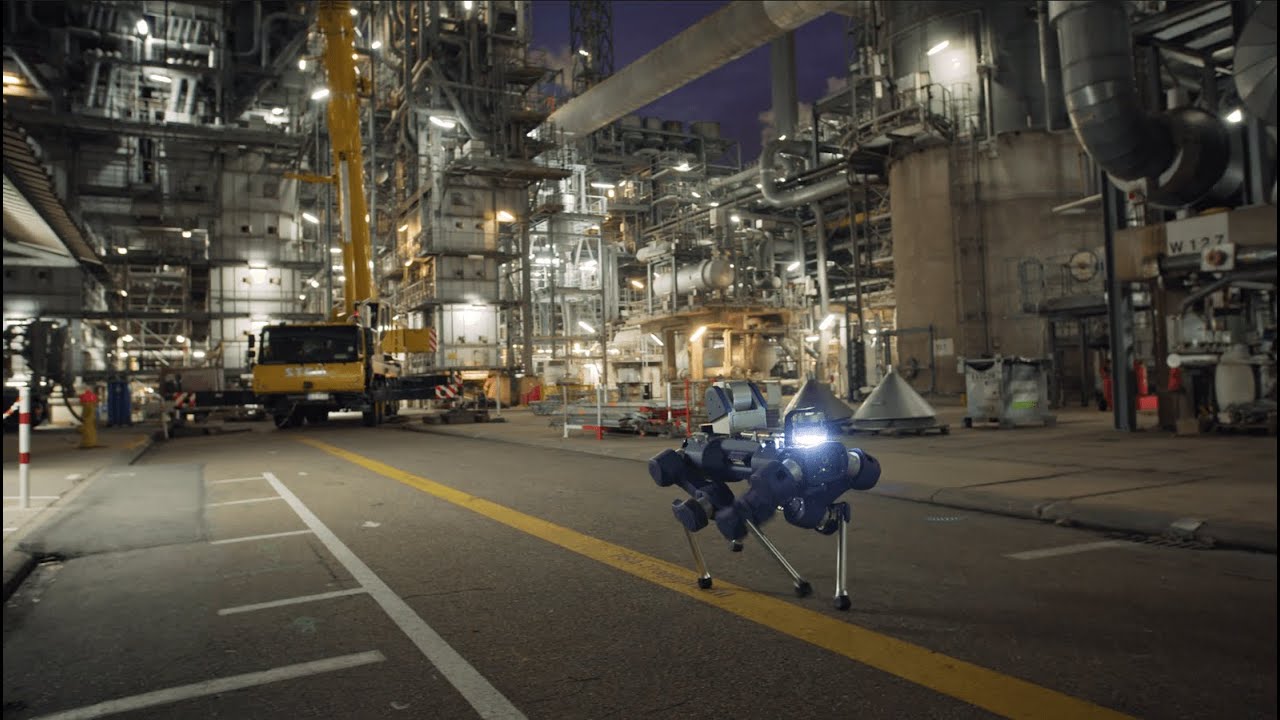
Field tests at BASF Ludwigshafen examined automated inspection of gauges, pumps and tanks.
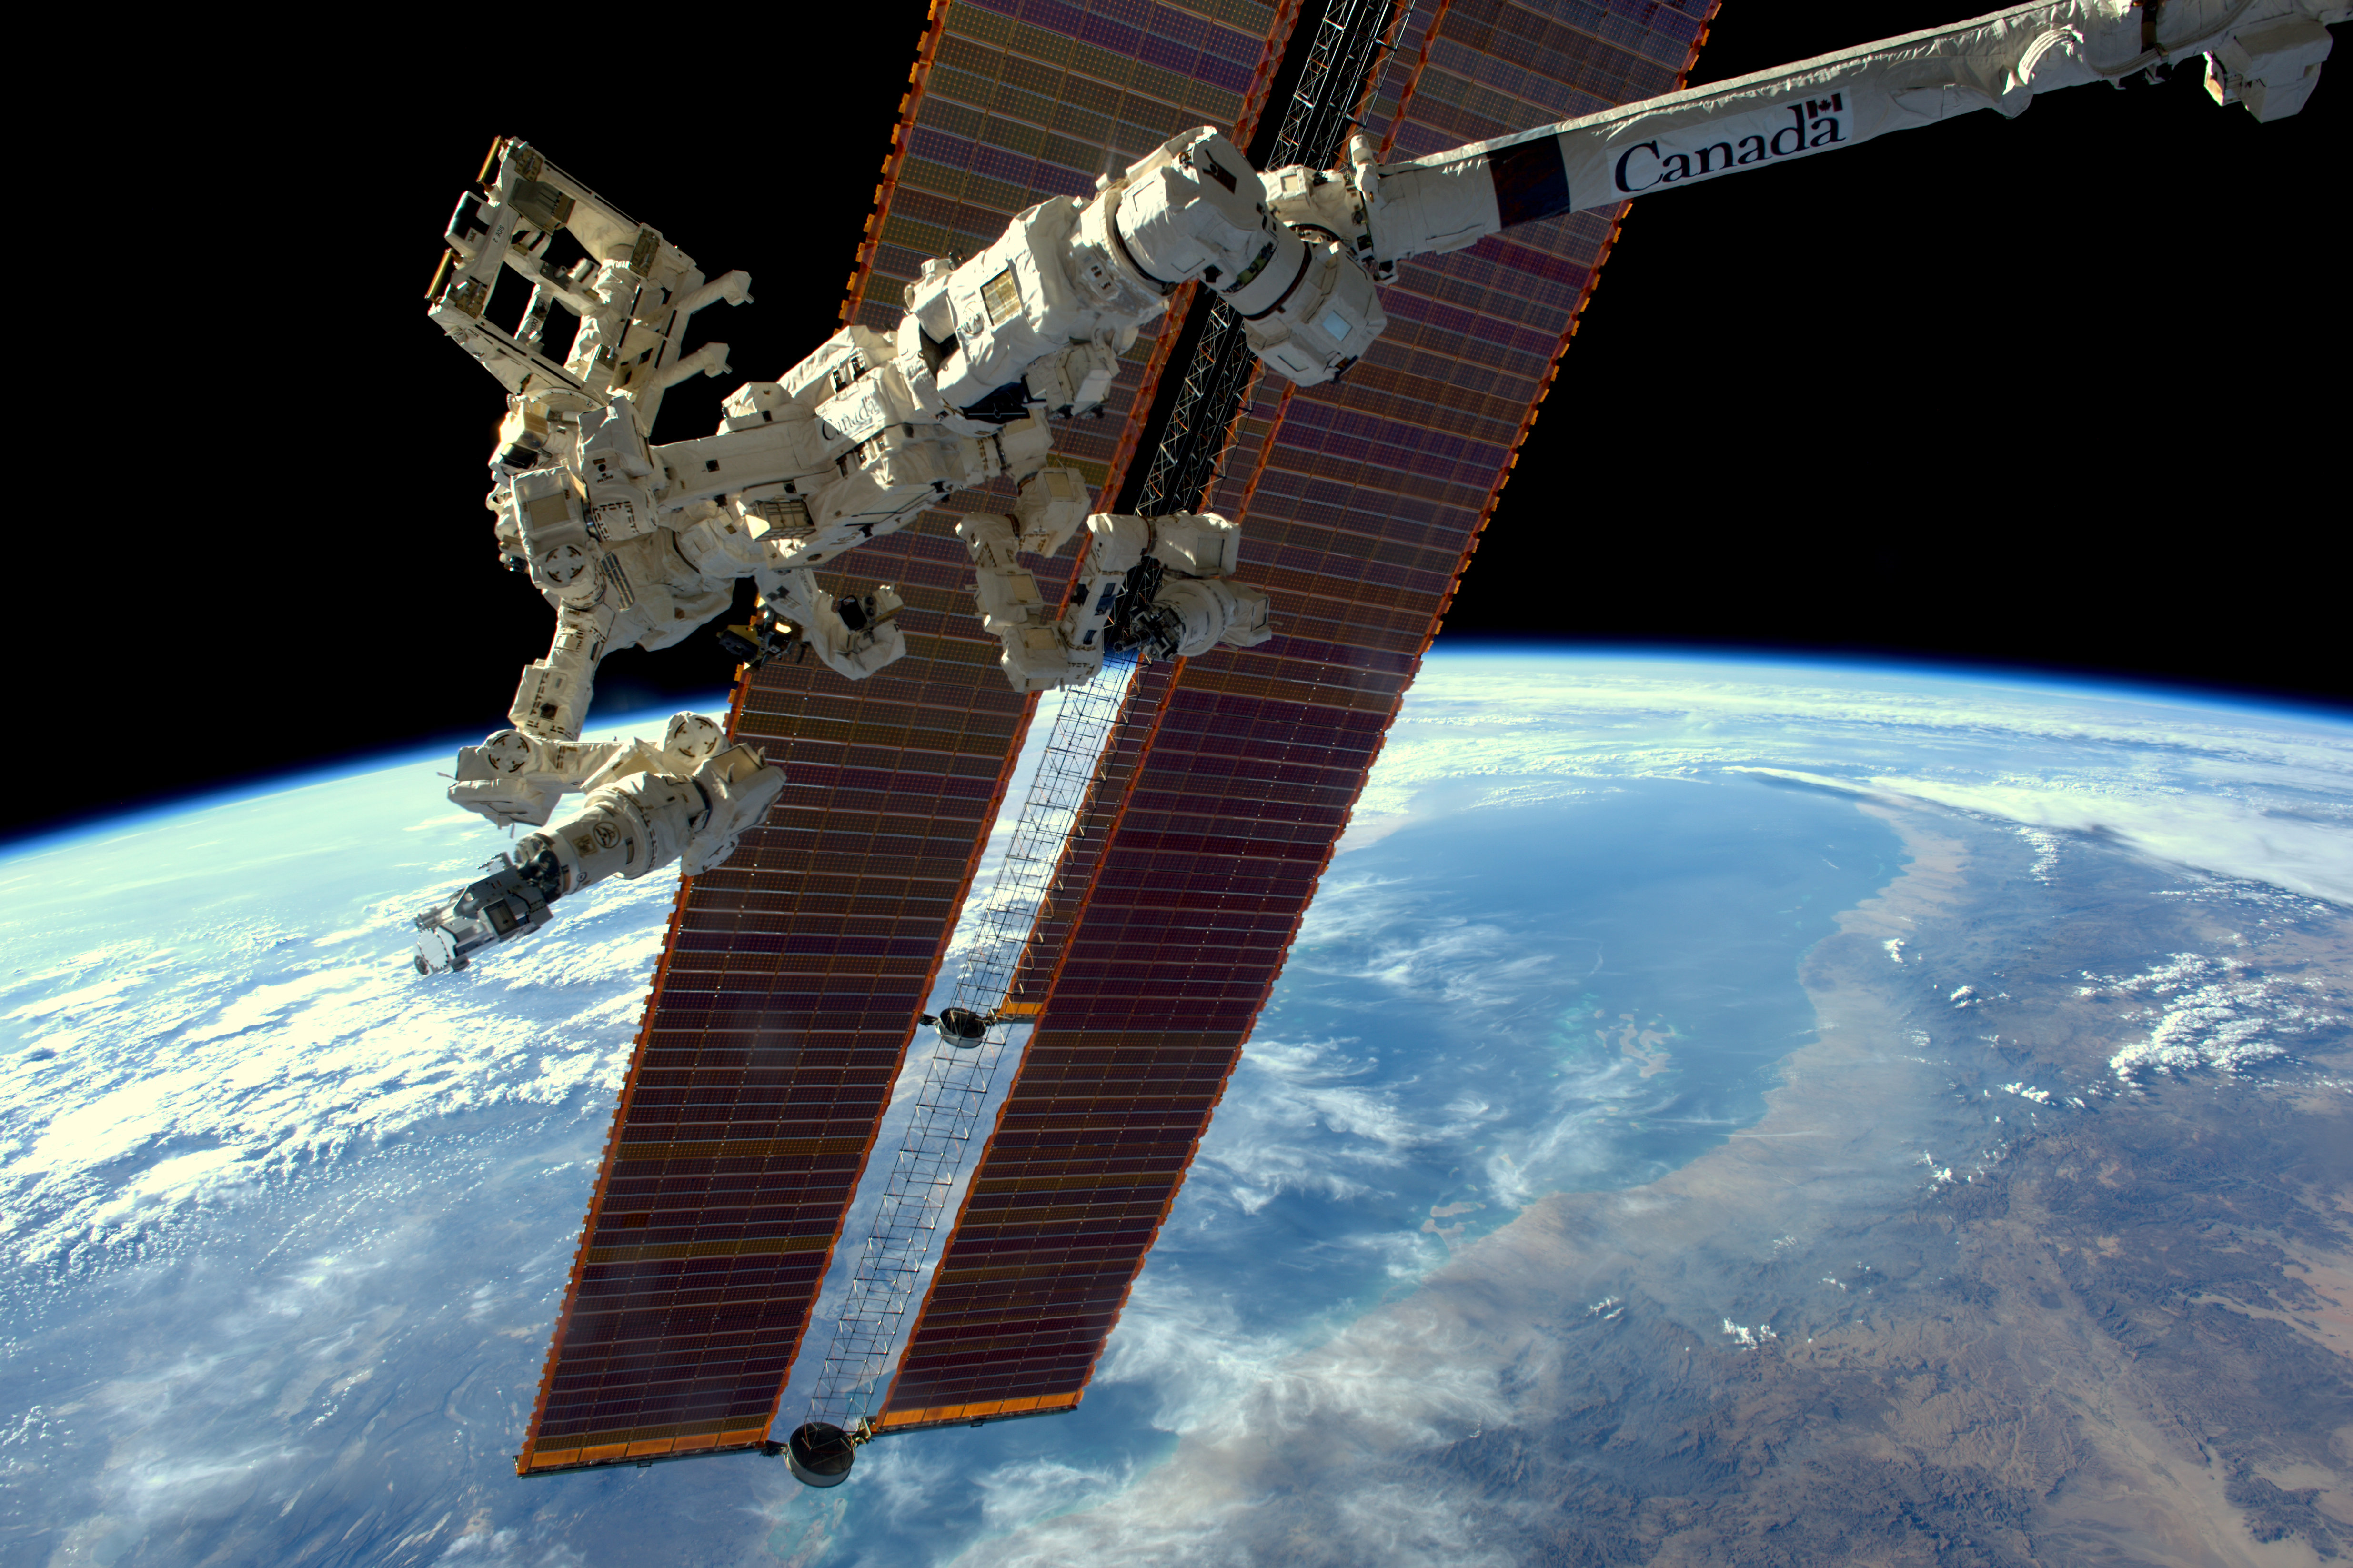
A robot-mounted gas detector surveys the station exterior for cooling-system leaks.
 Video
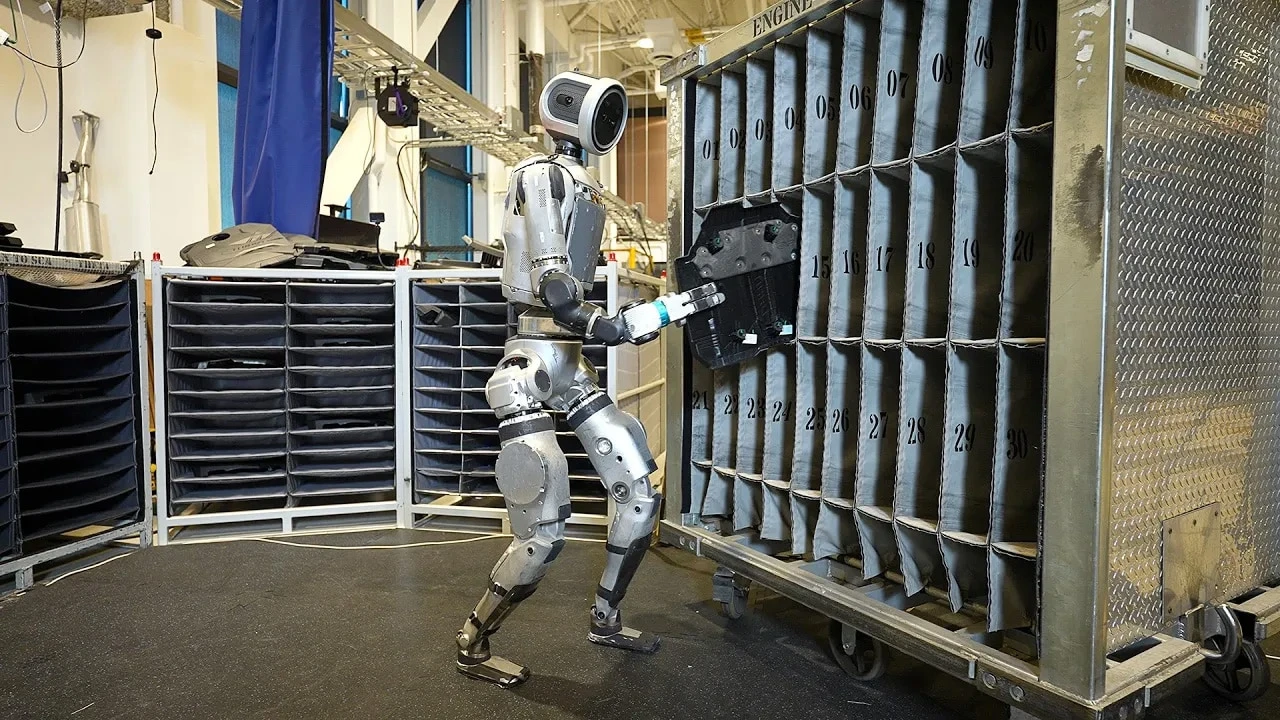
Moving parts between supplier containers and a sequencing dolly from a list of bin locations.
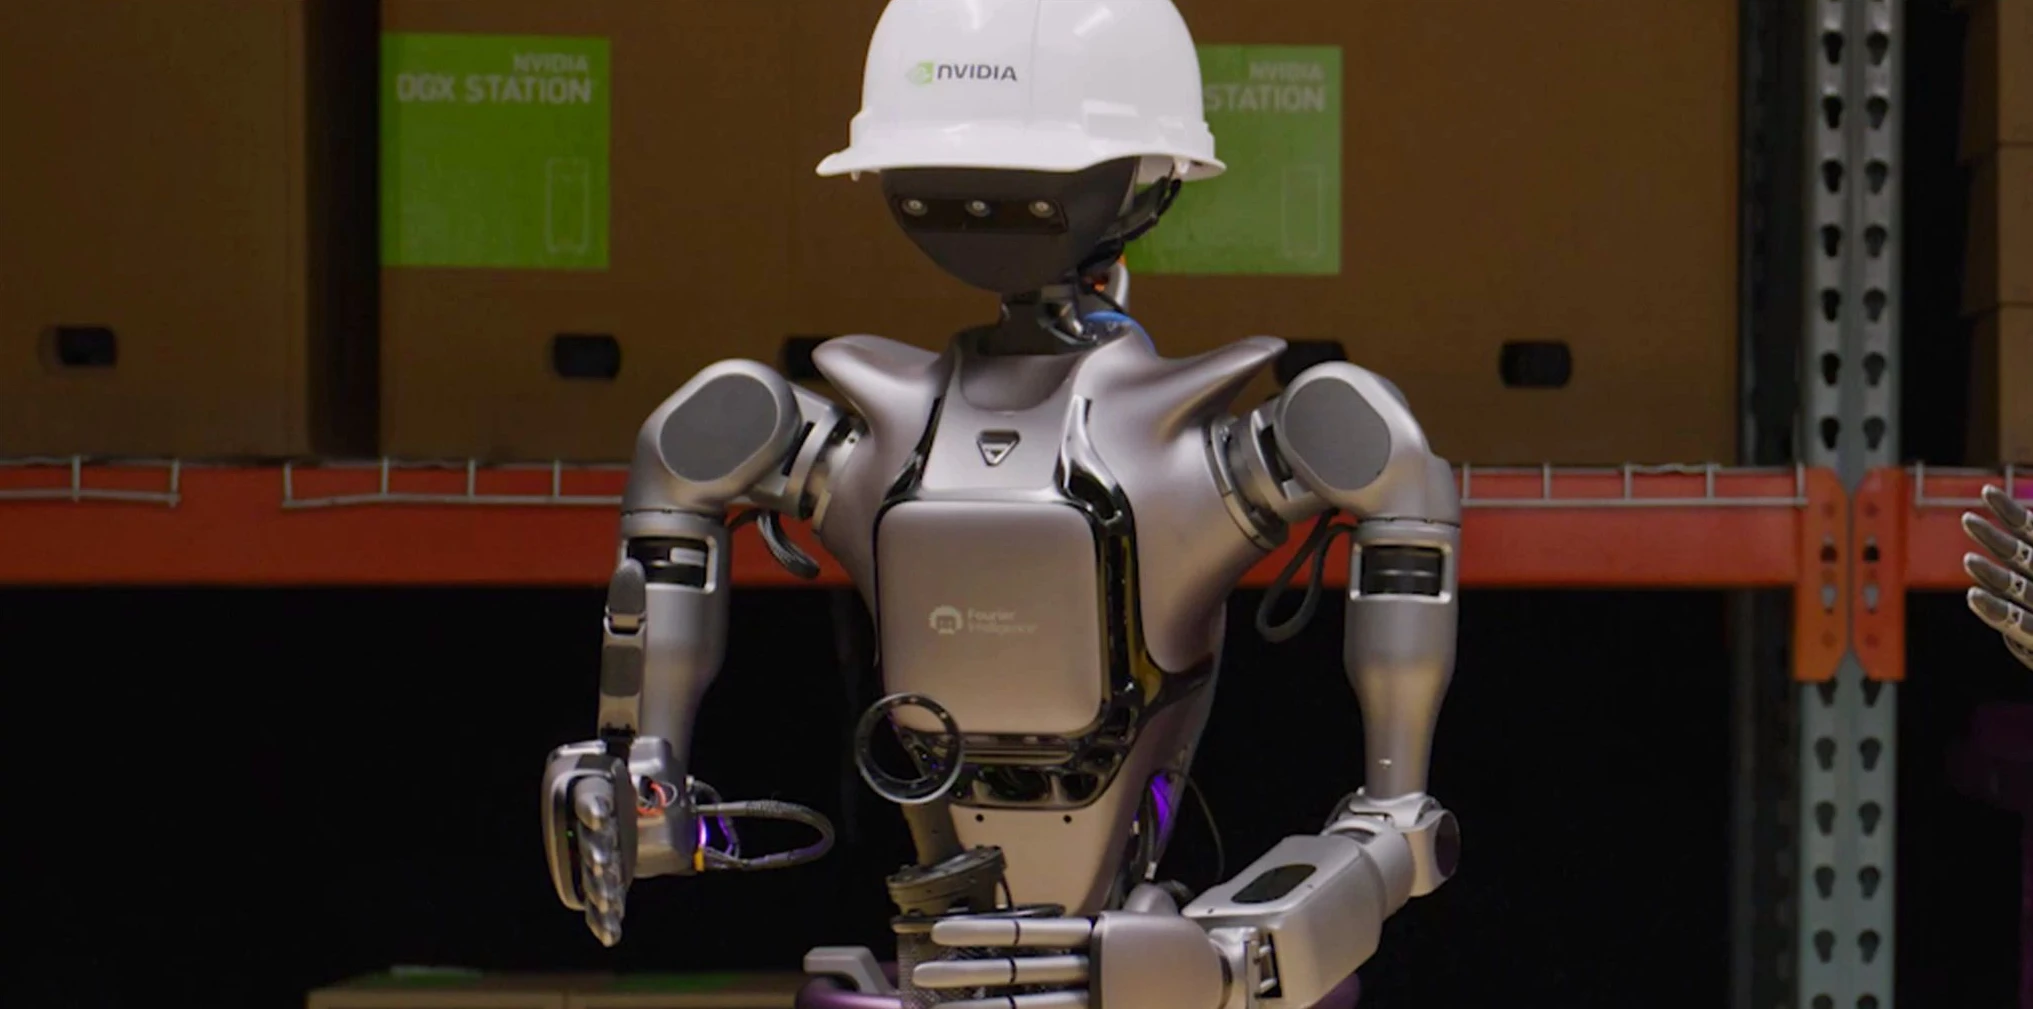
Studying pick-and-place, handovers and bimanual coordination with hardware demonstrations, simulation and task-specific adaptation.
 1080p
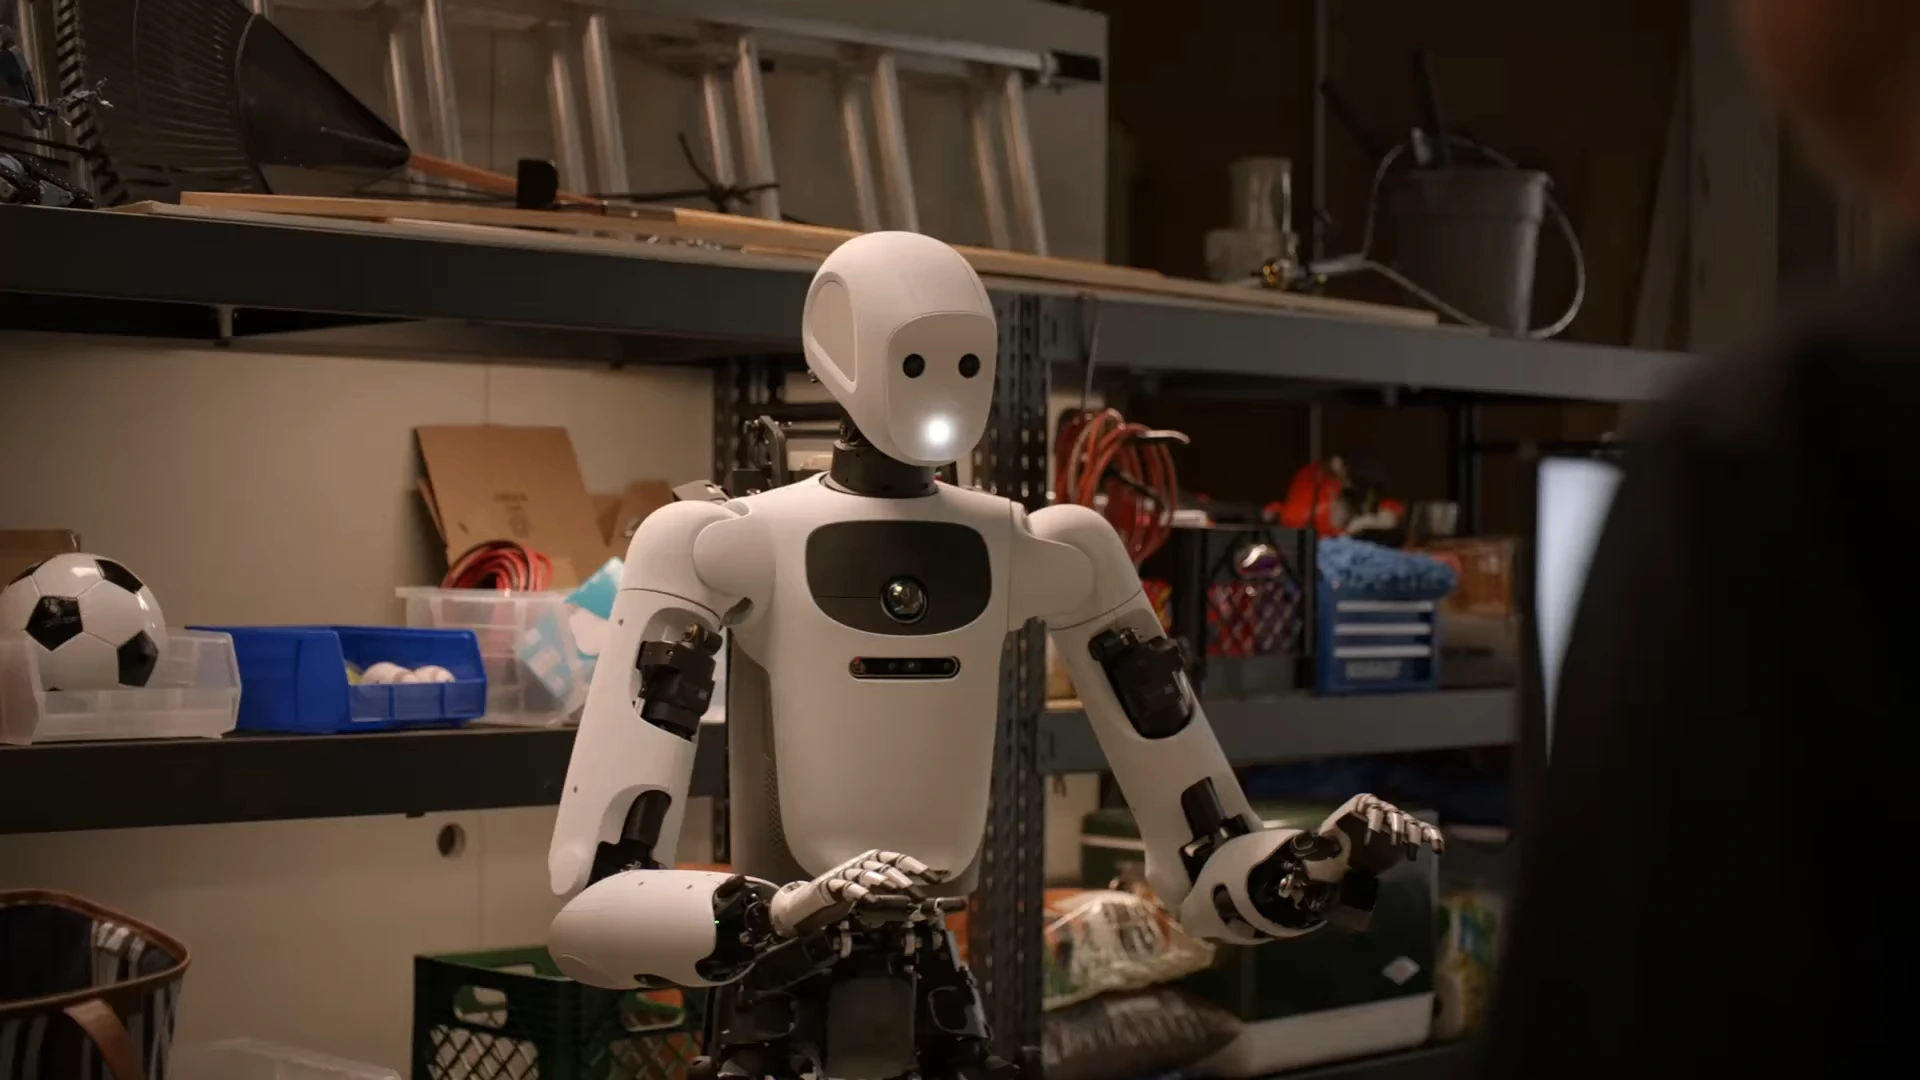
An official whole-body demonstration shows a robot carrying a container while moving, linking instruction understanding with execution.
Field-record noteEELS brings locomotion, mapping and risk assessment into a single exploration task.
Working on a related study? Submit a project with its objectives, progress and resource access.
Visit community projects ↗