← Latest updates
Preprint · proof of concept
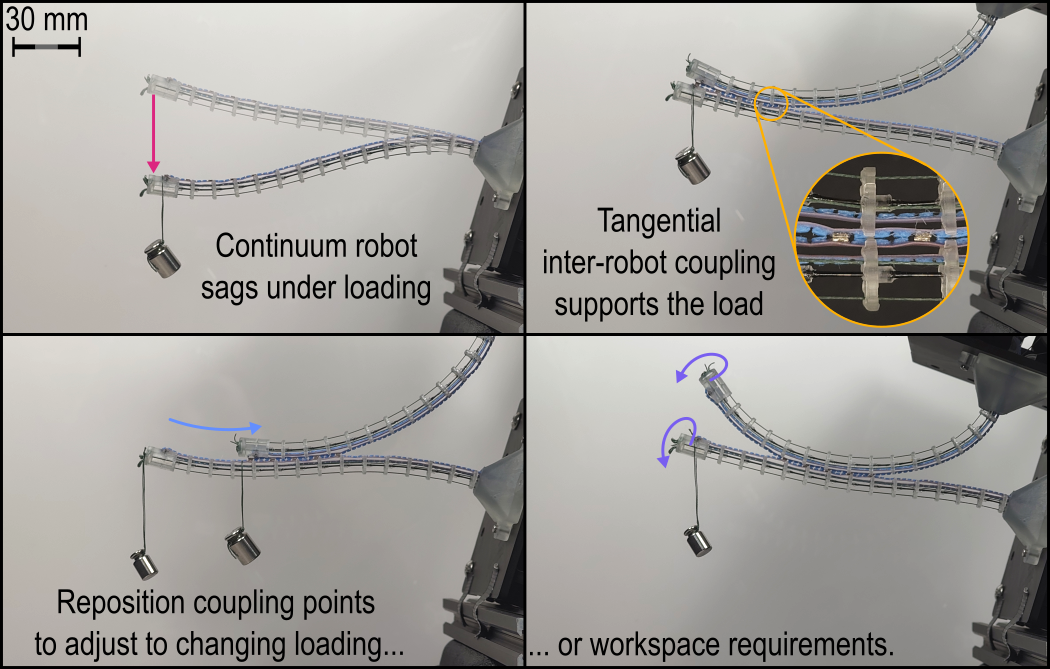
Moving magnetic coupling points along a 9 mm continuum robot
Integrated conveyor belts reposition functional elements along a slender robot, with permanent magnets demonstrating reconfigurable coupling between robots.
- Source published
- Sources checked
- 2026-11-09
What changed
- Up to three conveyor mechanisms fit inside a 9 mm diameter continuum robot.
- Changing the position and number of magnetic coupling points adjusts the coupled system’s effective stiffness.
Relevance to constrained-space work
Repositioning functional elements along the body extends mechanism design beyond a fixed end effector.
Compiled by OpenRuwei editorial