 1080p
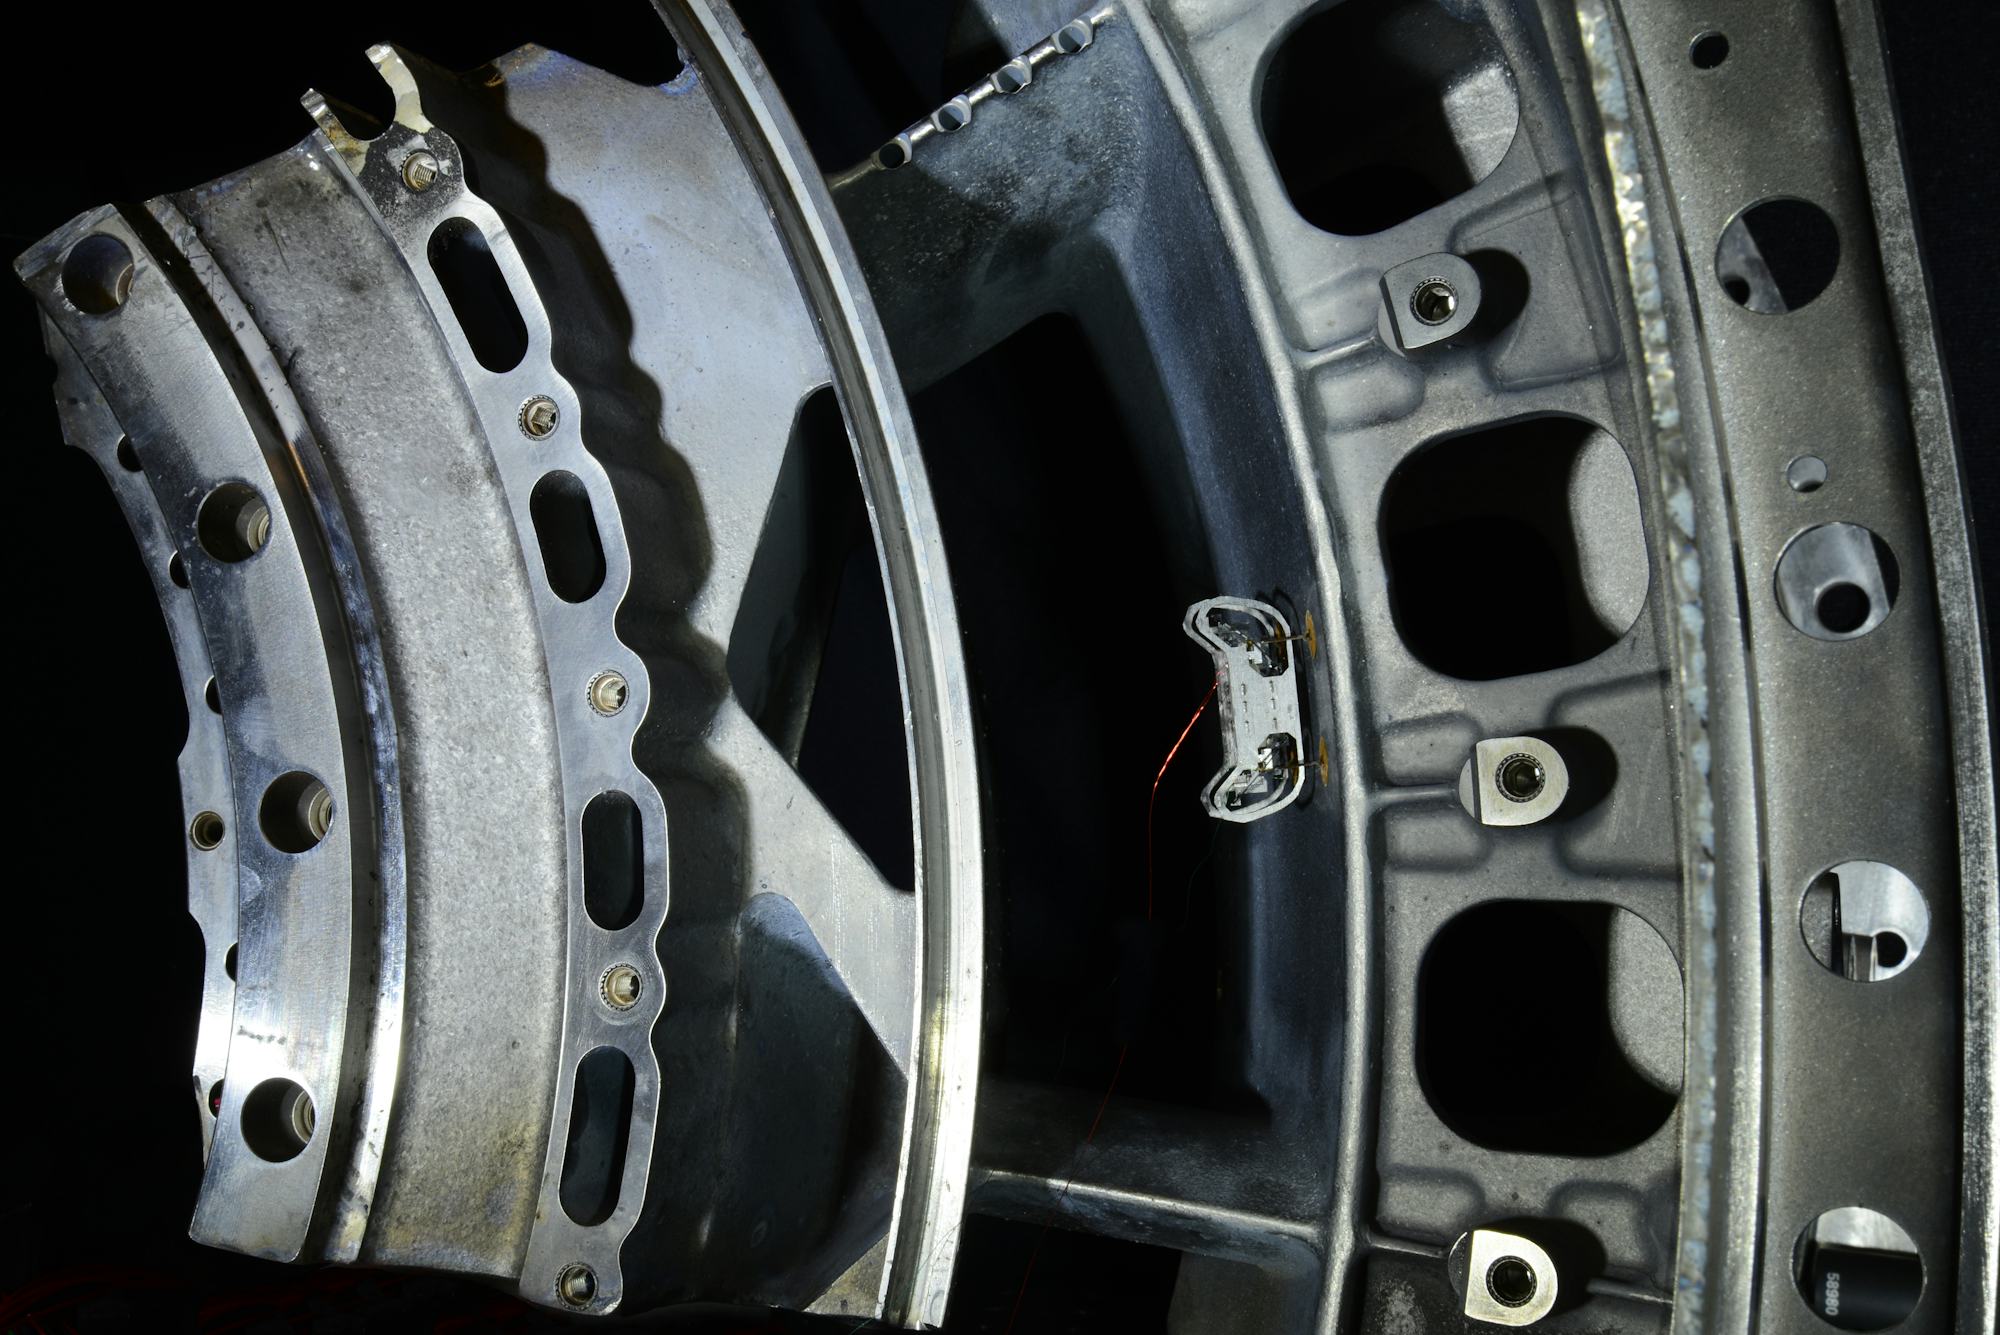
HAMR-E: electroadhesive crawling on engine walls
A centimetre-scale tethered robot uses electroadhesive feet to crawl on vertical, inverted and curved conductive surfaces.
Tethered climbing experimentsRead case
Structure, actuation and load transmission.
Space illustration · OPENRUWEI1080pA centimetre-scale tethered robot uses electroadhesive feet to crawl on vertical, inverted and curved conductive surfaces.
 1080p
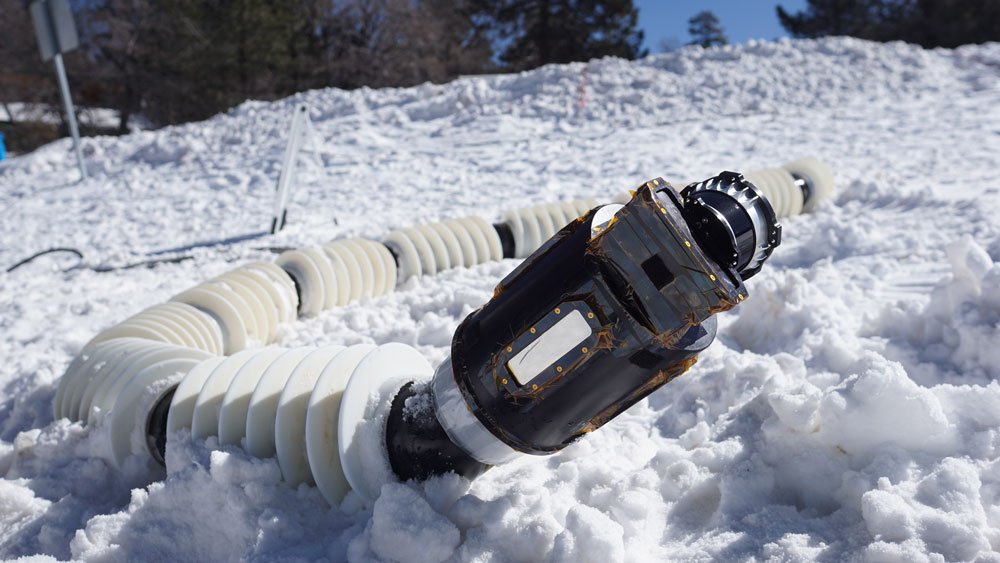
A segmented robot combines rotating screw propulsion with environmental mapping in ground tests on ice, snow, sand and glacier passages.
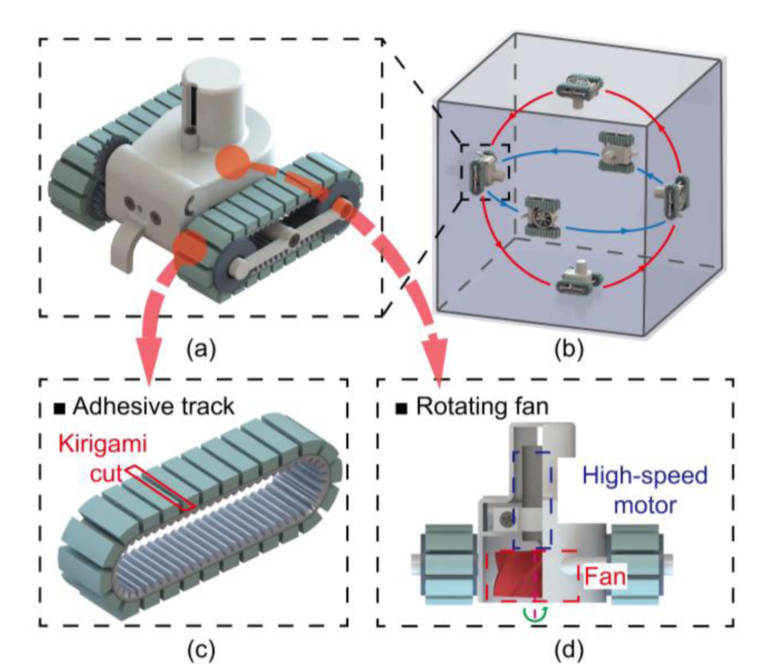
Kirigami-inspired adhesive tracks and negative-pressure preload enable a miniature robot to transition between surfaces of varying curvature.
 720p
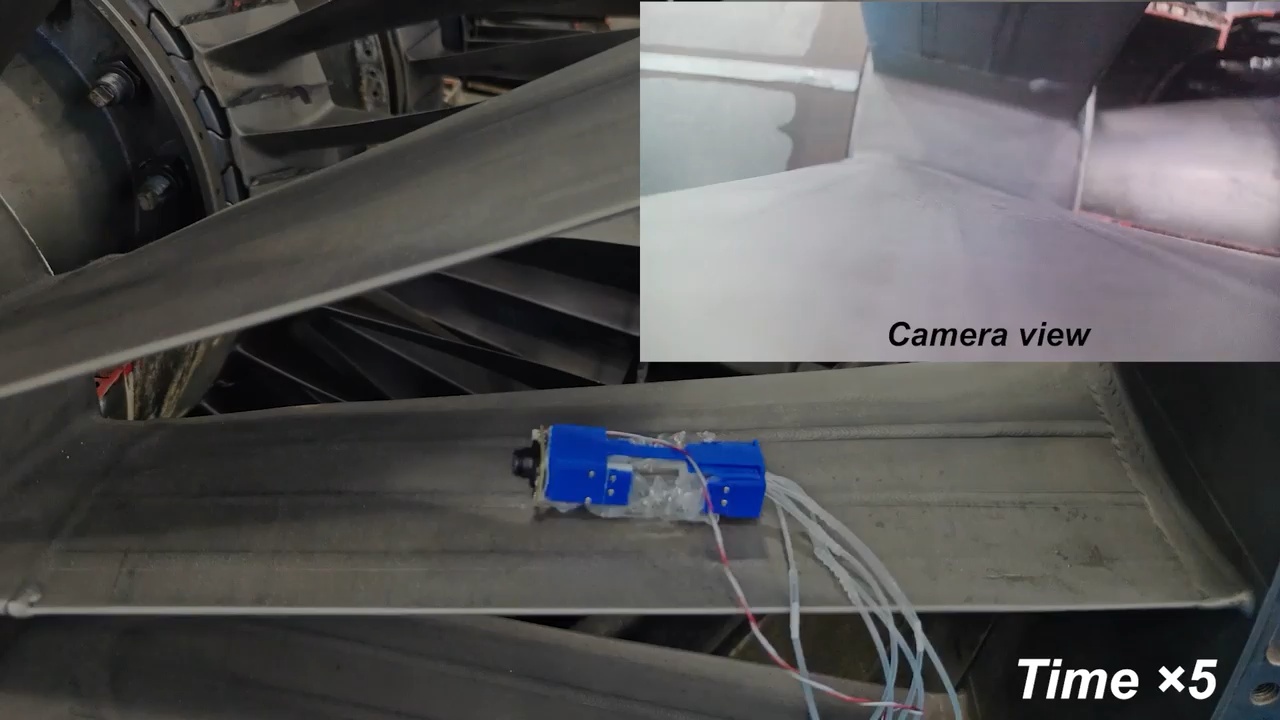
A unified active-compliance mechanism adapts to varied surfaces, with visual-inspection tests inside a decommissioned engine.
 1080p
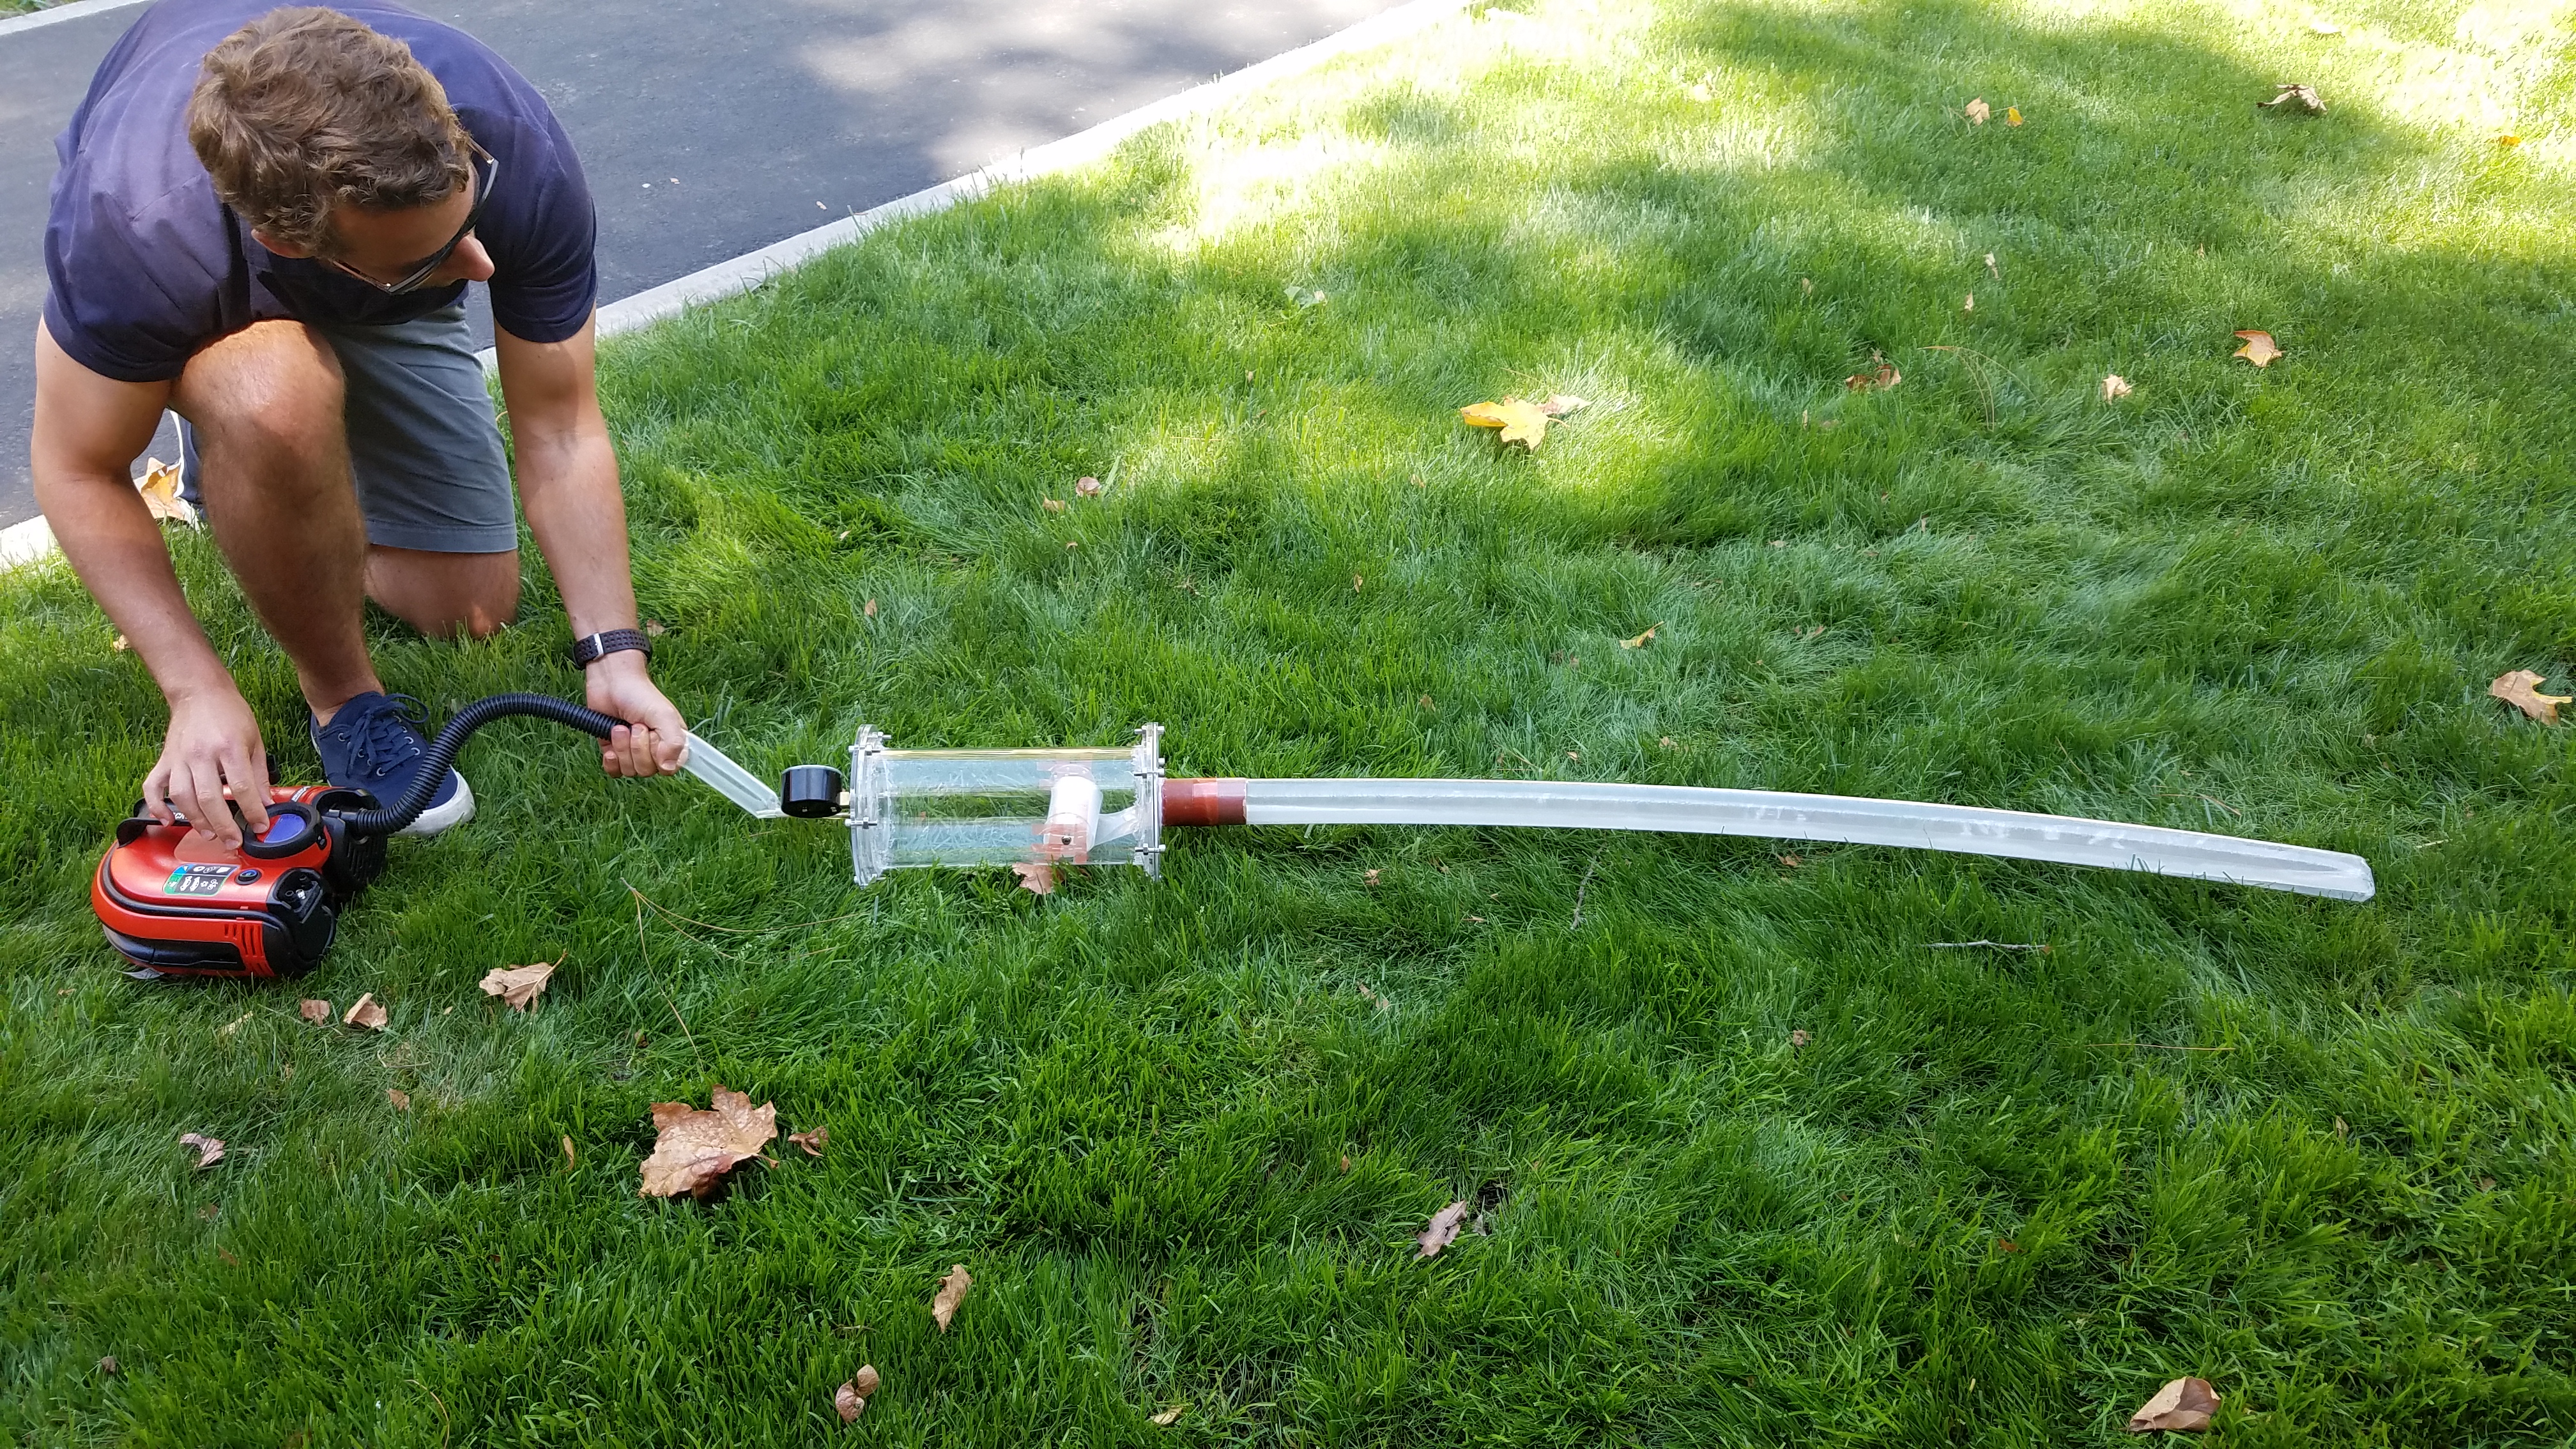
A flexible tube grows by eversion at its tip, offering another way to move around obstacles.
 4K
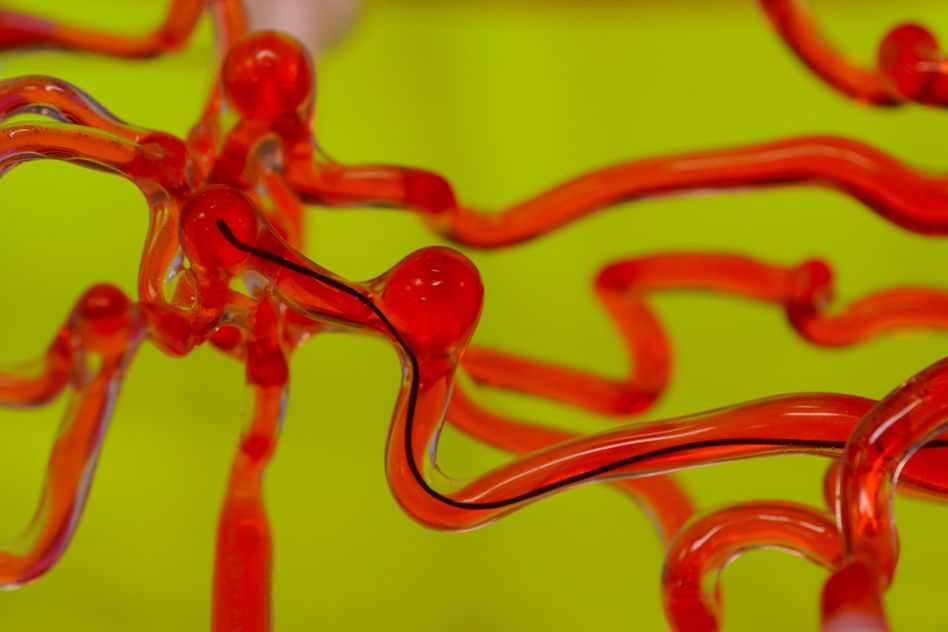
A magnetic field steers a slender thread, with a hydrogel coating to reduce friction.
 1080p
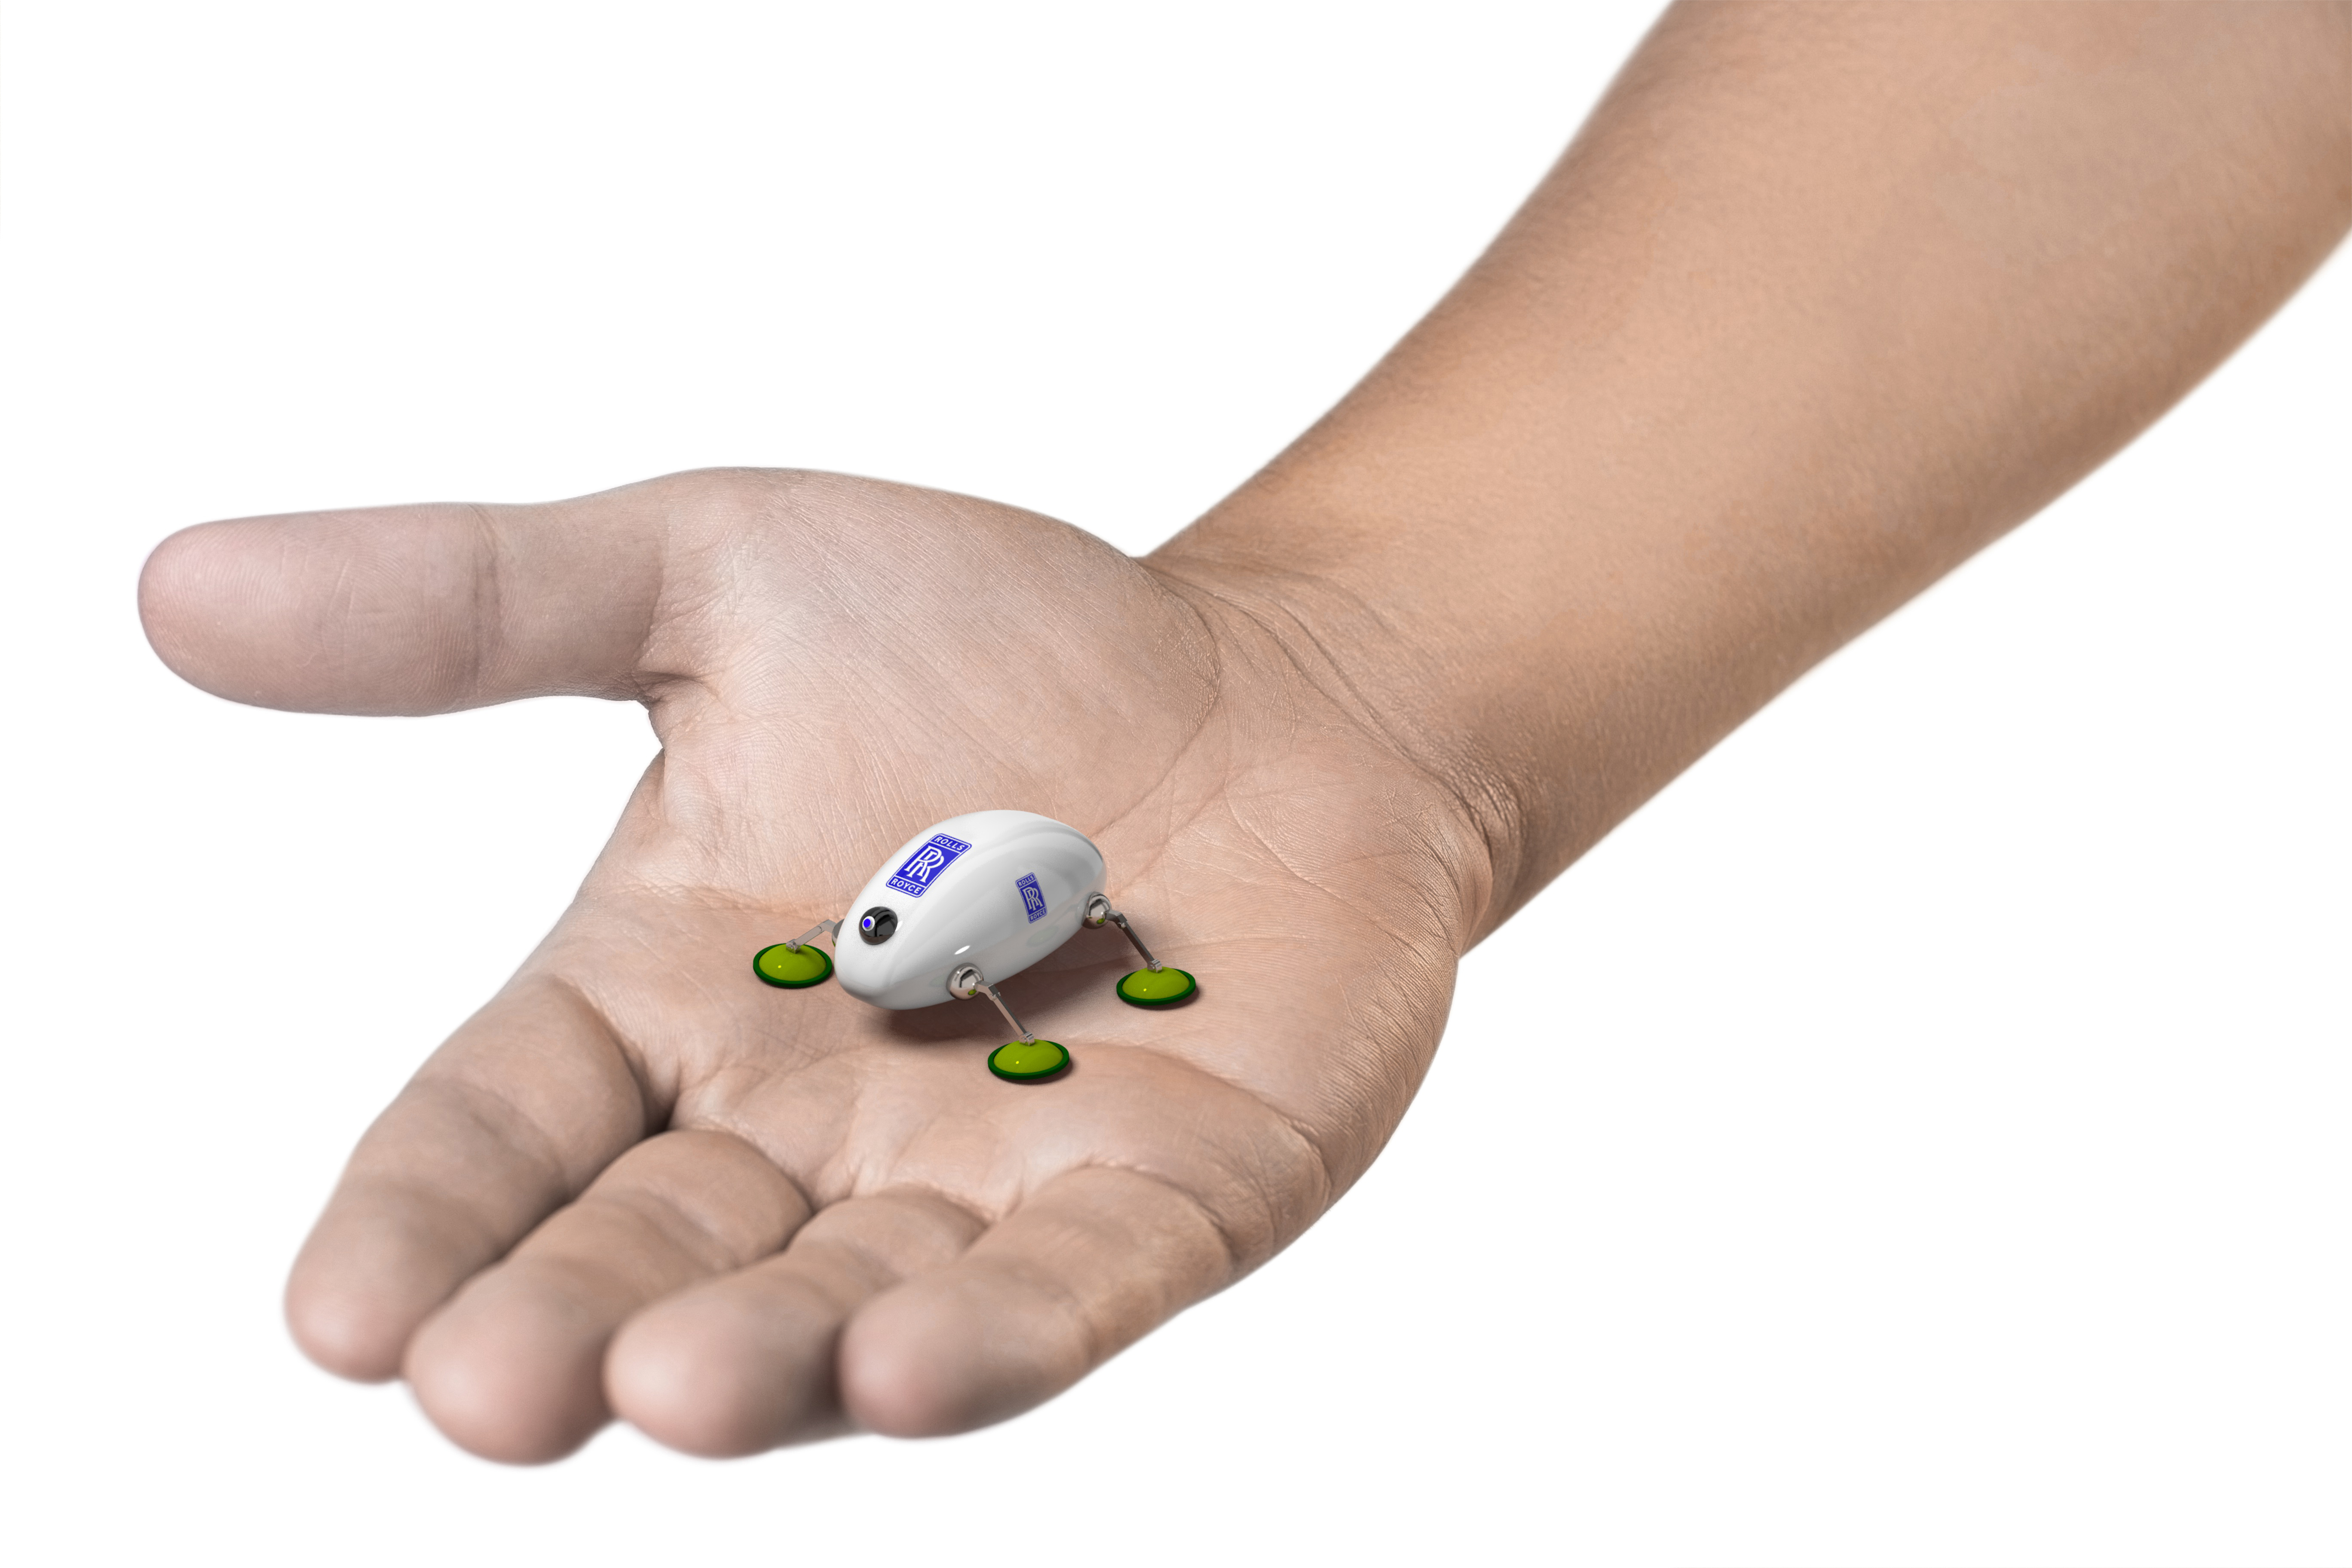
A proposed snake carrier would deploy and retrieve miniature crawlers to inspect surfaces beyond conventional borescope access.
 Video
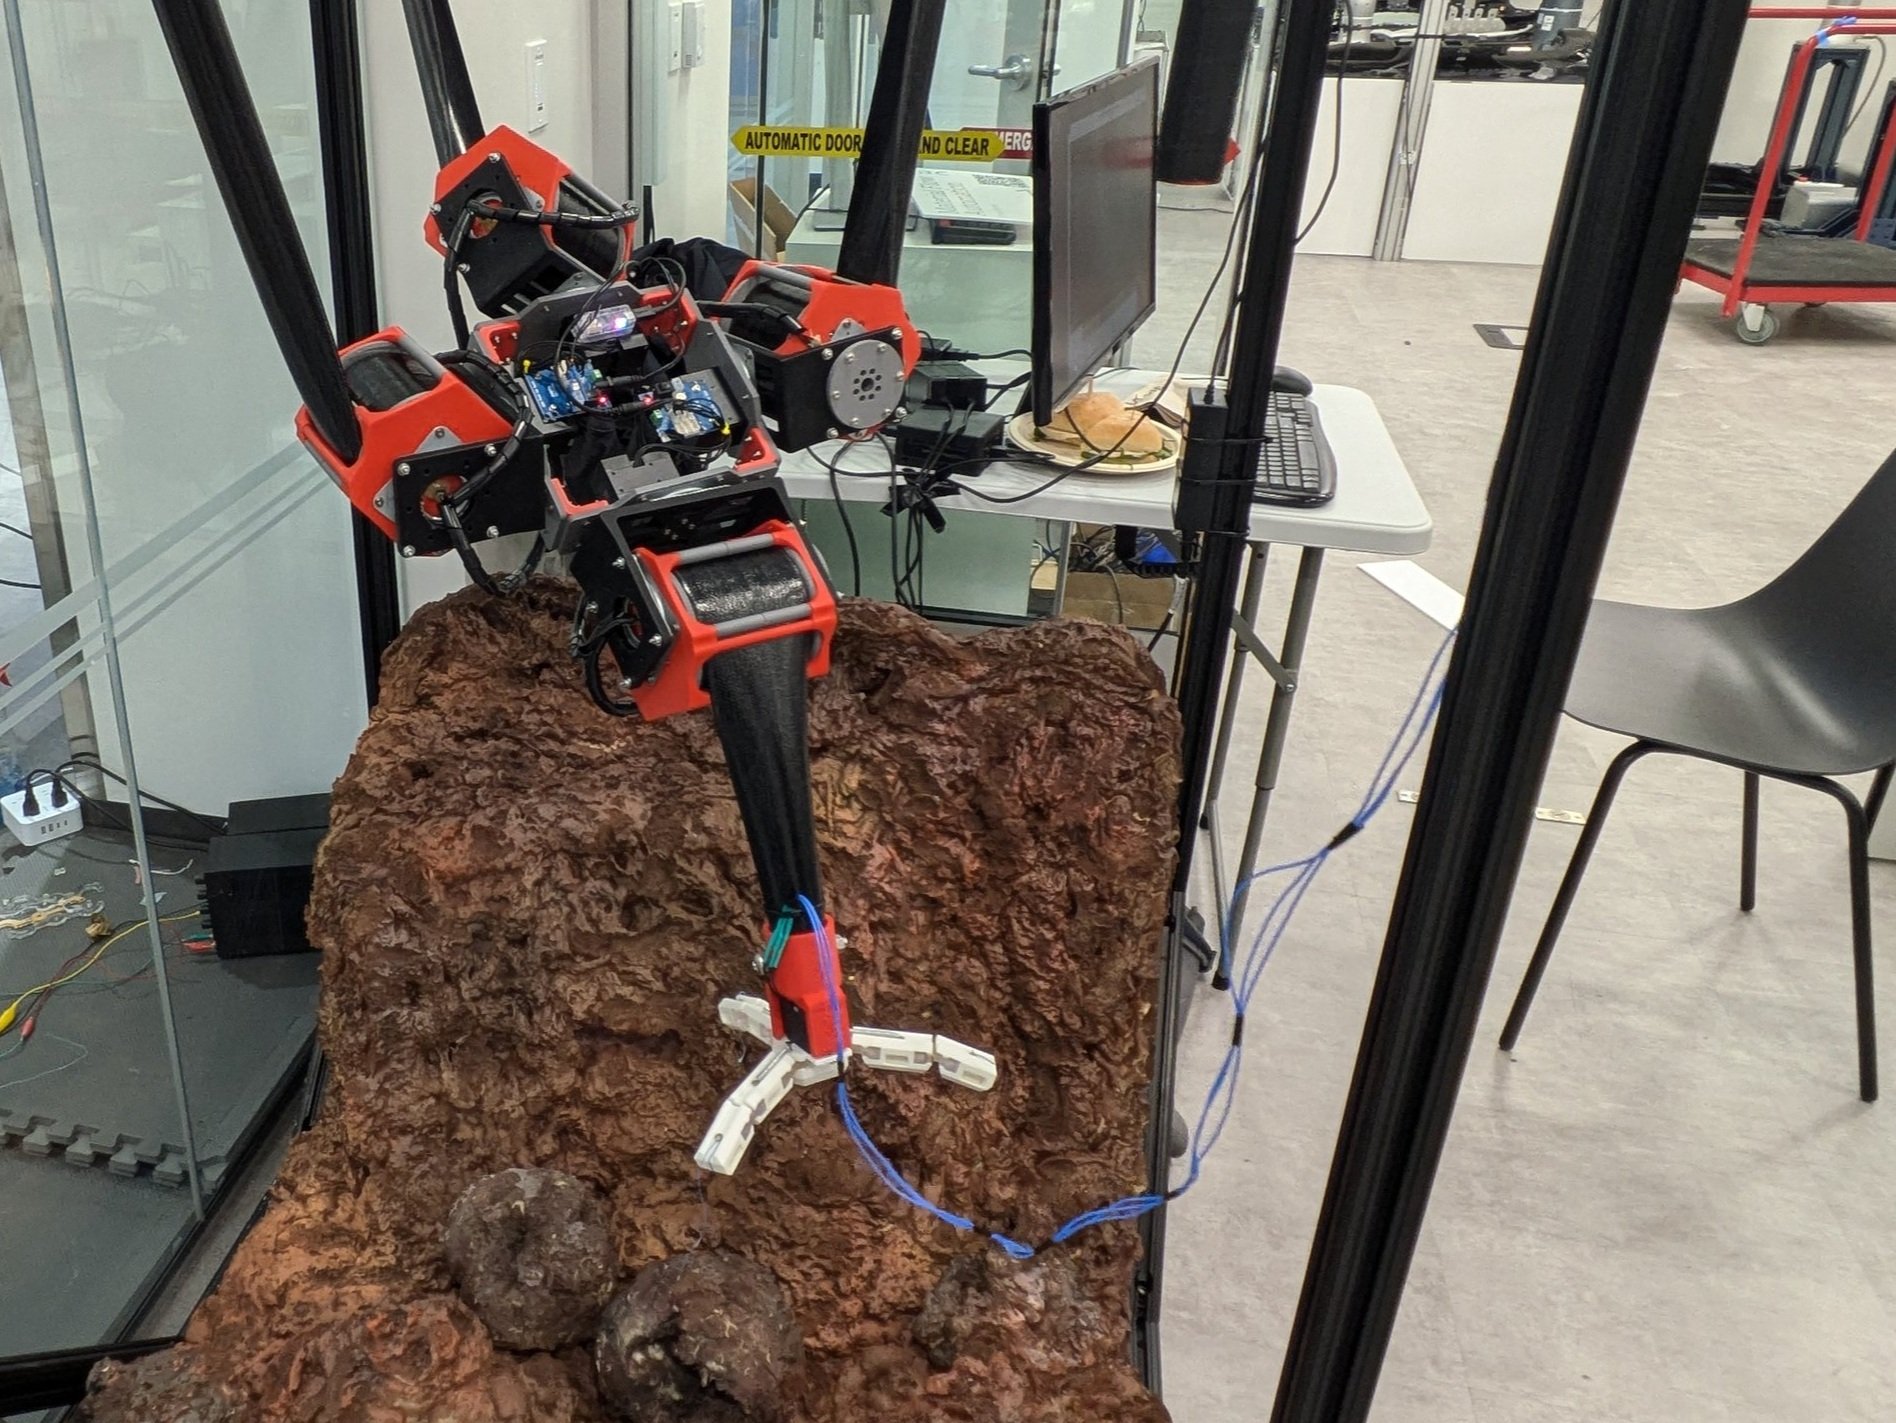
Microspine grippers at the ends of extendable booms find anchors on rock surfaces.
 1080p
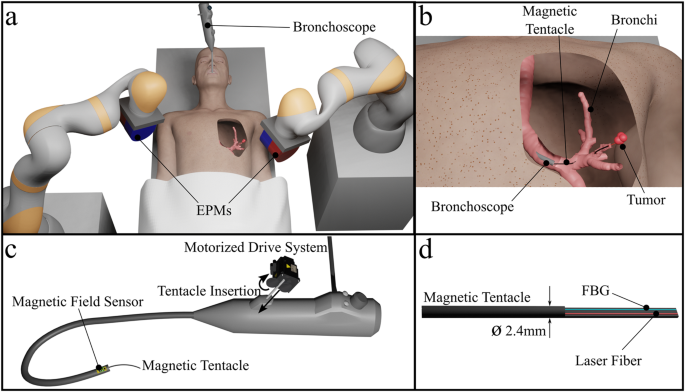
A 2.4 mm magnetic catheter integrates shape sensing and an optical fibre for peripheral-airway navigation and laser delivery.
 1080p
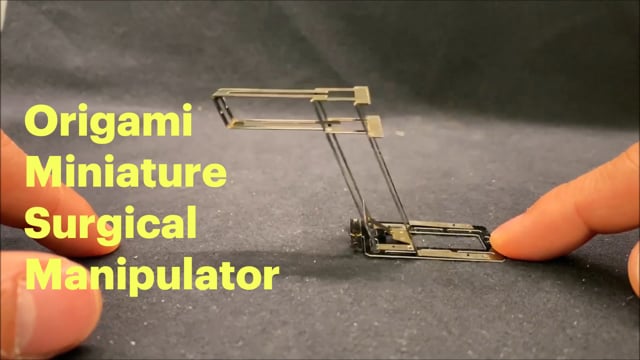
The miniature teleoperated mini-RCM demonstrates tracing and simulated retinal-vein cannulation.
 1080p
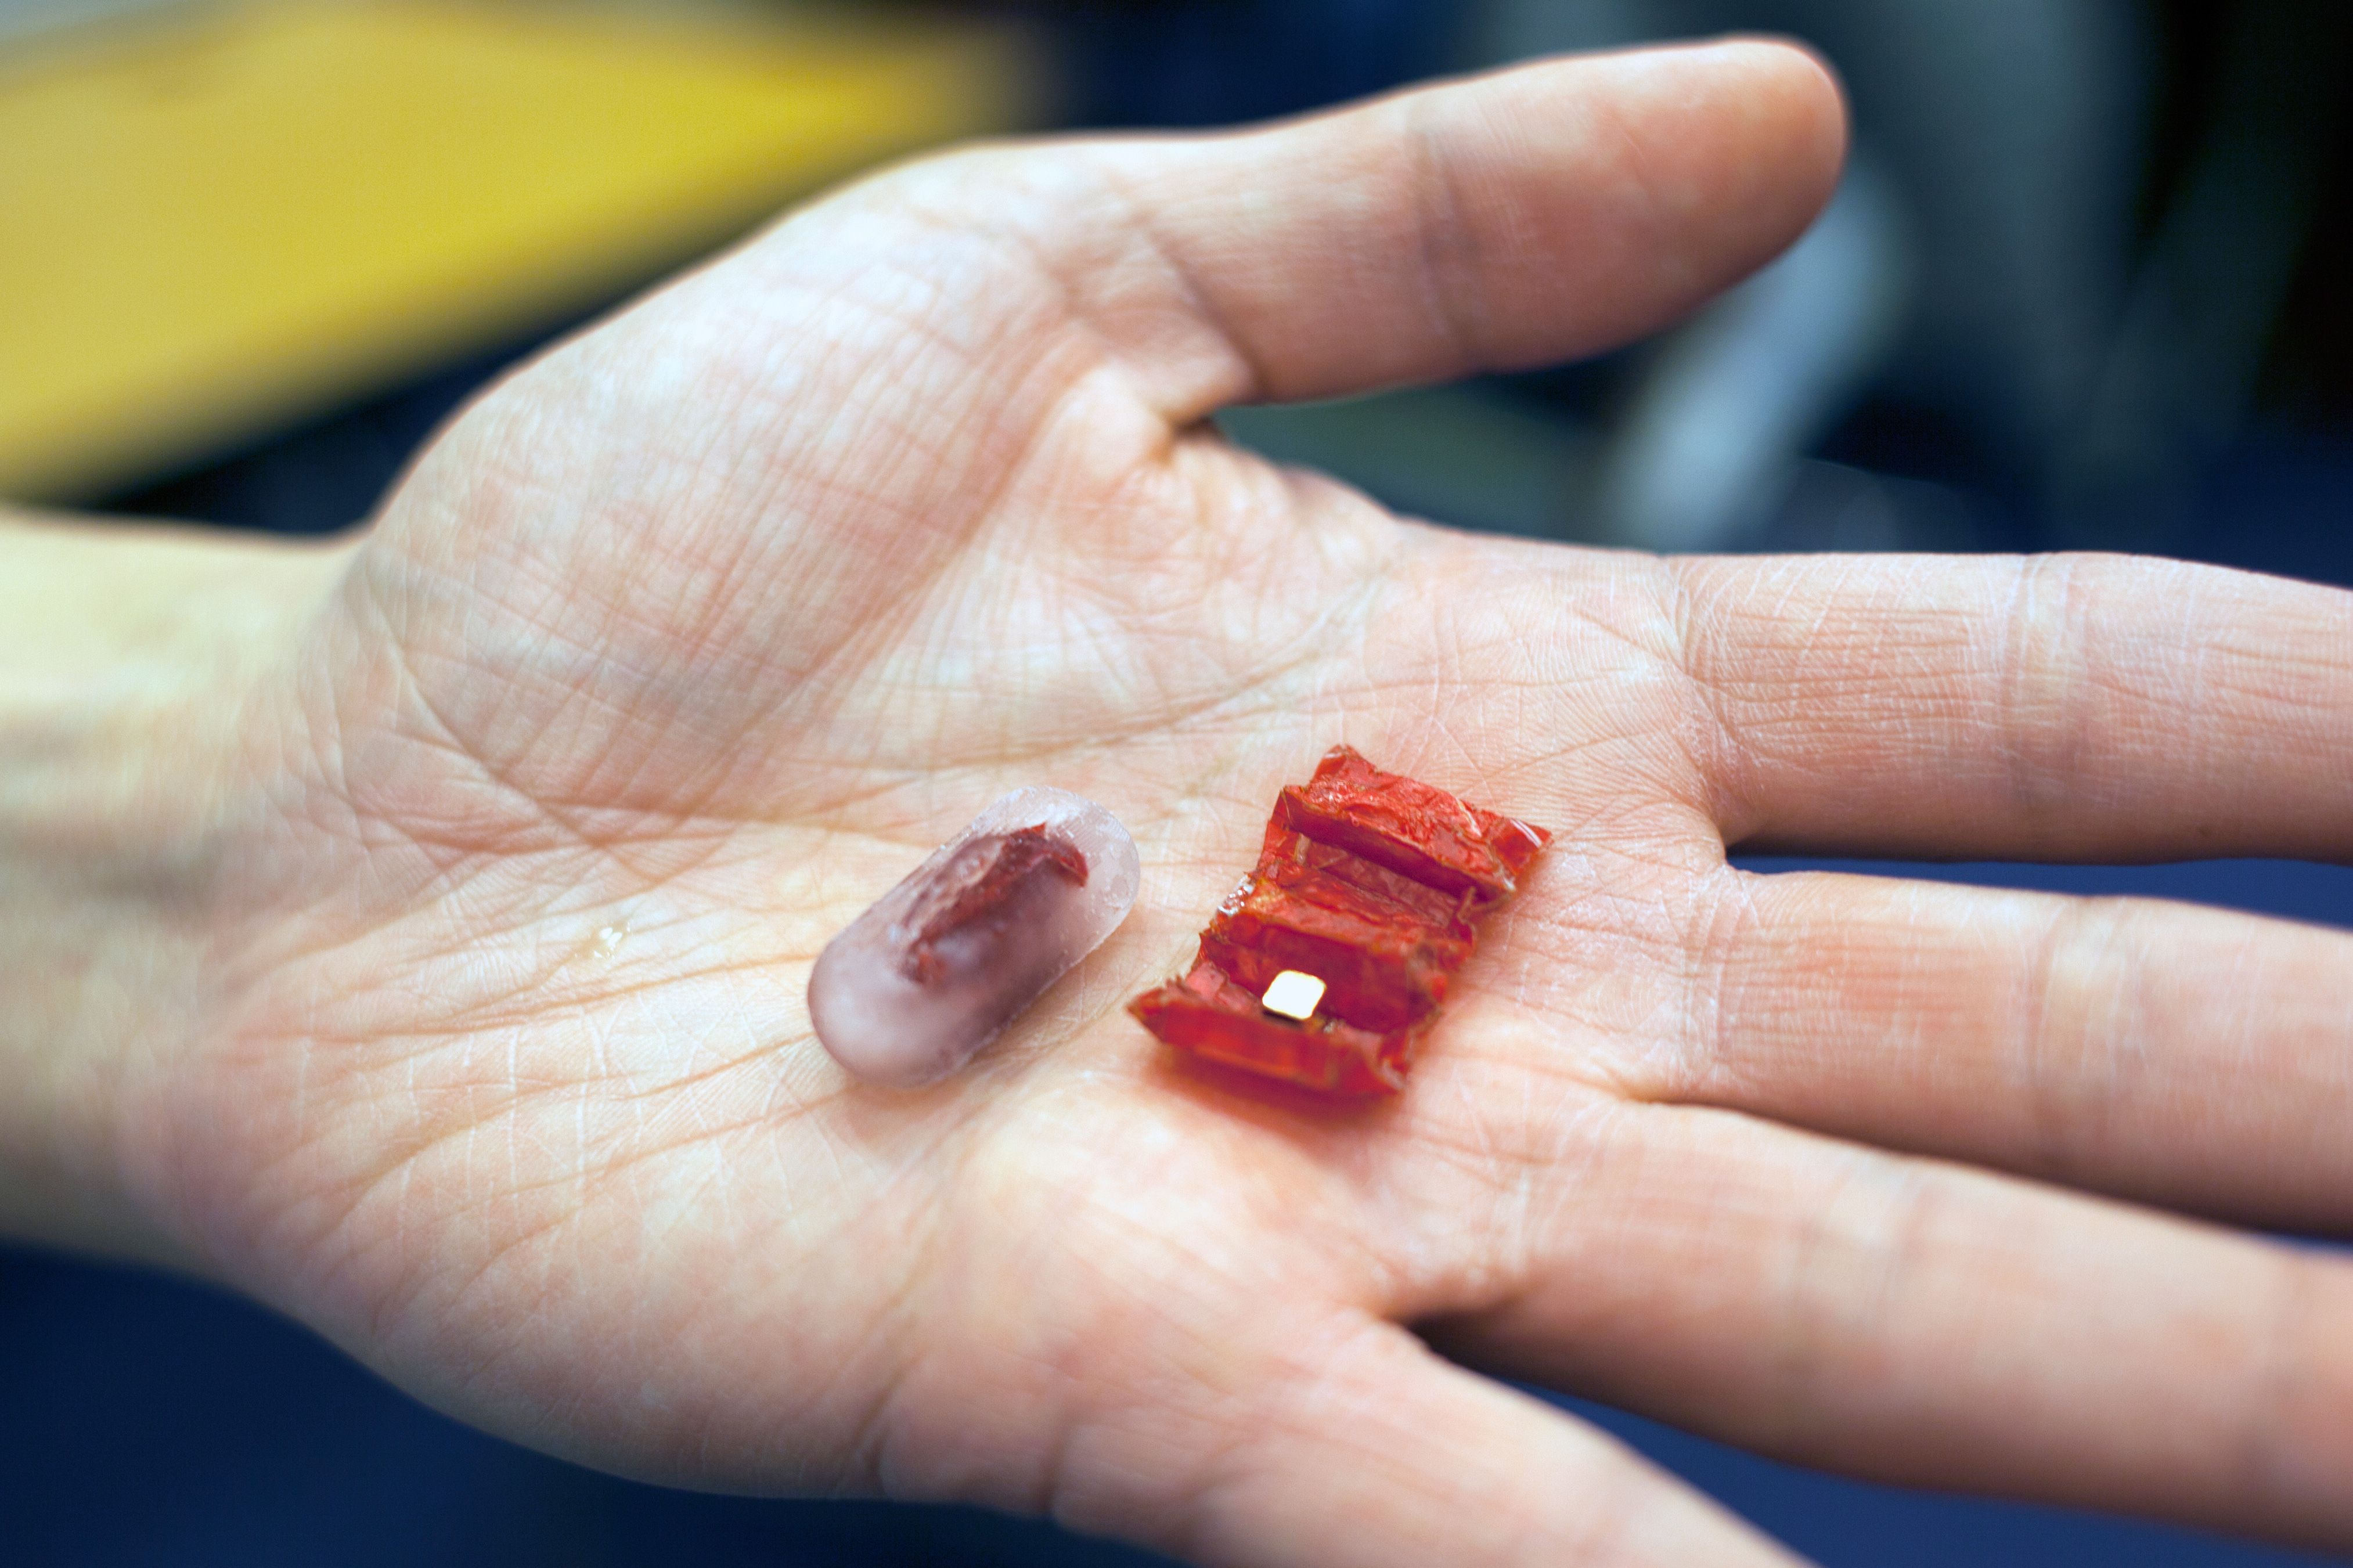
A robot unfolds from a capsule and uses magnetic guidance to remove a button battery in a simulated stomach.
Magnetic actuation and origami-inspired structures support millimetre-scale research on locomotion, shape change and delivery.
 480p
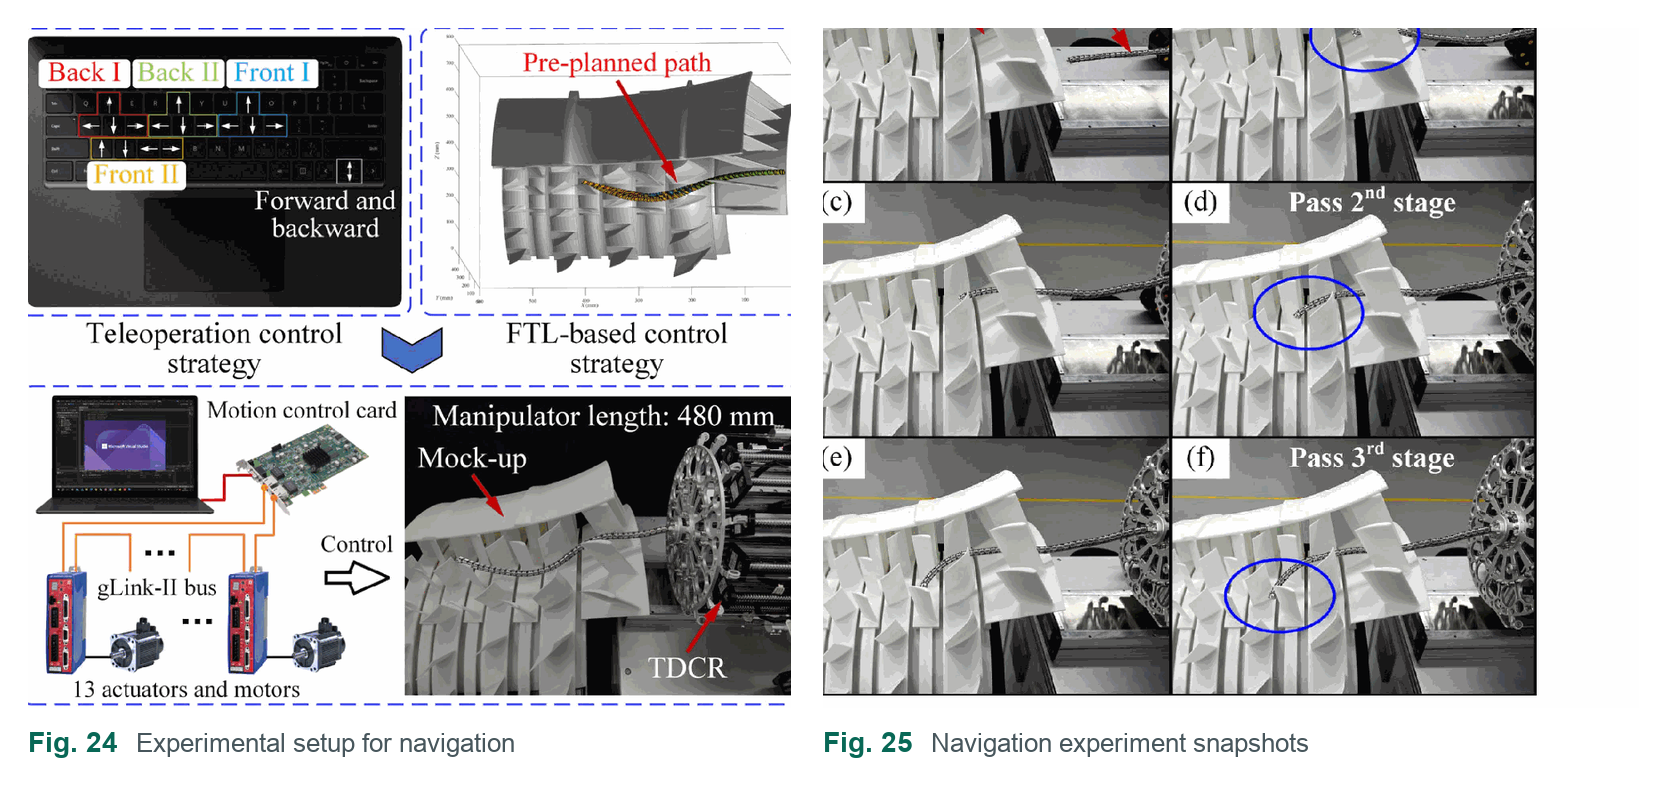
Internal contact-aided compliant mechanisms improve a slender manipulator’s resistance to twisting and compression buckling.
Nested tendon-driven and concentric-tube structures use axial sliding to adjust a continuum robot’s configuration and stiffness.
 540p
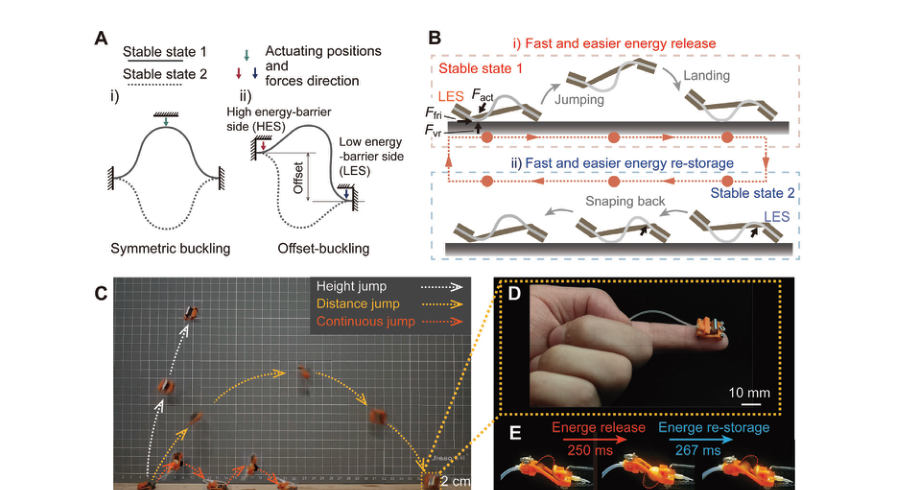
Tunable energy barriers control storage and release to produce multiple jumping modes at insect scale.
 Video
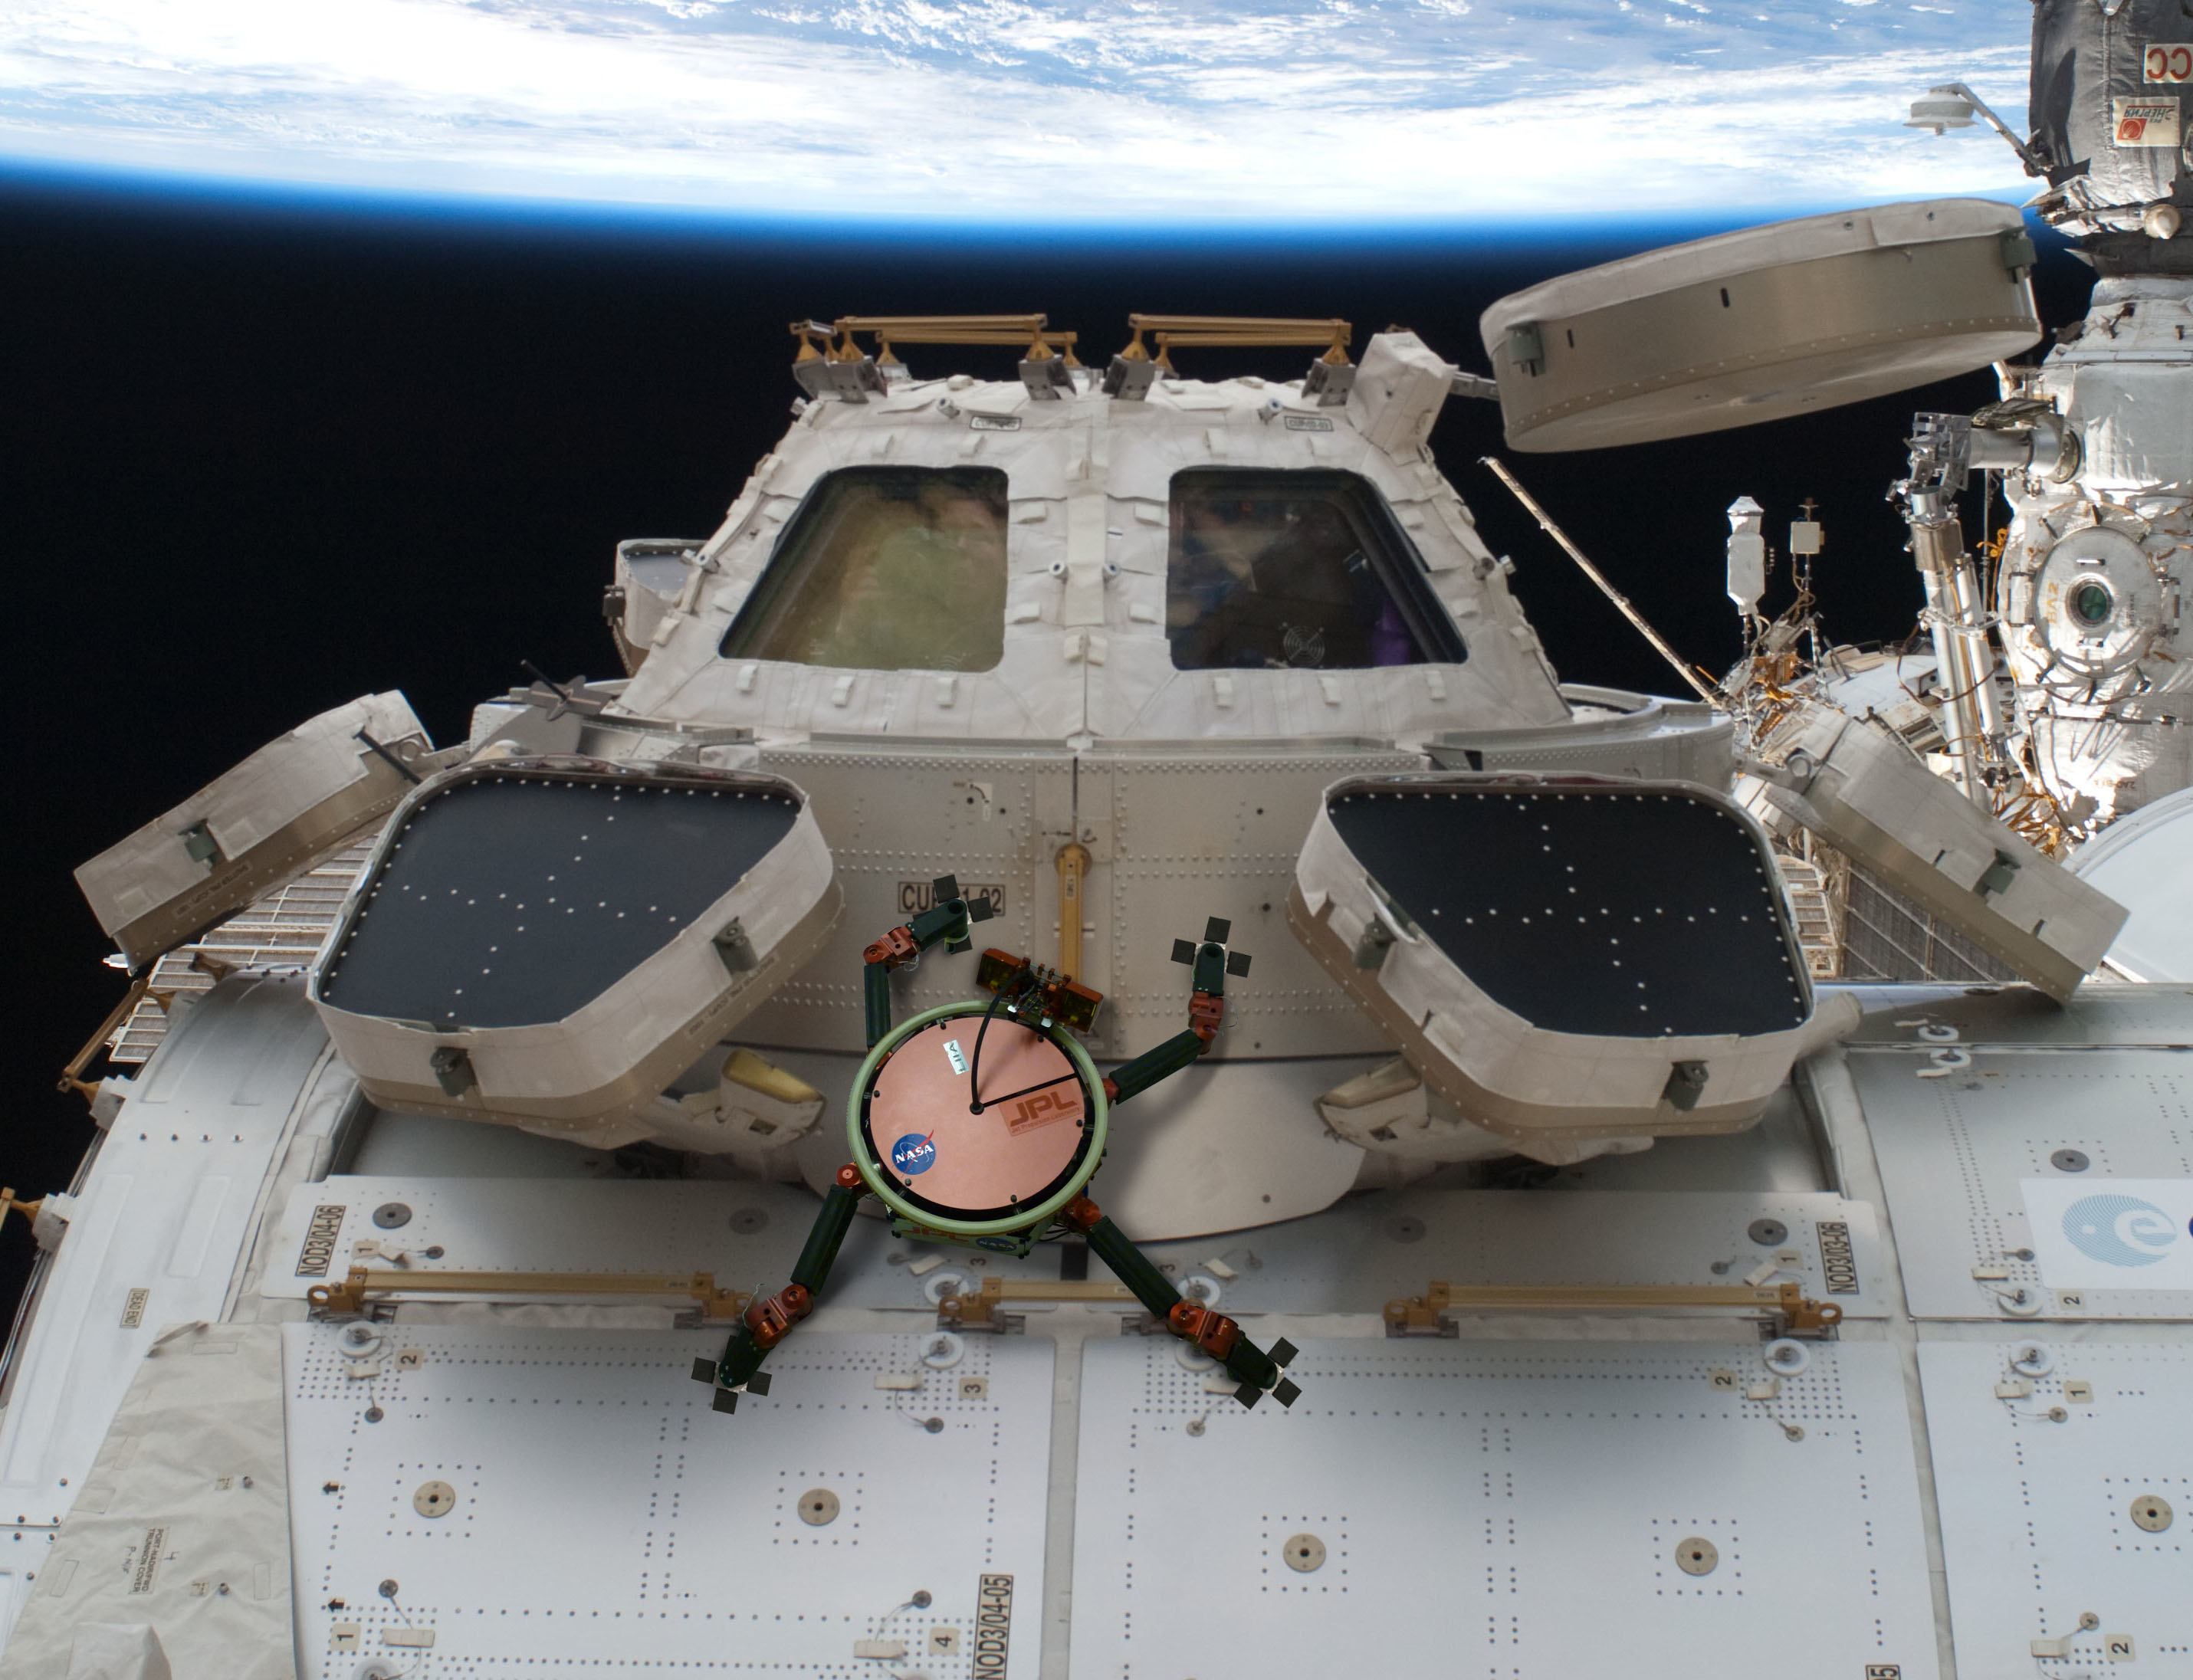
Adhesion, locomotion and grasping studied on spacecraft-surface mock-ups and in microgravity tests.
 Video
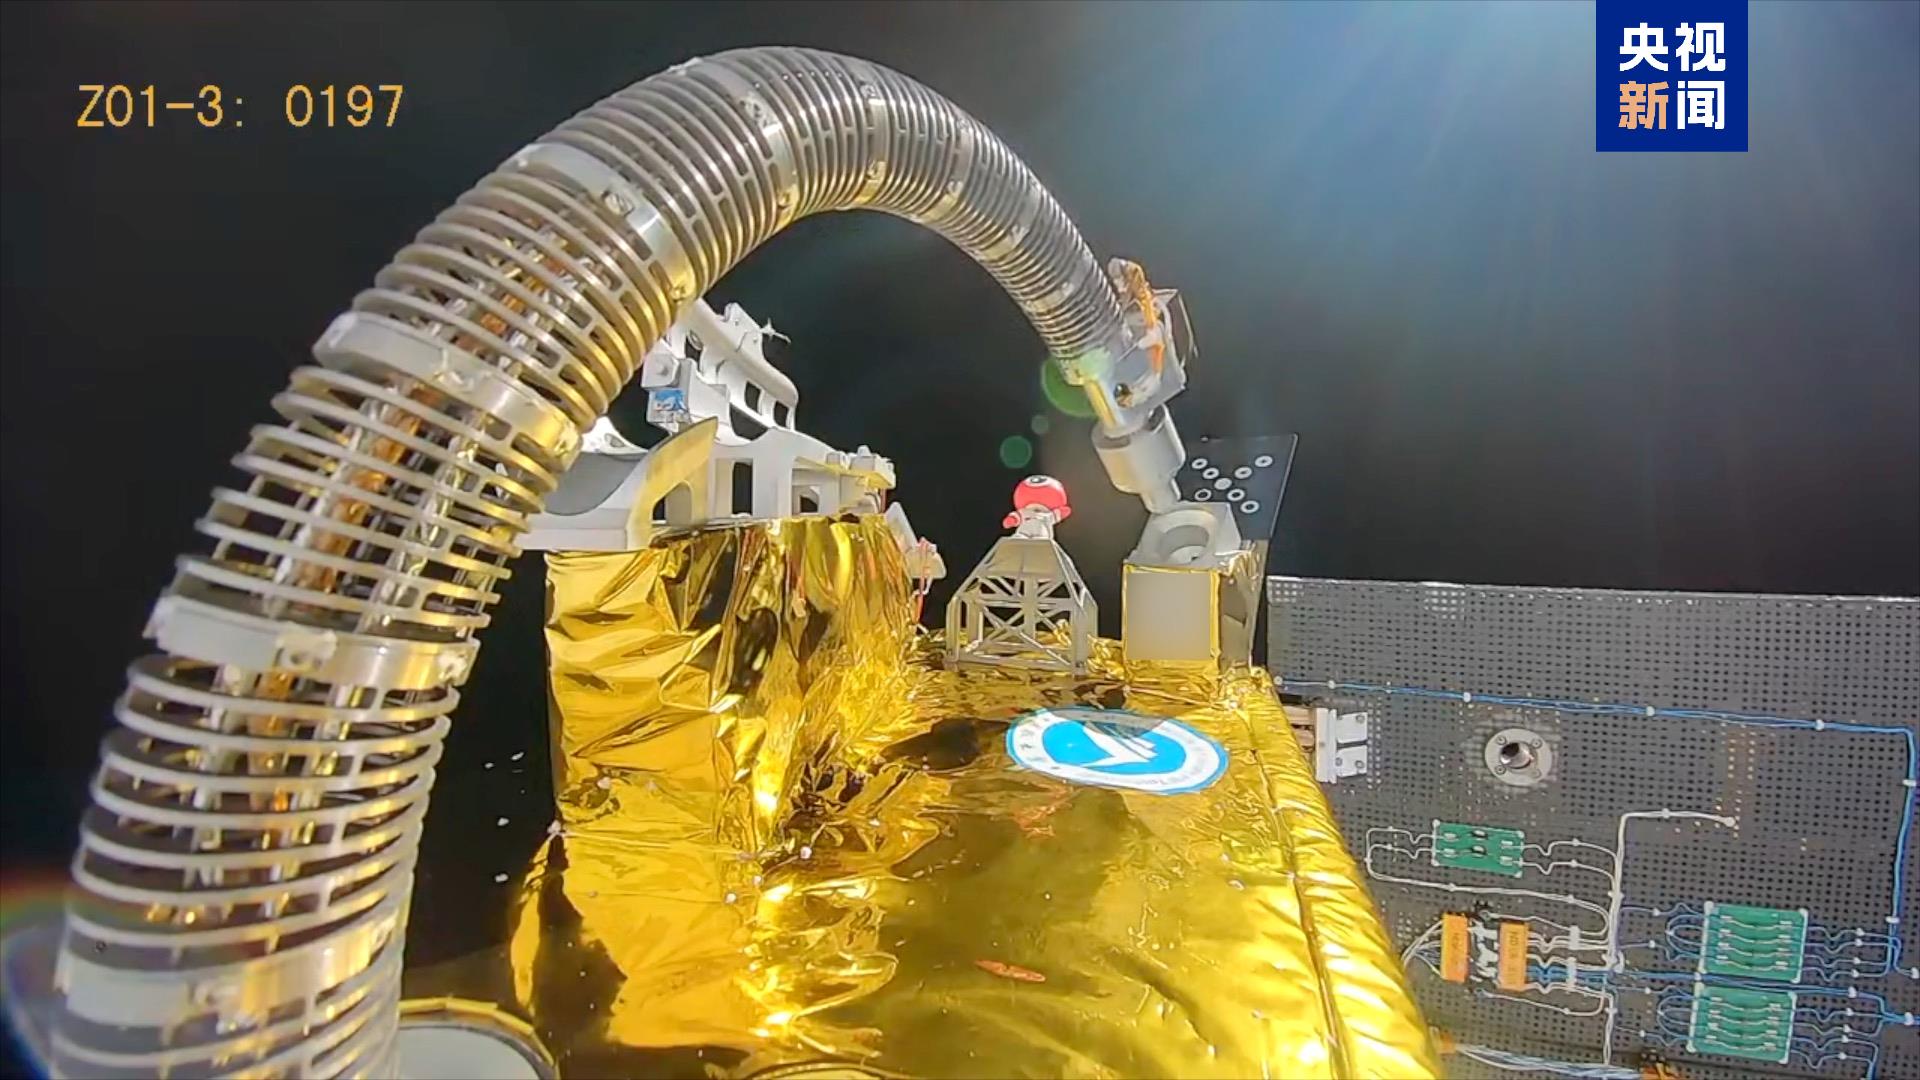
Orbital tests aboard Xiyuan-0 examined simulated refuelling and compliant manipulation.
 720p
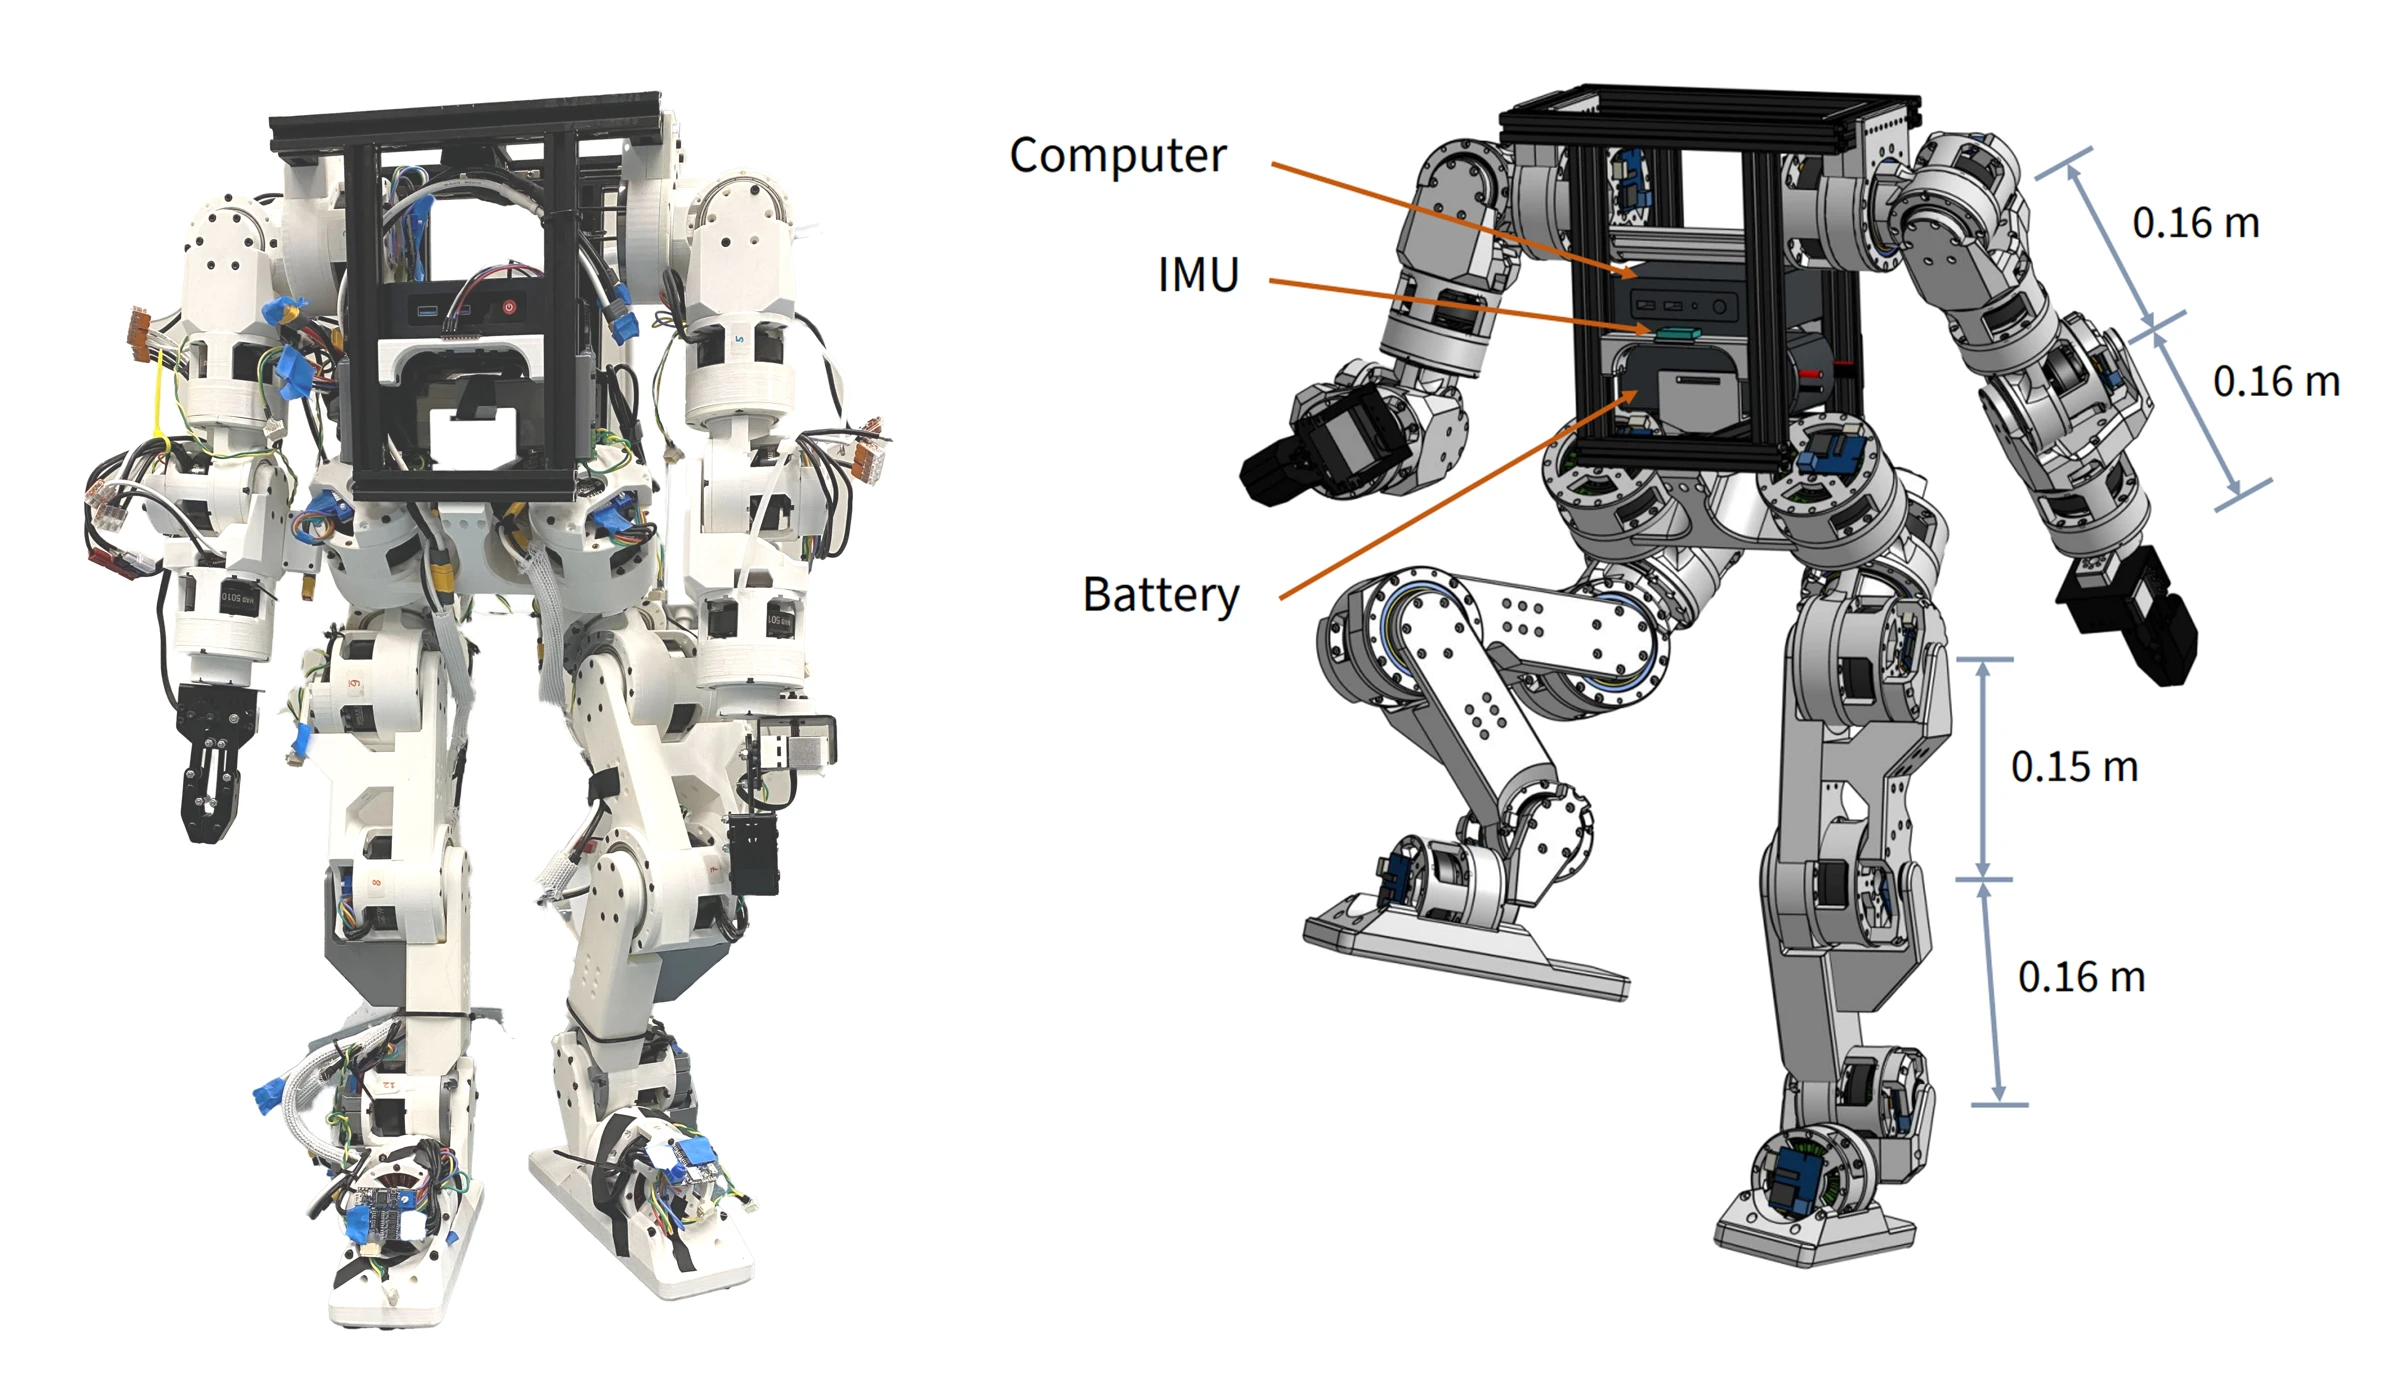
Open hardware and learning-based control, from 3D-printed gearboxes to arm manipulation and bipedal walking.
 Video
Tesla’s official video shows revised actuators, walking and hand motion, including gentle handling of an egg.
Working on a related study? Submit a project with its objectives, progress and resource access.
Visit community projects ↗