← Latest updates
Preprint · simulation
Locating body contact from tendon measurements
A new preprint combines known obstacle geometry with moving horizon estimation to infer contact location and force in a two-section continuum-robot simulation.
- Source published
- Sources checked
- 2026-11-09
What changed
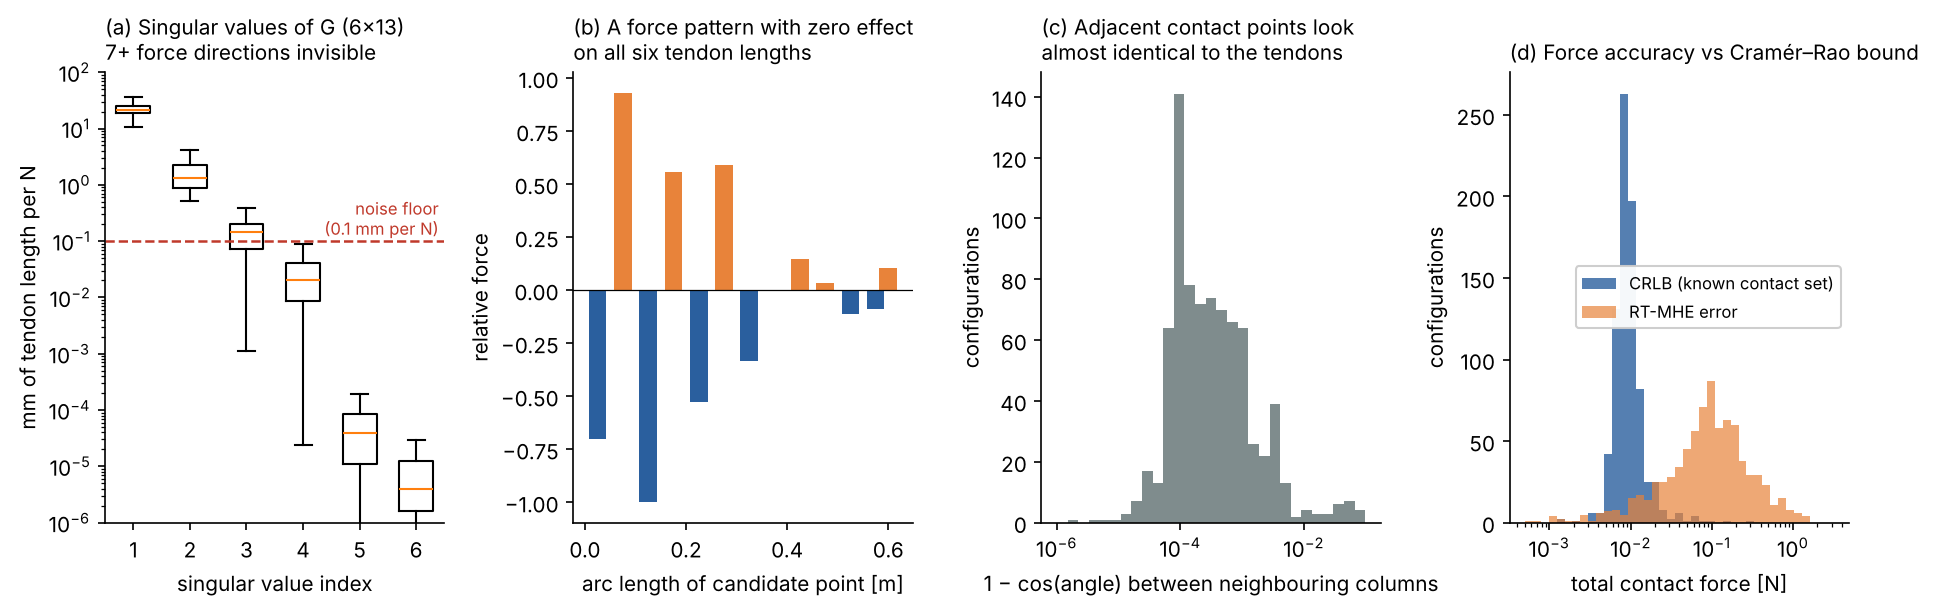
- The finite-element benchmark reports 0.9 mm location error and 0.22 N force error; these are simulation results.
- Known geometry, non-penetration and complementarity constraints make contact estimation possible from otherwise insufficient tendon observations.
Relevance to constrained-space work
For narrow passages, the useful question is how geometric prior knowledge can supply contact feedback.
Compiled by OpenRuwei editorial