← Latest updates
Preprint · platform experiments
A reusable actuation platform for continuum robots
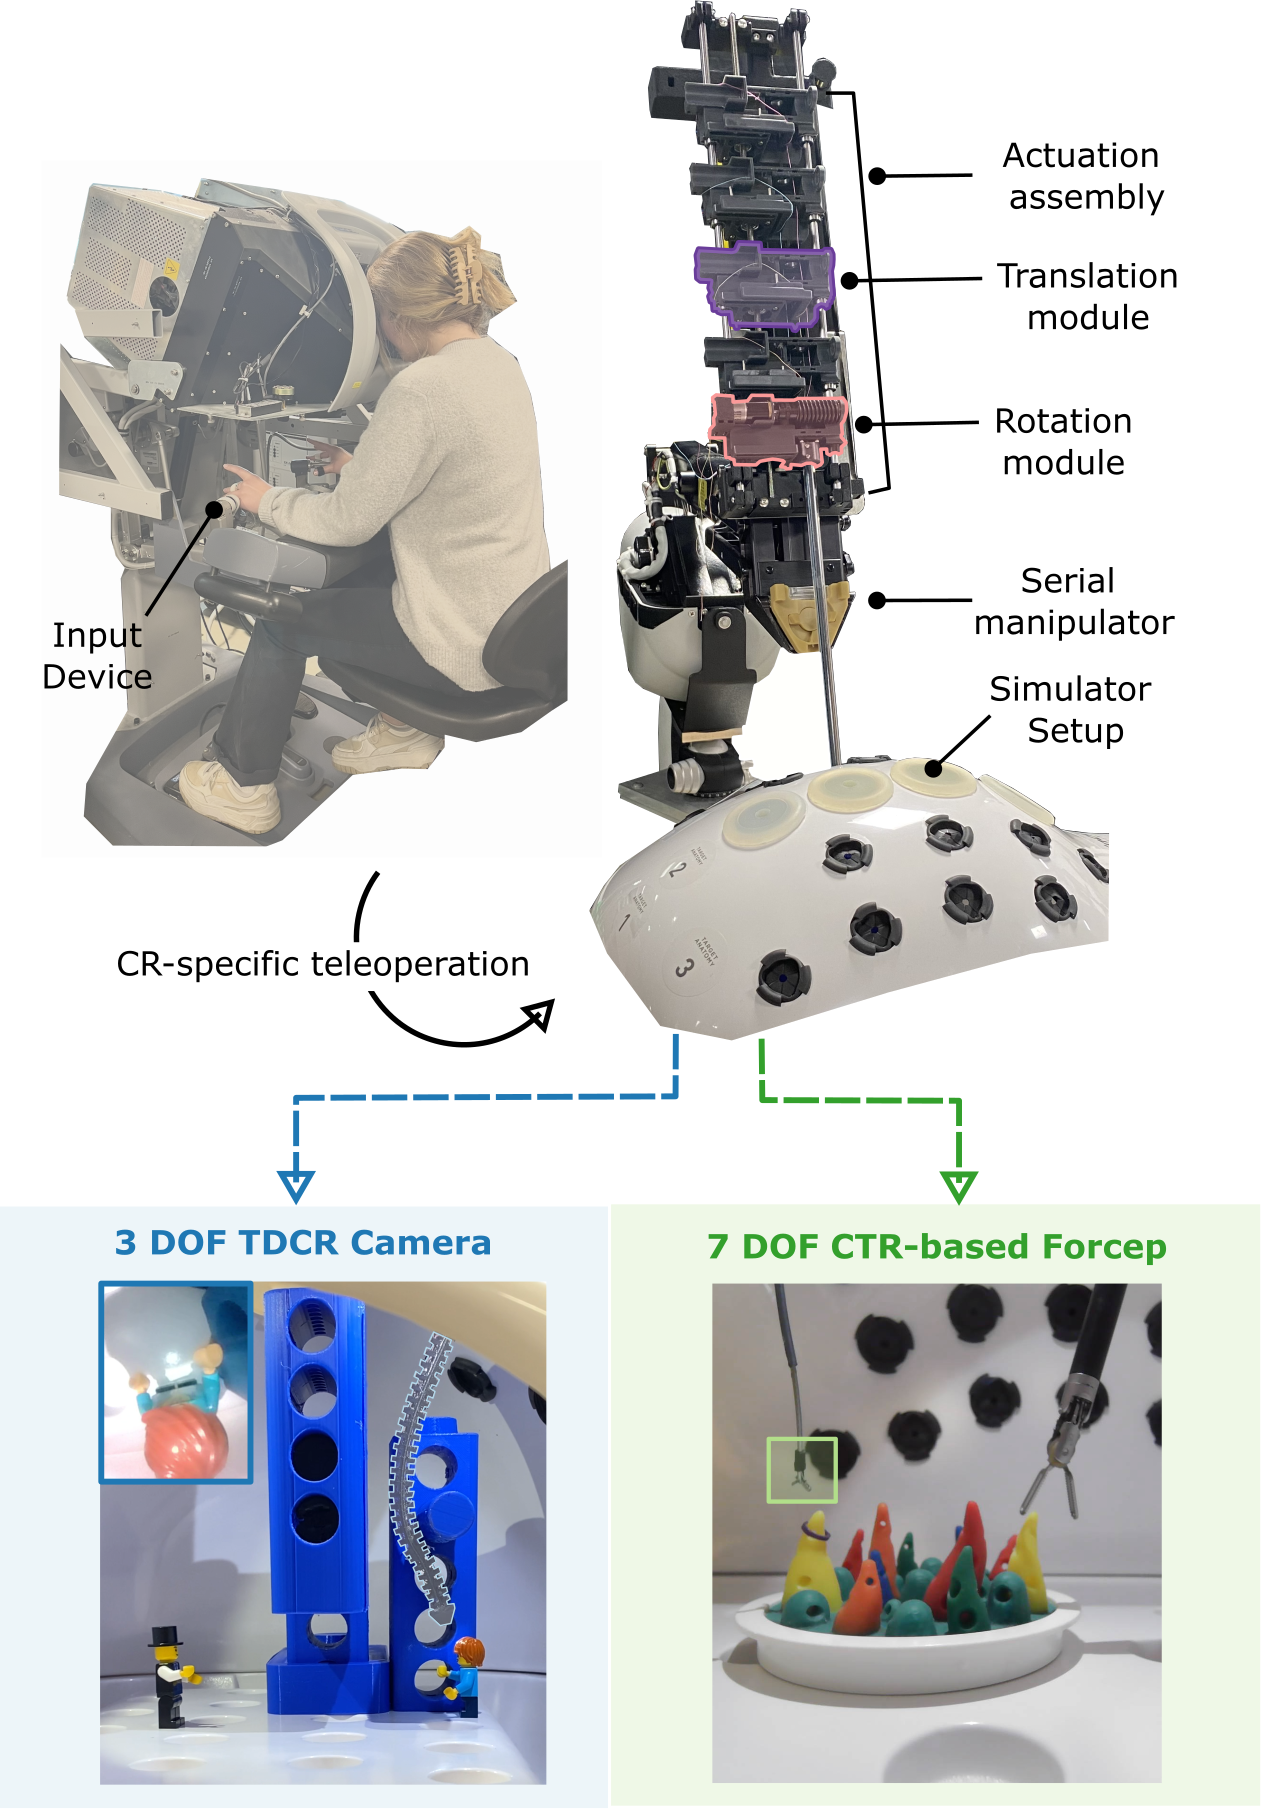
A modular platform separates actuation hardware and software from robot architecture, demonstrated through camera teleoperation and bimanual concentric-tube forceps manipulation.
- Source published
- Sources checked
- 2026-11-09
What changed
- Module characterization reports submillimetre translation accuracy over 30 mm and under 5° rotational error over 180°.
- The authors report releasing hardware designs and ROS software; module metrics are distinct from clinical tip accuracy.
Relevance to constrained-space work
Reusable modules and common interfaces support replication and comparison across continuum architectures.
Compiled by OpenRuwei editorial