 720p
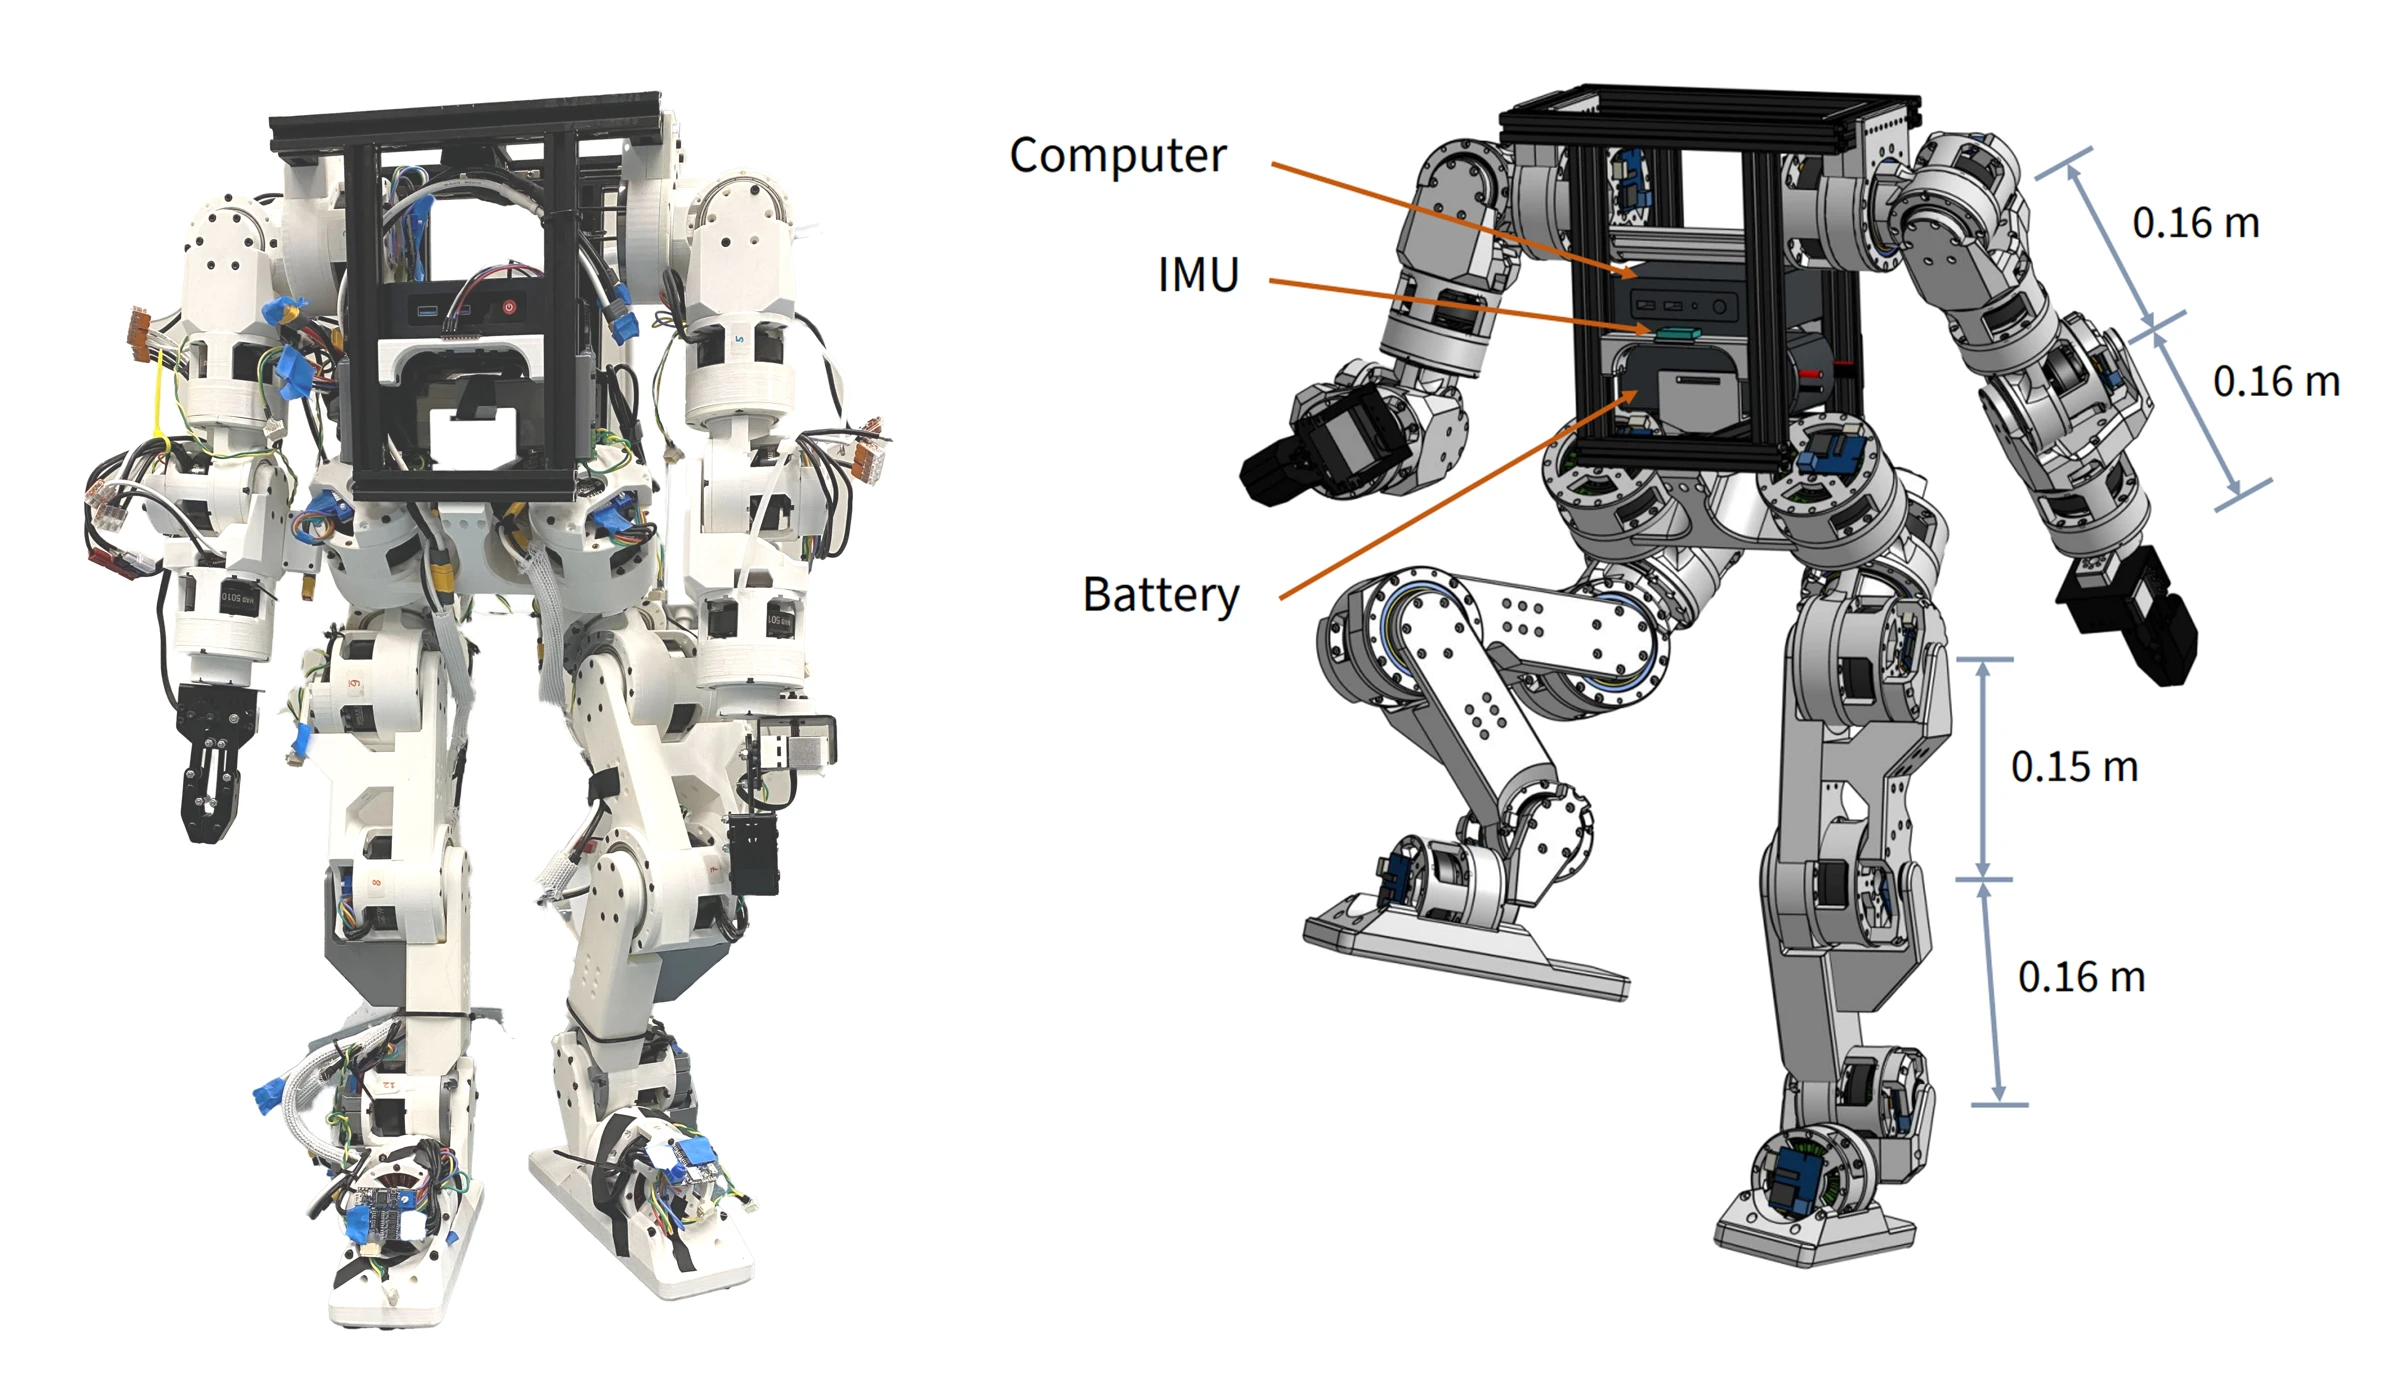
Berkeley Humanoid Lite: a reproducible humanoid platform
Open hardware and learning-based control, from 3D-printed gearboxes to arm manipulation and bipedal walking.
Research prototype and hardware experimentsRead case
Learn from data and interaction, and test policies in new conditions.
Space illustration · OPENRUWEI720pOpen hardware and learning-based control, from 3D-printed gearboxes to arm manipulation and bipedal walking.
 1080p
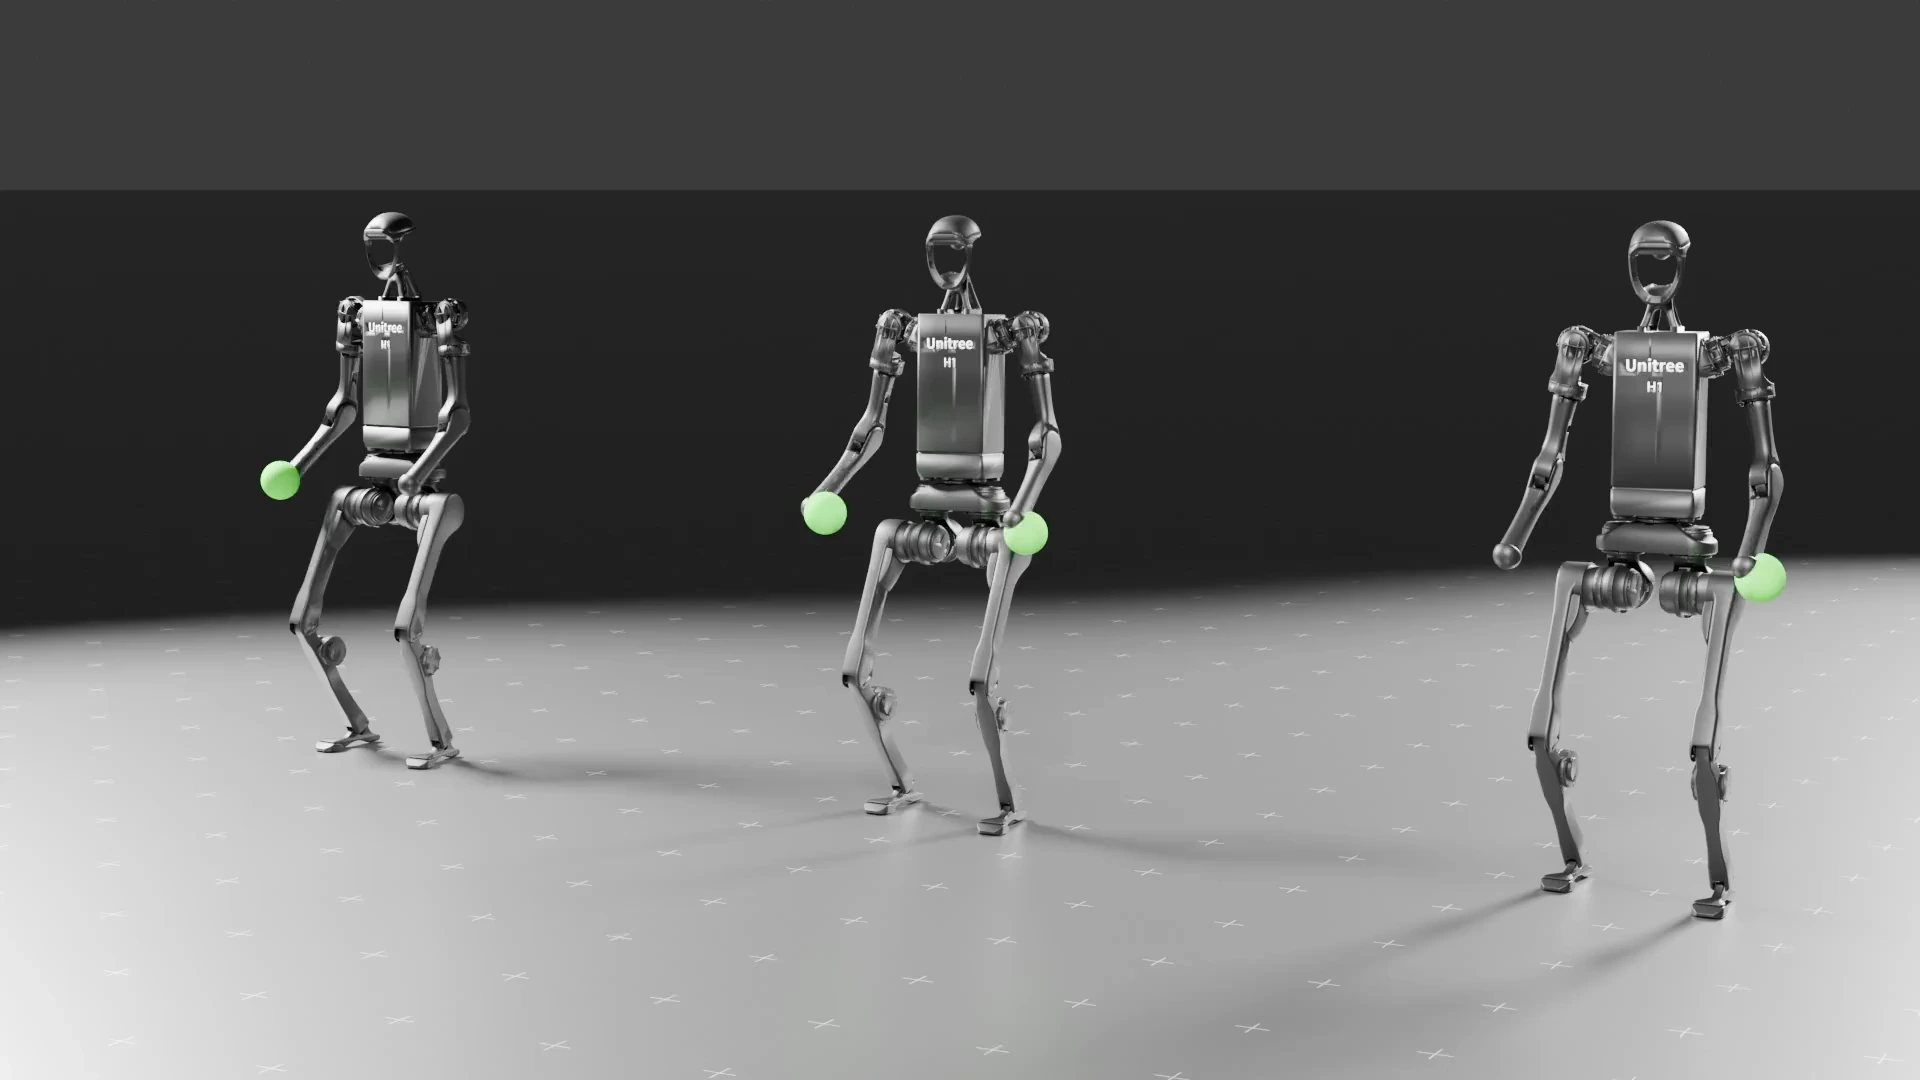
A humanoid policy tracks hand, head and root commands while coordinating upper and lower body motion.
 Video
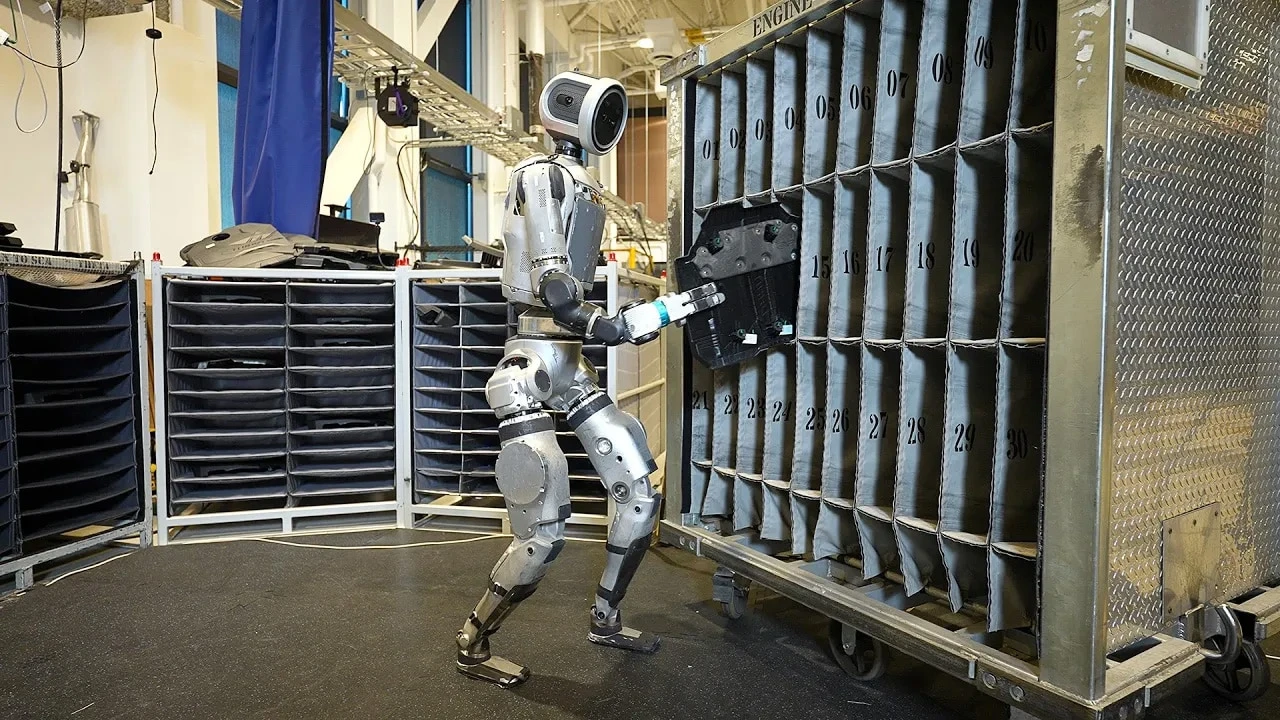
Moving parts between supplier containers and a sequencing dolly from a list of bin locations.
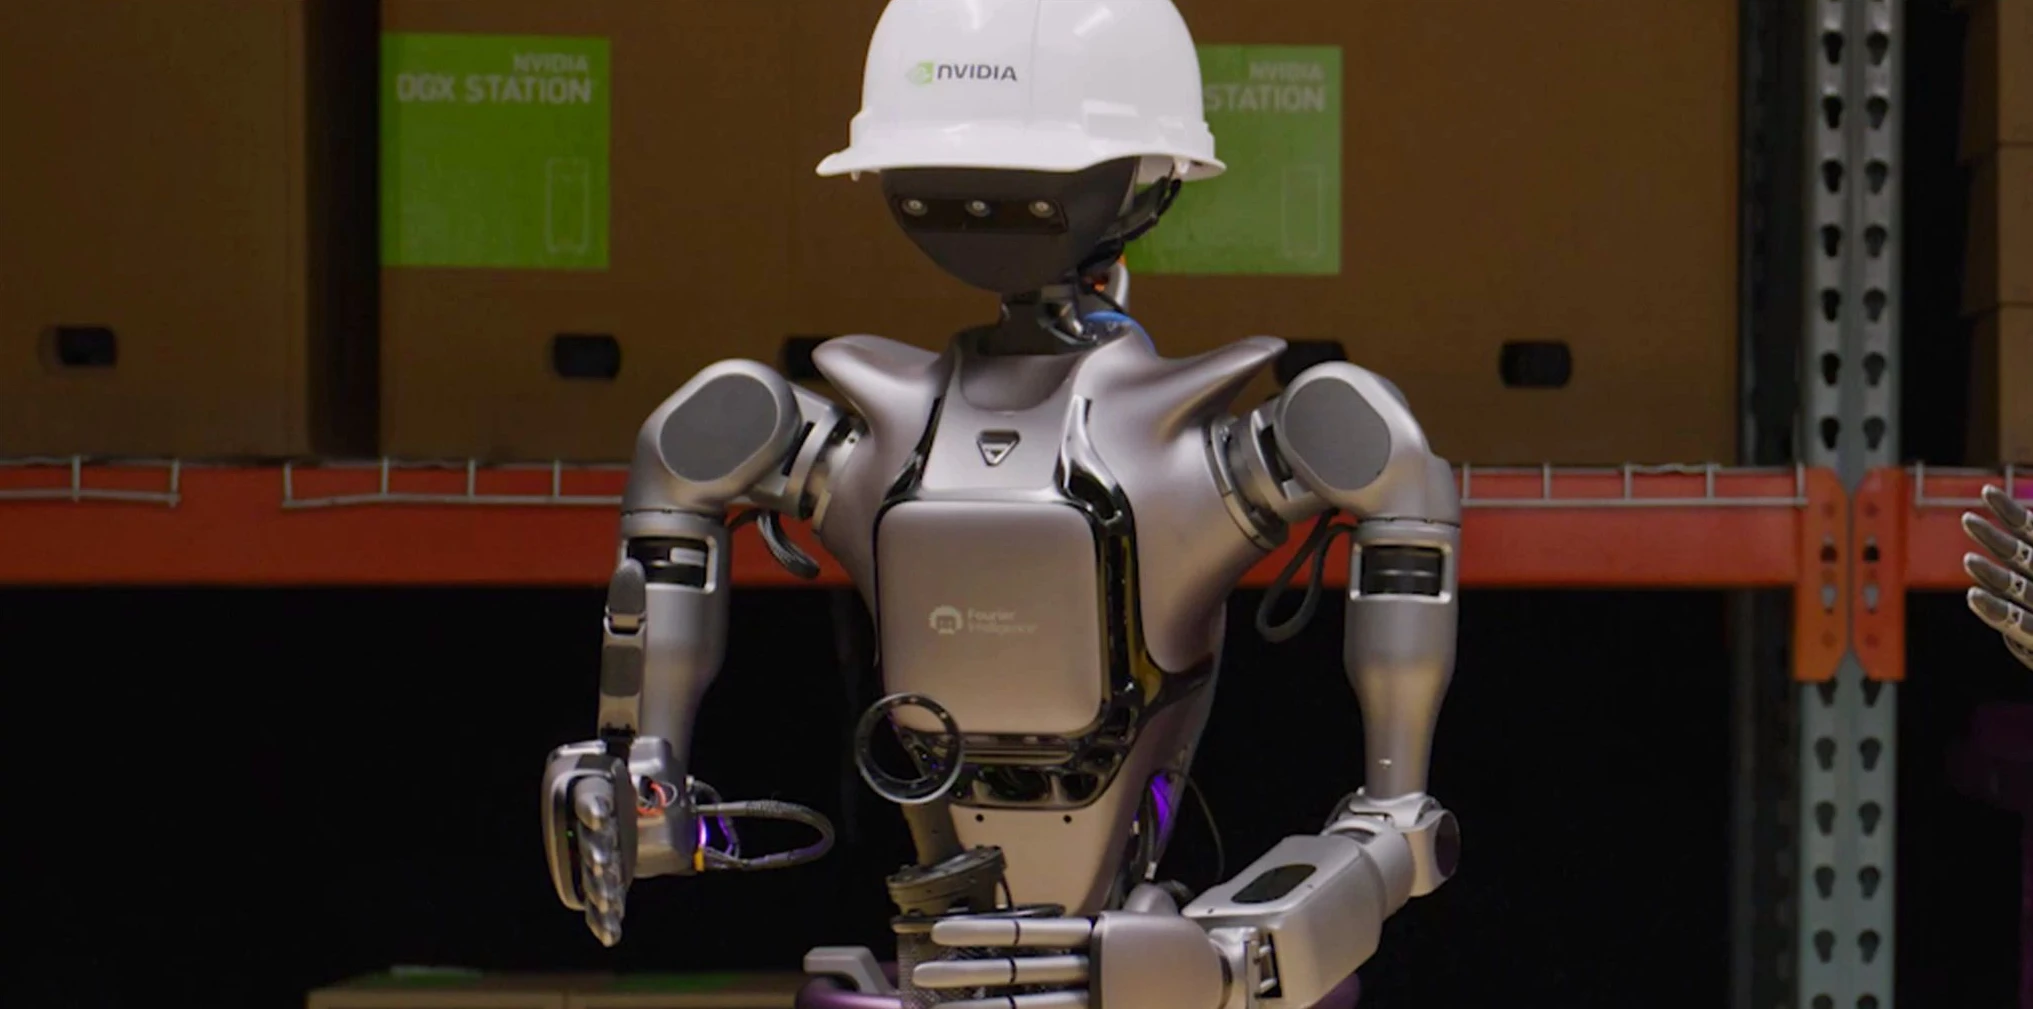
Studying pick-and-place, handovers and bimanual coordination with hardware demonstrations, simulation and task-specific adaptation.
 1080p
An official whole-body demonstration shows a robot carrying a container while moving, linking instruction understanding with execution.
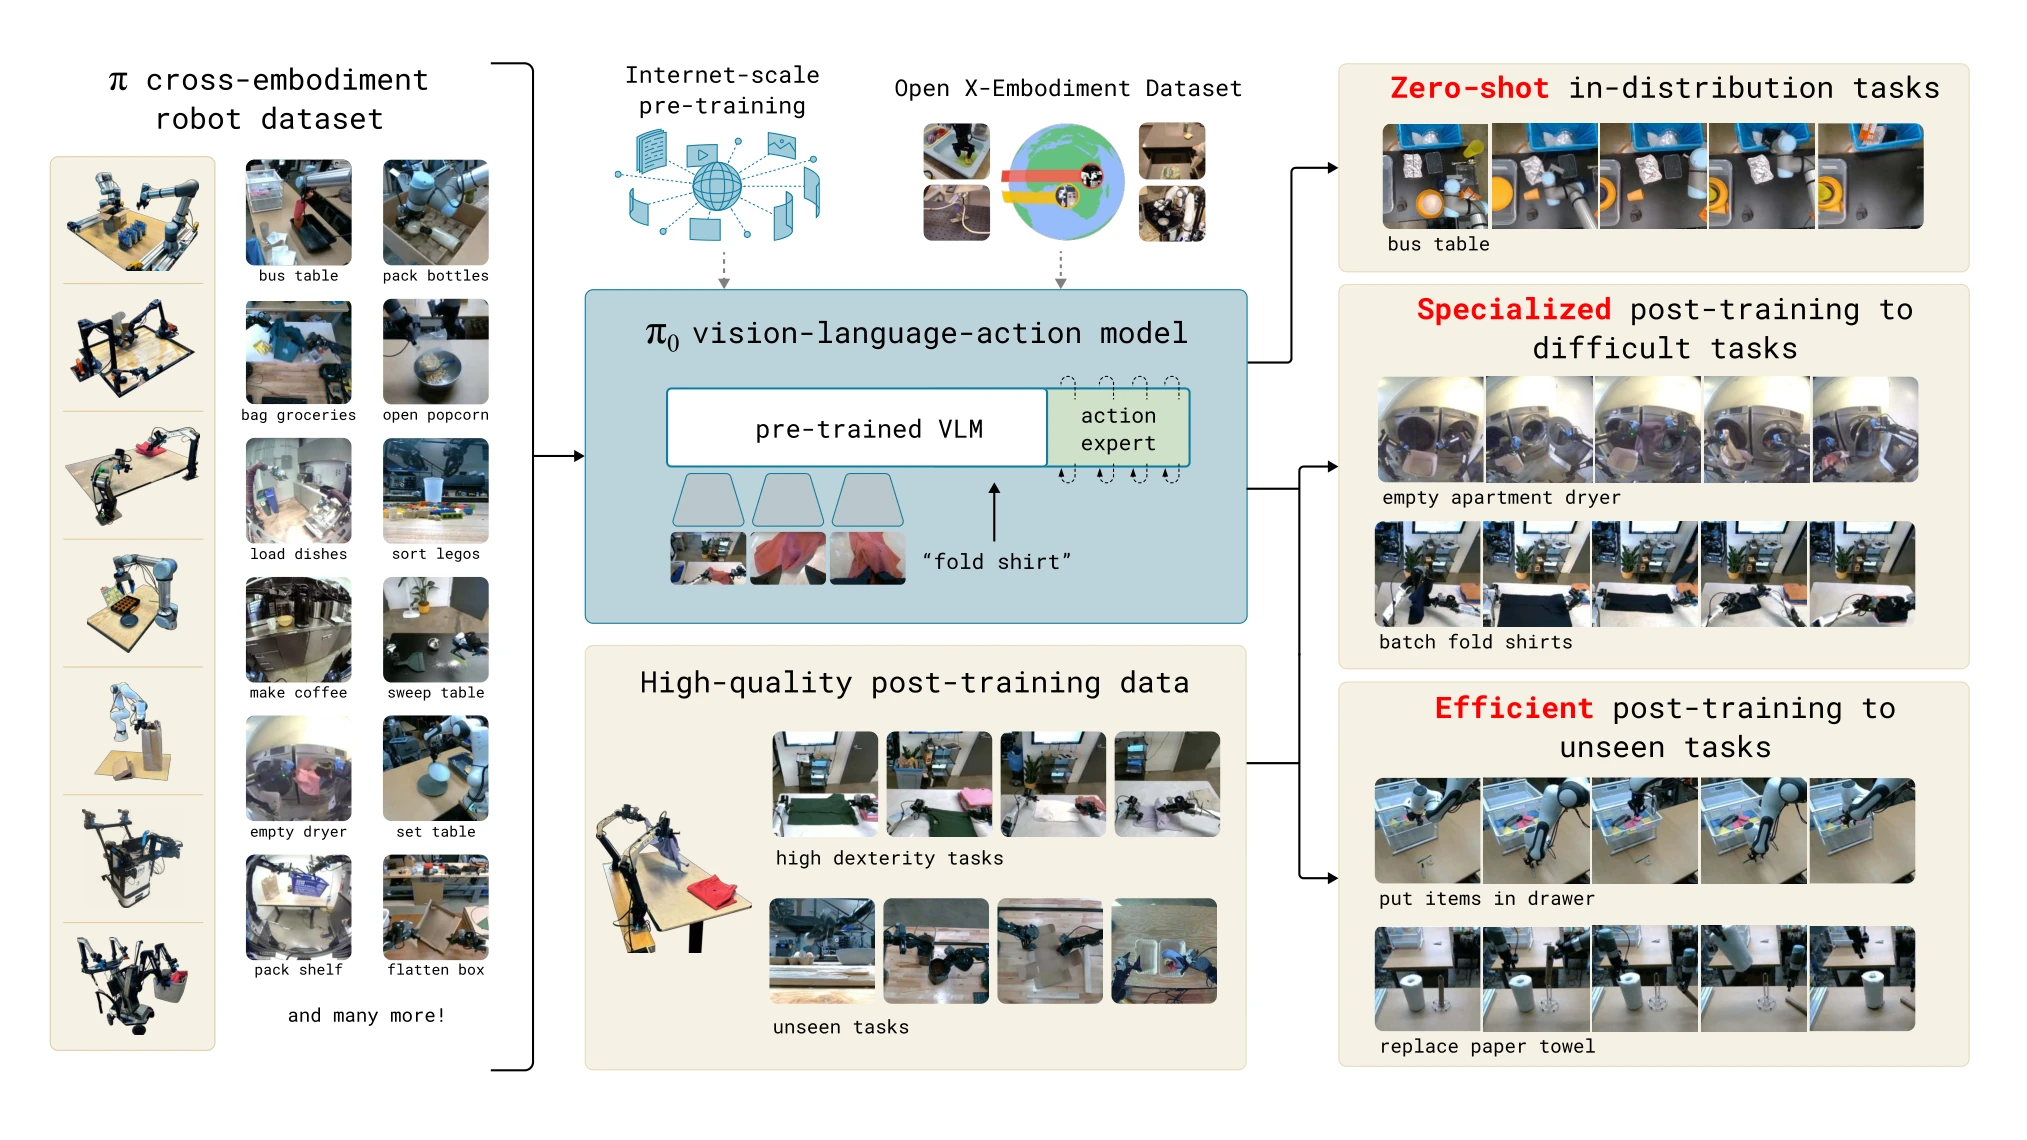
A cross-embodiment vision-language-action model studies folding laundry, clearing tables and assembling boxes.
 720p
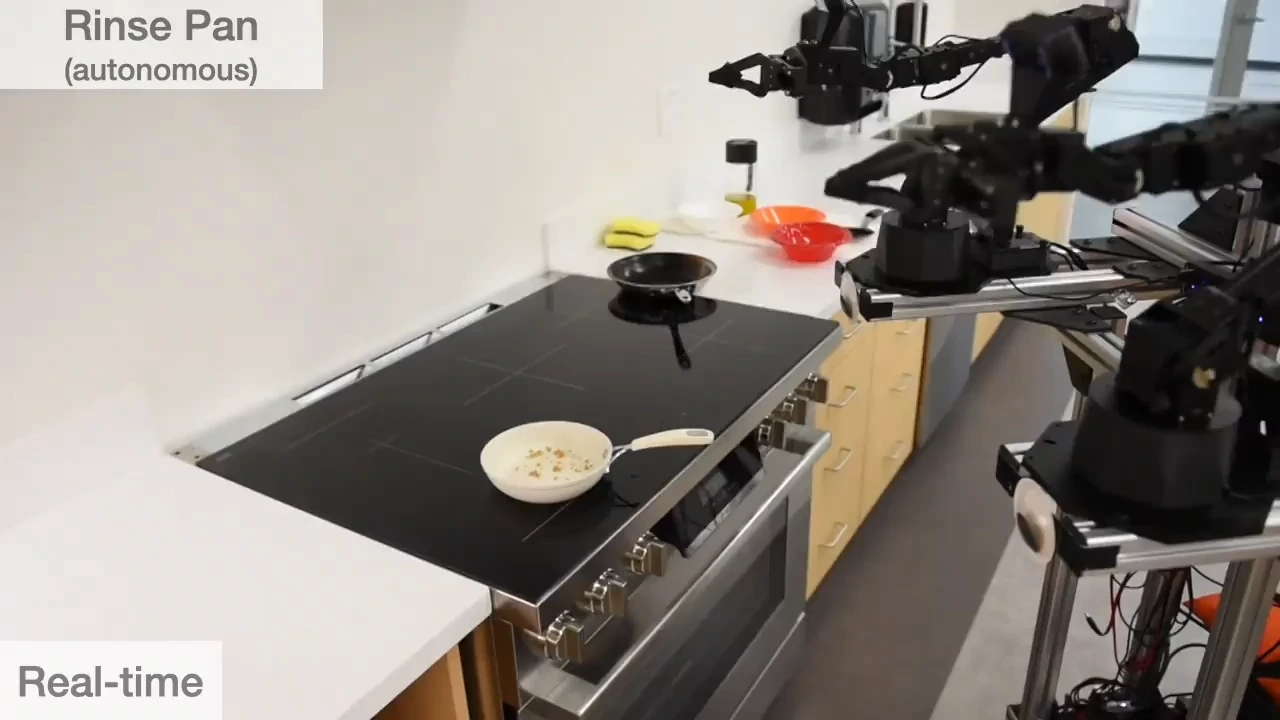
Teleoperated demonstrations support learned mobile tasks such as opening cabinets, rinsing a pan and cooking.
Working on a related study? Submit a project with its objectives, progress and resource access.
Visit community projects ↗