Research directions & topics
Explore crawling, snake, quadruped and humanoid robotics, embodied intelligence and physical AI.
Research directions & topics
Browse by technical question, or start with a robot and its task.
TECHNICAL DIRECTIONS
01Mechanisms & actuation
Structure, actuation and load transmission.
Perception & localisation
Observe the environment and estimate shape, position and contact.
Planning & control
Choose feasible paths, coordinate motion and respond to feedback.
Contact & manipulation
Adhesion, friction, force feedback and tool interaction.
Learning & adaptation
Learn from data and interaction, and test policies in new conditions.
ROBOTS & TASKS
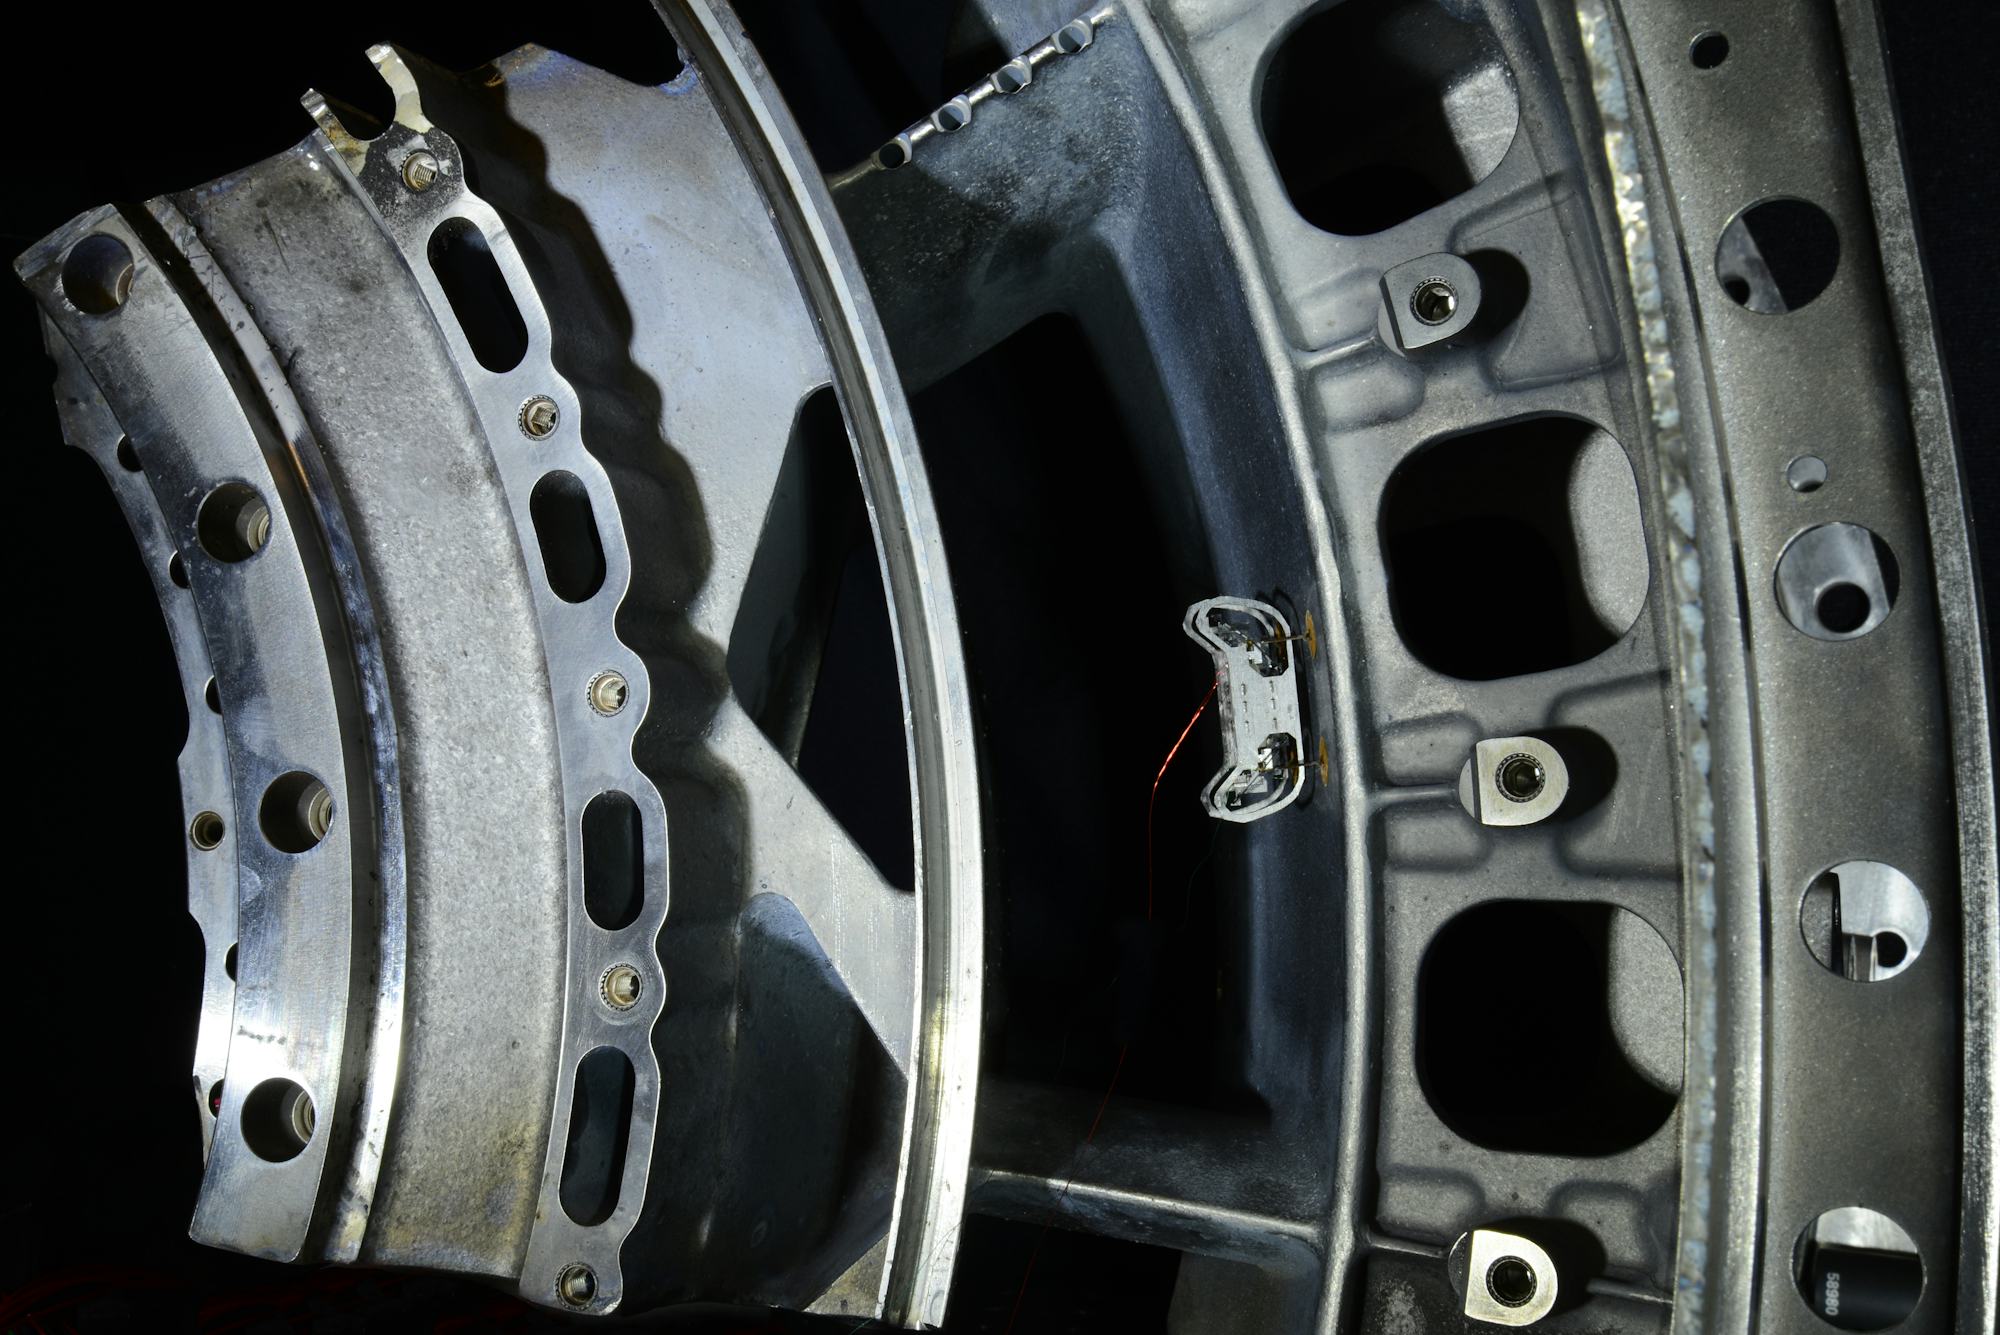
Crawling & climbing
Adhesion, locomotion and tools on engine walls and spacecraft surfaces.
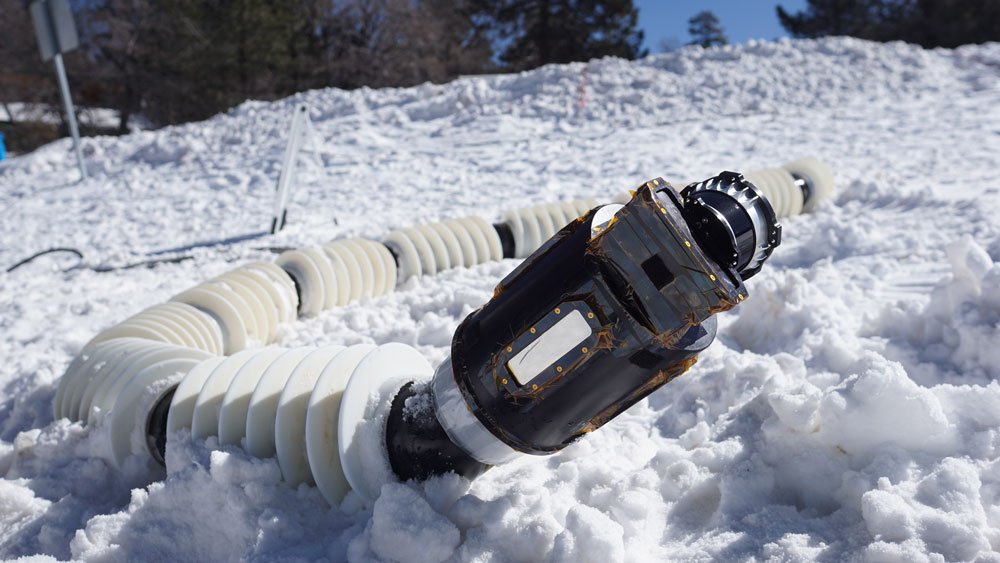
Snake & continuum
Navigate winding paths to observe and manipulate within limited space.
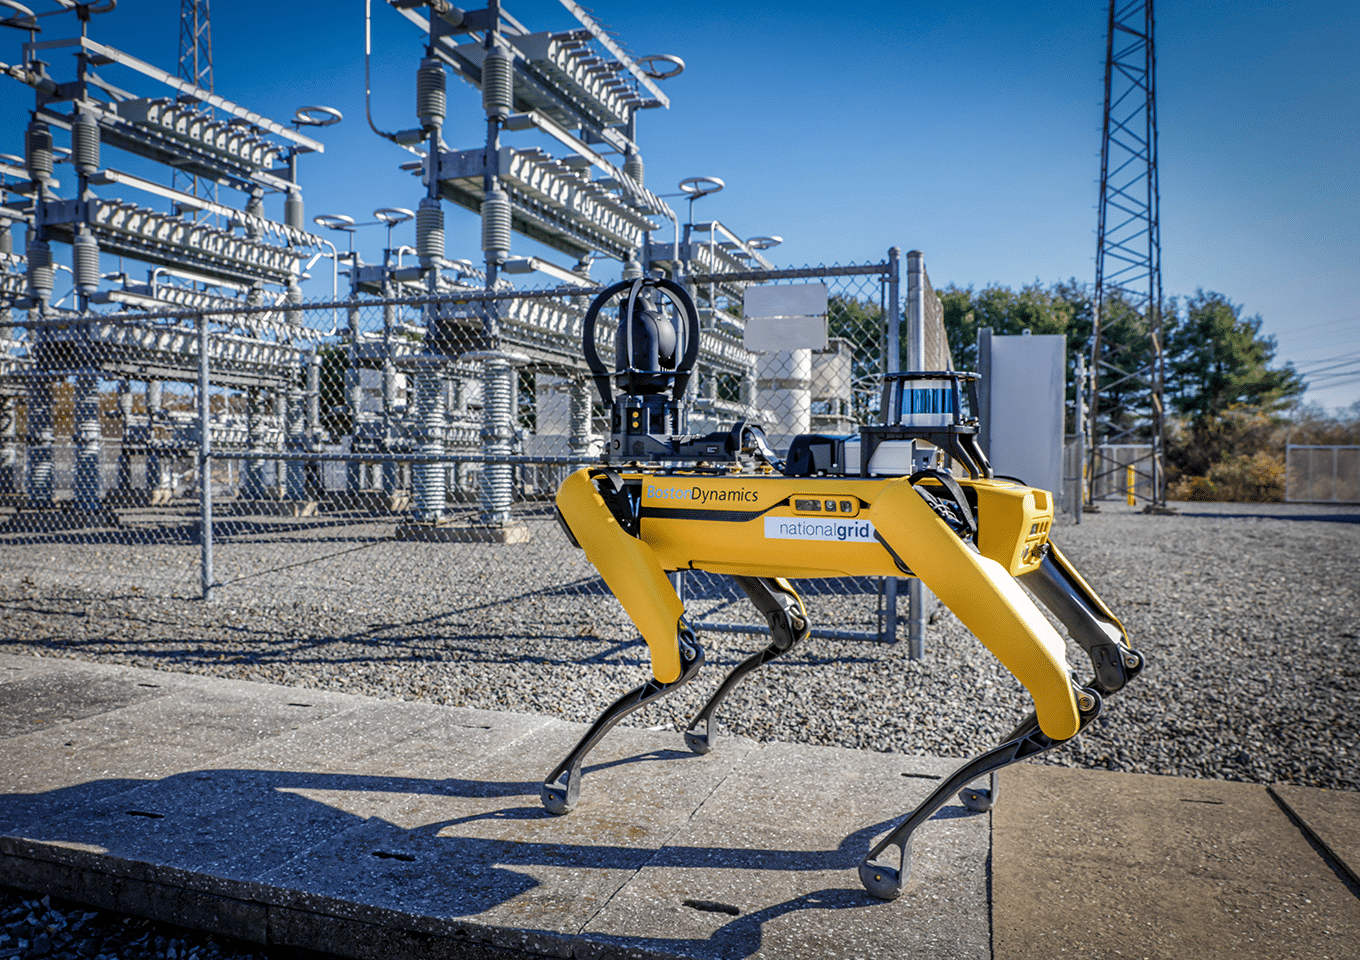
Quadrupeds & inspection
Cross stairs, grating and equipment passages to inspect industrial assets.
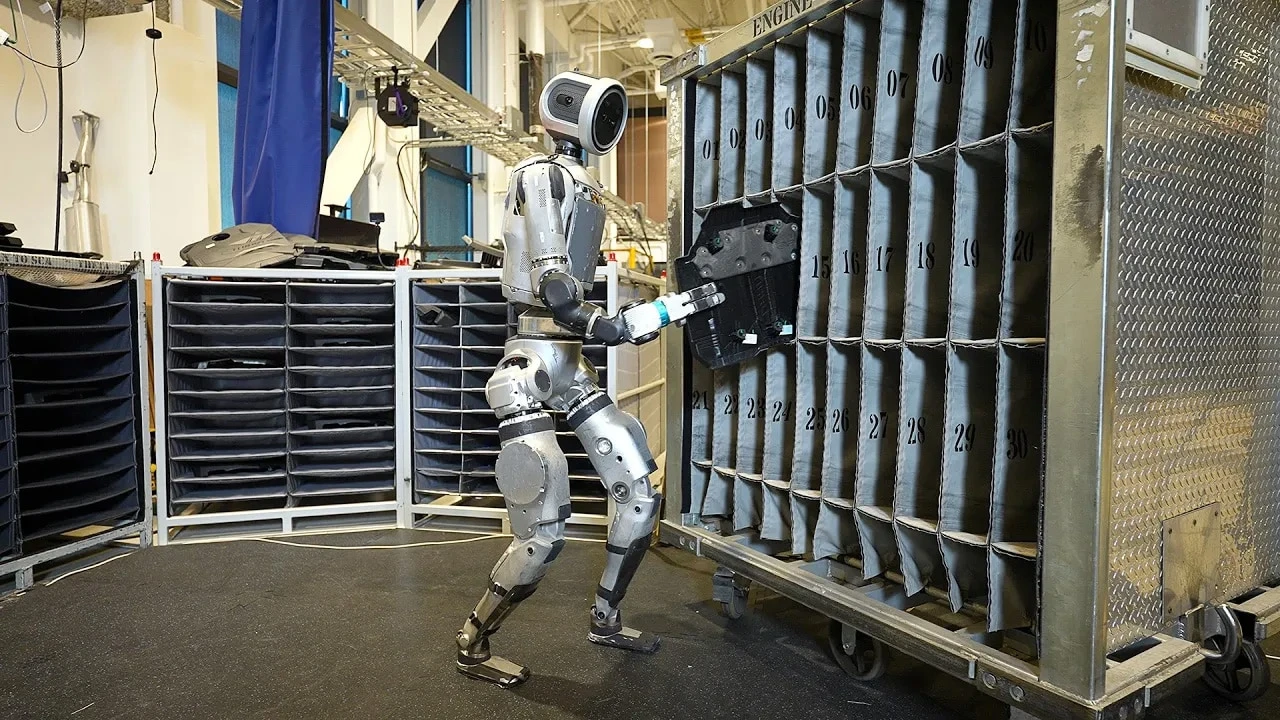
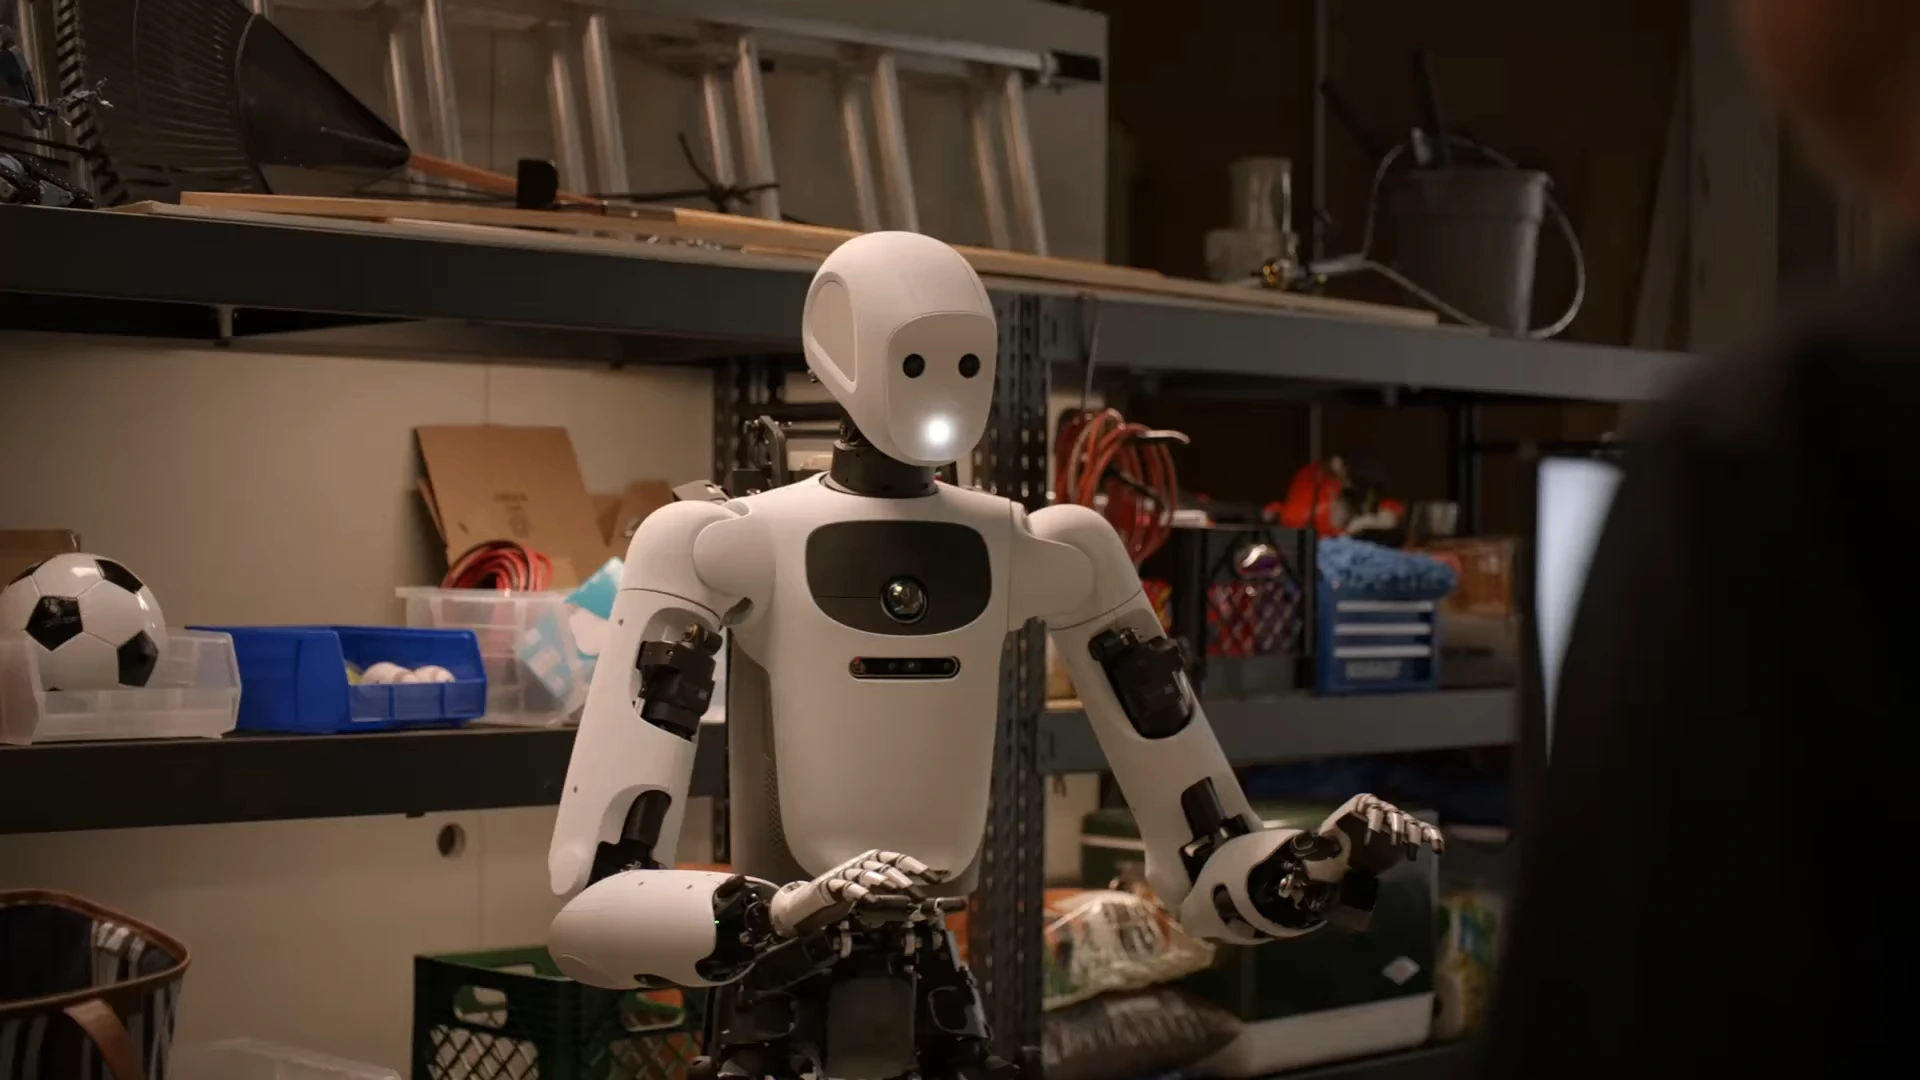
Humanoid robotics
From open hardware and whole-body control to bimanual manipulation and action models.
LEARNING & SIMULATION
Embodied intelligence & physical AI
Study how robots learn from demonstrations, language and interaction, alongside the data and code.