 1080p
Gemini Robotics: coordinating whole-body movement
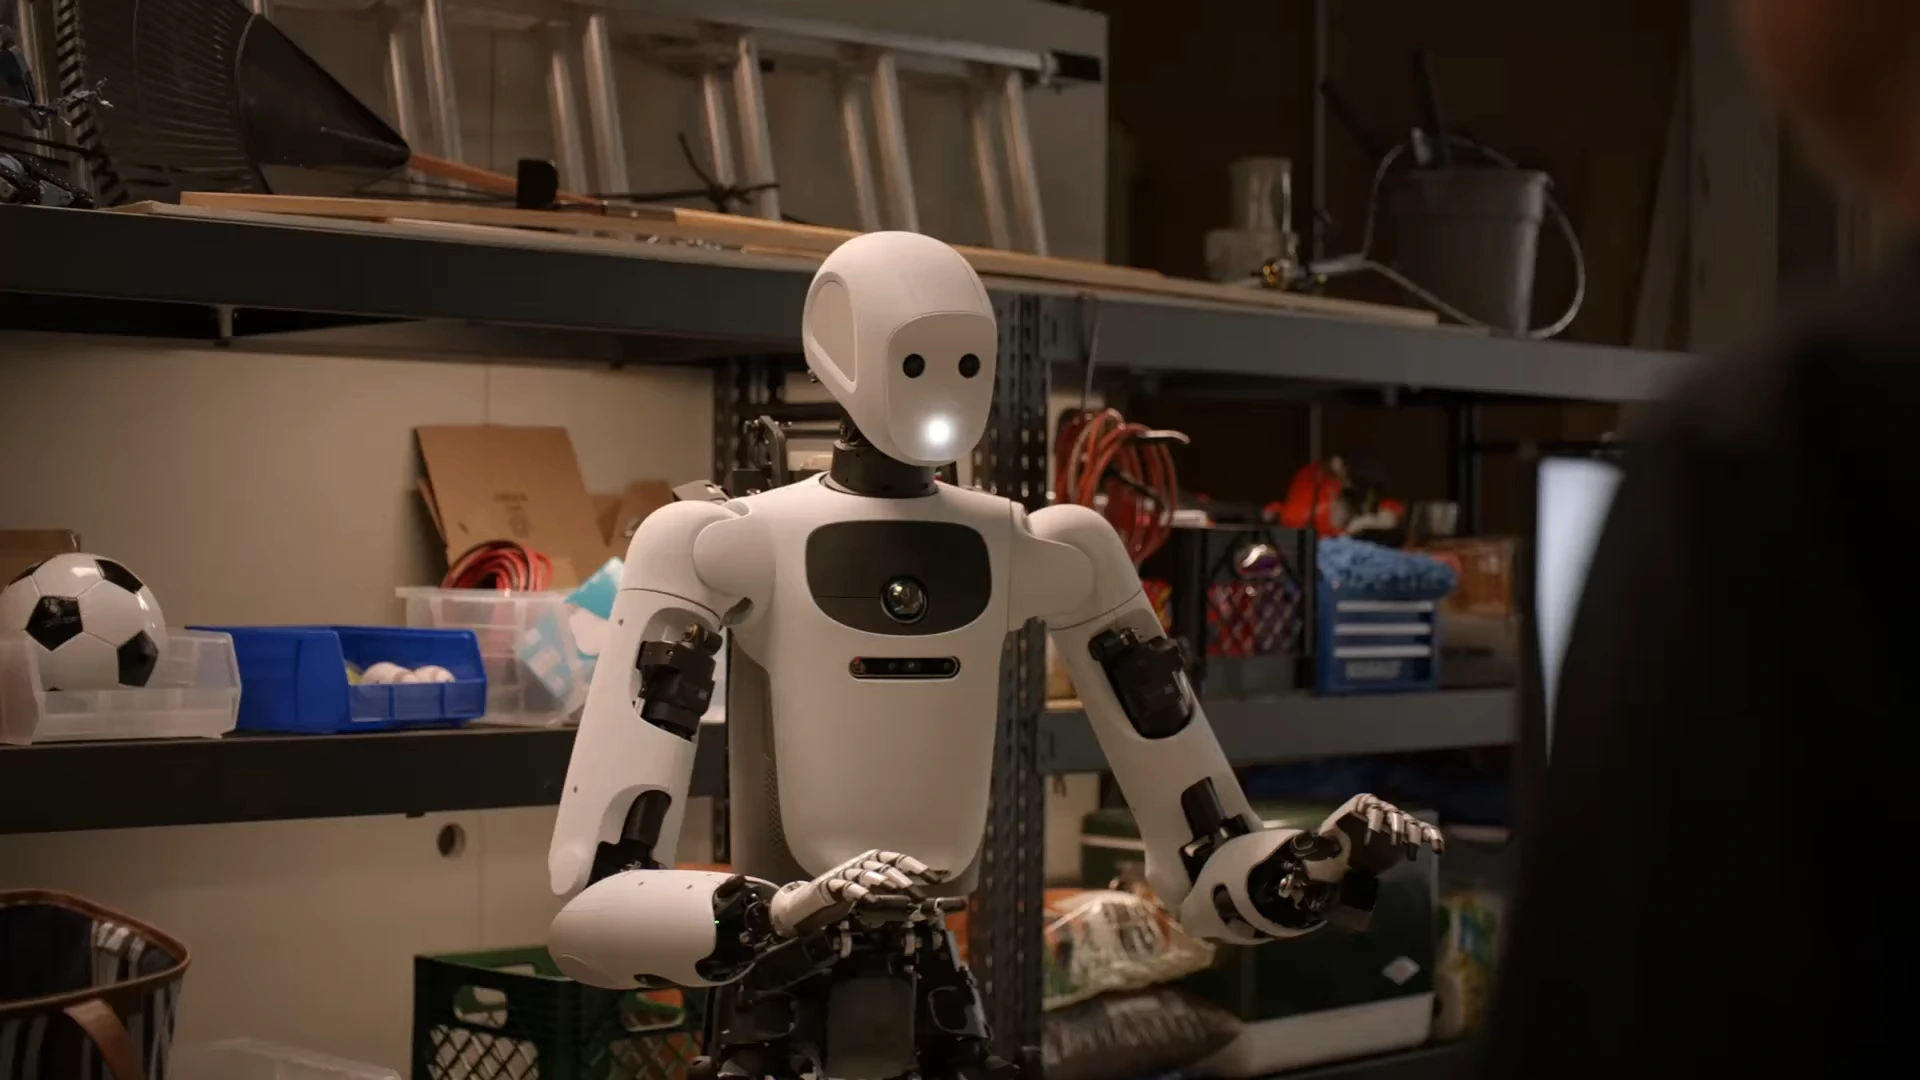
An official whole-body demonstration shows a robot carrying a container while moving, linking instruction understanding with execution.
Official model demonstrationRead case
Study how robots learn from demonstrations, language and interaction, alongside the data and code.
Google DeepMind · official video frameFollow the path from demonstration collection to policy execution on specific robots and tasks. Cases distinguish autonomy, teleoperation and simulated results.
1080pAn official whole-body demonstration shows a robot carrying a container while moving, linking instruction understanding with execution.
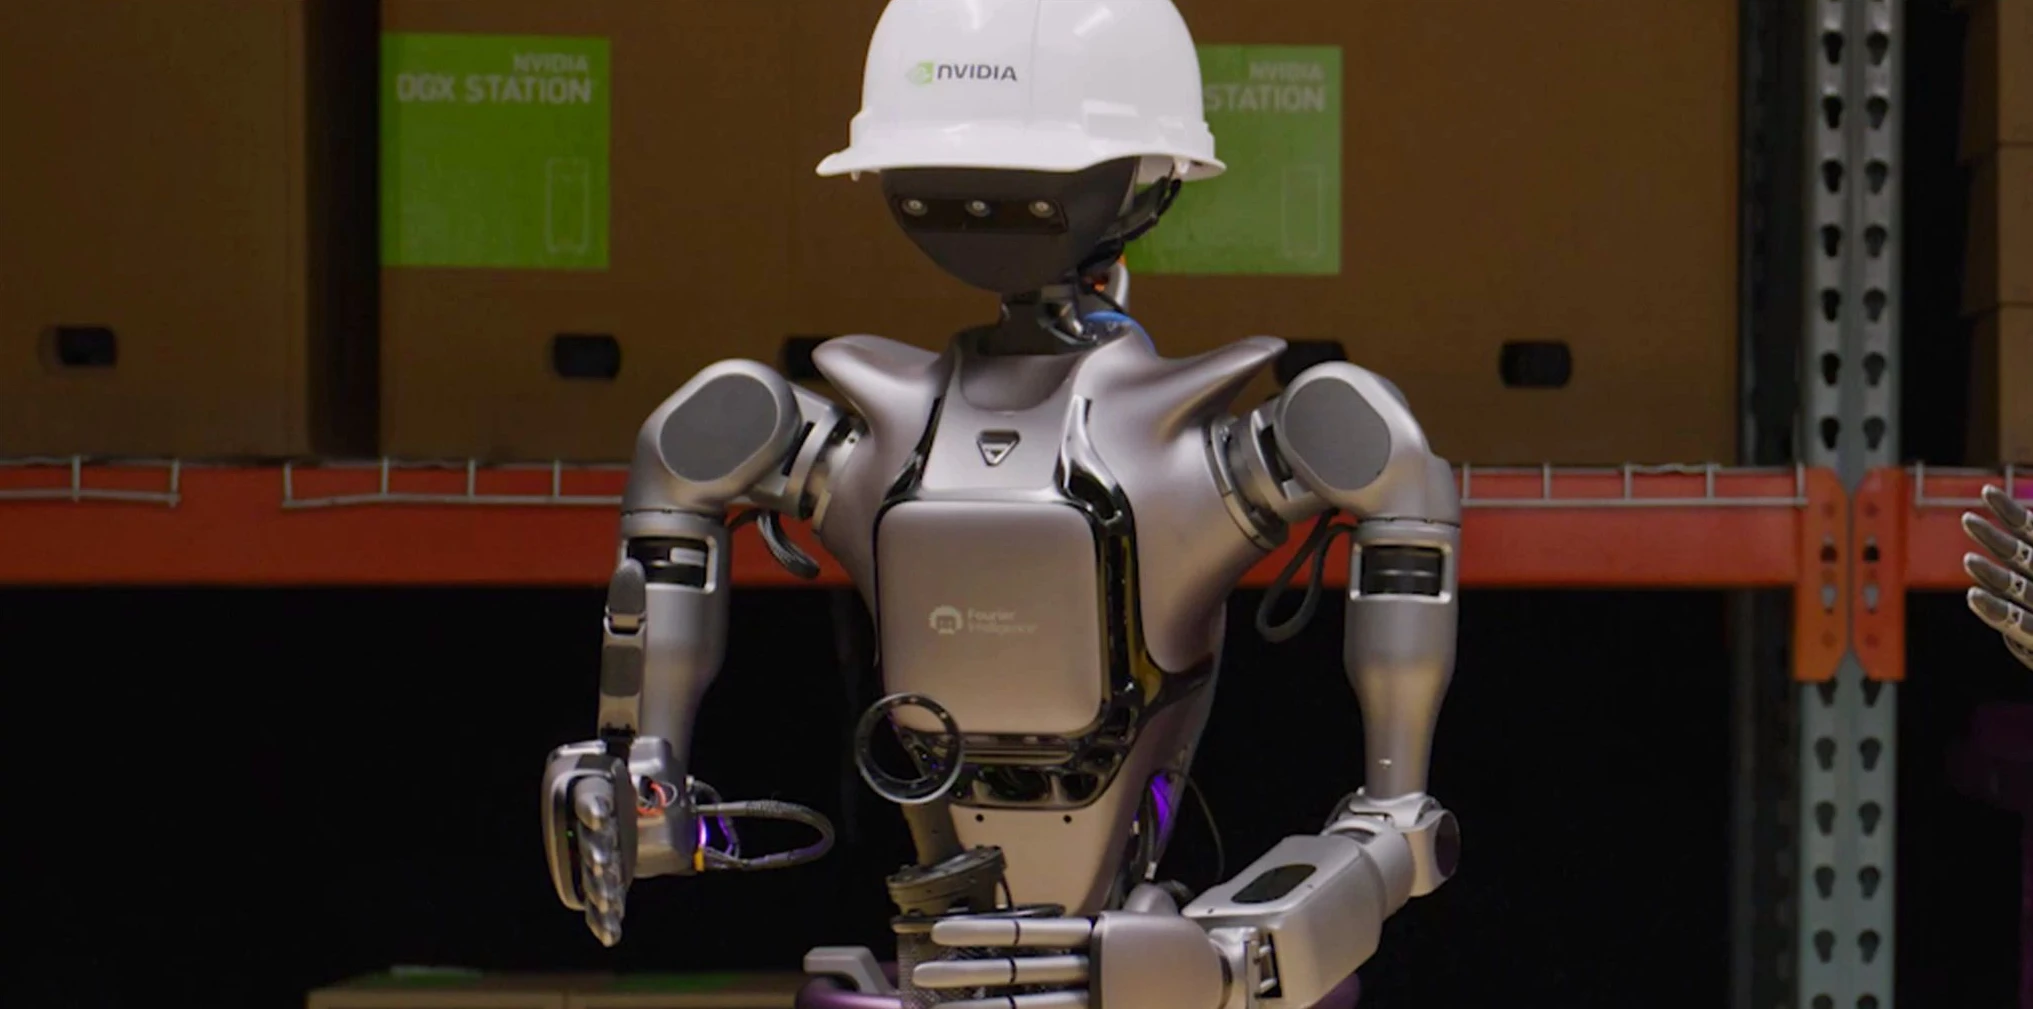
Studying pick-and-place, handovers and bimanual coordination with hardware demonstrations, simulation and task-specific adaptation.
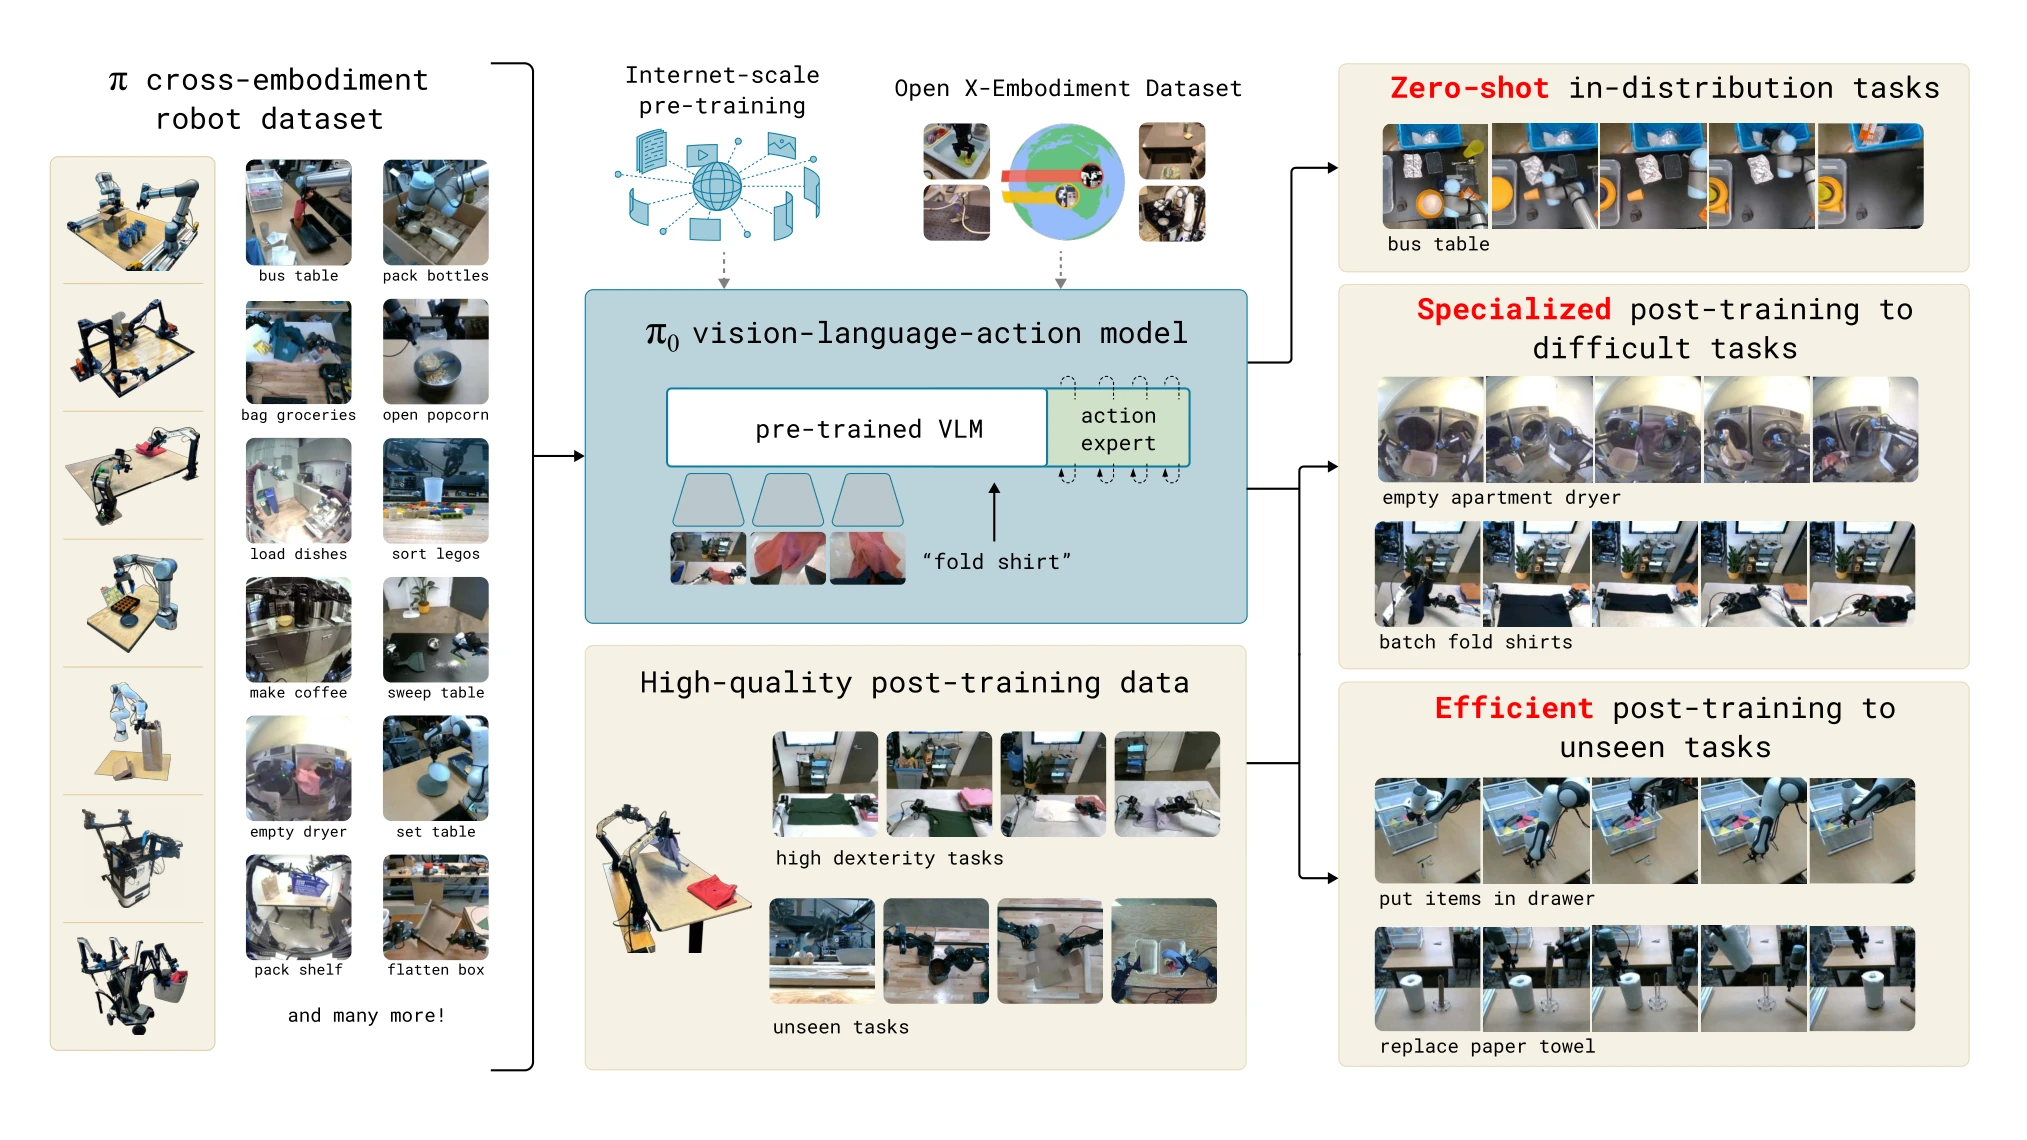
A cross-embodiment vision-language-action model studies folding laundry, clearing tables and assembling boxes.
 720p
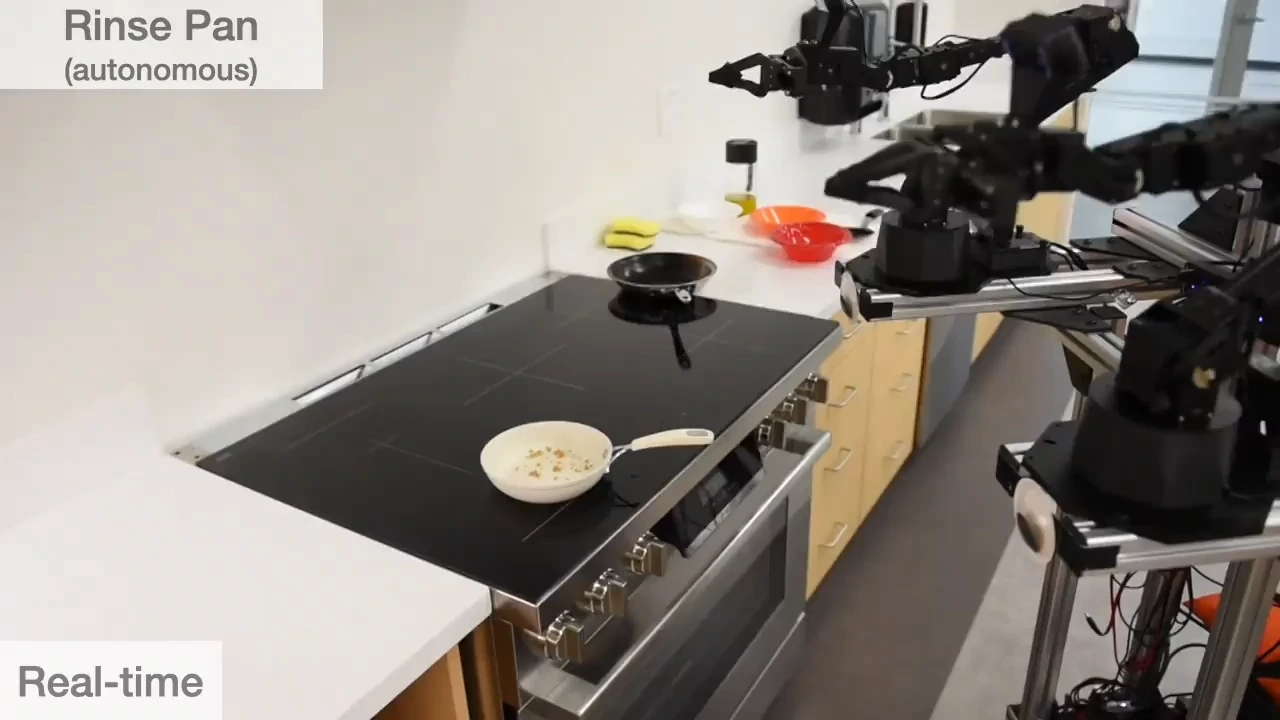
Teleoperated demonstrations support learned mobile tasks such as opening cabinets, rinsing a pan and cooking.
 1080p
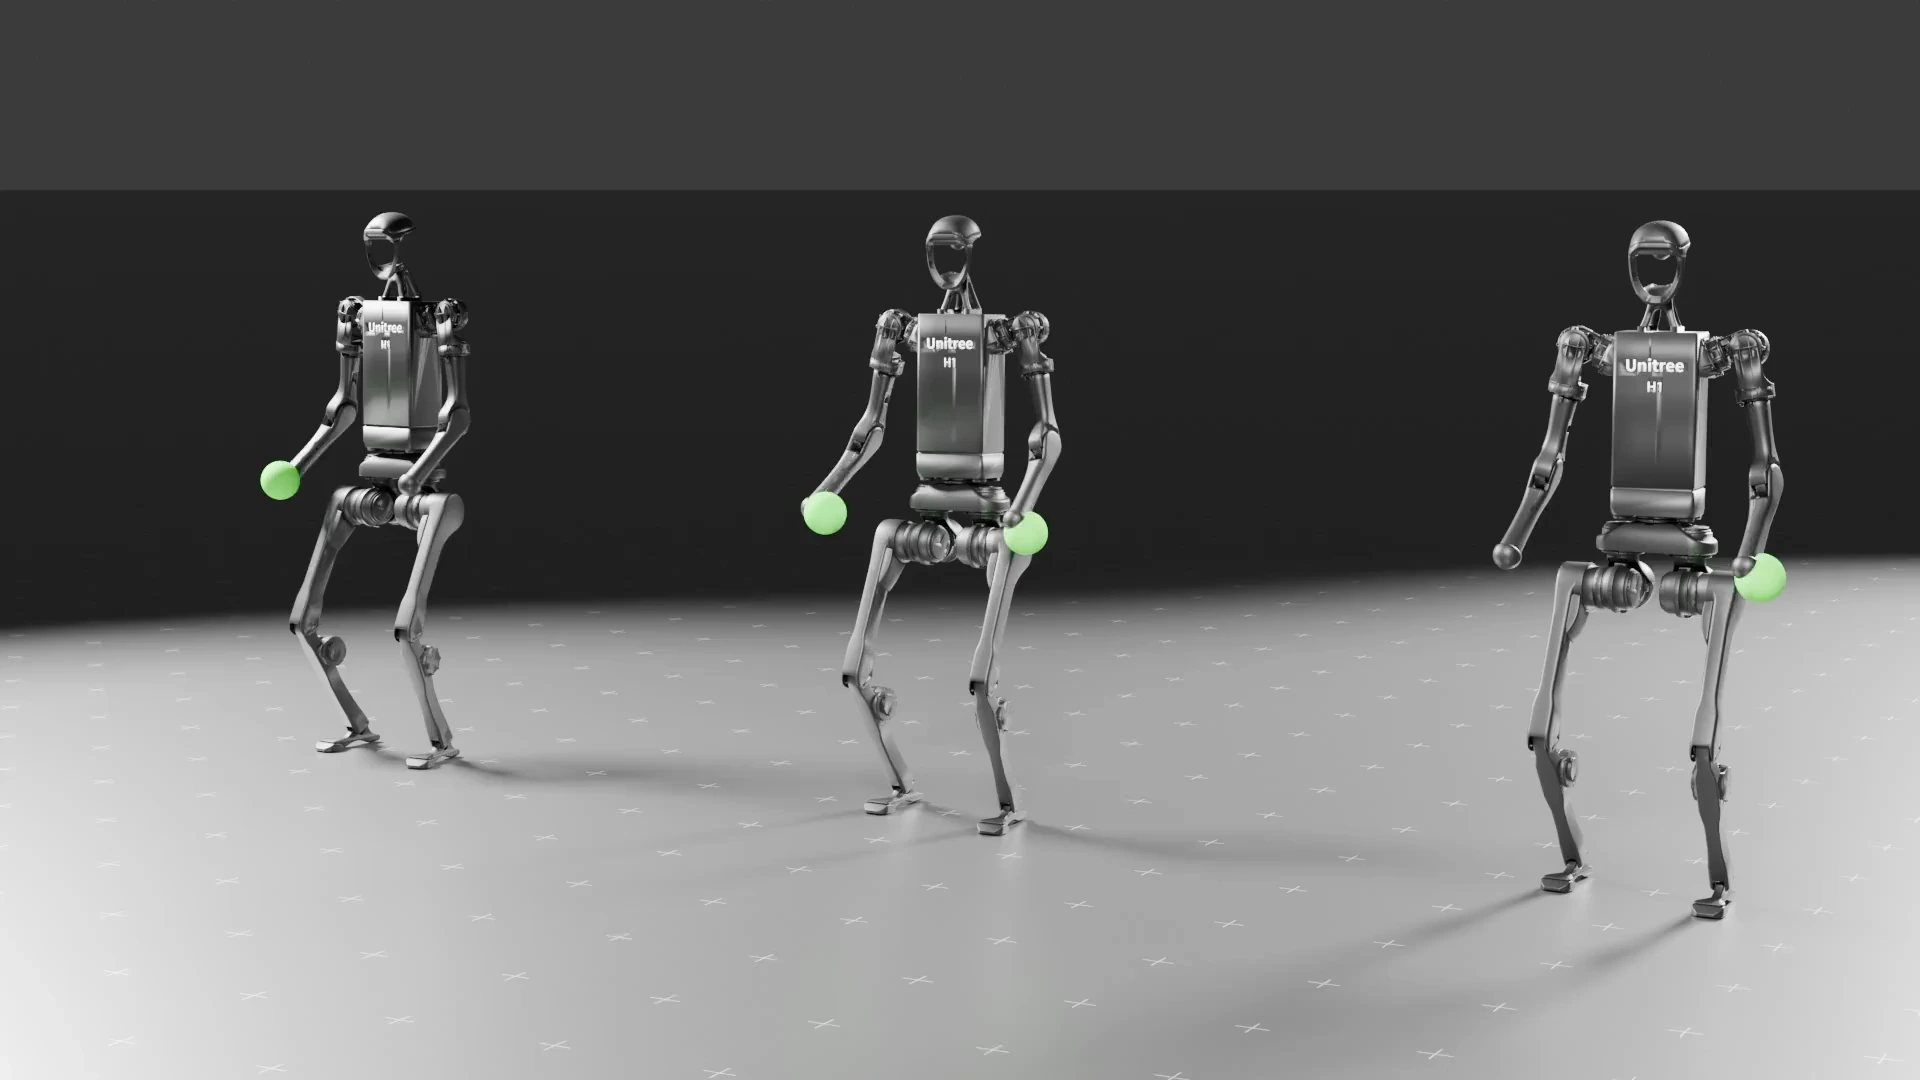
A humanoid policy tracks hand, head and root commands while coordinating upper and lower body motion.
 Video
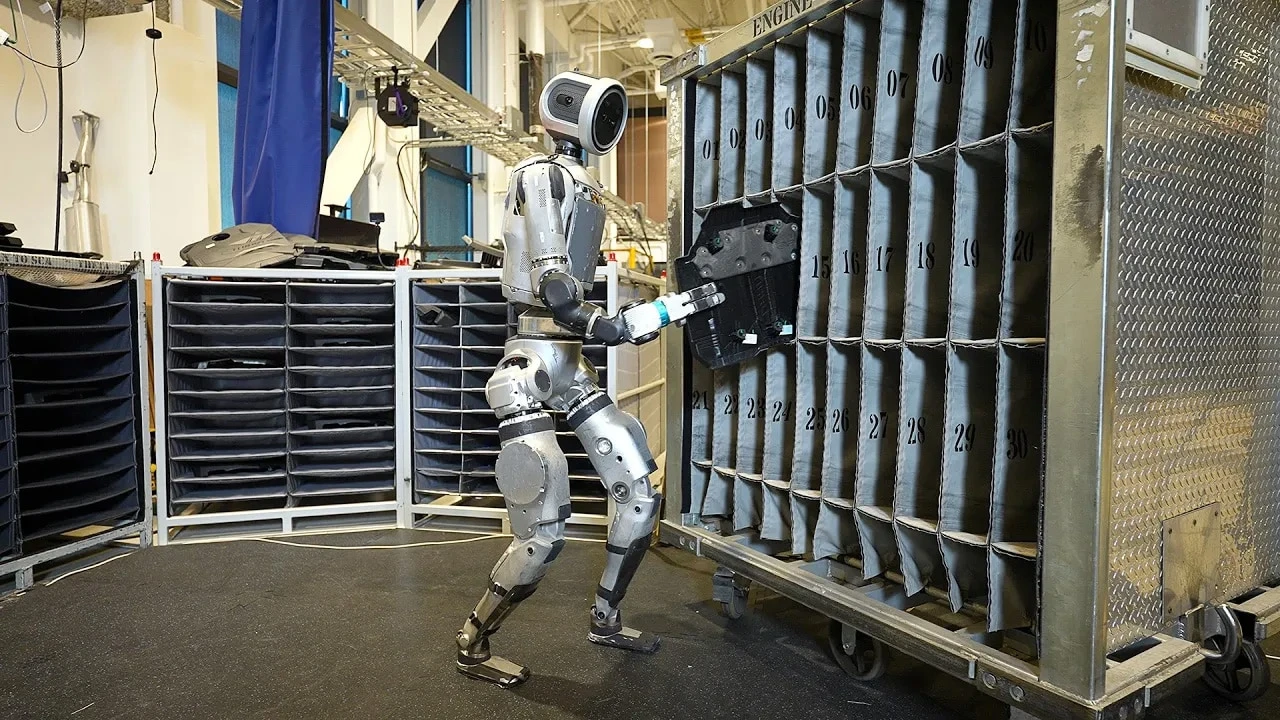
Moving parts between supplier containers and a sequencing dolly from a list of bin locations.
 1080p
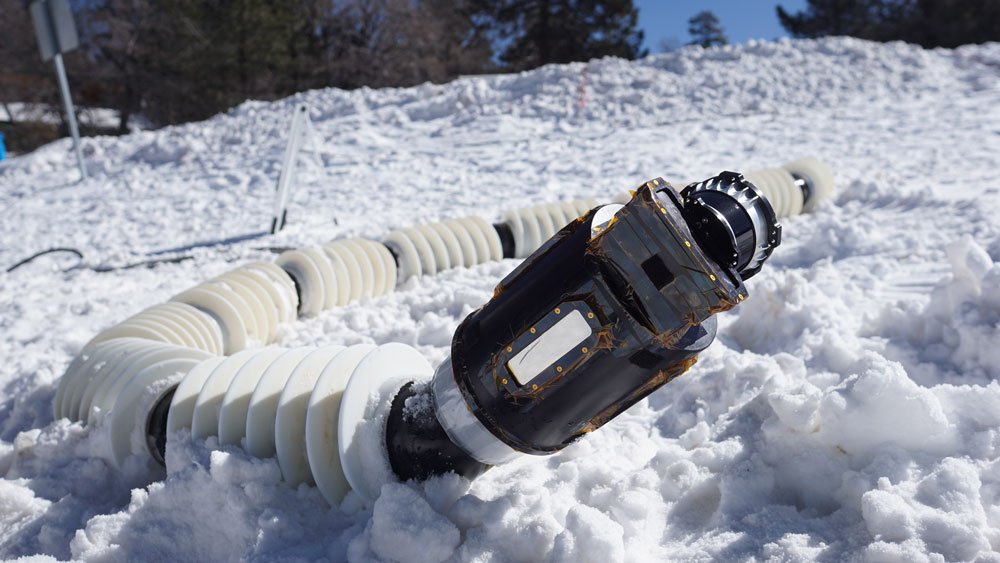
A segmented robot combines rotating screw propulsion with environmental mapping in ground tests on ice, snow, sand and glacier passages.
 540p
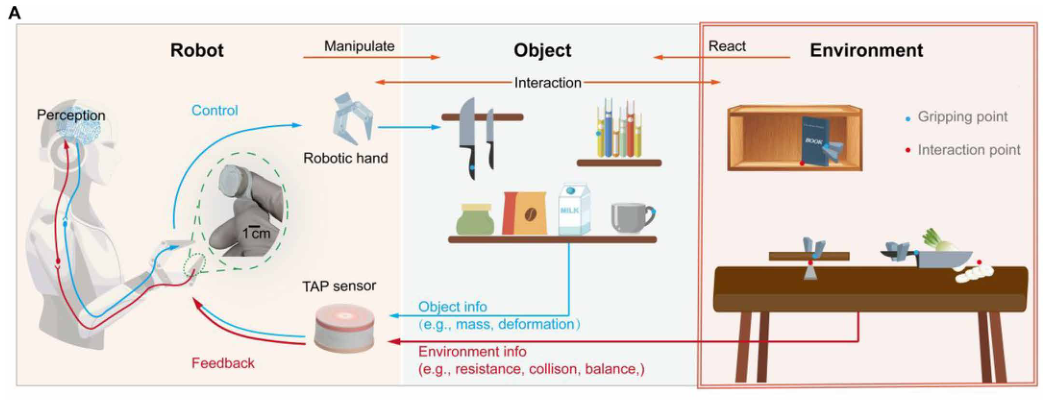
Combined tactile measurements provide contact-state feedback for placement, stacking and cutting experiments without vision.
Field-record noteEELS brings locomotion, mapping and risk assessment into a single exploration task.
 Methods discussion
Start with control, perception and data, then examine access to a specific space.
Robot policies, world models and embodied reasoning serve different roles. This index includes open resources and official model records, with access and disclosure stated for each. Task capability must be assessed with the robot and experimental conditions.
Browse Learning & adaptation ↗Working on a related study? Submit a project with its objectives, progress and resource access.
Visit community projects ↗