Skip to content
入微OPENRUWEI
HomeApplicationsCasesProjectsJournalResourcesAboutContribute ↗
中文
CASE GALLERY / 02

Case library

Robots in equipment, body passages, exploration sites, industrial facilities and orbital servicing.

37cases
28 videos
Task fields & general capabilities
Technical direction
OPENRUWEI / PUBLIC CASES

Case list

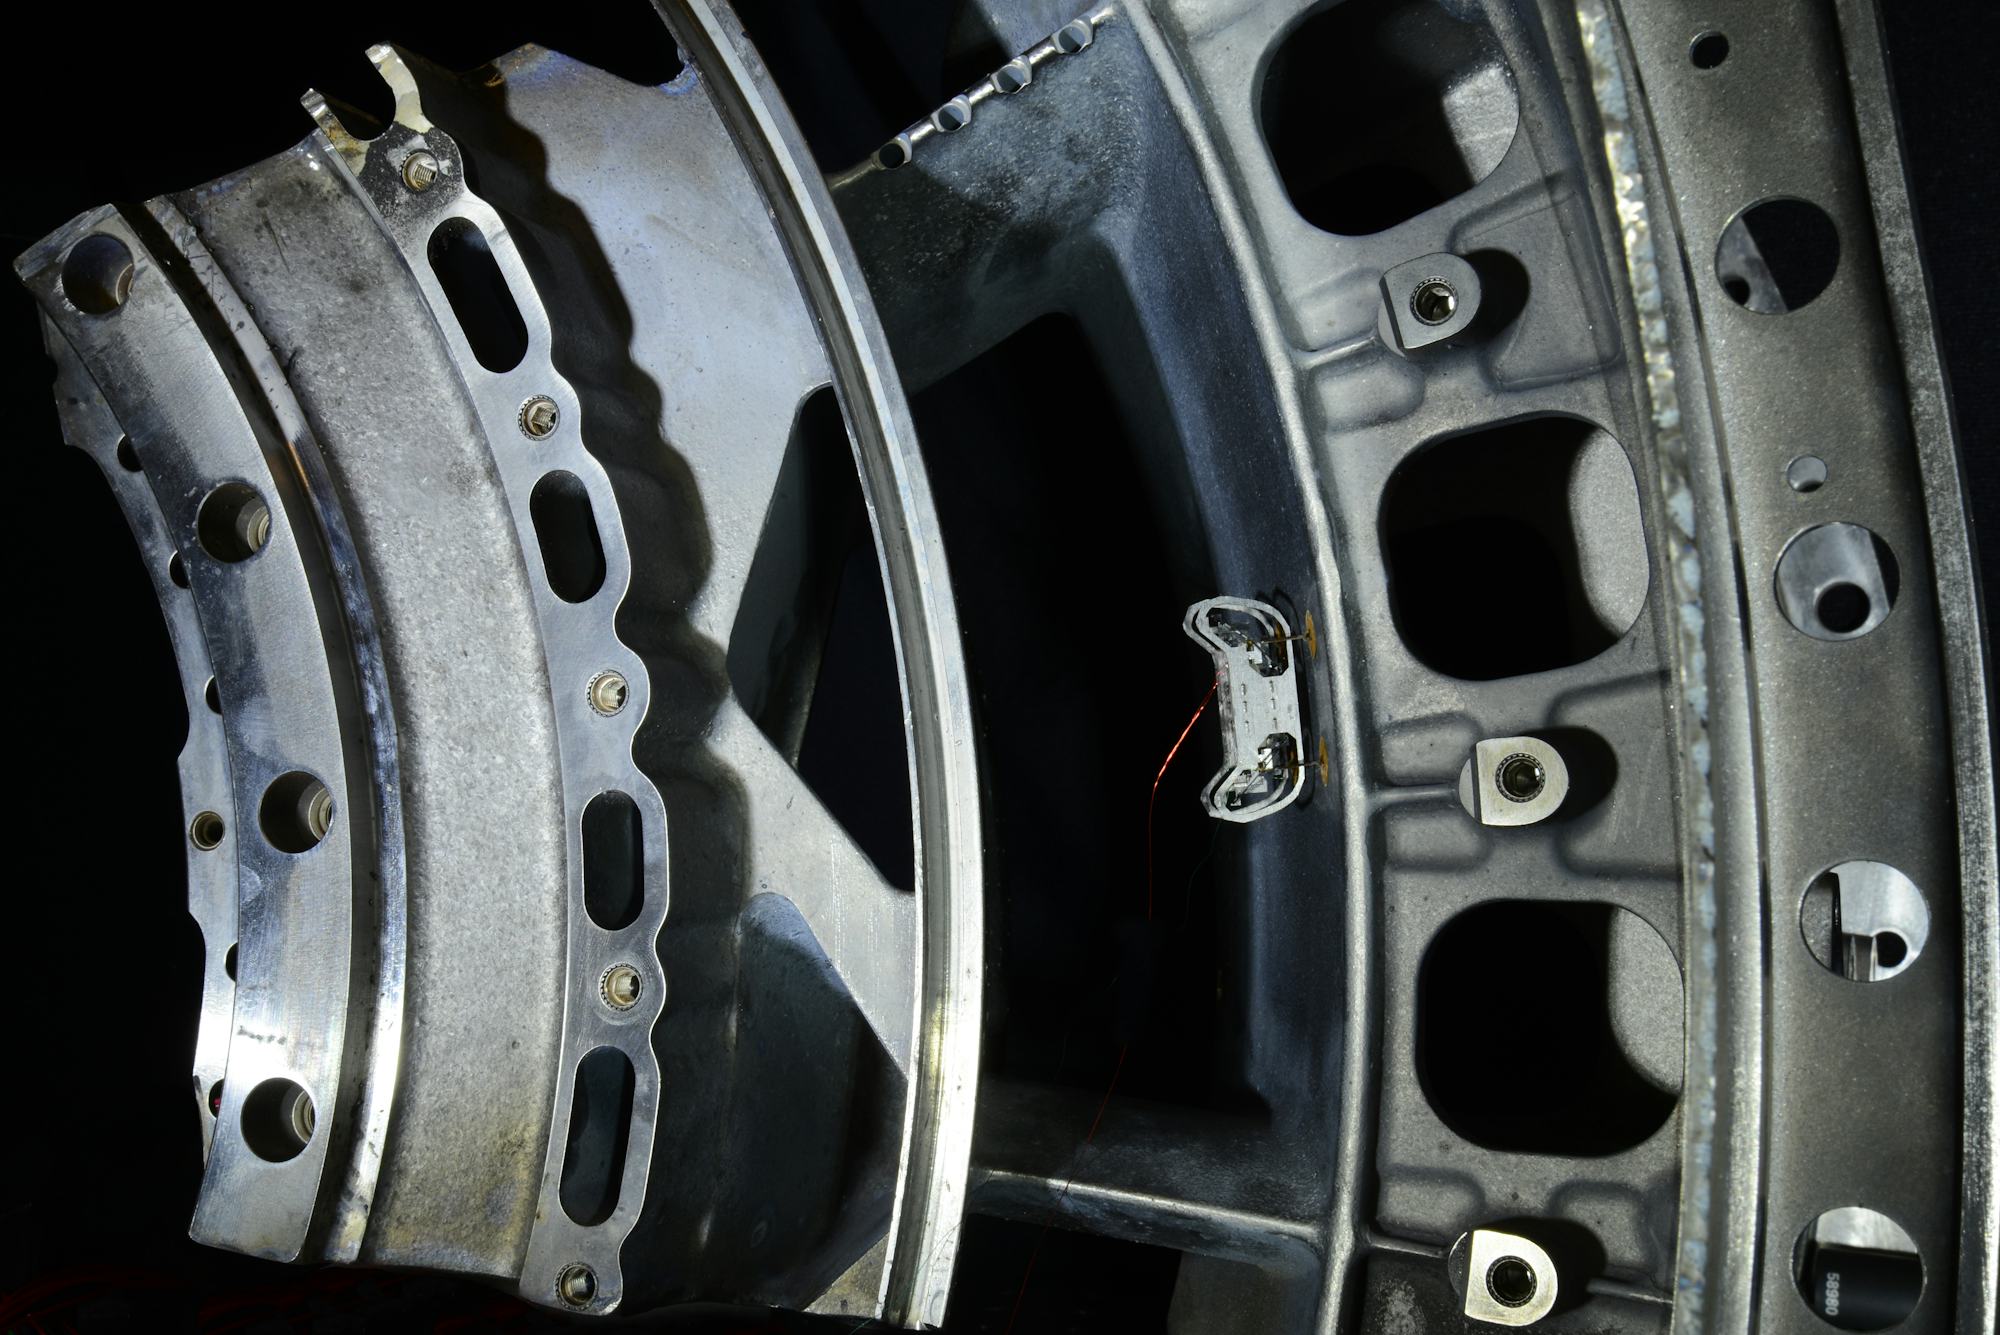
HAMR-E on a curved engine-section wall; its tether is visible.▶1080p
Harvard · HAMR-E2018

HAMR-E: electroadhesive crawling on engine walls

A centimetre-scale tethered robot uses electroadhesive feet to crawl on vertical, inverted and curved conductive surfaces.
Tethered climbing experimentsRead case
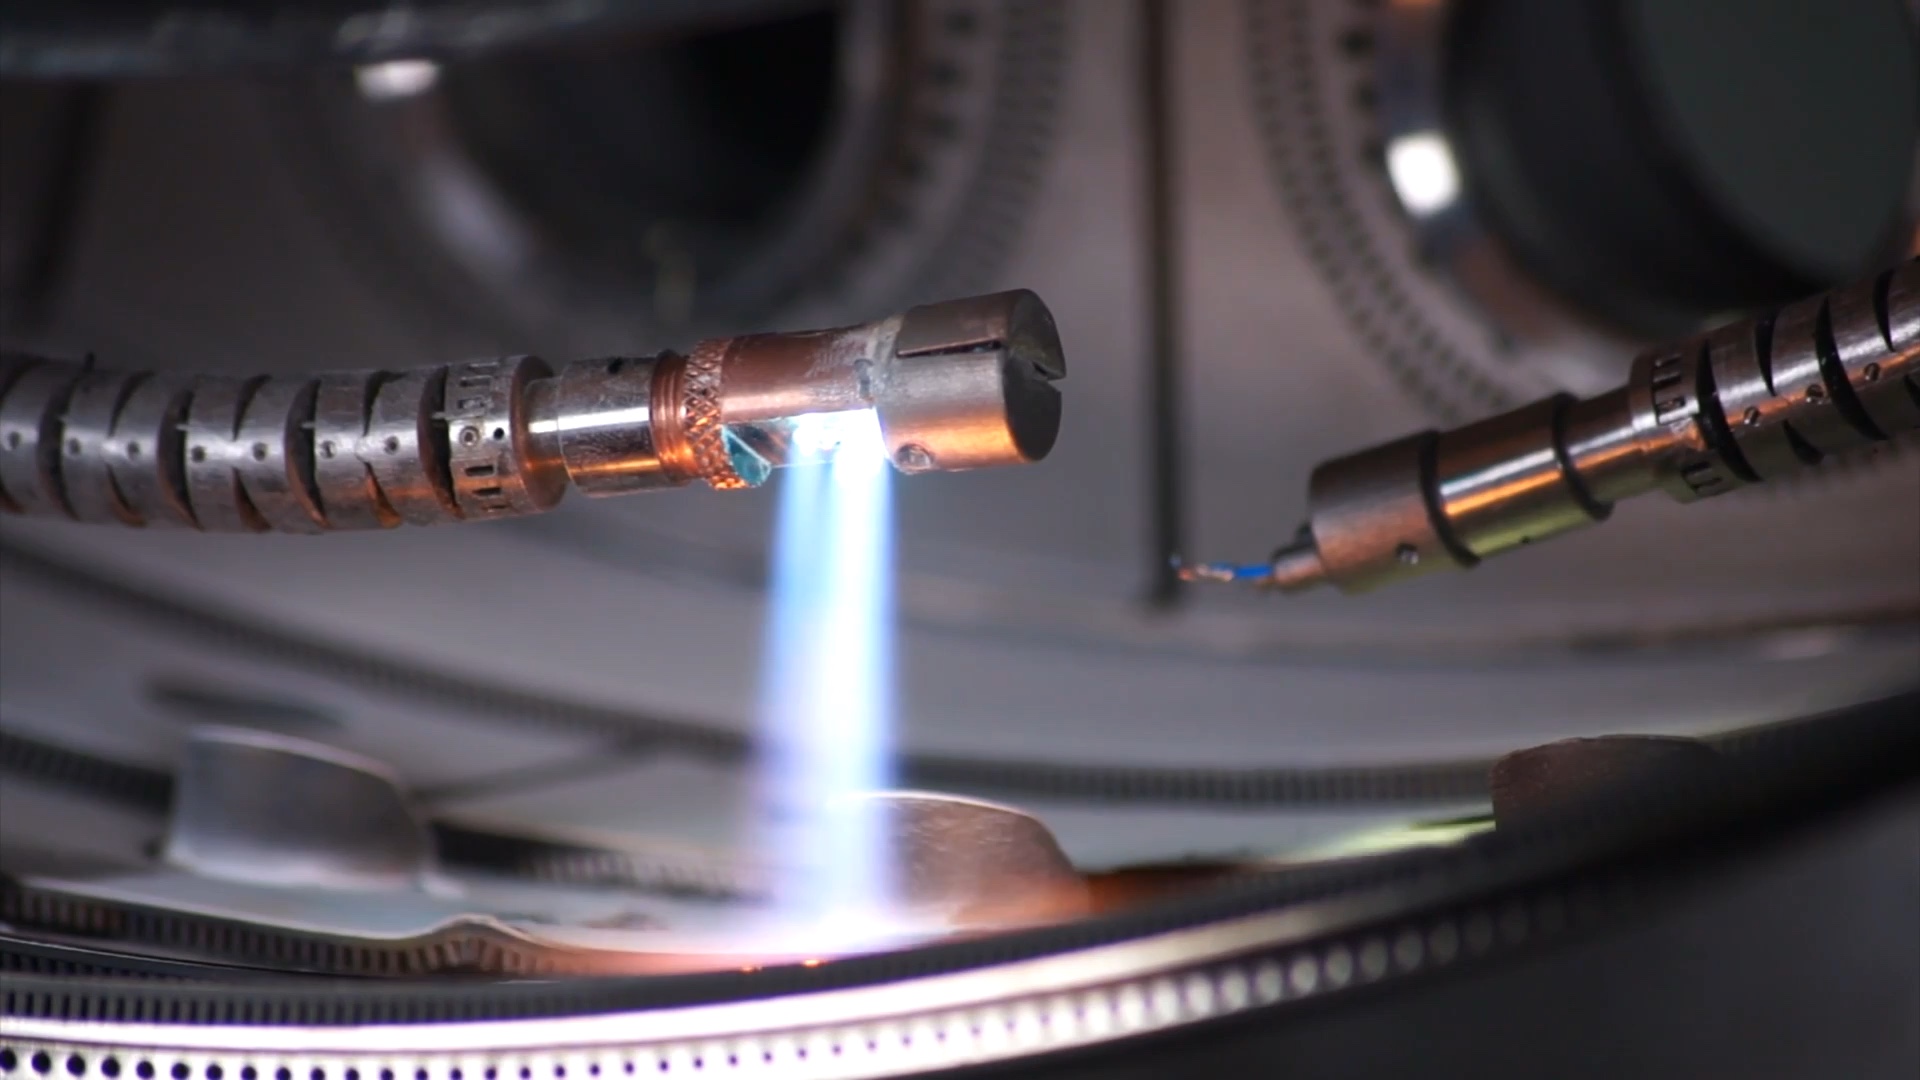
Official video frame: FLARE snake tips during a combustor flame-spray experiment (01:50).▶1080p
Rolls-Royce · FLARE2019

FLARE: twin snake robots patch thermal-barrier coatings

Two snake robots reach a combustor through limited access to observe and patch local thermal-barrier coating damage.
Laboratory engine testsRead case
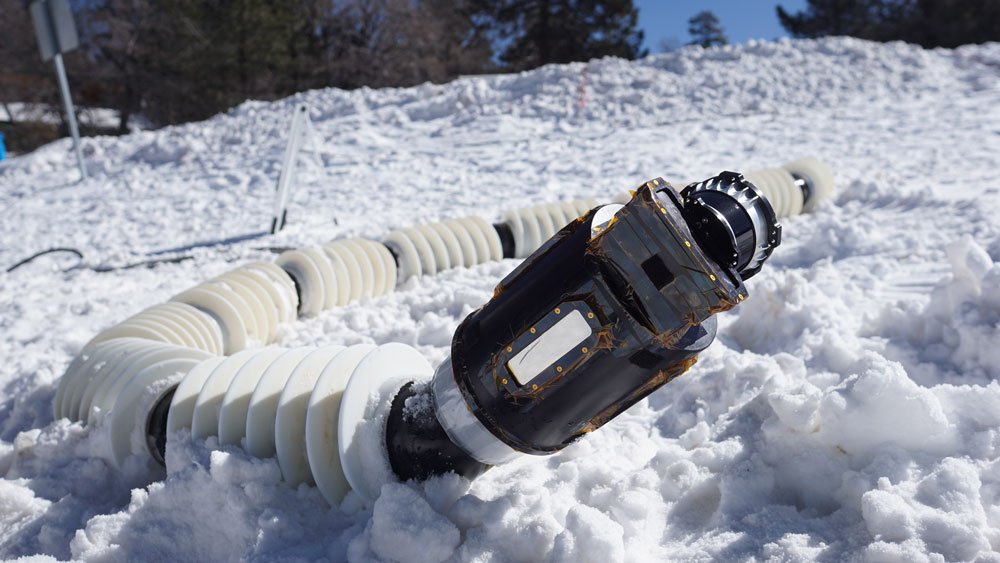
EELS prototype during snow tests in Southern California, February 2023.▶1080p
NASA JPL · EELS2024

EELS: a snake robot for passages through ice

A segmented robot combines rotating screw propulsion with environmental mapping in ground tests on ice, snow, sand and glacier passages.
Ground prototypes and glacier testsRead case
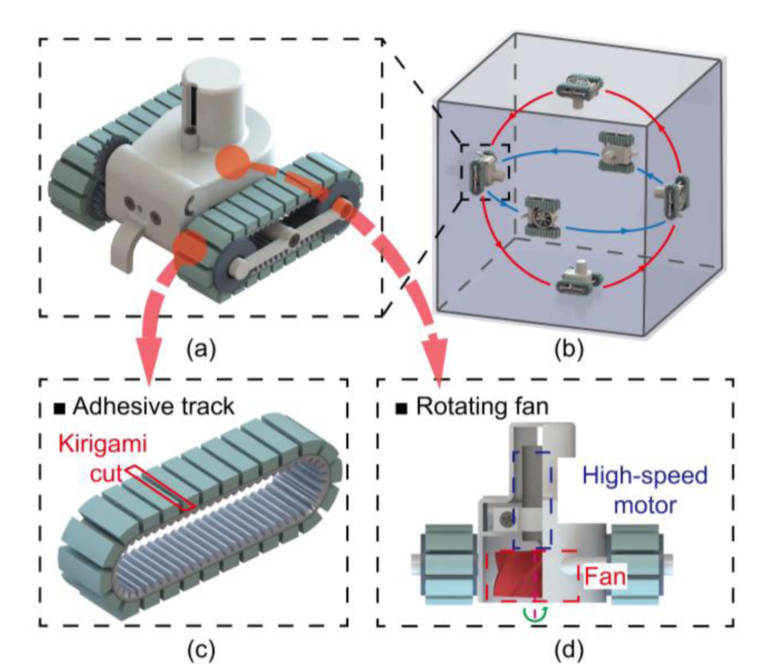
Sun et al., 2026, K-Track Fig. 1: kirigami adhesive tracks, fan and a wall-to-wall path.
K-Track2026

Miniature robot for wall-to-wall transitions

Kirigami-inspired adhesive tracks and negative-pressure preload enable a miniature robot to transition between surfaces of varying curvature.
Experiments and engine-component testsRead case
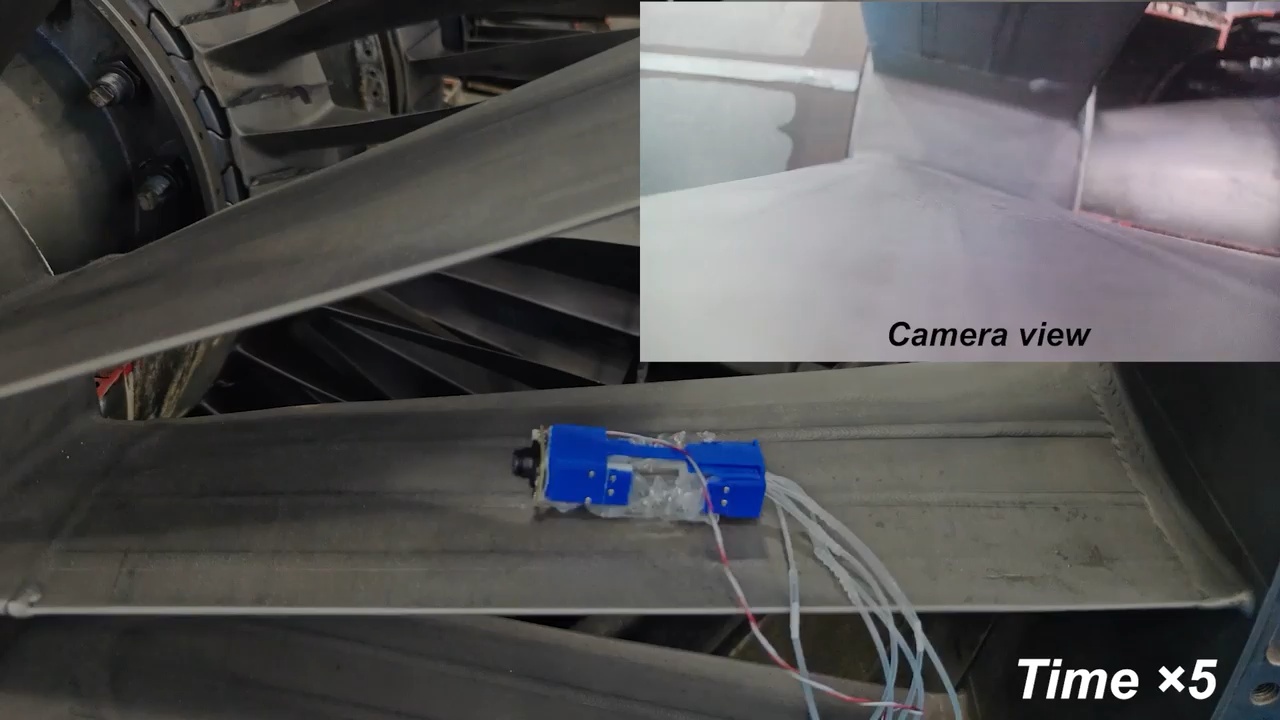
Guo et al., 2026, supplementary video at 79.988 s: the miniature crawler moves along a blade surface in a decommissioned JT8D engine, with its camera view at upper right. The source video is marked Time ×5.▶720p
TRACE2026

Miniature climbing robot with active compliance

A unified active-compliance mechanism adapts to varied surfaces, with visual-inspection tests inside a decommissioned engine.
Experiments and decommissioned-engine testsRead case
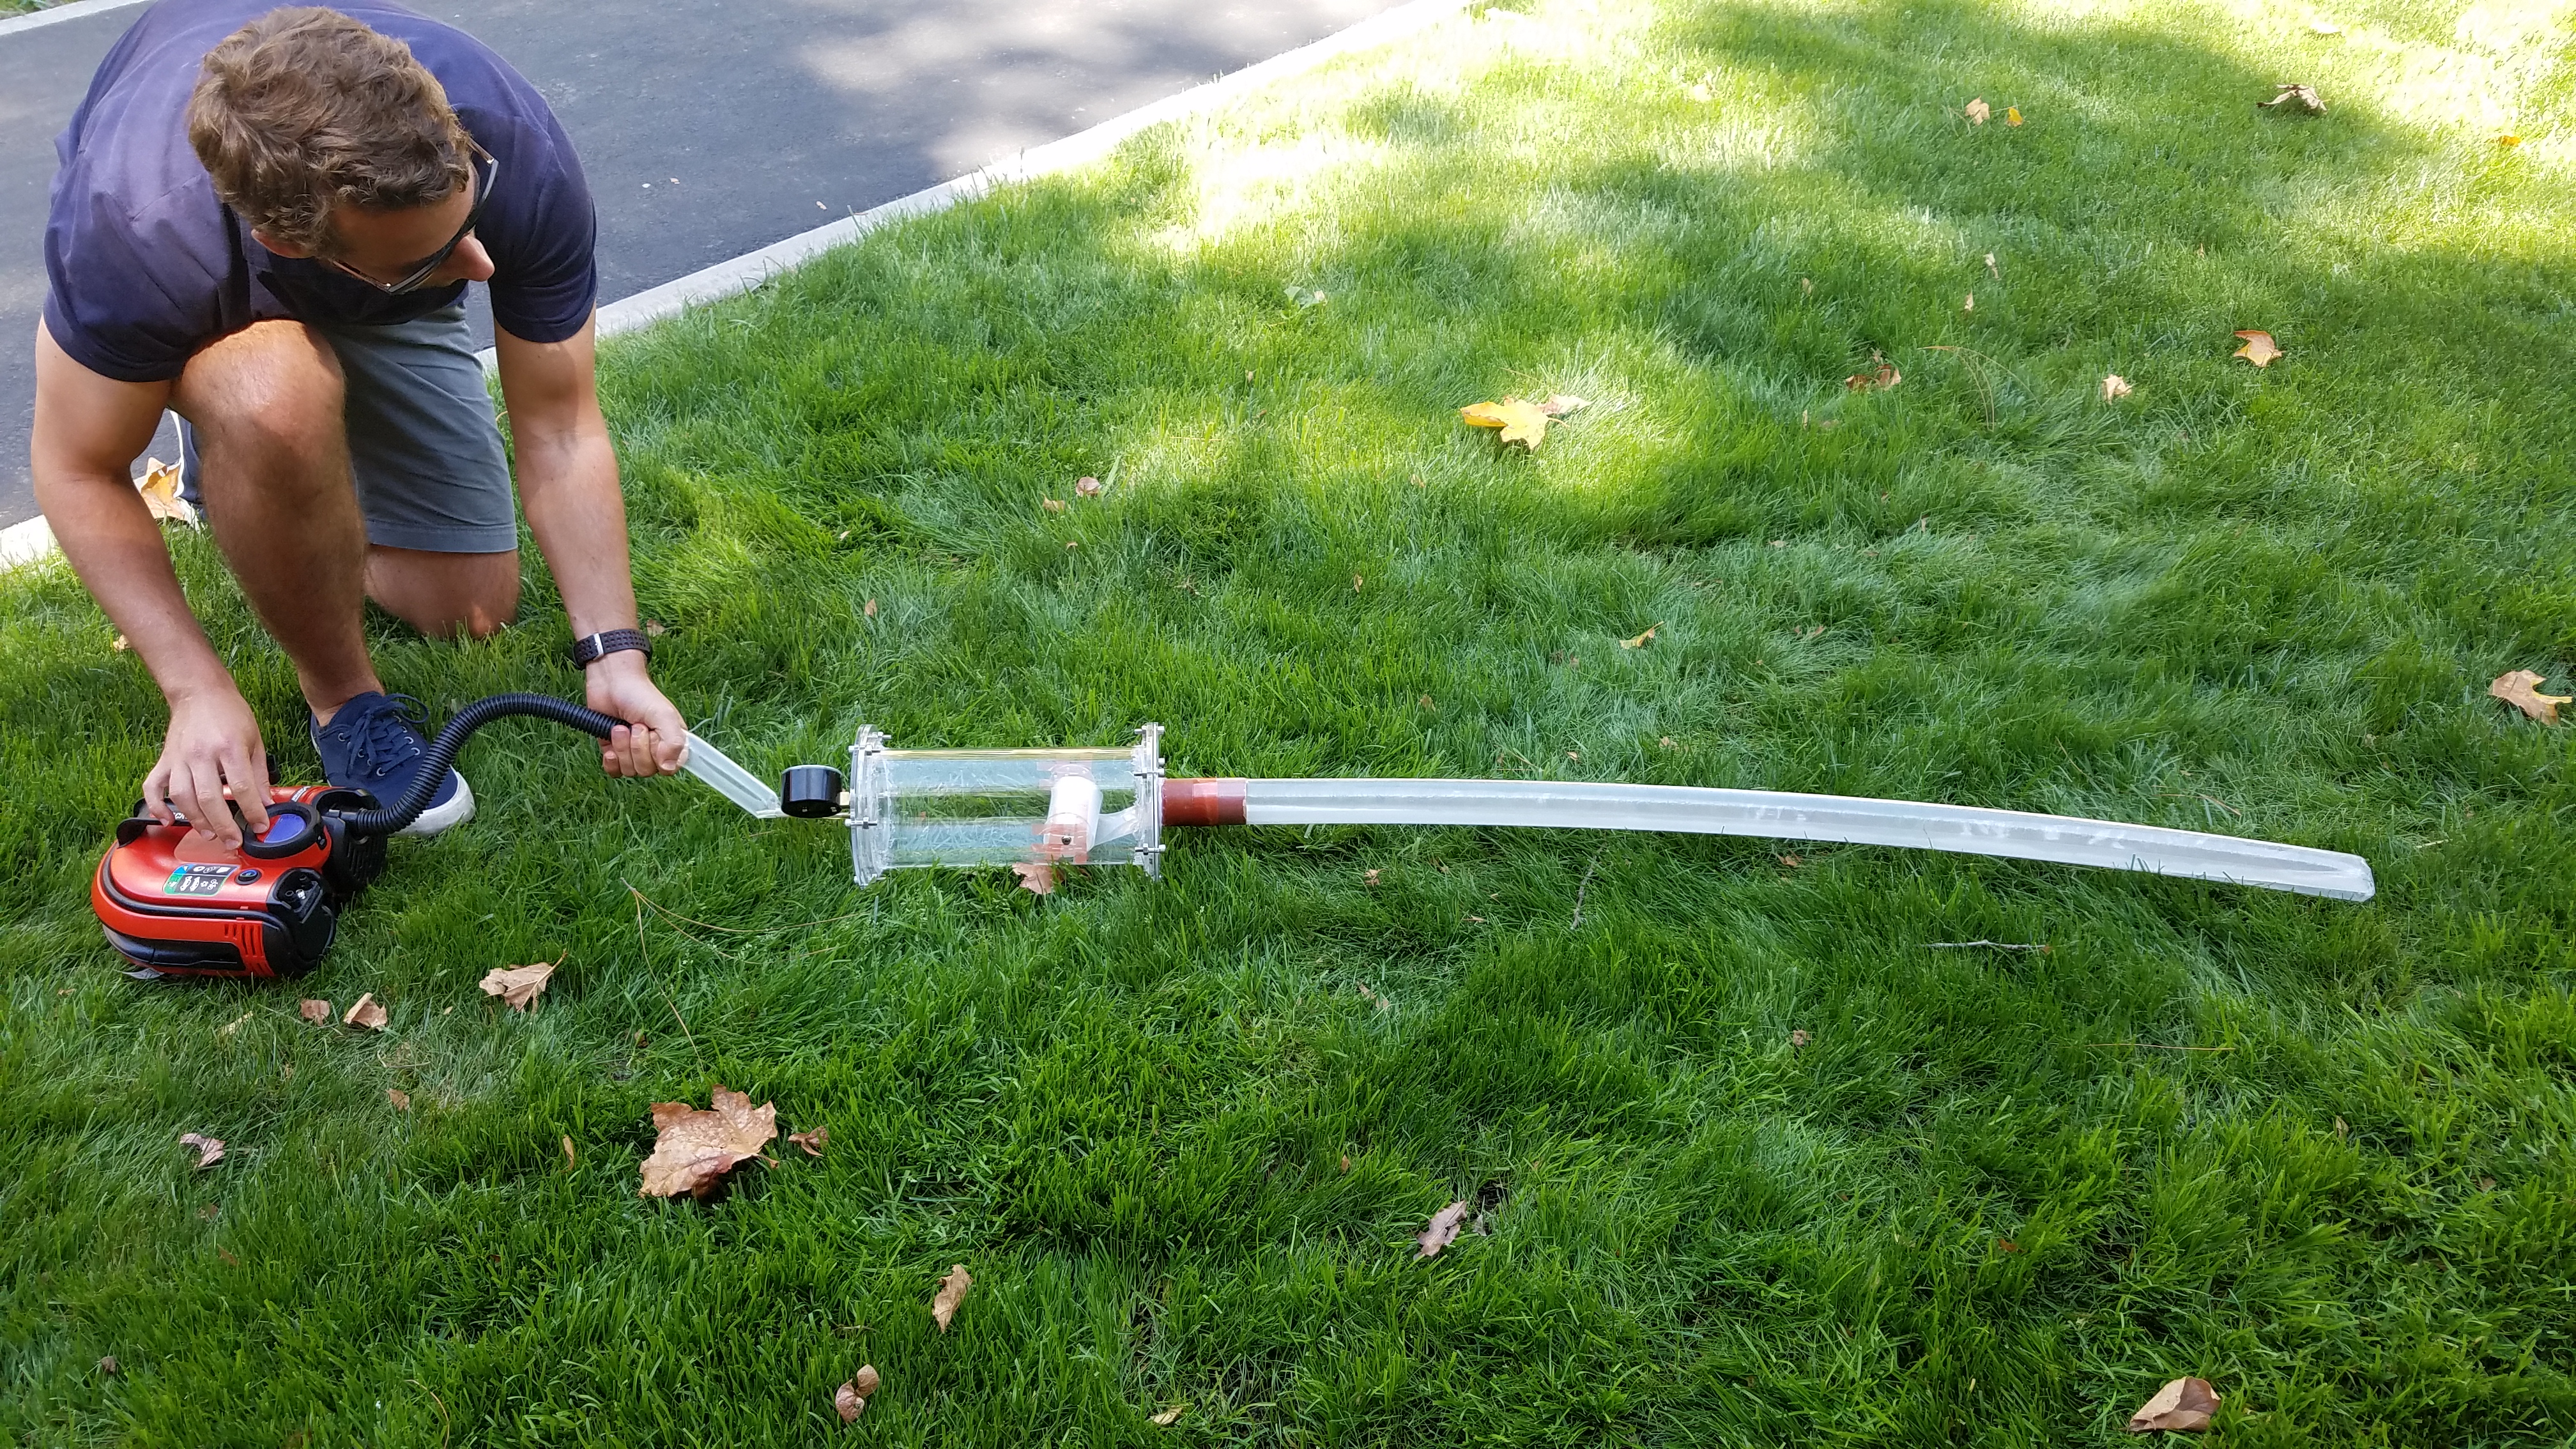
A growing robot demonstrated on grass, from the researchers’ project website.▶1080p
Stanford · Vine robot2017

A soft robot that advances by tip growth

A flexible tube grows by eversion at its tip, offering another way to move around obstacles.
Growth-based proof of conceptRead case
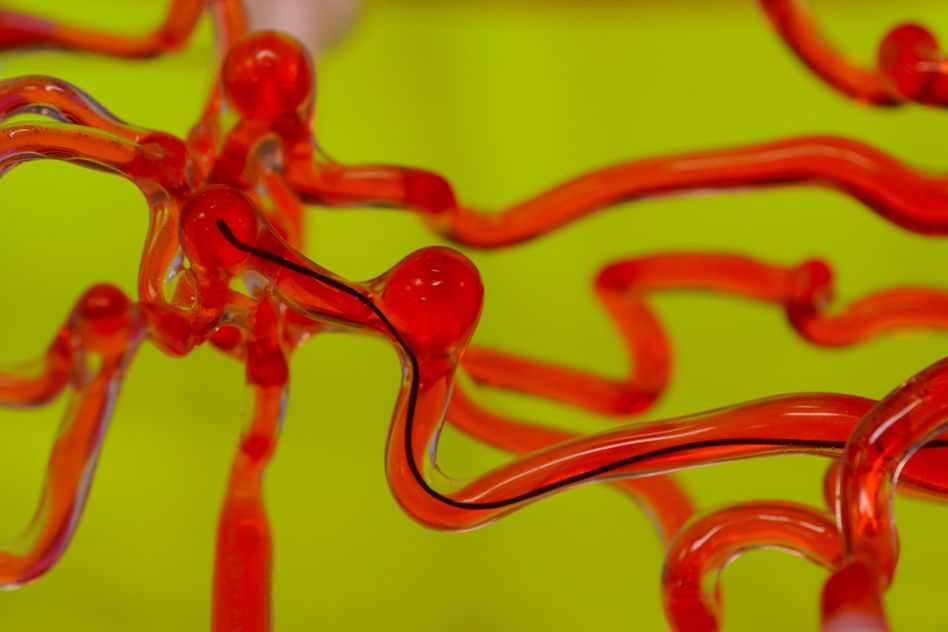
A magnetic thread inside a silicone vessel model, not an image from a patient.▶4K
MIT · Robo-thread2019

Magnetically steered thread in a cerebral-vessel model

A magnetic field steers a slender thread, with a hydrogel coating to reduce friction.
Vascular-model experimentsRead case
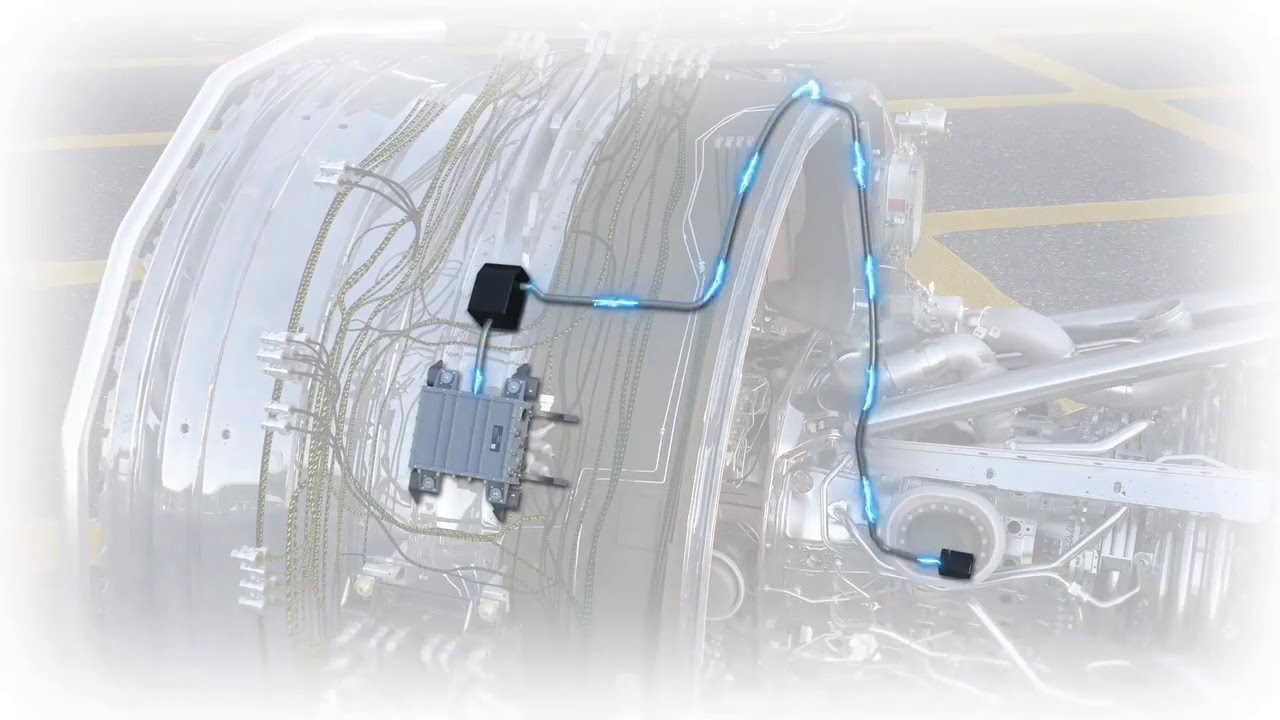
INSPECT embedded-probe concept-animation preview.▶720p
Rolls-Royce · INSPECT2019

INSPECT: embedded optical probes through borescope ports

Retractable optical probes use borescope ports to observe adjacent compressor-blade edges during slow rotation.
Compressor-rig integration testsRead case
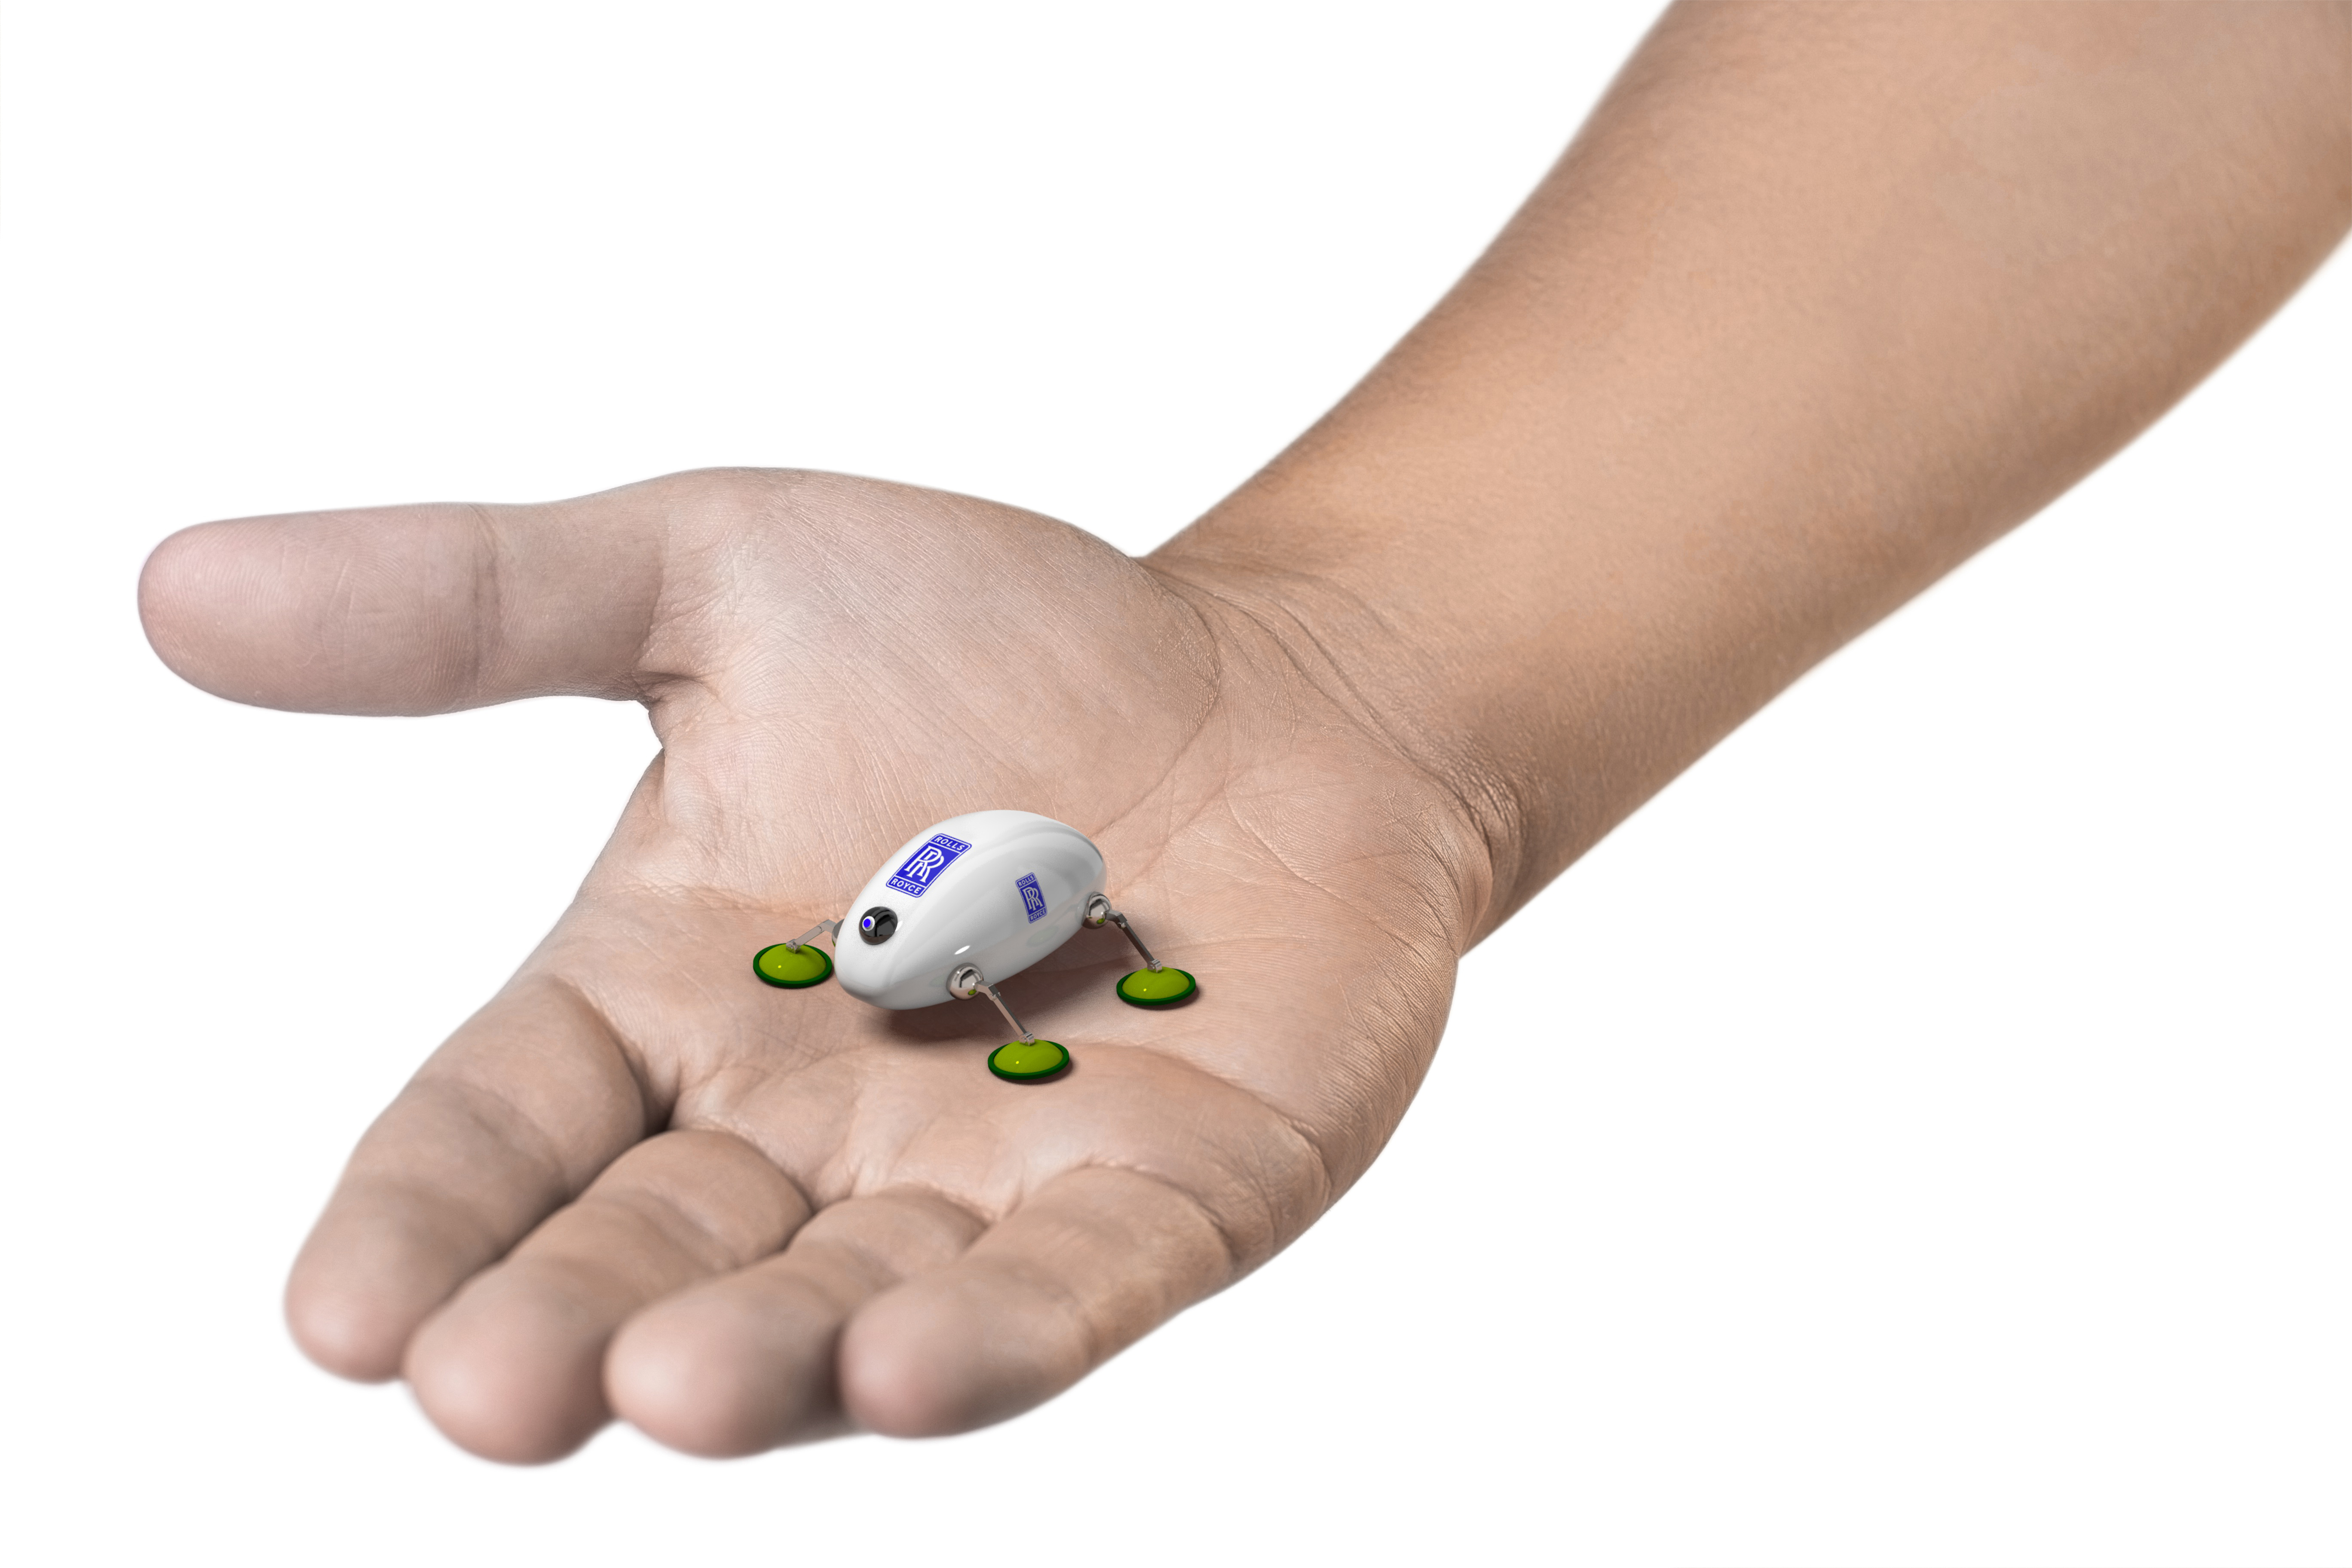
Rolls-Royce SWARM artist’s impression; not an operational deployment photograph.▶1080p
Rolls-Royce · SWARM2018

SWARM: a concept for miniature inspection robots in engines

A proposed snake carrier would deploy and retrieve miniature crawlers to inspect surfaces beyond conventional borescope access.
System concept and locomotion prototypesRead case
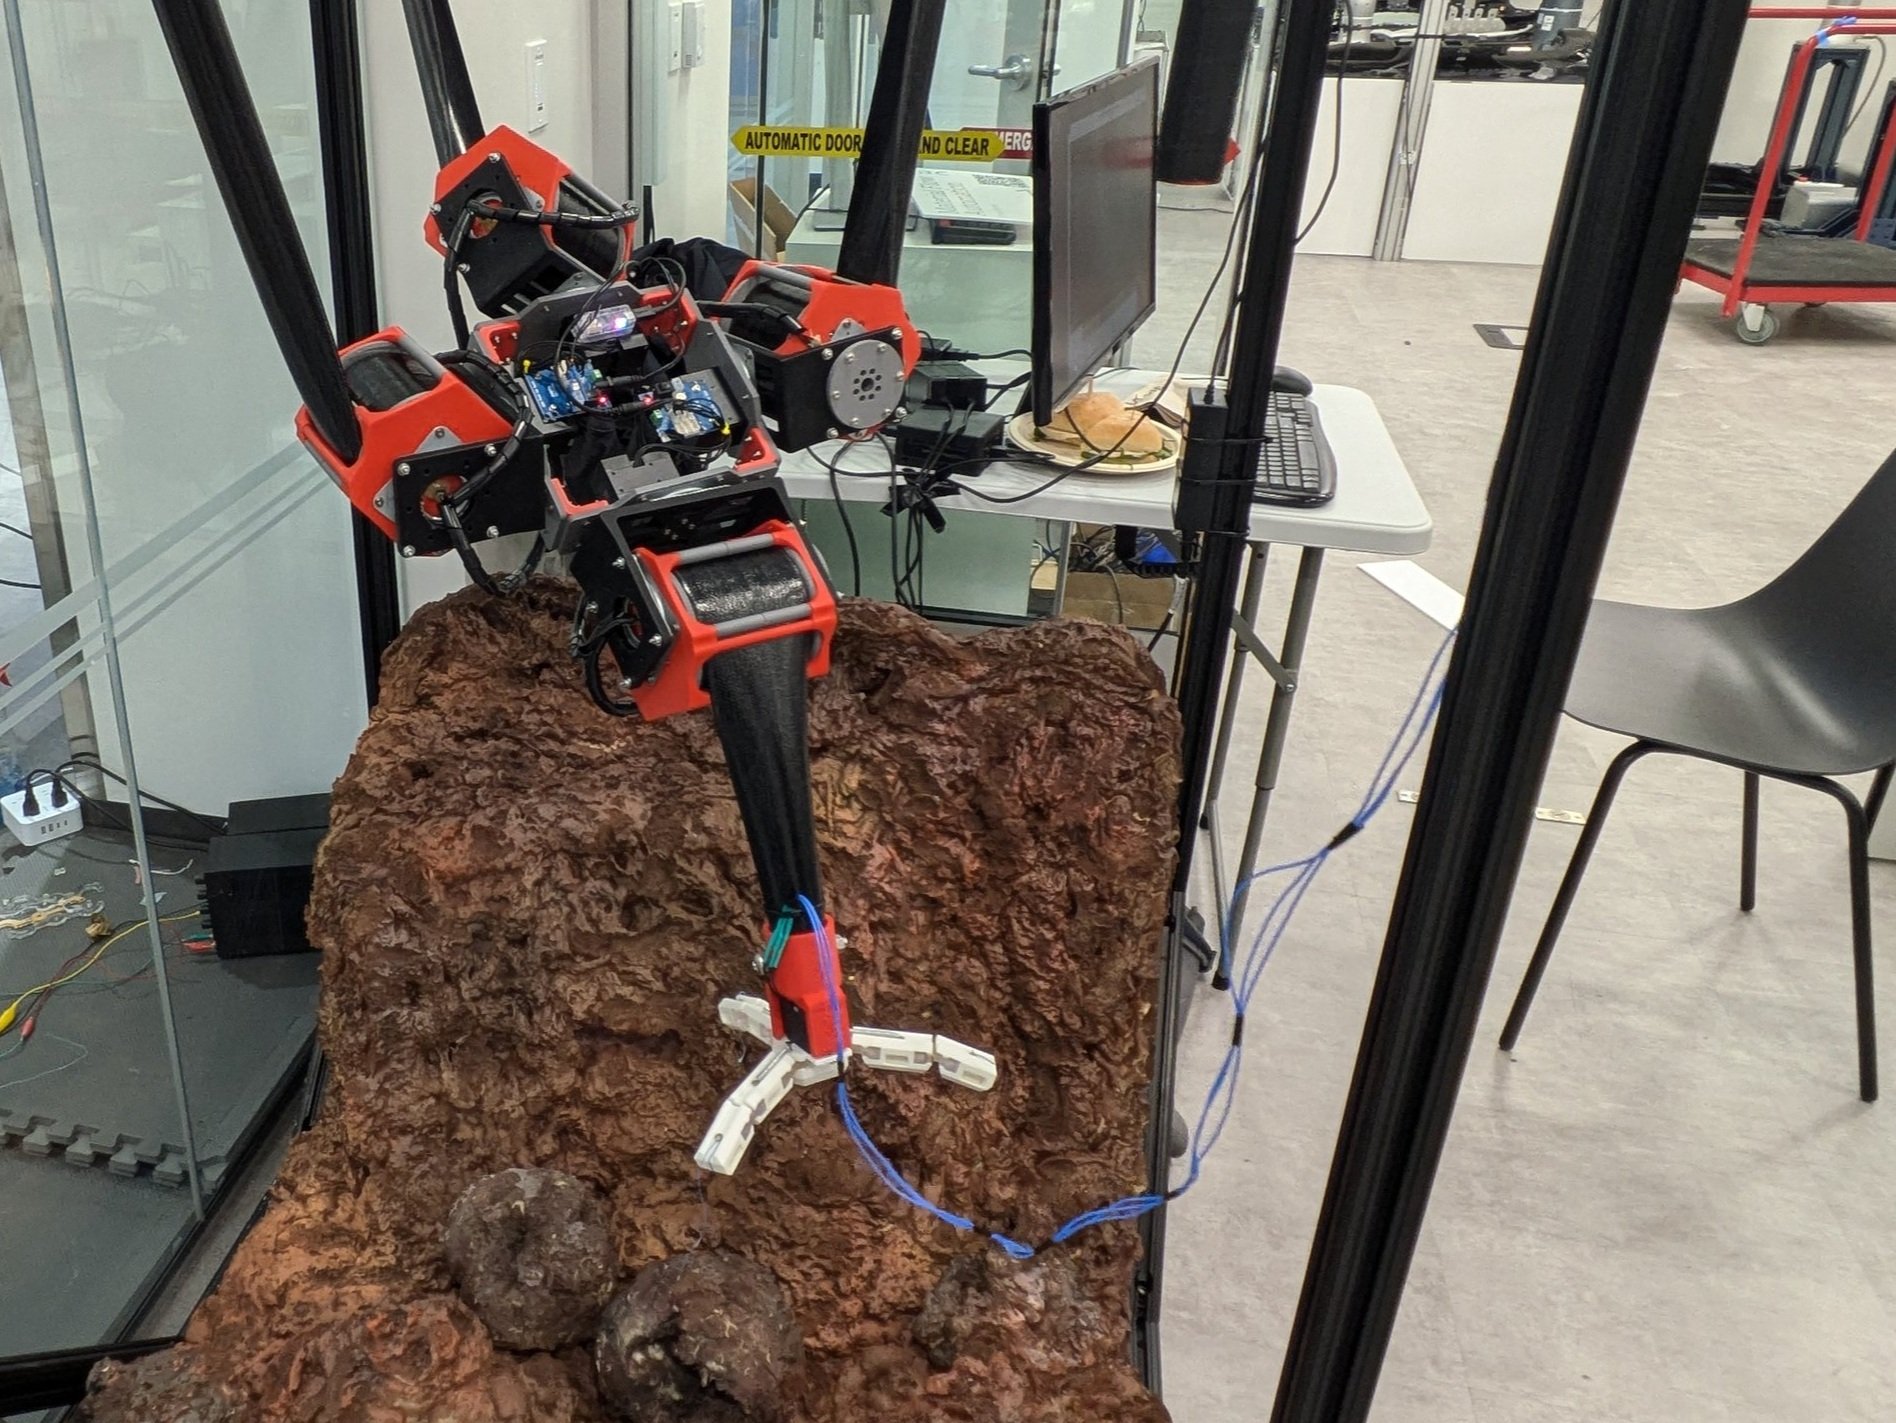
ReachBot prototype in Stanford’s demonstration environment.▶Video
Stanford · ReachBot2024

ReachBot: finding anchors with extendable booms

Microspine grippers at the ends of extendable booms find anchors on rock surfaces.
Lab prototypes and single-boom field testsRead case
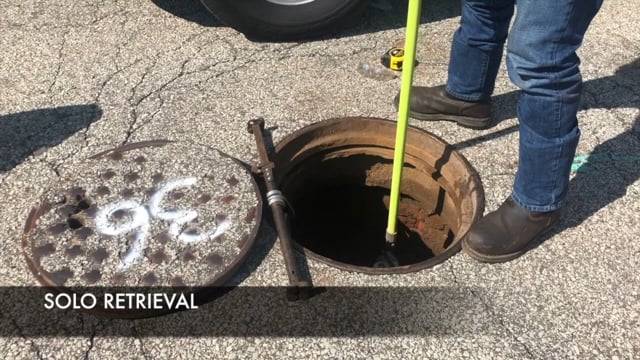
SOLO: pipe inspection from a manhole▶720p
RedZone · SOLO2020

SOLO: pipe inspection from a manhole

The tracked SOLO robot is deployed through a manhole to collect interior imagery for sewer assessment.
Manufacturer deployment demonstrationRead case
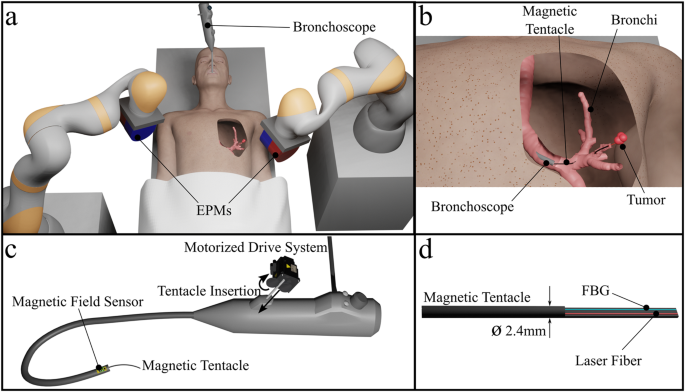
Platform concept and experimental setup, Fig. 1 of the paper.▶1080p
Leeds · Magnetic tentacles2023

Peripheral-airway navigation with a magnetic catheter

A 2.4 mm magnetic catheter integrates shape sensing and an optical fibre for peripheral-airway navigation and laser delivery.
Phantom and ex-vivo validationRead case
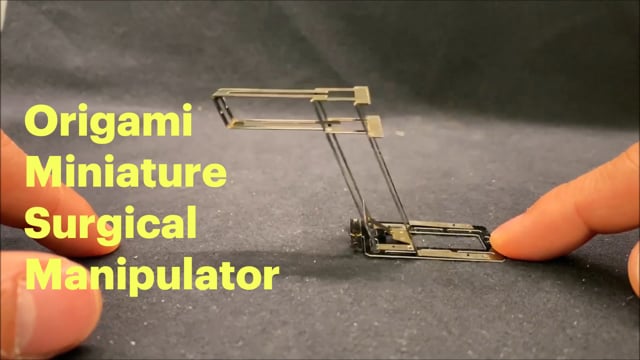
mini-RCM: an origami-inspired miniature teleoperator▶1080p
Harvard · mini-RCM2020

mini-RCM: an origami-inspired miniature teleoperator

The miniature teleoperated mini-RCM demonstrates tracing and simulated retinal-vein cannulation.
Bench-top micromanipulationRead case
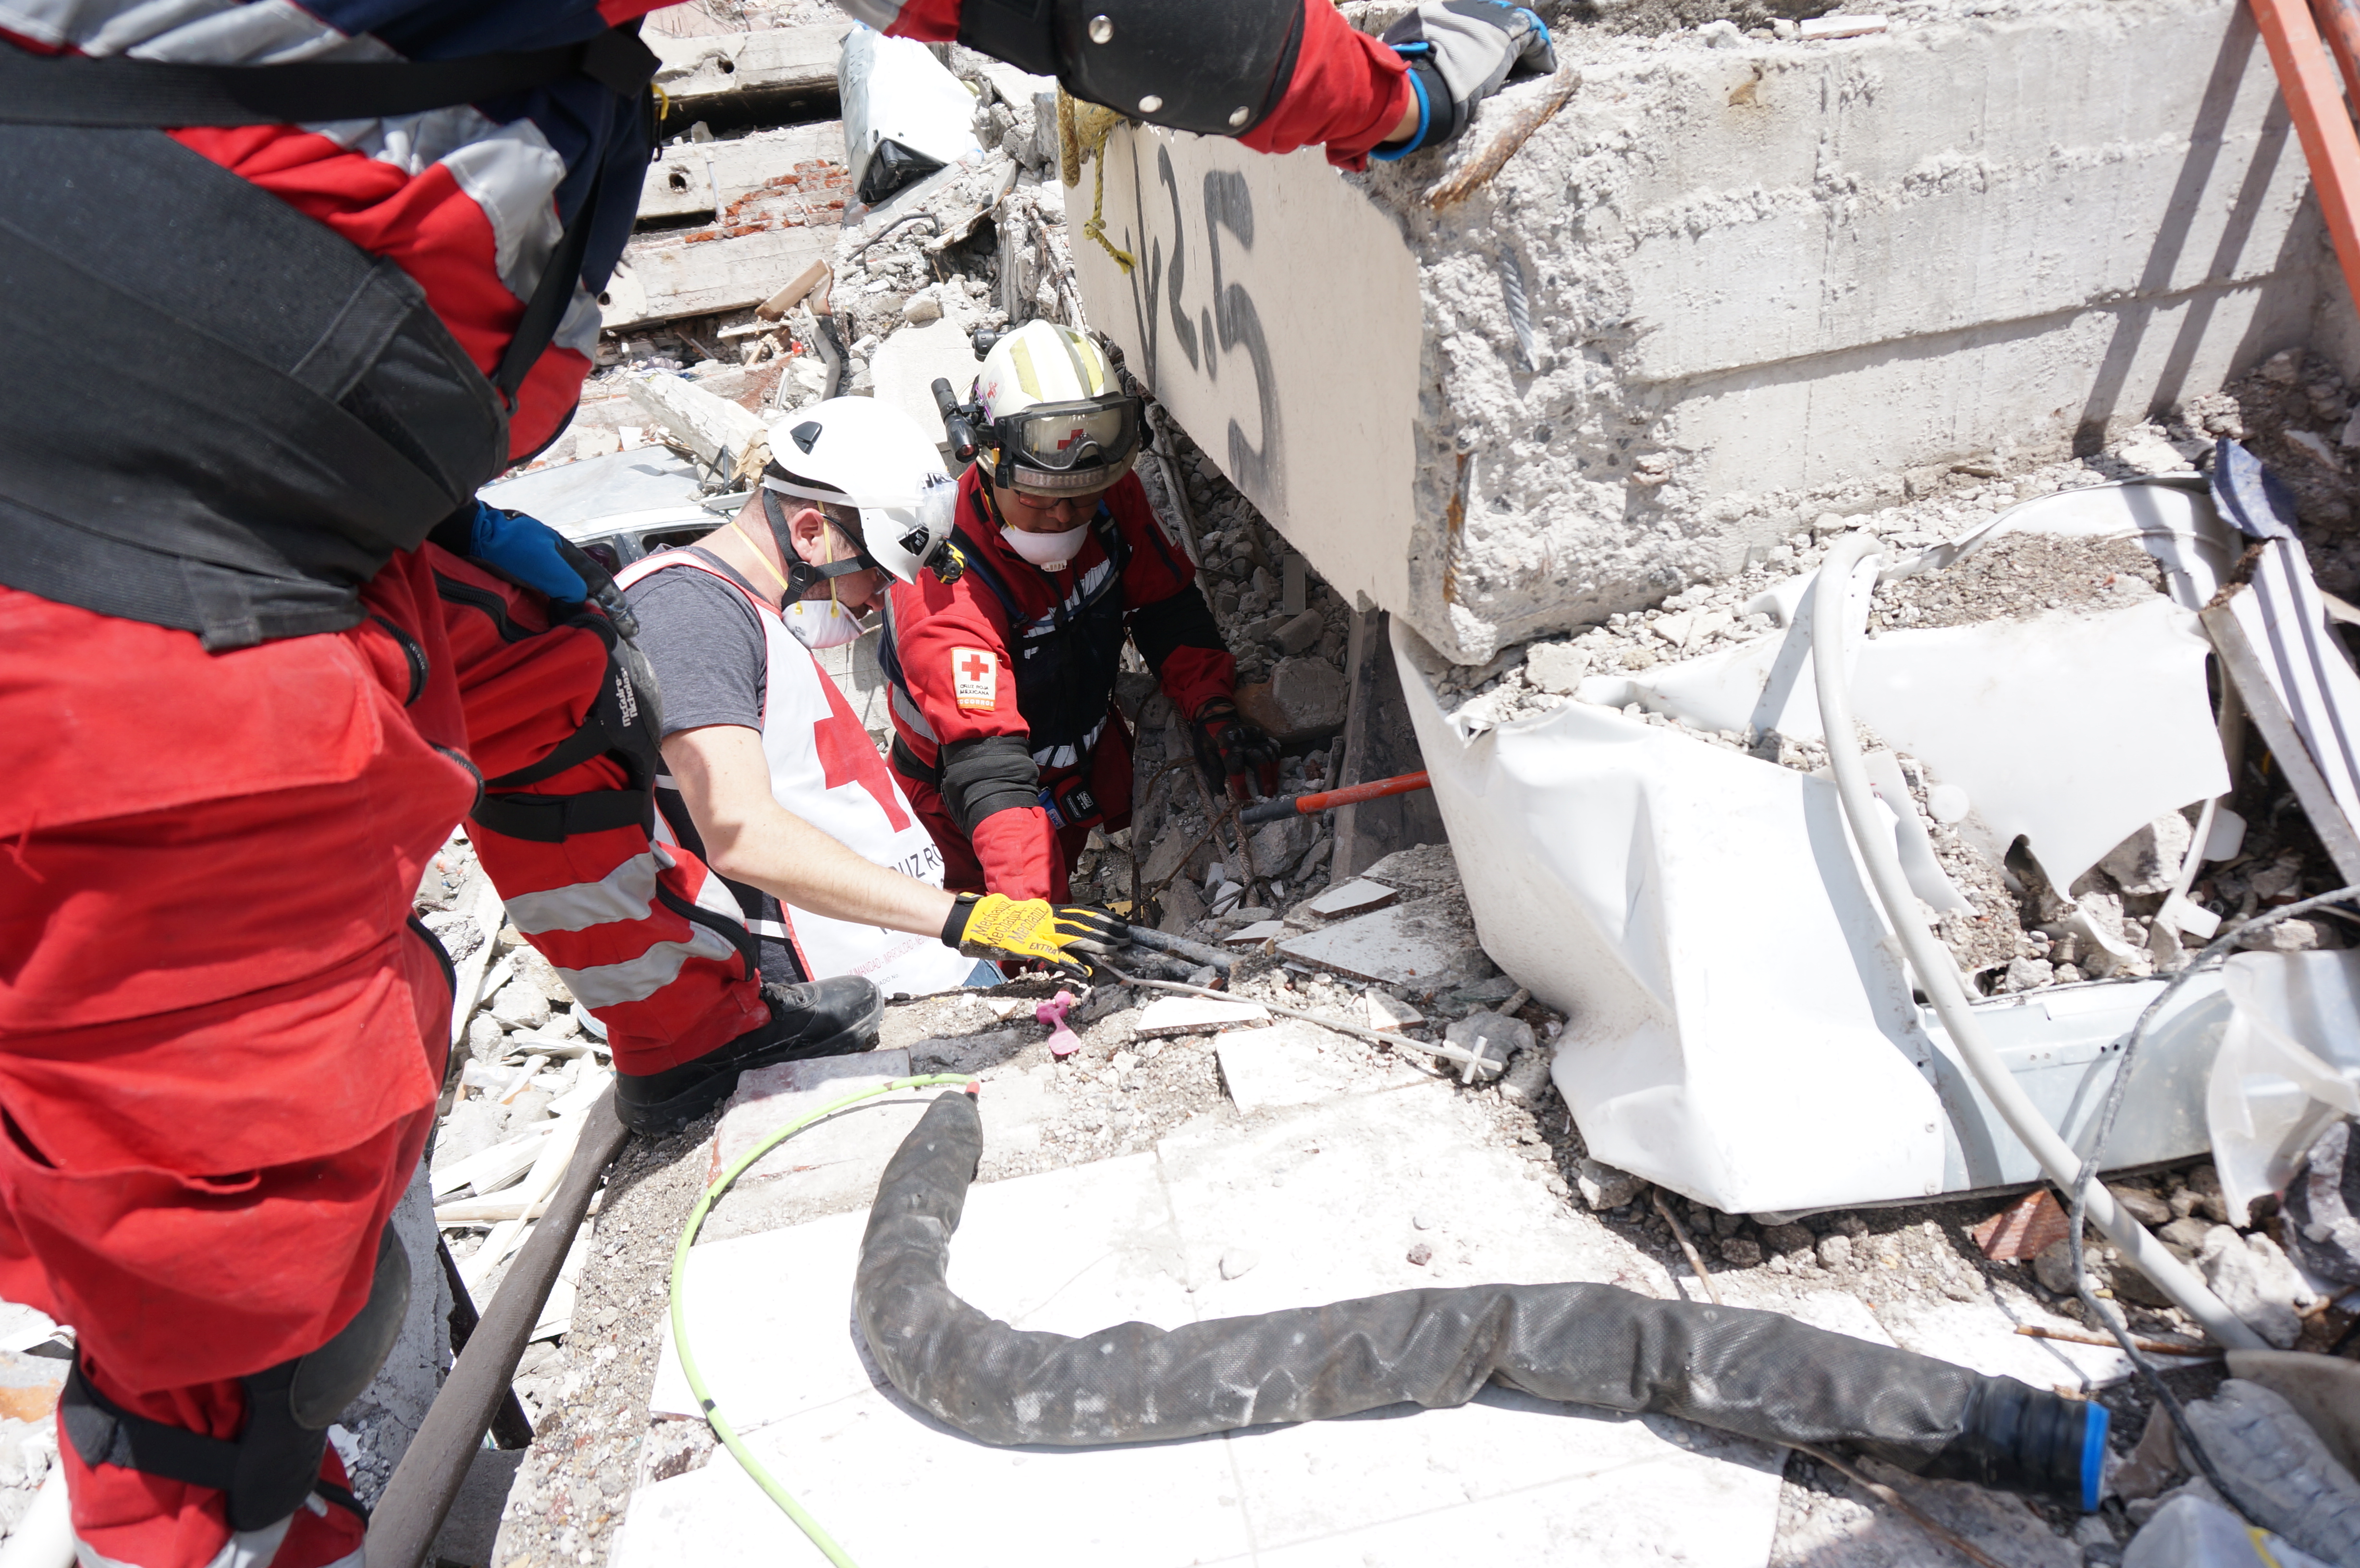
Snake-robot deployment after the 2017 Mexico City earthquake.
CMU · Snake robot2018

Snake robot in earthquake rubble

After the 2017 Mexico City earthquake, a snake robot provided camera views inside gaps inaccessible to conventional cameras.
Documented earthquake deploymentRead case
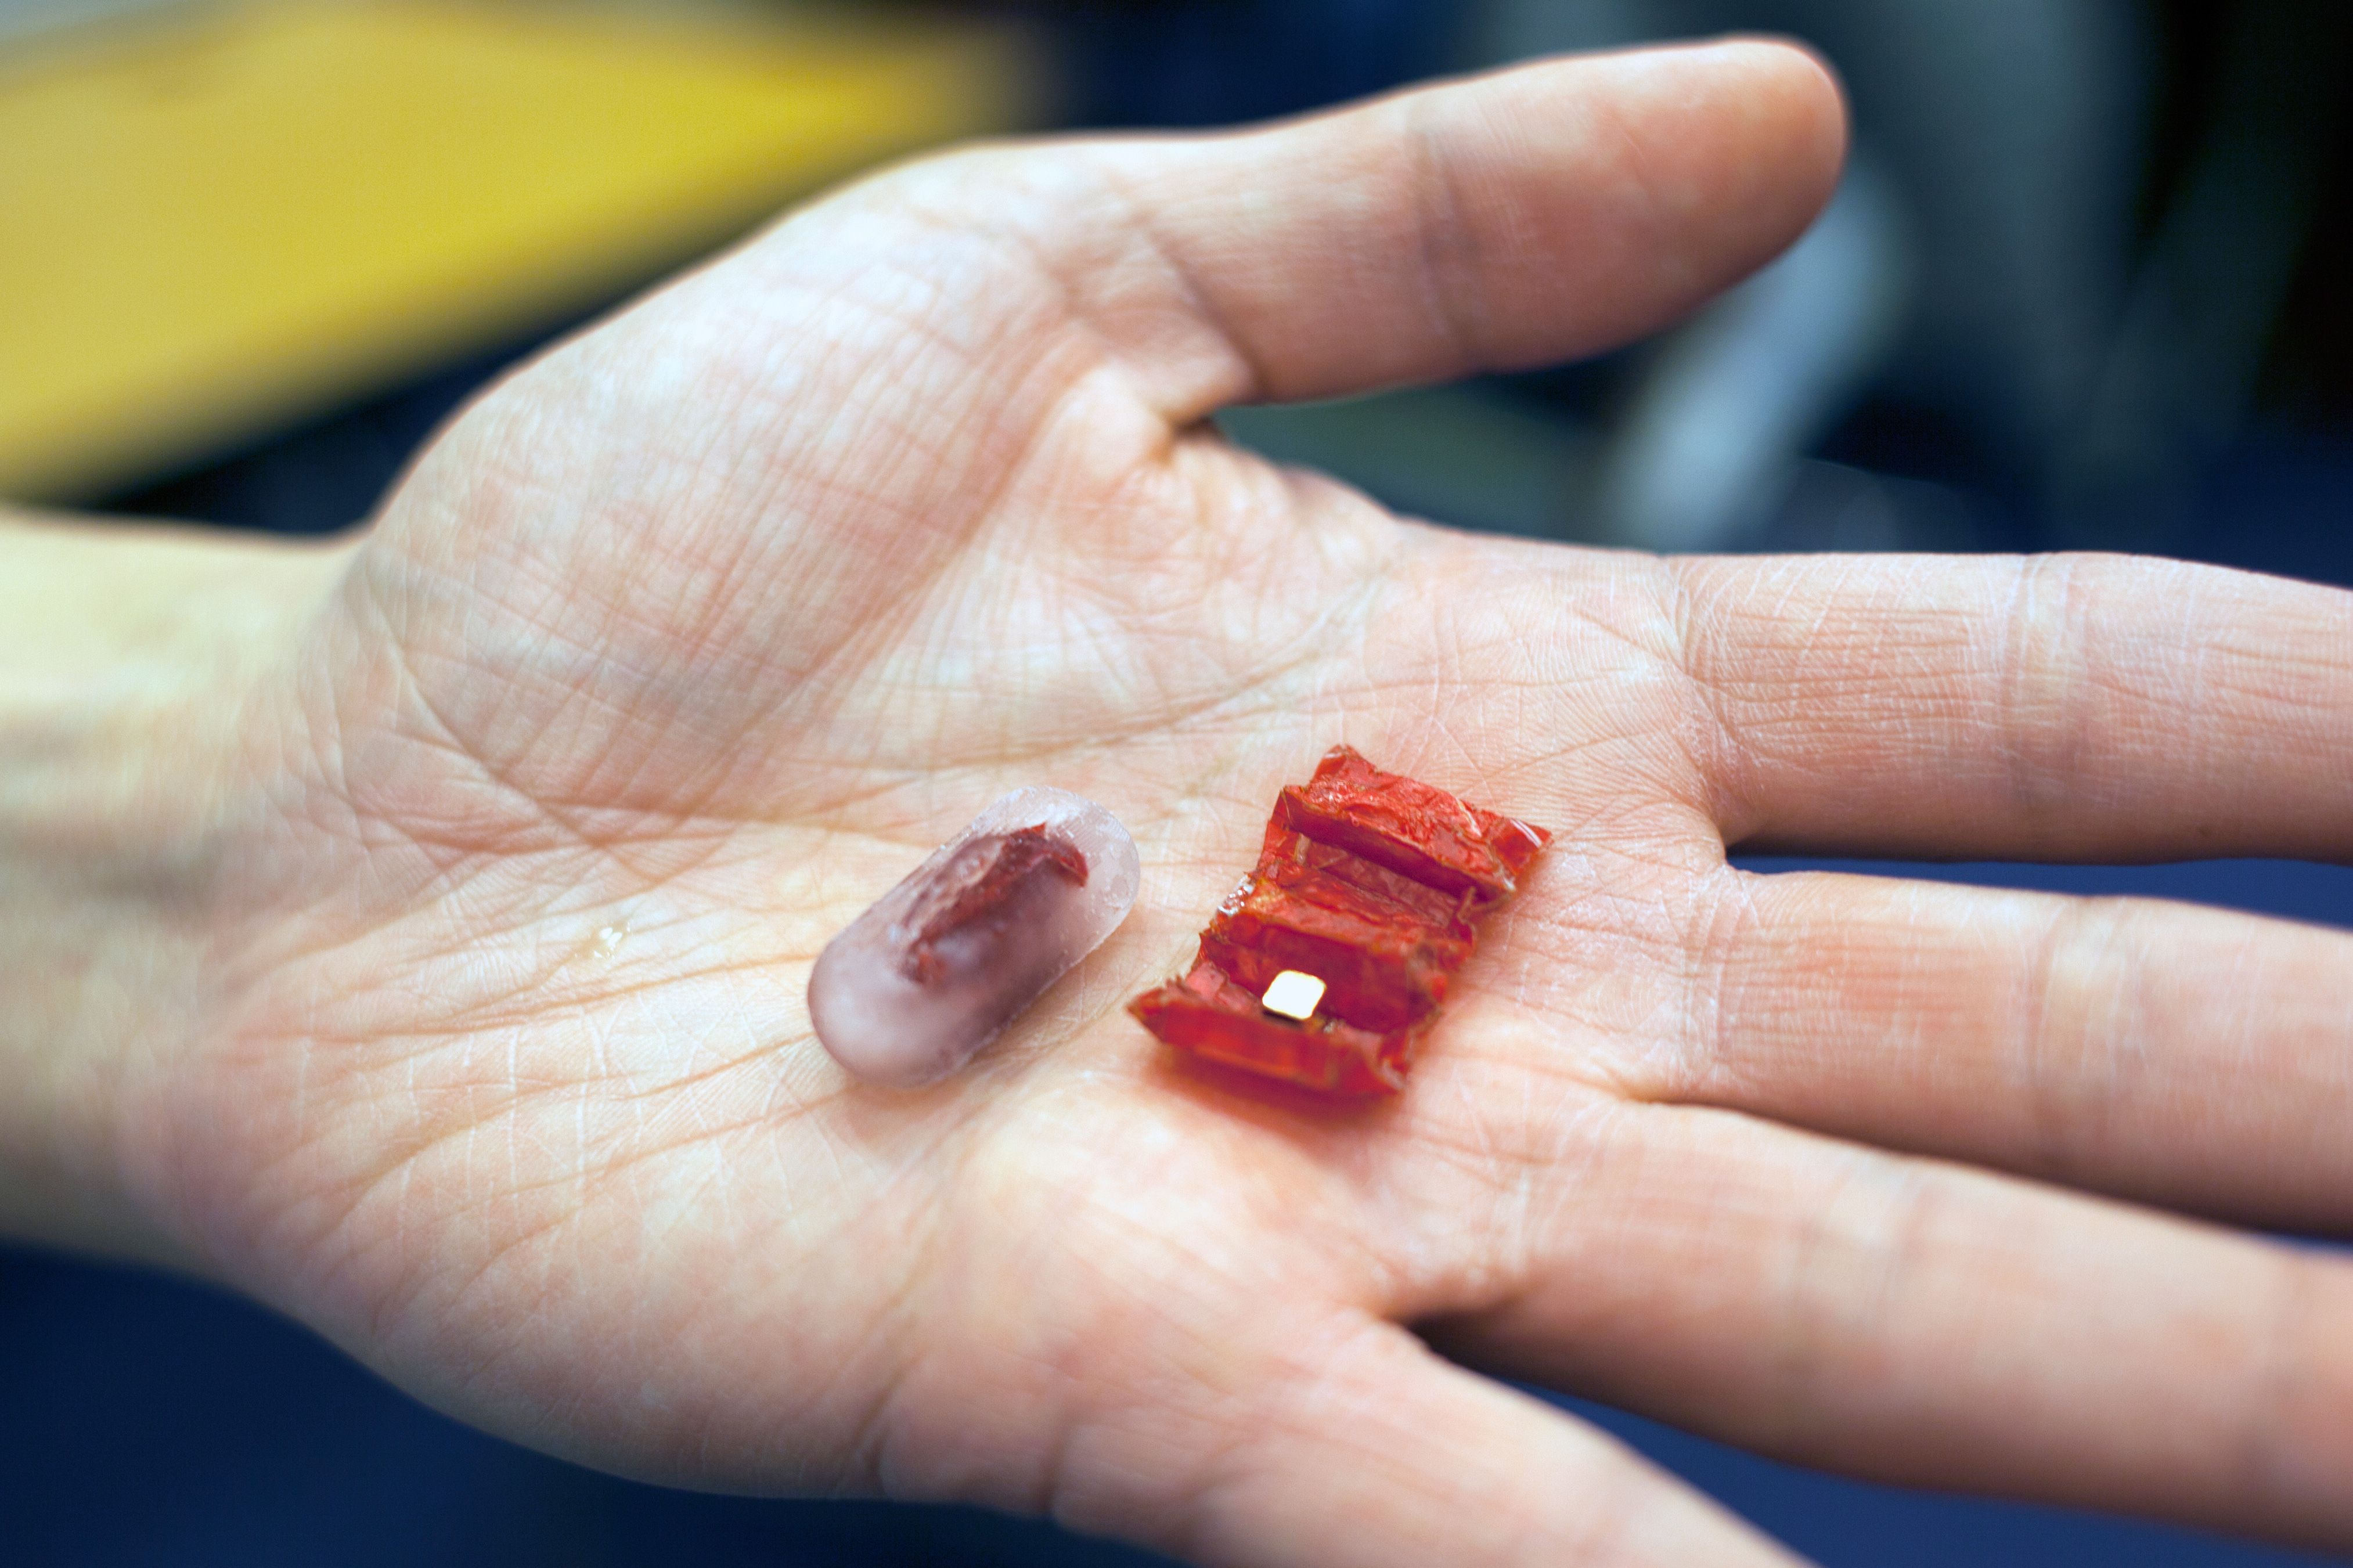
The capsule and unfolded origami robot.▶1080p
MIT · Origami robot2016

An ingestible origami robot in a stomach model

A robot unfolds from a capsule and uses magnetic guidance to remove a button battery in a simulated stomach.

Simulated-stomach proof of conceptRead case
Elios 3Infrastructure
▶Video
Flyability · Elios 3—

Elios 3: protected drone inspection in enclosed facilities

A protective cage, visual imaging and lidar support aerial inspection and spatial mapping inside enclosed facilities.

Manufacturer product demonstrationRead case
MillirobotMedical
Stanford · Millirobot2022

Magnetic millirobots for locomotion and delivery research

Magnetic actuation and origami-inspired structures support millimetre-scale research on locomotion, shape change and delivery.
Research prototype for medical useRead case
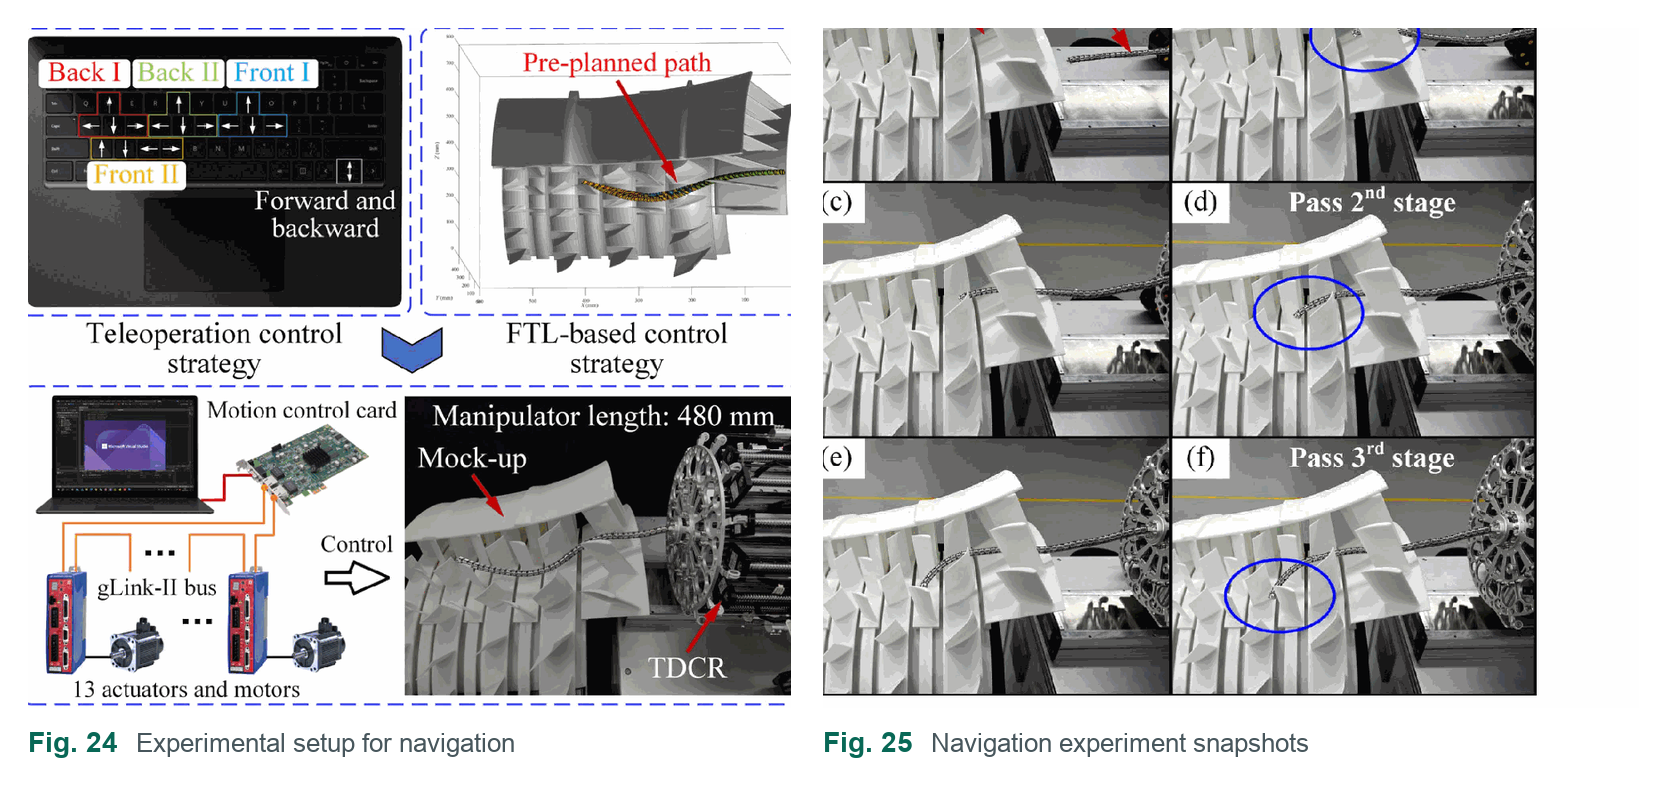
Yang et al., 2024, Figs. 24–25: experimental setup and navigation through an aero-engine blade mock-up.▶480p
CACM2024

Contact-aided continuum robot

Internal contact-aided compliant mechanisms improve a slender manipulator’s resistance to twisting and compression buckling.

Laboratory validationRead case
Nested continuumMechanisms
Nested continuum2026

Nested continuum robot

Nested tendon-driven and concentric-tube structures use axial sliding to adjust a continuum robot’s configuration and stiffness.
Design, modeling and experimentsRead case
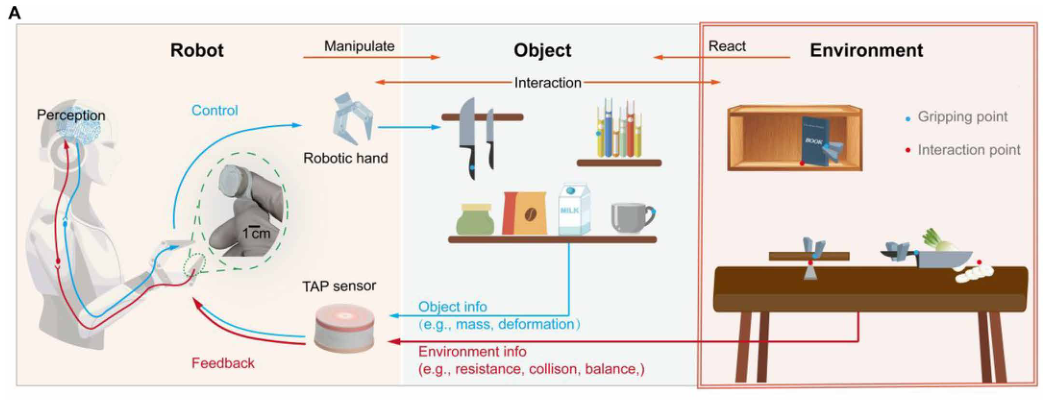
Wang et al., 2026, Fig. 1A: contact feedback for environment-in-the-loop manipulation.▶540p
TAP2026

TAP: torque, angle and pressure for tactile feedback

Combined tactile measurements provide contact-state feedback for placement, stacking and cutting experiments without vision.
Manipulation experimentsRead case
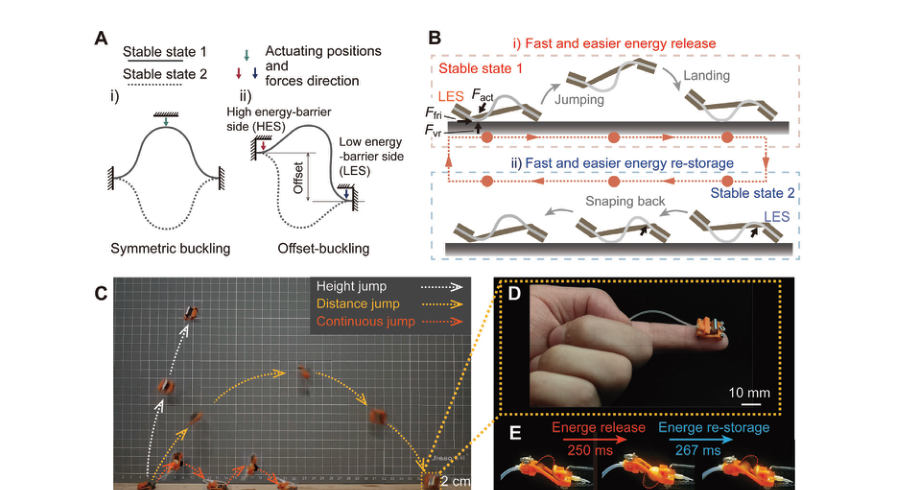
Guo et al., 2024, Fig. 1A–E: bistable mechanism, motion sequences and a fingertip-scale prototype.▶540p
BATE2024

Insect-scale bistable jumper

Tunable energy barriers control storage and release to produce multiple jumping modes at insect scale.
Laboratory prototypeRead case
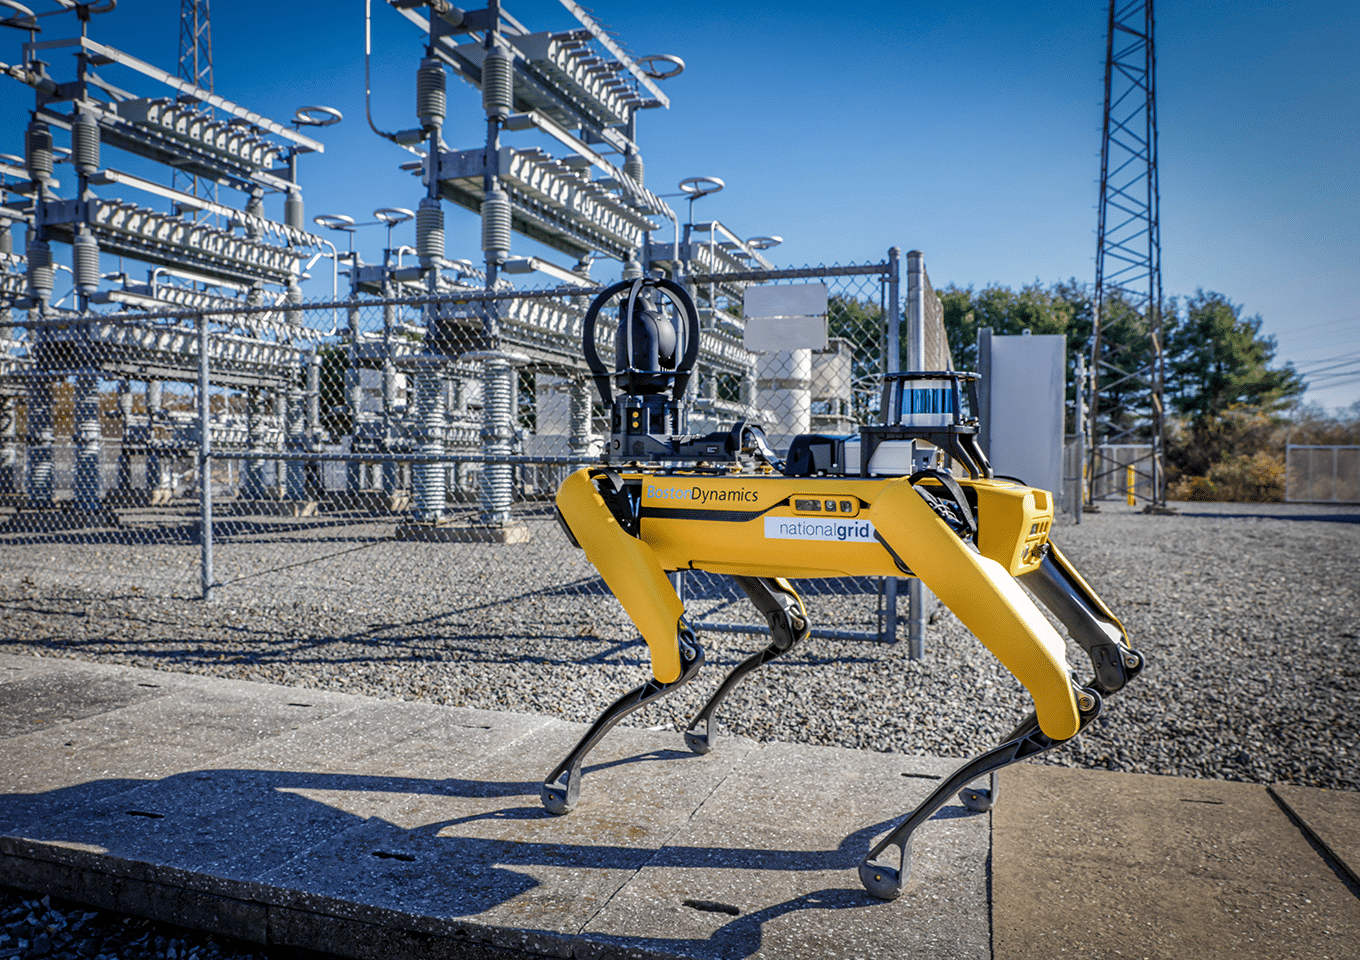
Spot outside the Sandy Pond converter station.▶Video
Spot · National Grid2023

Spot: remote inspection in an operating converter station

Visual and thermal inspection in an energised valve hall inaccessible to personnel.
Used in site inspection routinesRead case
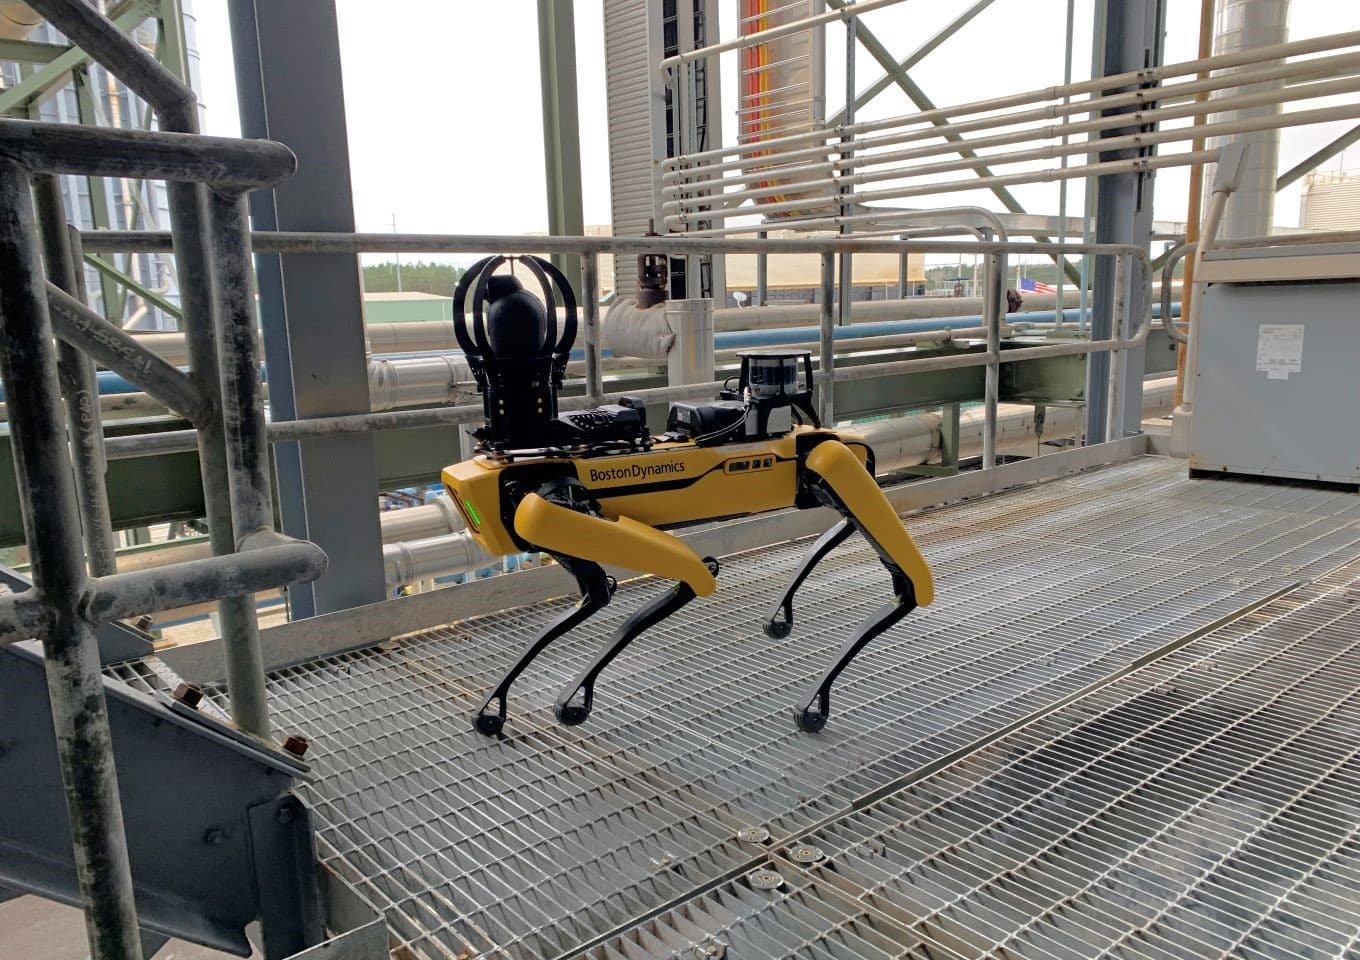
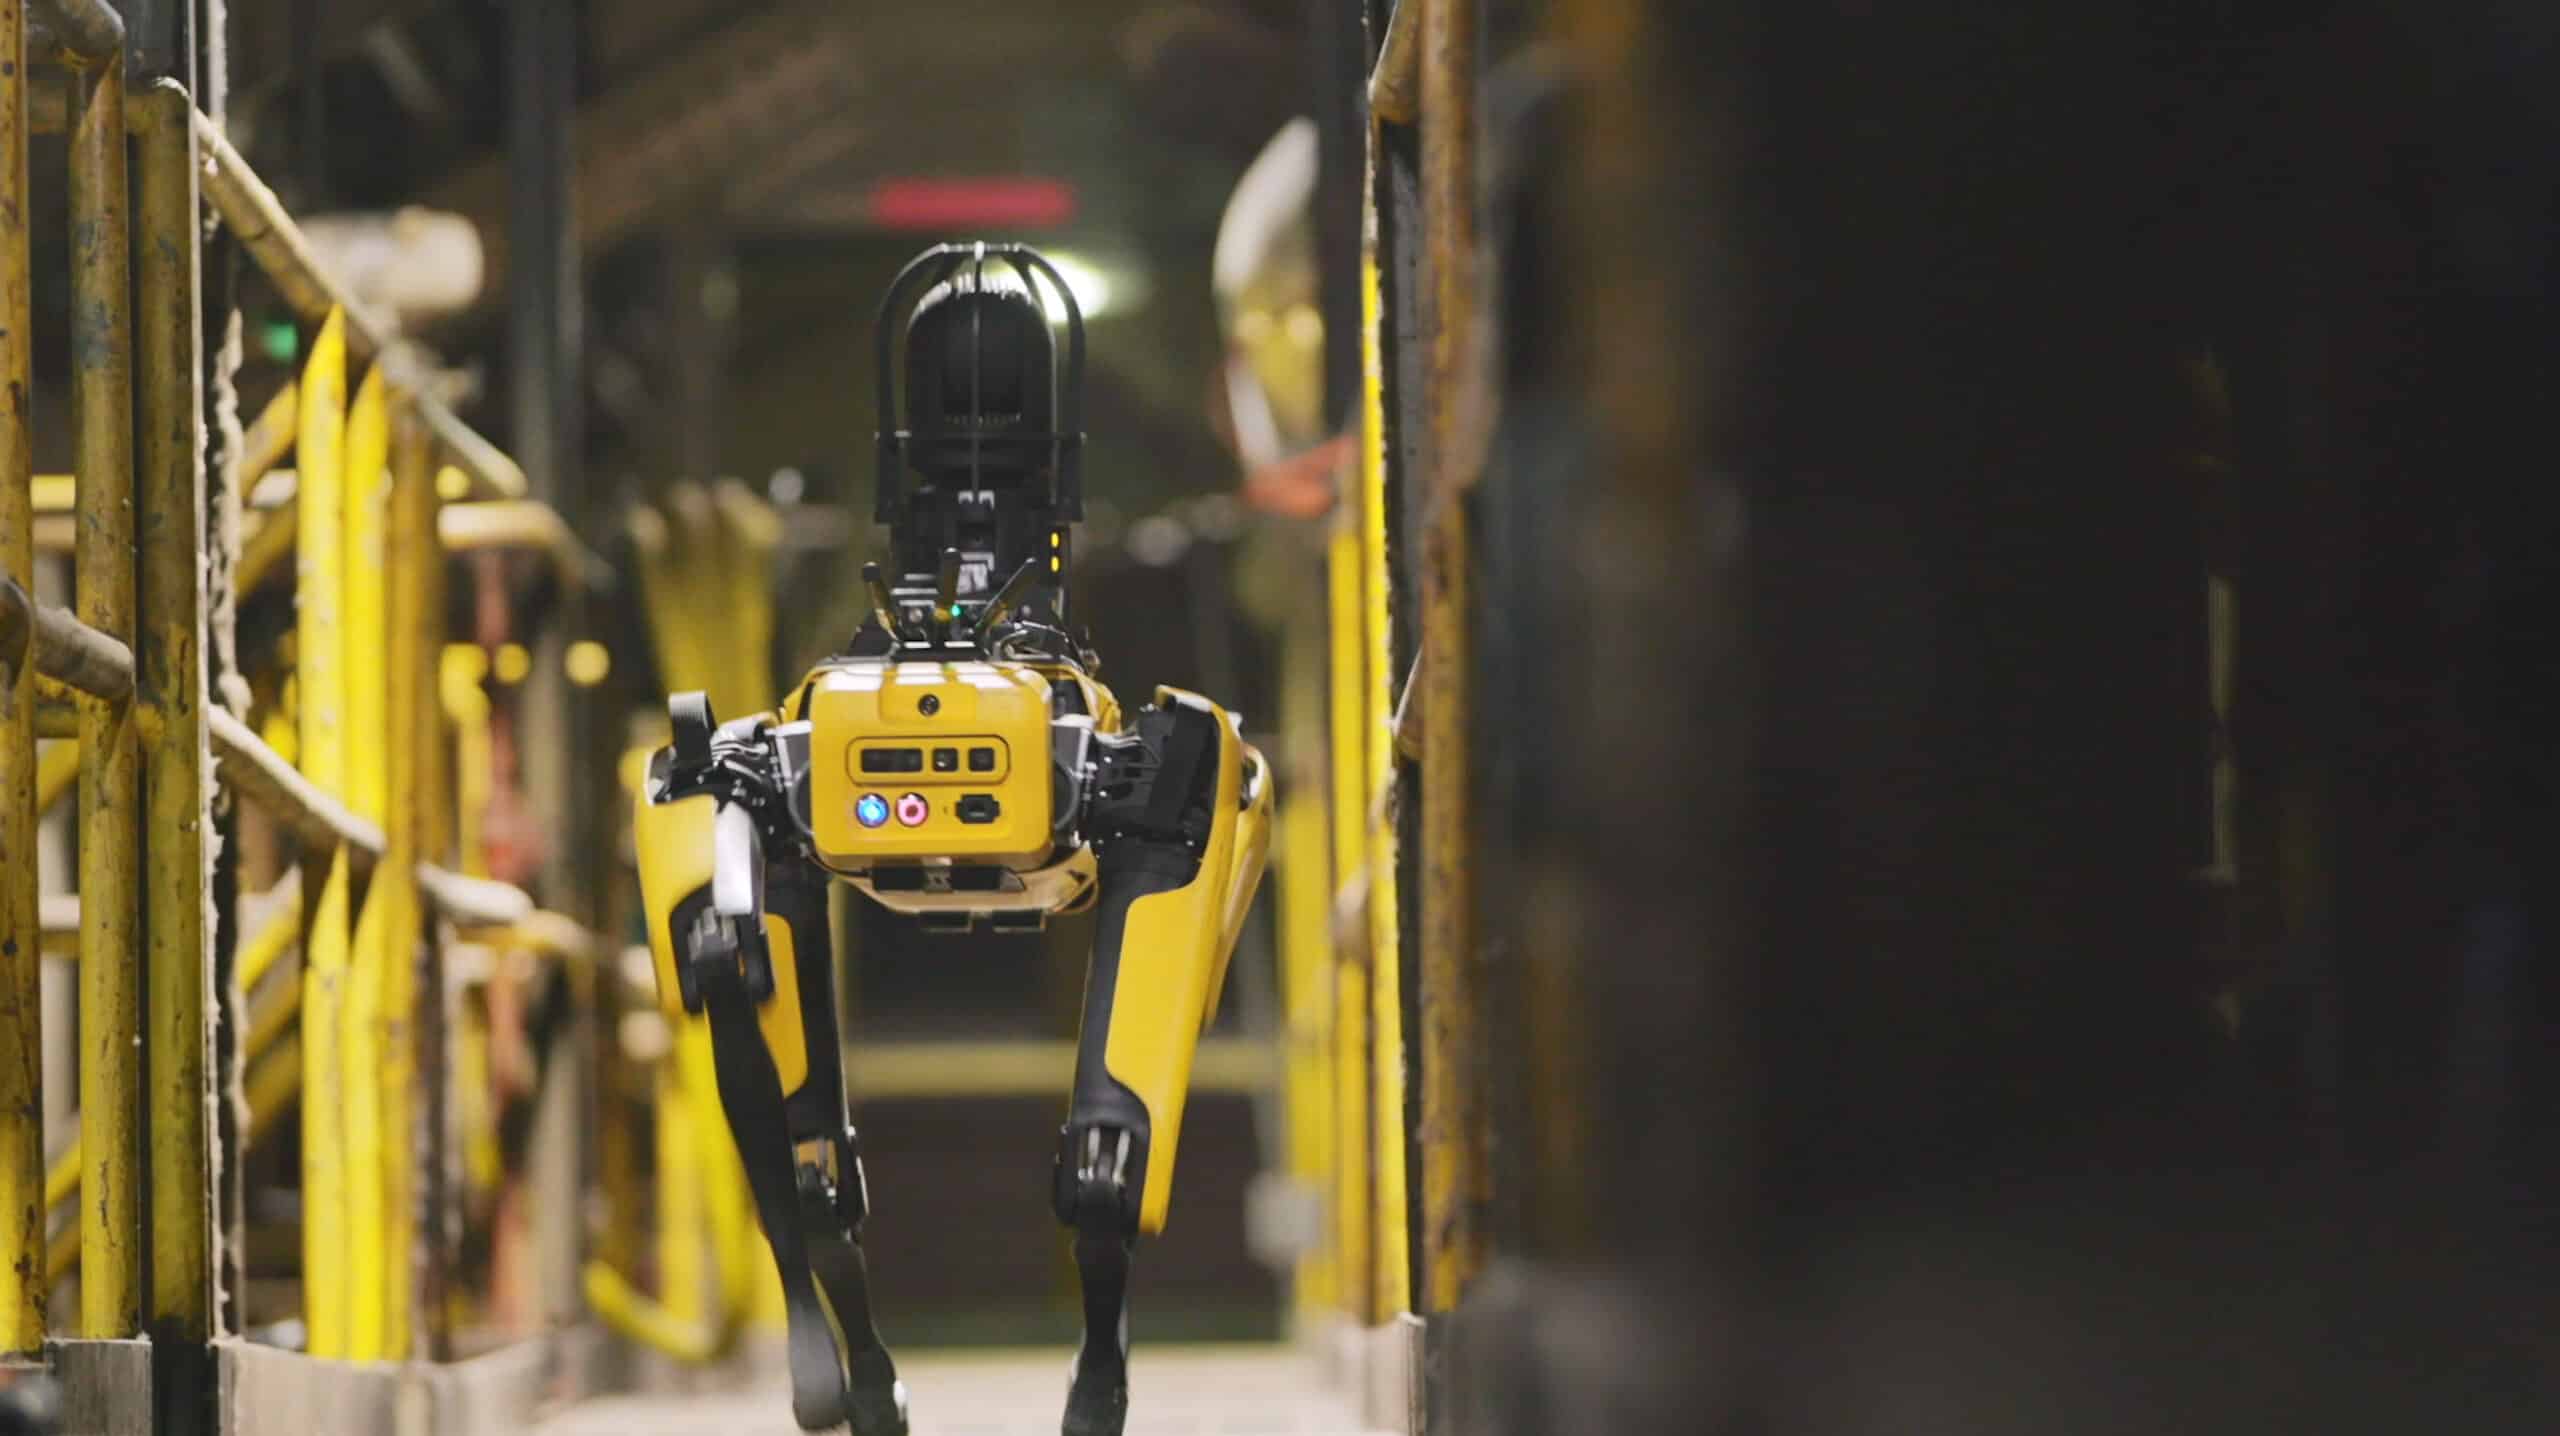
Spot on grated platforms at the power plant.
Spot · Southern Company2023

Spot: thermal and gauge inspections at a gas-fired power plant

Collecting heat-recovery steam-generator thermograms and temperature-gauge images across industrial stairs and platforms.
Power-plant field pilotRead case
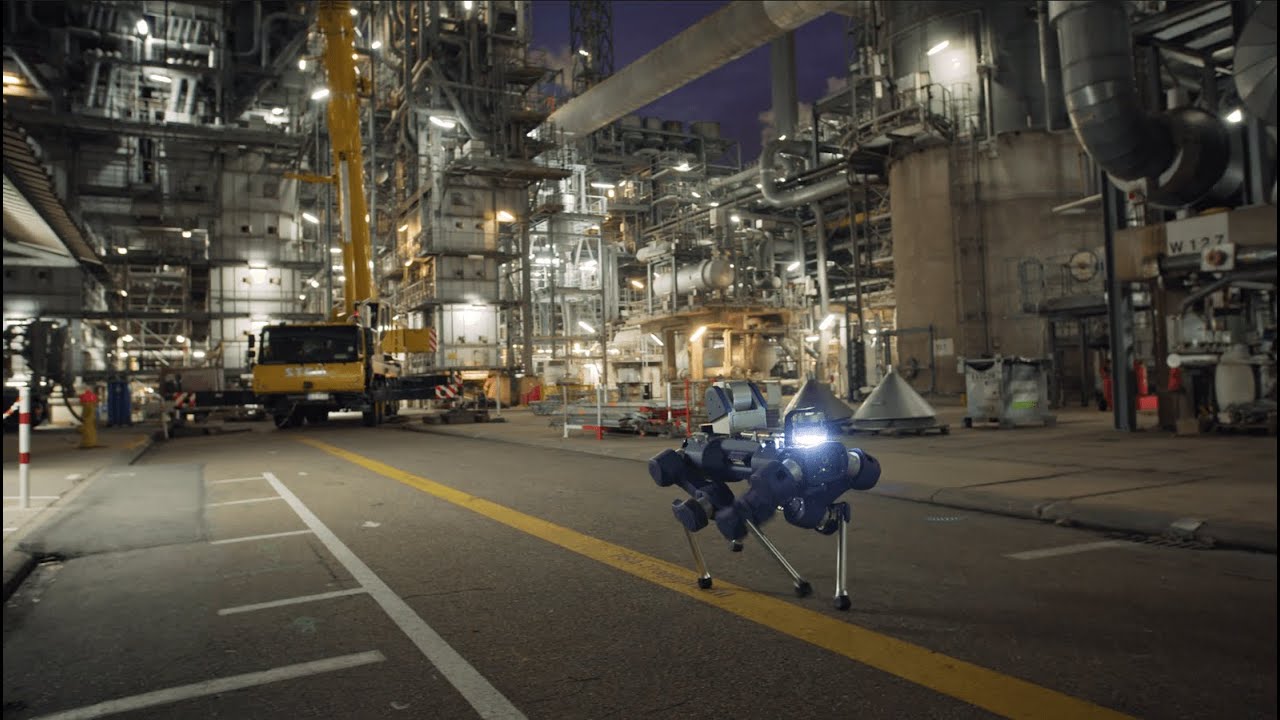
Spot in a passage at a bp industrial facility.
Spot · bp2020

Spot: from an industrial test site to a refinery

Trials at a simulated industrial site and Whiting refinery examined mobility through narrow passages, grating and stairs.
Industrial testing and field trialRead case
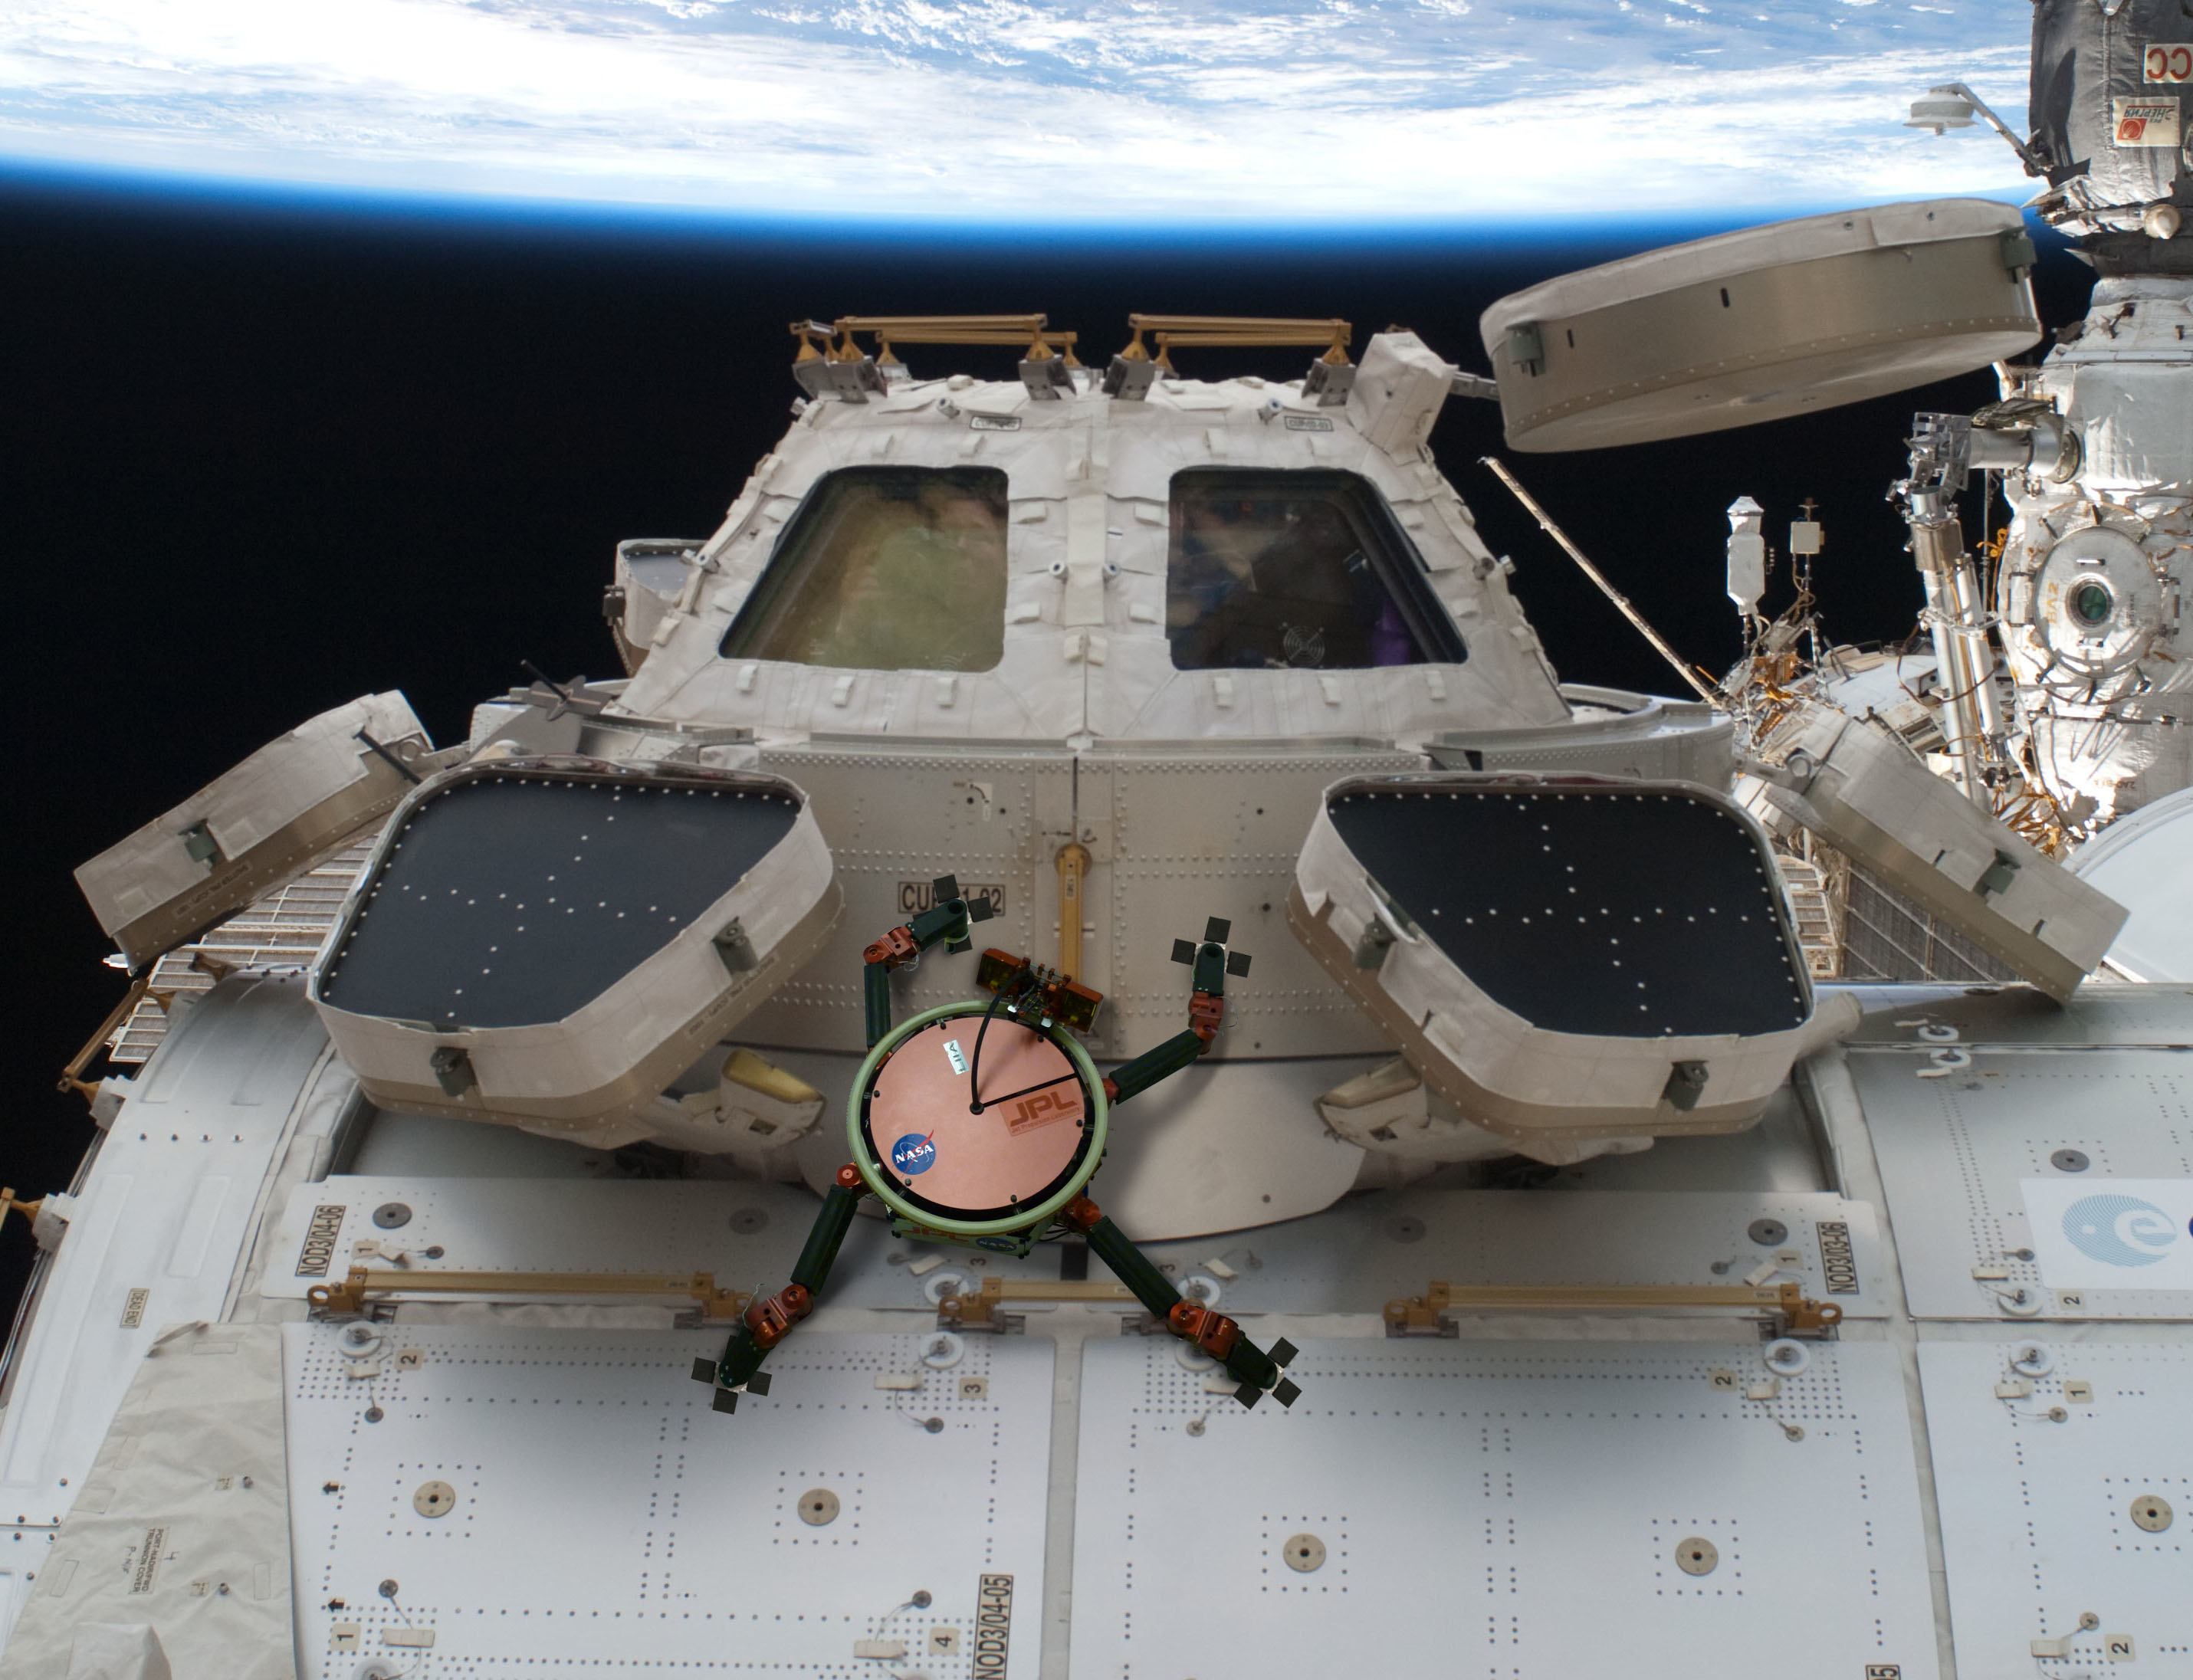
ANYmal X field tests at BASF; official video cover.▶Video
ANYmal X · BASF2023

ANYmal X: multi-level inspection in a chemical plant

Field tests at BASF Ludwigshafen examined automated inspection of gauges, pumps and tanks.
Chemical-plant field testsRead case
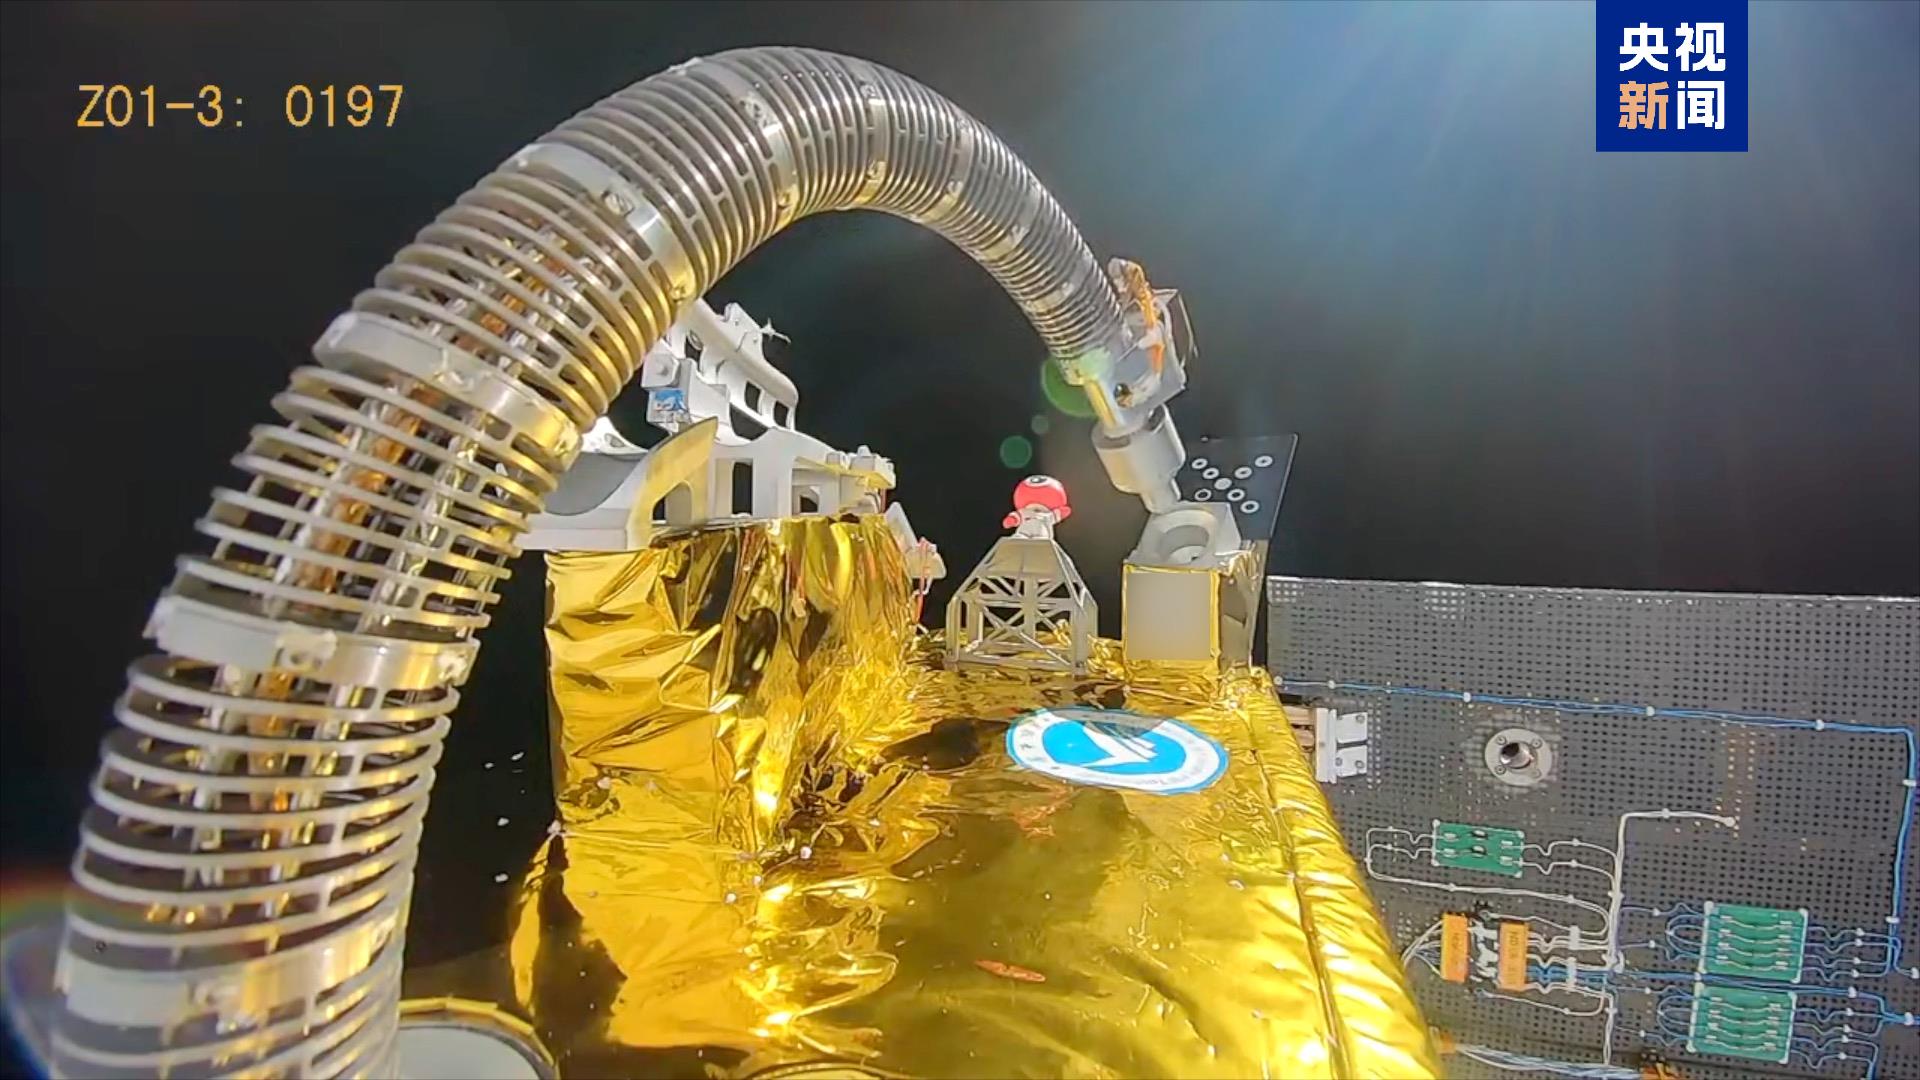
Concept illustration of LEMUR working on the station exterior.▶Video
JPL · LEMUR / Gecko2014–2015

LEMUR and gecko-inspired adhesion for spacecraft surfaces

Adhesion, locomotion and grasping studied on spacecraft-surface mock-ups and in microgravity tests.
Ground and simulated-microgravity validationRead case
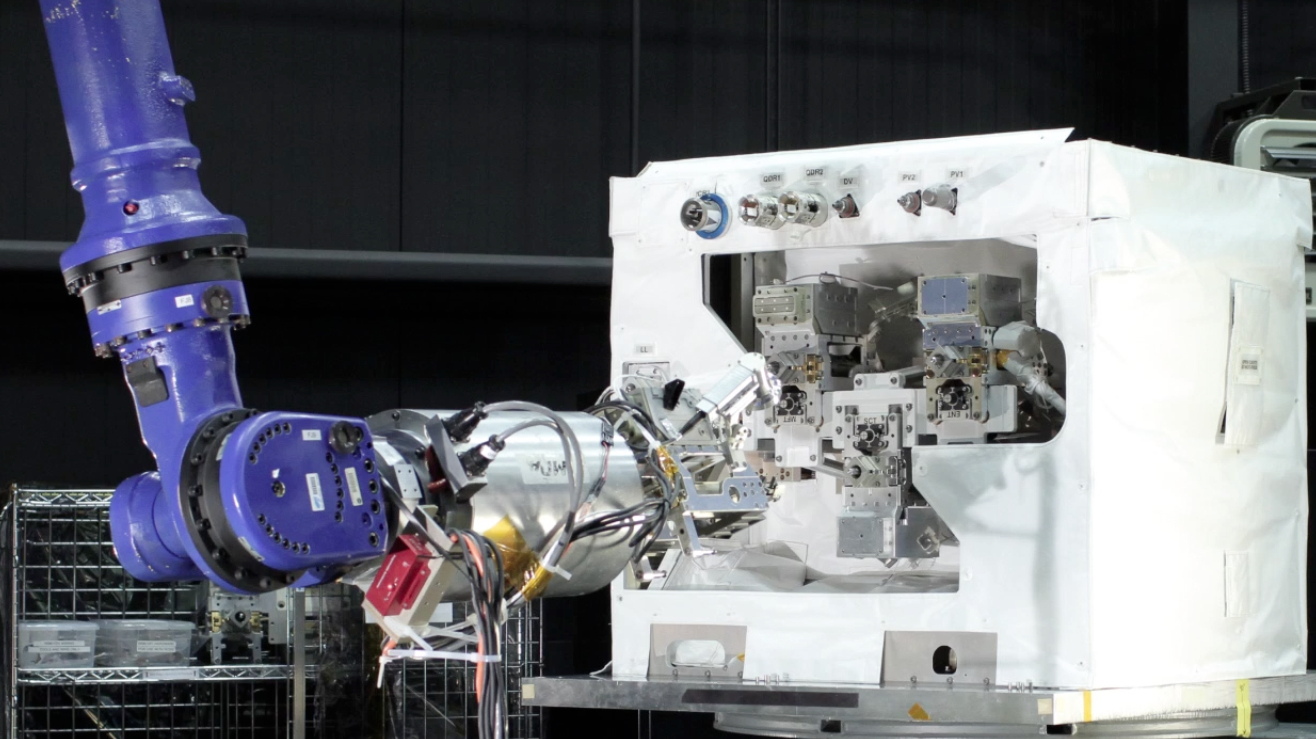
Space continuum arm shown in the CCTV report.▶Video
清华 SIGS · 西垣0号2026

A space continuum arm: orbital technology tests for refuelling

Orbital tests aboard Xiyuan-0 examined simulated refuelling and compliant manipulation.
Orbital technology demonstrationRead case
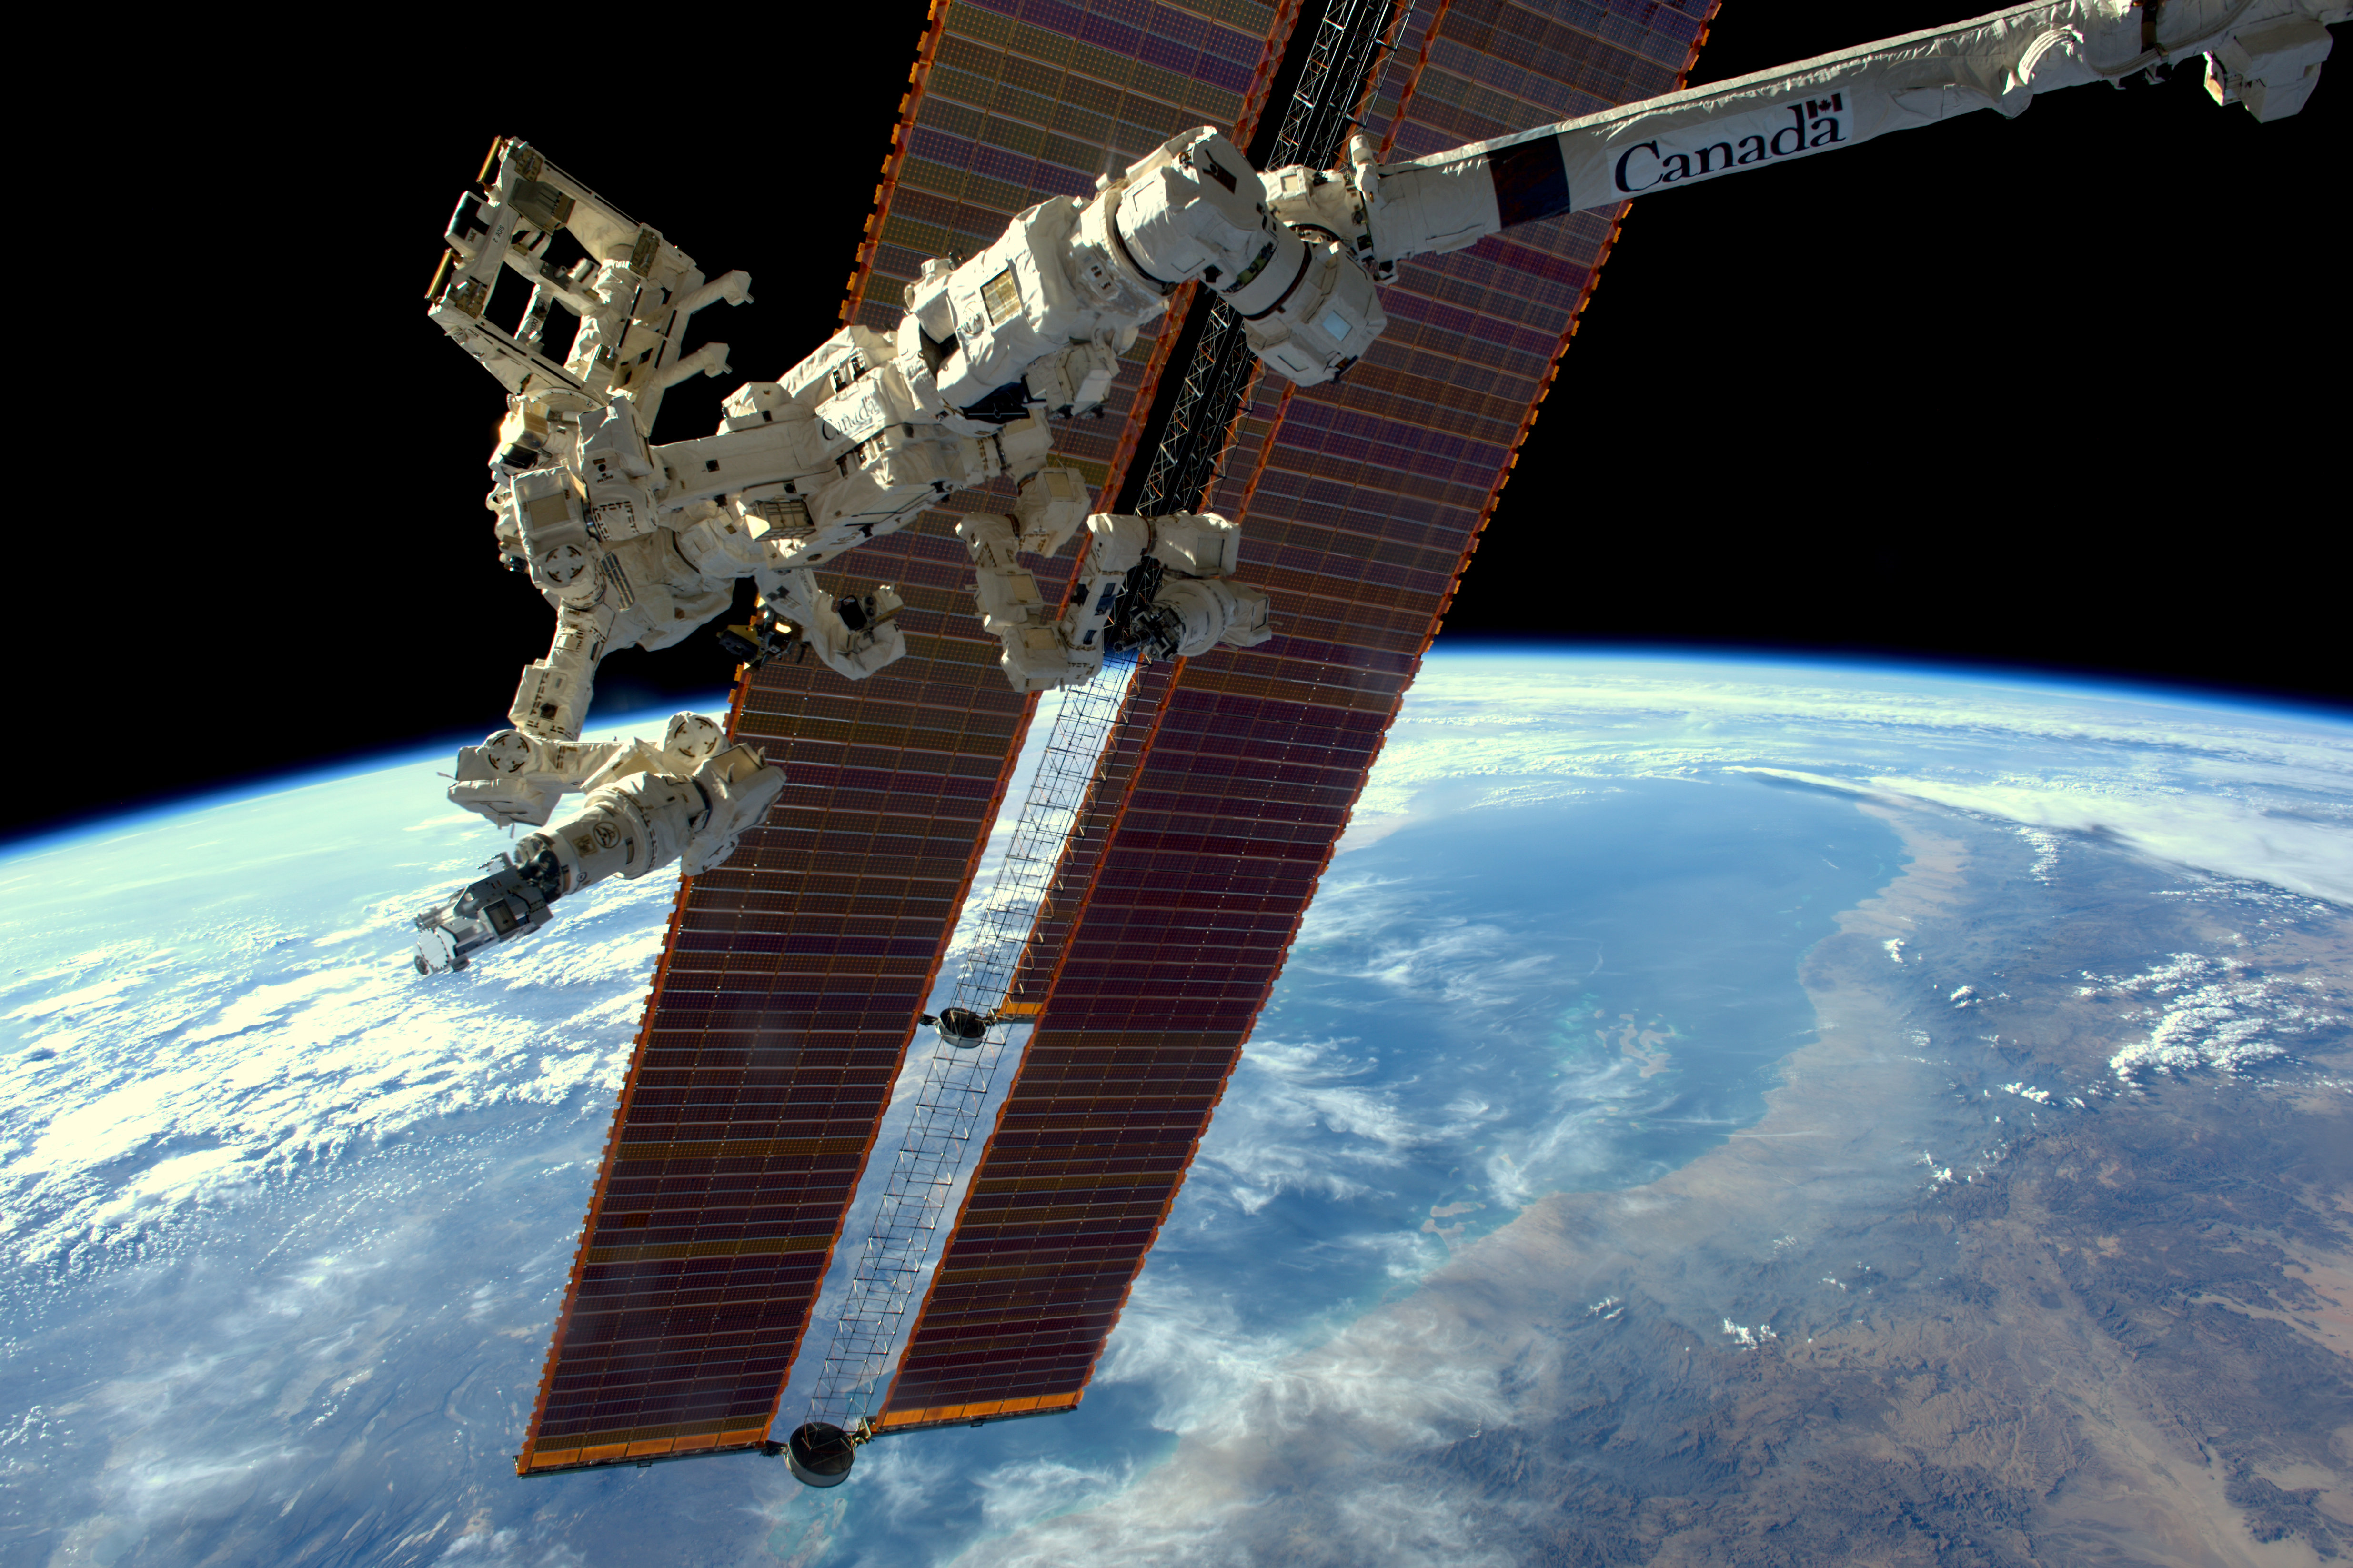
Tool and experiment-module image from NASA’s RRM mission video.▶Video
NASA / CSA · RRM2011–2013

Dextre and RRM: orbital servicing and fluid transfer

Removing caps, operating valves and transferring ethanol on an external station experiment module.
Orbital demonstration on the ISSRead case
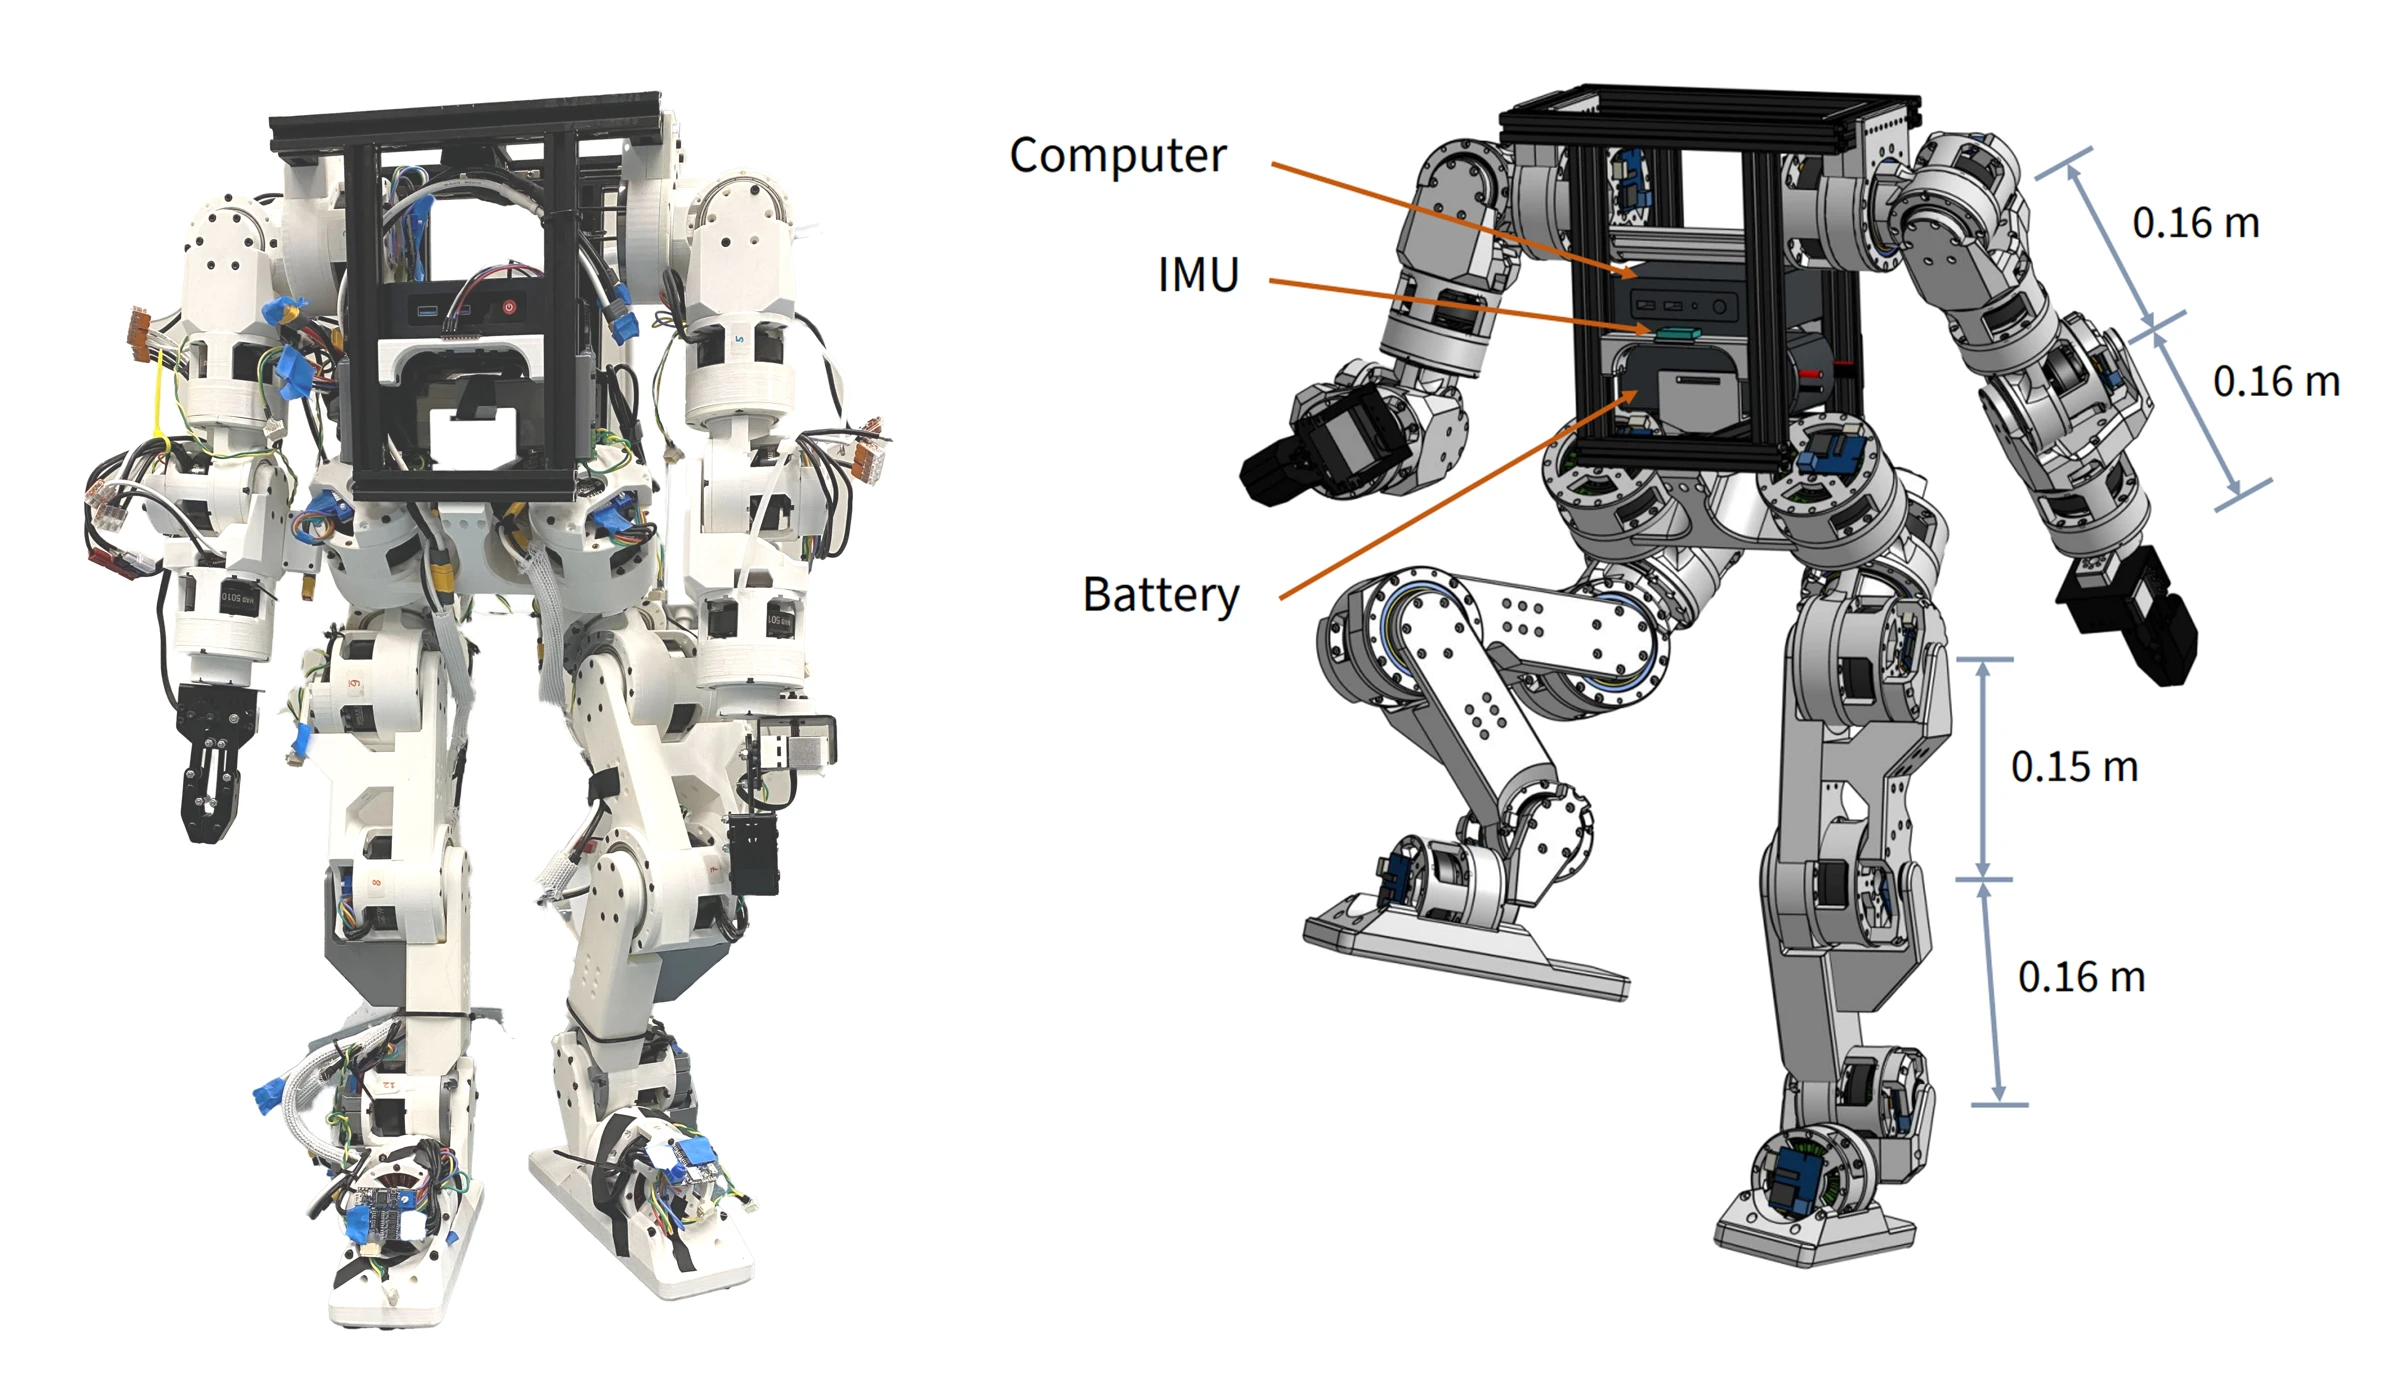
Dextre carrying RELL outside the ISS in 2017.
NASA / CSA · RELL2015–2020

RELL and Dextre: locating external ammonia leaks on the ISS

A robot-mounted gas detector surveys the station exterior for cooling-system leaks.
Documented orbital leak localisationRead case
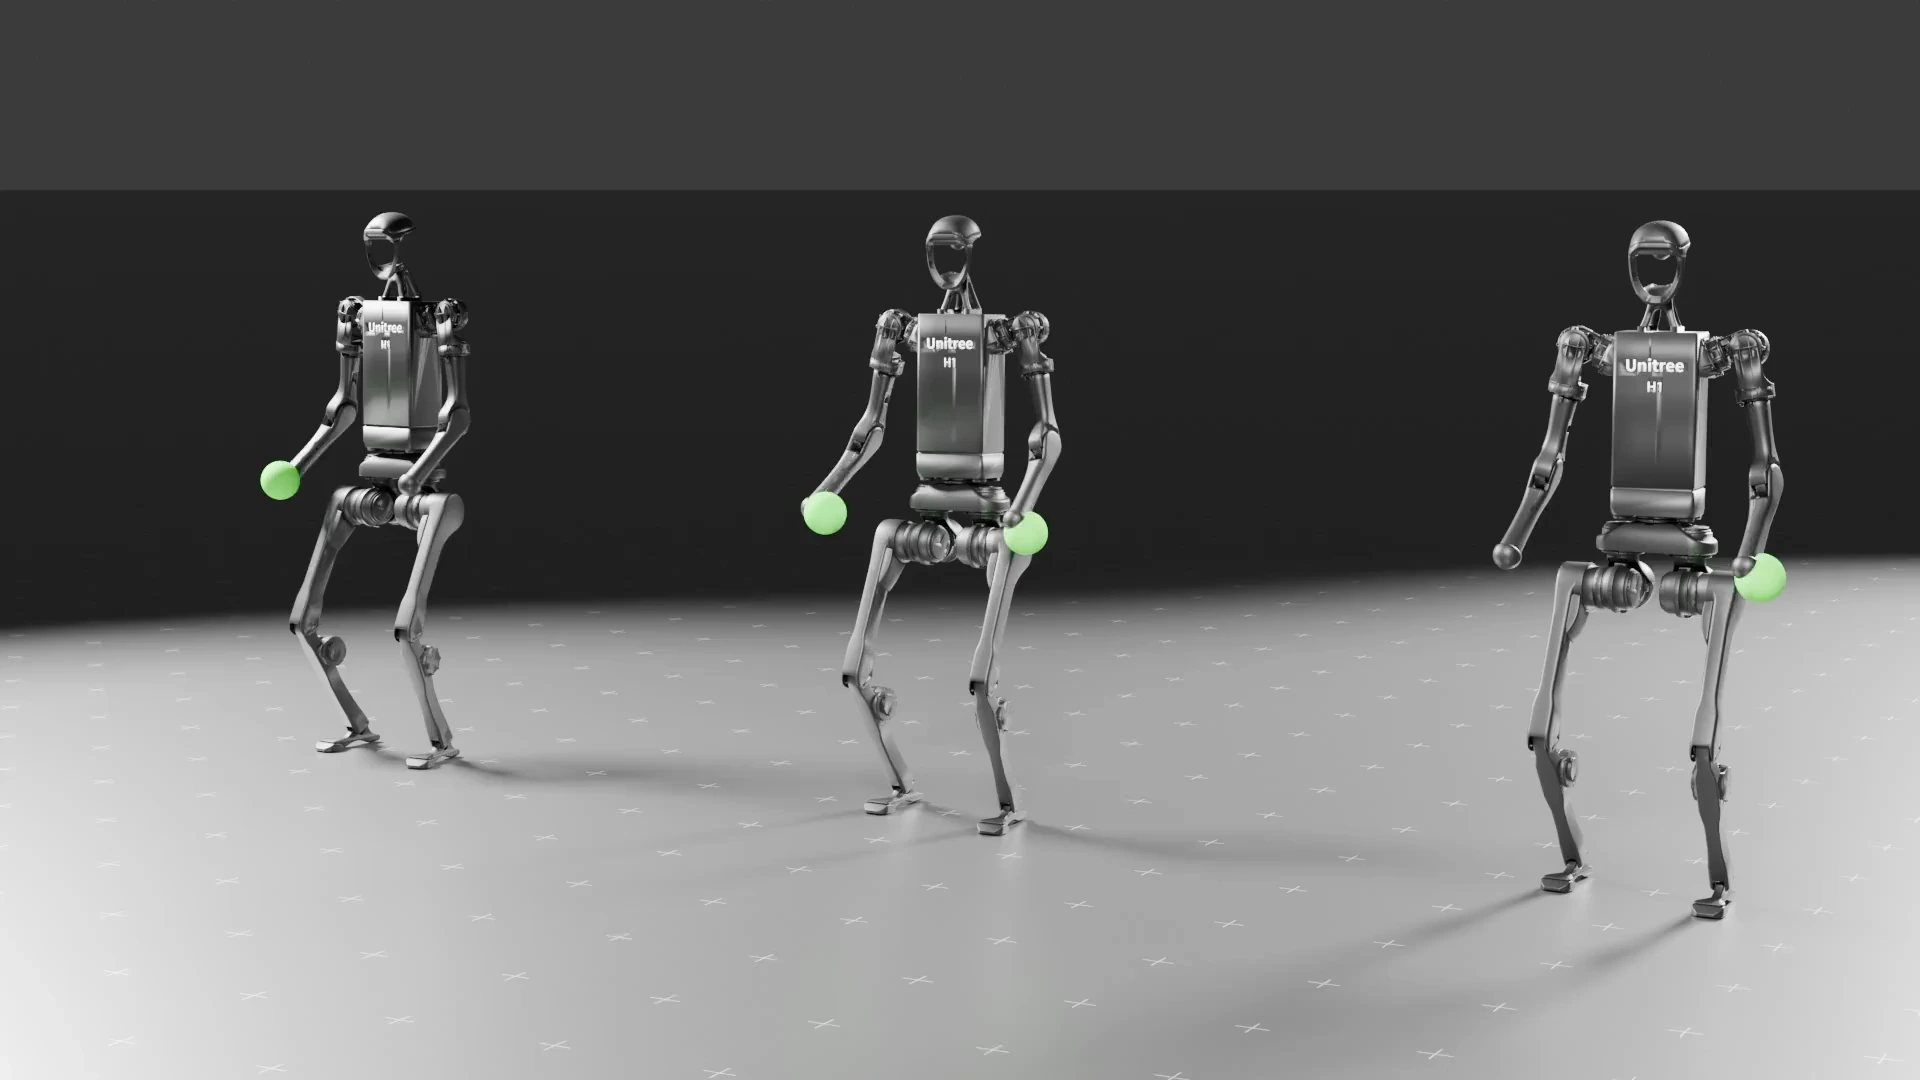
Berkeley Humanoid Lite project image showing hardware and designs in different configurations.▶720p
Berkeley Humanoid Lite2025

Berkeley Humanoid Lite: a reproducible humanoid platform

Open hardware and learning-based control, from 3D-printed gearboxes to arm manipulation and bipedal walking.
Research prototype and hardware experimentsRead case
Frame from the official HOVER recording: left/right hand-position control on Unitree H1.▶1080p
HOVER2024–2025

HOVER: switching whole-body control modes within one policy

A humanoid policy tracks hand, head and root commands while coordinating upper and lower body motion.
Hardware control experimentsRead case
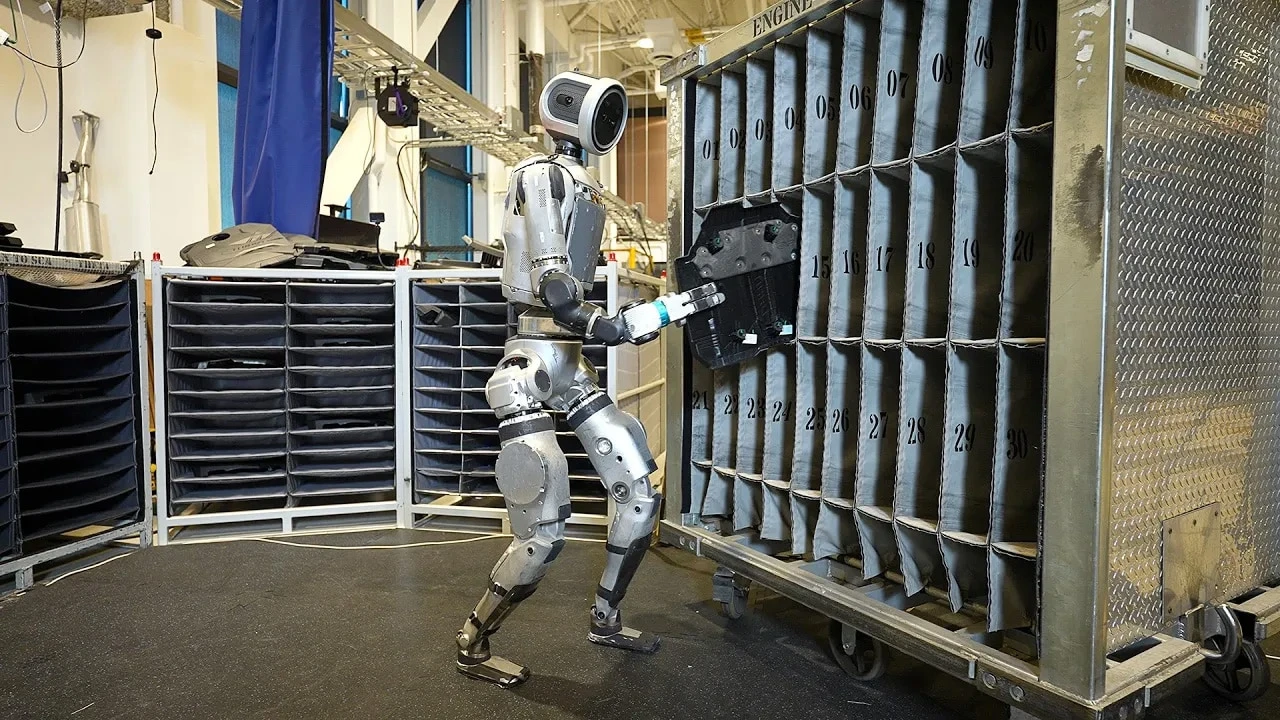
Official Boston Dynamics image: Atlas transferring engine covers in an industrial test setting.▶Video
Atlas · Hands On2024

Atlas: autonomous handling of engine-cover parts

Moving parts between supplier containers and a sequencing dolly from a list of bin locations.
Manufacturer hardware demonstrationRead case
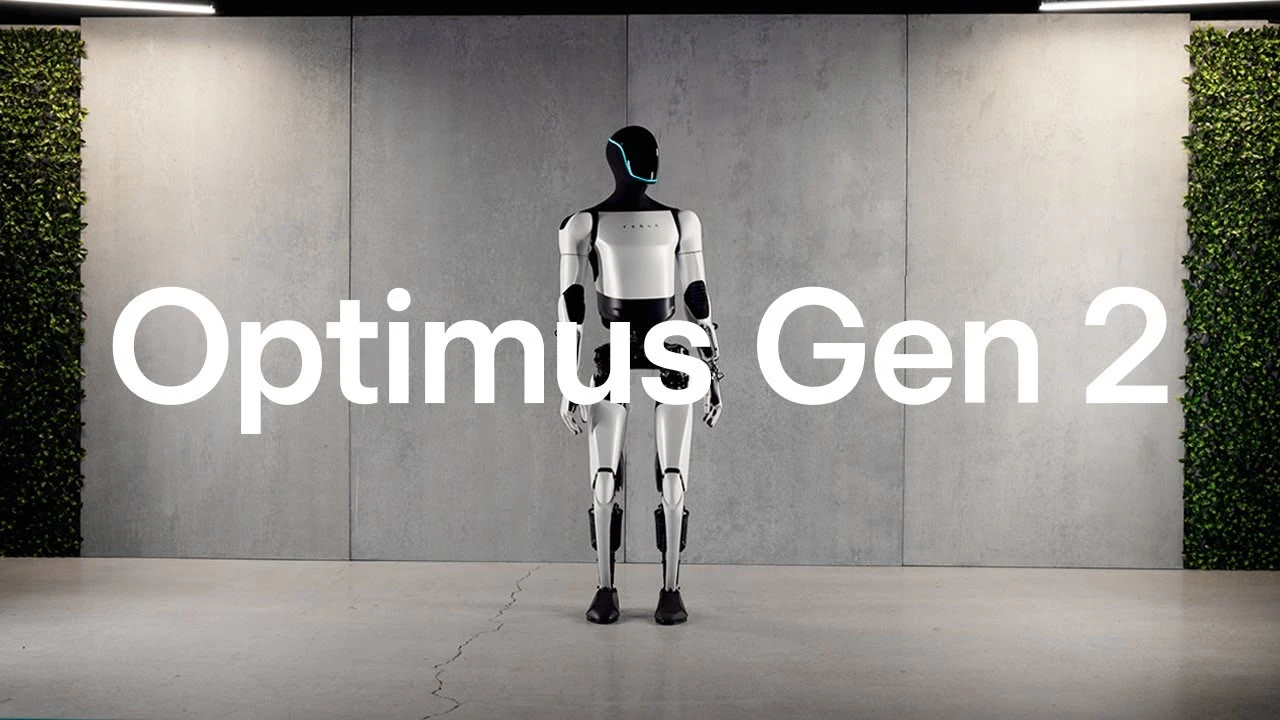
Cover from Tesla’s official Optimus Gen 2 recording.▶Video
Tesla · Optimus Gen 22023

Optimus Gen 2: walking, balance and hand manipulation

Tesla’s official video shows revised actuators, walking and hand motion, including gentle handling of an egg.
Manufacturer prototype demonstrationRead case
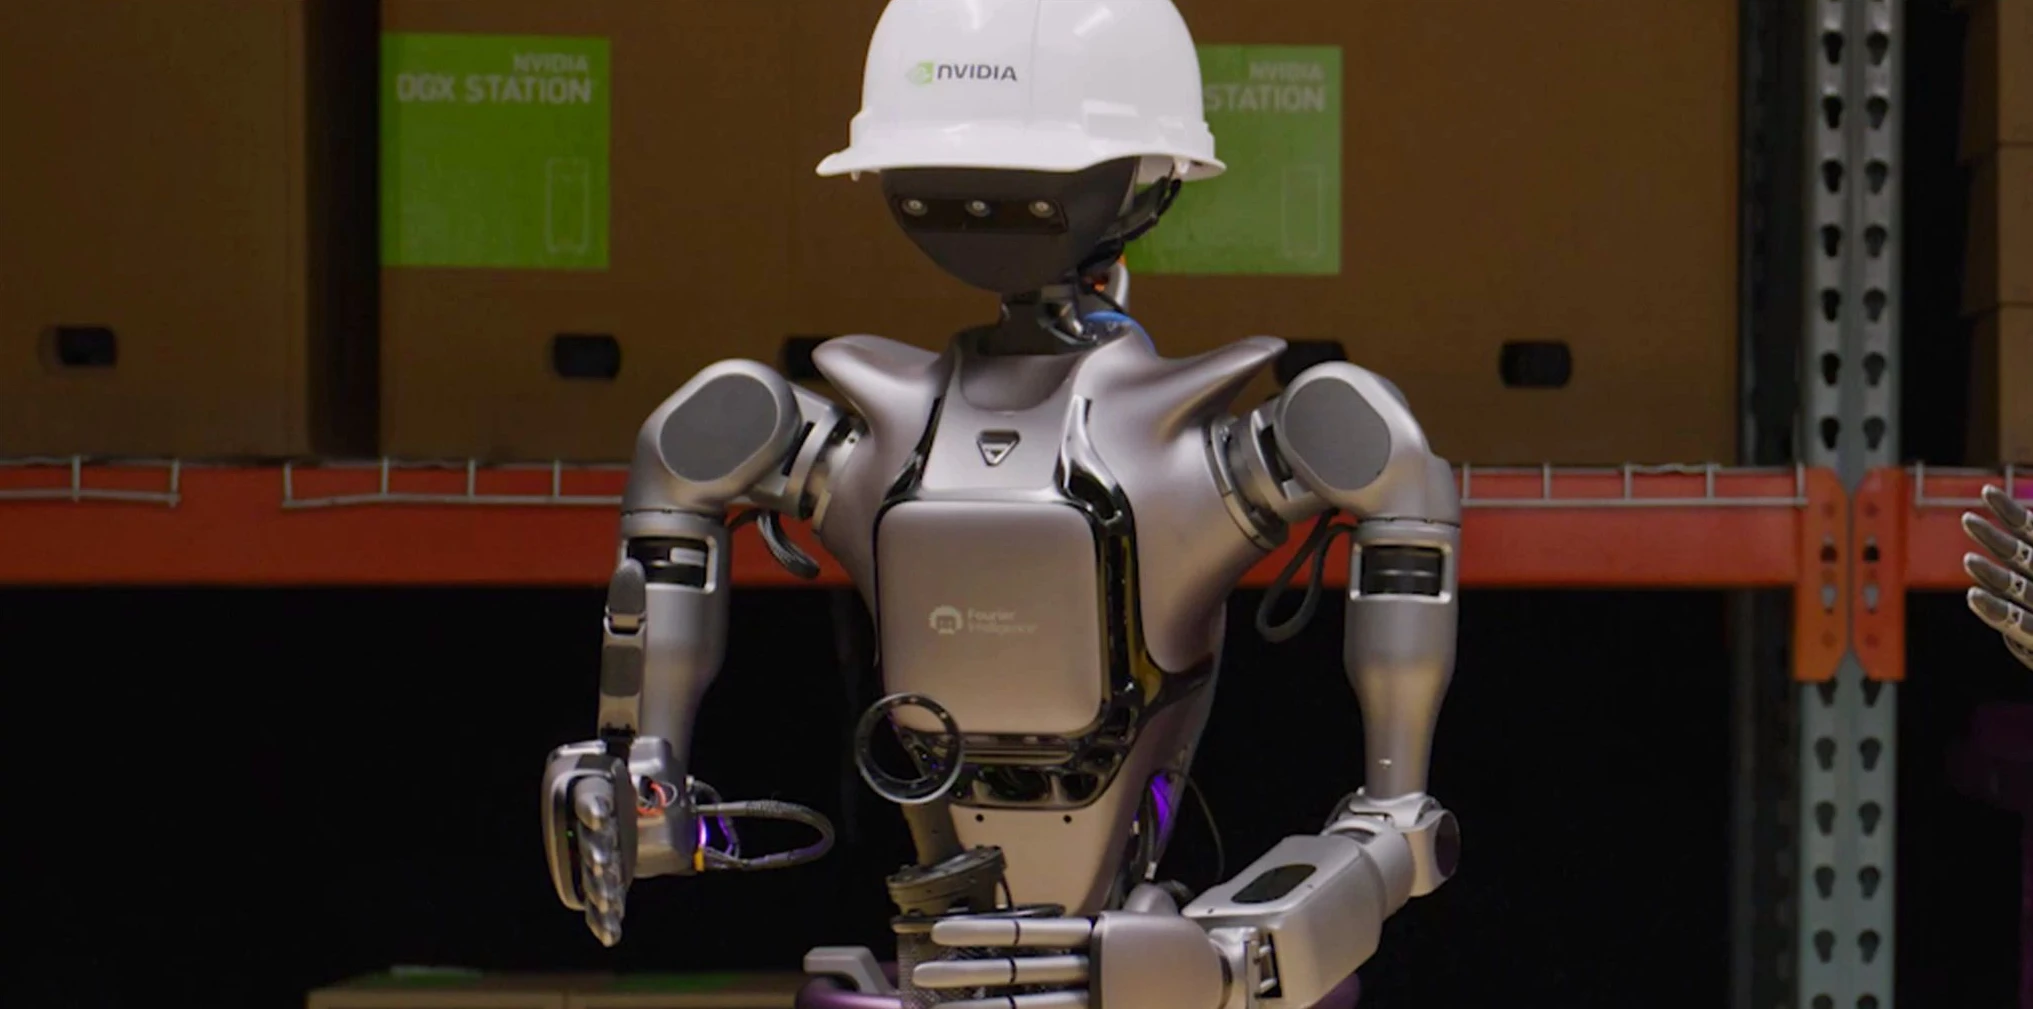
Official NVIDIA hardware-manipulation example: bimanual tasks on Fourier GR1.
NVIDIA · GR00T N12025

GR00T N1: bimanual humanoid manipulation

Studying pick-and-place, handovers and bimanual coordination with hardware demonstrations, simulation and task-specific adaptation.
Model and hardware manipulation experimentsRead case
Frame from Google DeepMind’s official whole-body control recording: carrying a container while moving.▶1080p
Google DeepMind · Gemini Robotics2026

Gemini Robotics: coordinating whole-body movement

An official whole-body demonstration shows a robot carrying a container while moving, linking instruction understanding with execution.
Official model demonstrationRead case
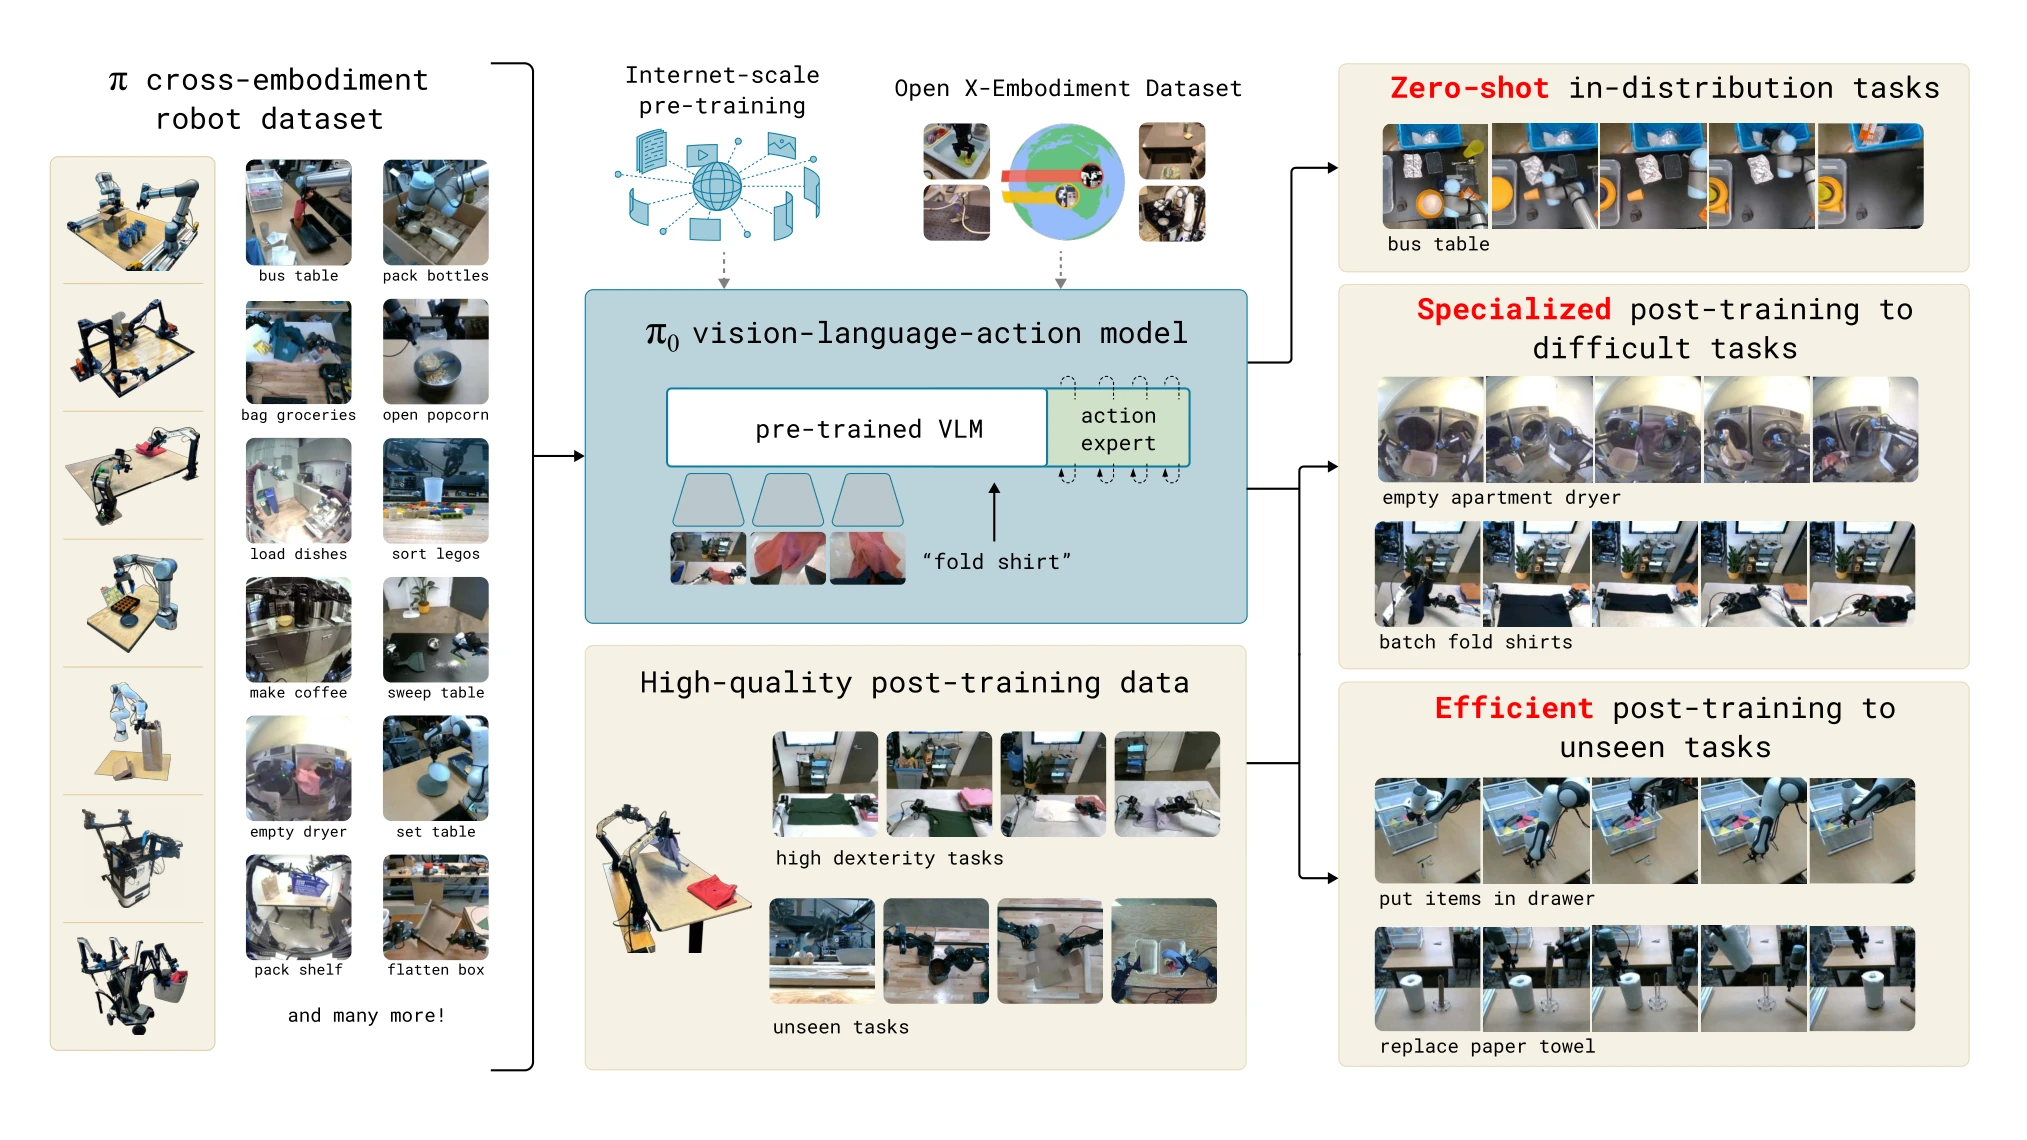
π₀ paper, Figure 1: cross-embodiment manipulation tasks and model overview.
Physical Intelligence · π₀2024

π₀: from language instructions to laundry handling

A cross-embodiment vision-language-action model studies folding laundry, clearing tables and assembling boxes.
Hardware manipulation researchRead case
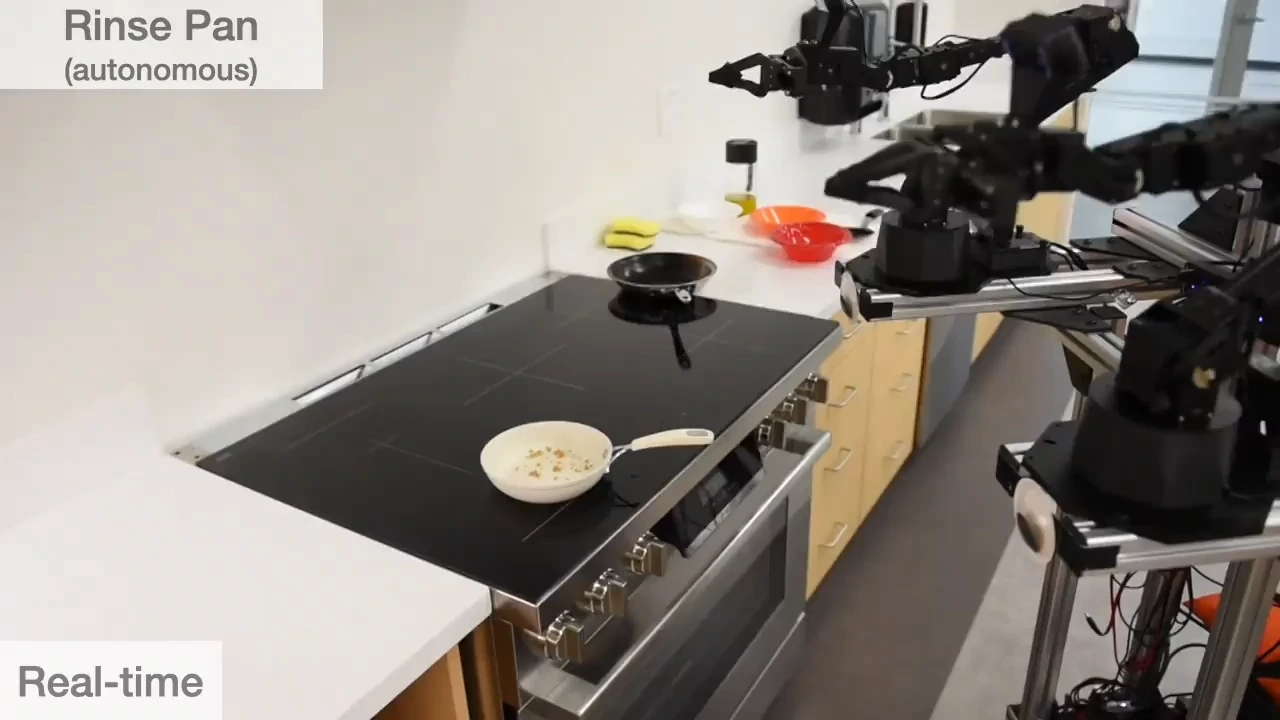
Frame from Mobile ALOHA’s official Autonomous Skills recording: rinsing a pan.▶720p
Mobile ALOHA2024

Mobile ALOHA: learning with two arms and a mobile base

Teleoperated demonstrations support learned mobile tasks such as opening cabinets, rinsing a pan and cooking.

Hardware imitation-learning experimentsRead case
No matching cases. Try another keyword or adjust the filters.

Each case links to its paper or official source, where you can check experimental conditions and how to use the images and code.

入微OPENRUWEI

A community for robotics in constrained spaces, with research and cases in maintenance, medical intervention, rescue, exploration, infrastructure inspection and orbital servicing.

Latest updatesContribute a resourceCommunity principlesopenruwei@163.com
Site activity
Page views
—
Visits
—

Loading activity

Counting method

Recording began on 2 October 2026; earlier traffic is excluded. Each visible page load that successfully reports an event counts as a page view. Visits group activity in the same browser within 30 minutes and are not unique visitors.

Counters use no cookies or device fingerprints. The database stores no IP addresses, page URLs or contact details; the browser stores only the last activity time. Do Not Track preferences are respected. Blocking, connection failures and automated traffic can affect the counts; these definitions differ from Cloudflare dashboard analytics.

OpenRuwei website QR codeScan to visit
© 2026 OpenRuwei · Robotics in constrained spacesCase images, videos and papers remain the property of their rights holders.