Skip to content
入微OPENRUWEI
HomeApplicationsProjectsResourcesContributeAbout
中文
CASE GALLERY / 02

Projects and cases

Robots on engine walls, in vessels, through rubble and inside ice crevasses.

21cases
17 videos
OPENRUWEI / PUBLIC CASES

HAMR-E on a curved engine-section wall; its tether is visible.▶1080p
Harvard · HAMR-E2018

HAMR-E: electroadhesive crawling on engine walls

Validate centimetre-scale locomotion on vertical, inverted and curved conductive surfaces.

Experimental locomotion validation, including an inverted demonstration in a curved commercial-engine sectionRead case
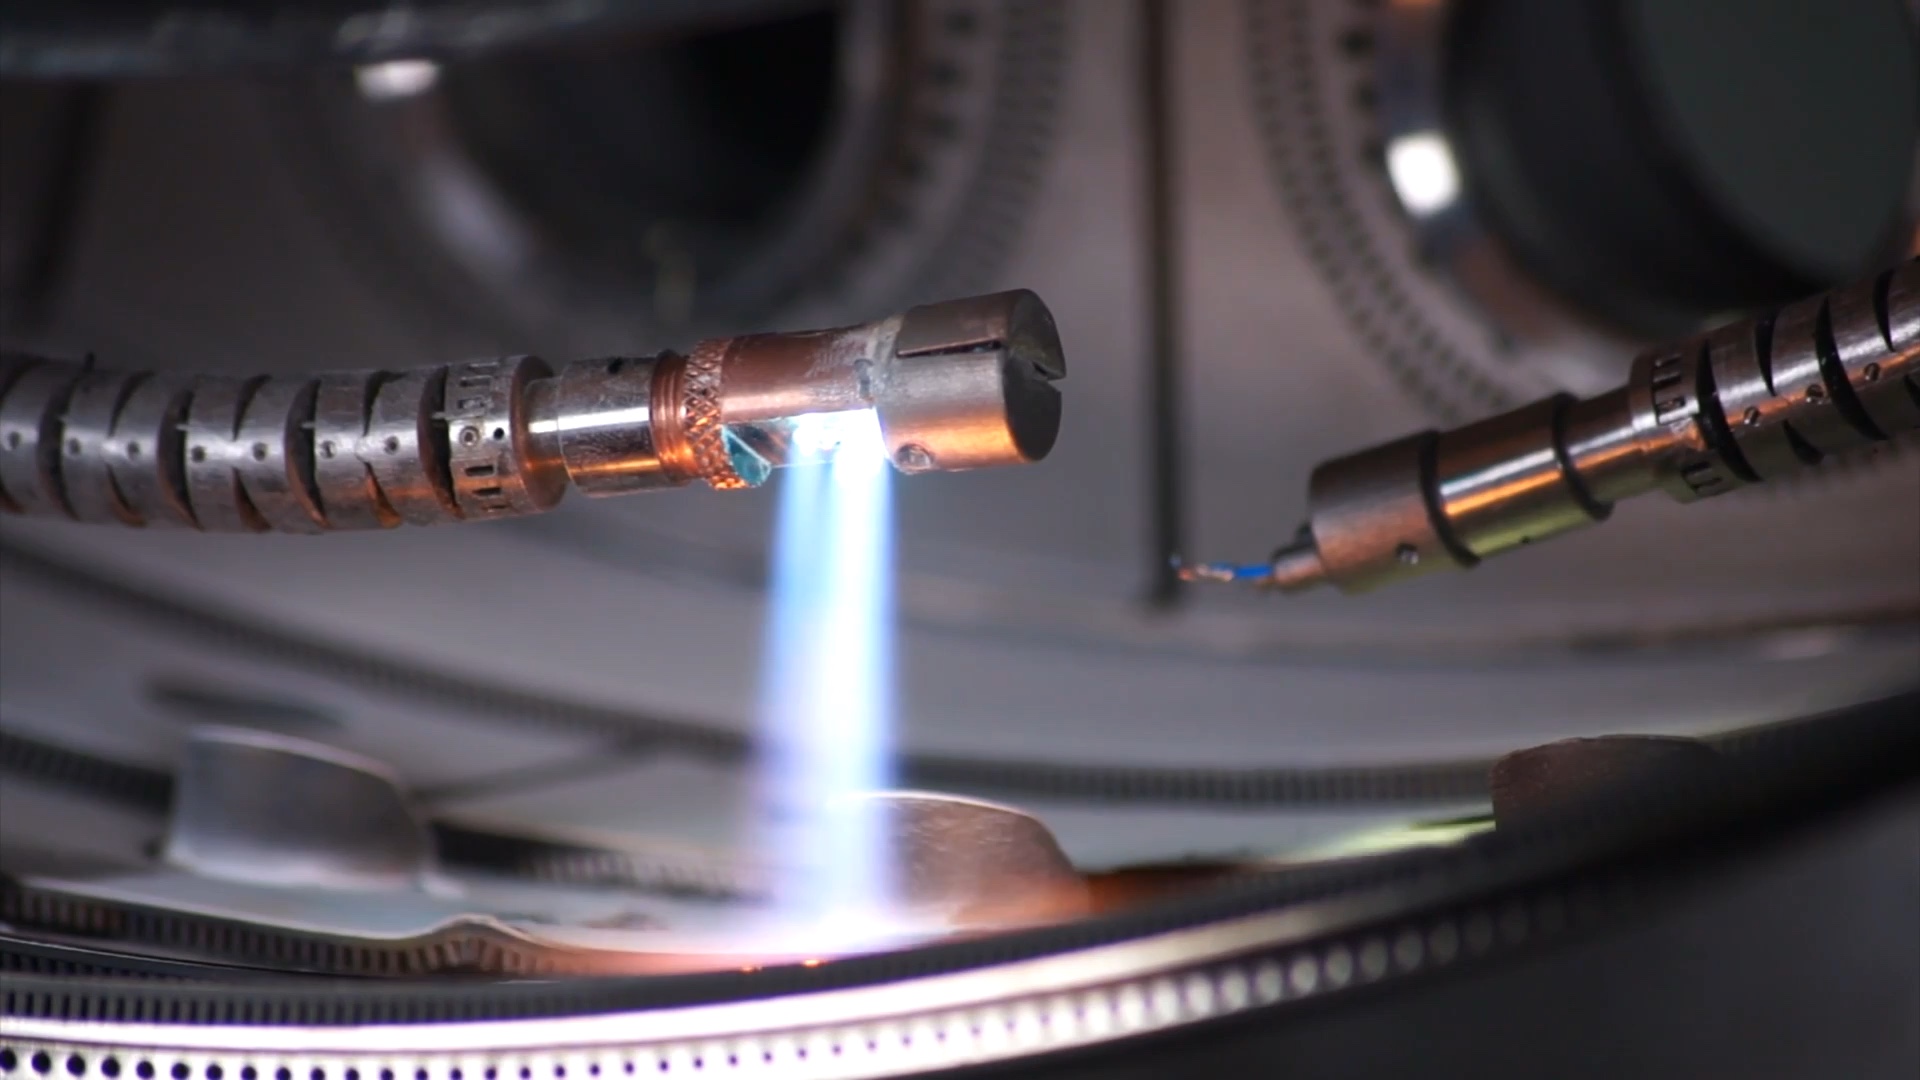
Official video frame: FLARE snake tips during a combustor flame-spray experiment (01:50).▶1080p
Rolls-Royce · FLARE2019

FLARE: twin snake robots patch thermal-barrier coatings

Reach combustor liners through limited access and patch damaged ceramic coatings.

Laboratory engine testsRead case
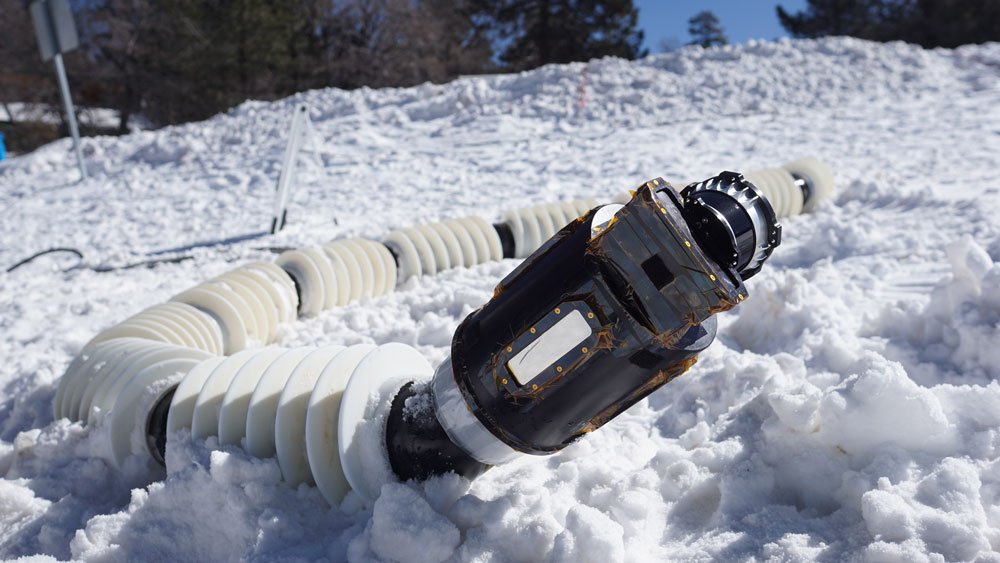
EELS prototype during snow tests in Southern California, February 2023.▶1080p
NASA JPL · EELS2024

EELS: a snake robot for passages through ice

A segmented body uses rotating screws for motion tests on ice, snow and sand.

Ground prototypes and glacier testsRead case
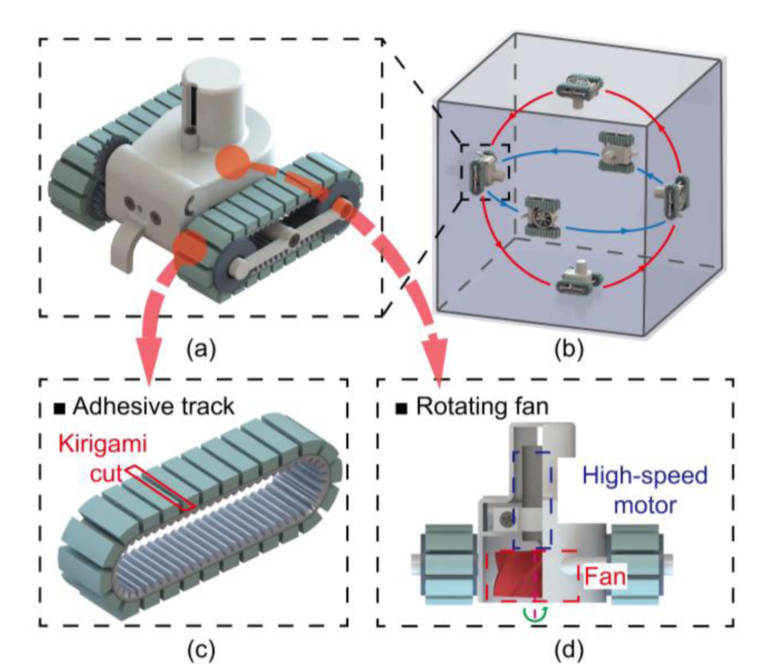
Sun et al., 2026, K-Track Fig. 1: kirigami adhesive tracks, fan and a wall-to-wall path.
K-Track2026

Miniature robot for wall-to-wall transitions

Kirigami-inspired adhesive tracks work with negative-pressure preload to cross changing surface geometries.

Experiments and engine-component testsRead case
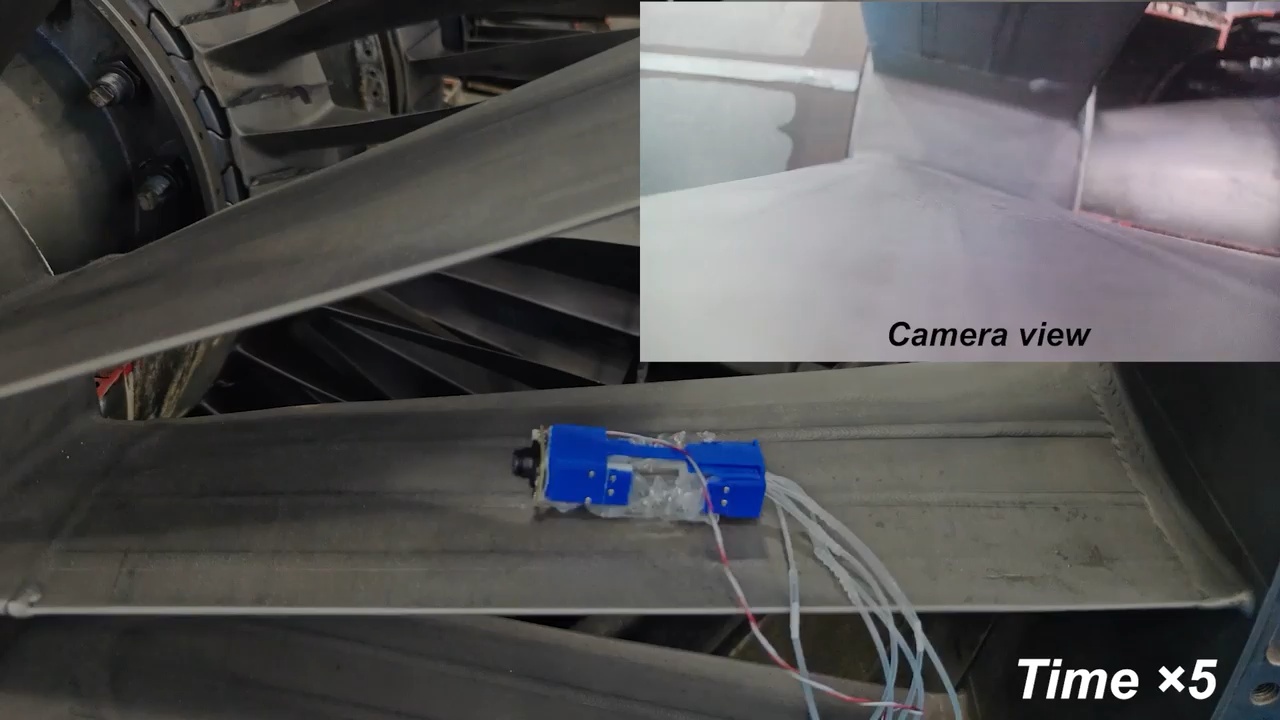
Guo et al., 2026, supplementary video at 79.988 s: the miniature crawler moves along a blade surface in a decommissioned JT8D engine, with its camera view at upper right. The source video is marked Time ×5.▶720p
TRACE2026

Miniature climbing robot with active compliance

A unified active-compliance mechanism adapts to varied surfaces, with visual-inspection tests inside a decommissioned engine.

Experiments and decommissioned-engine testsRead case
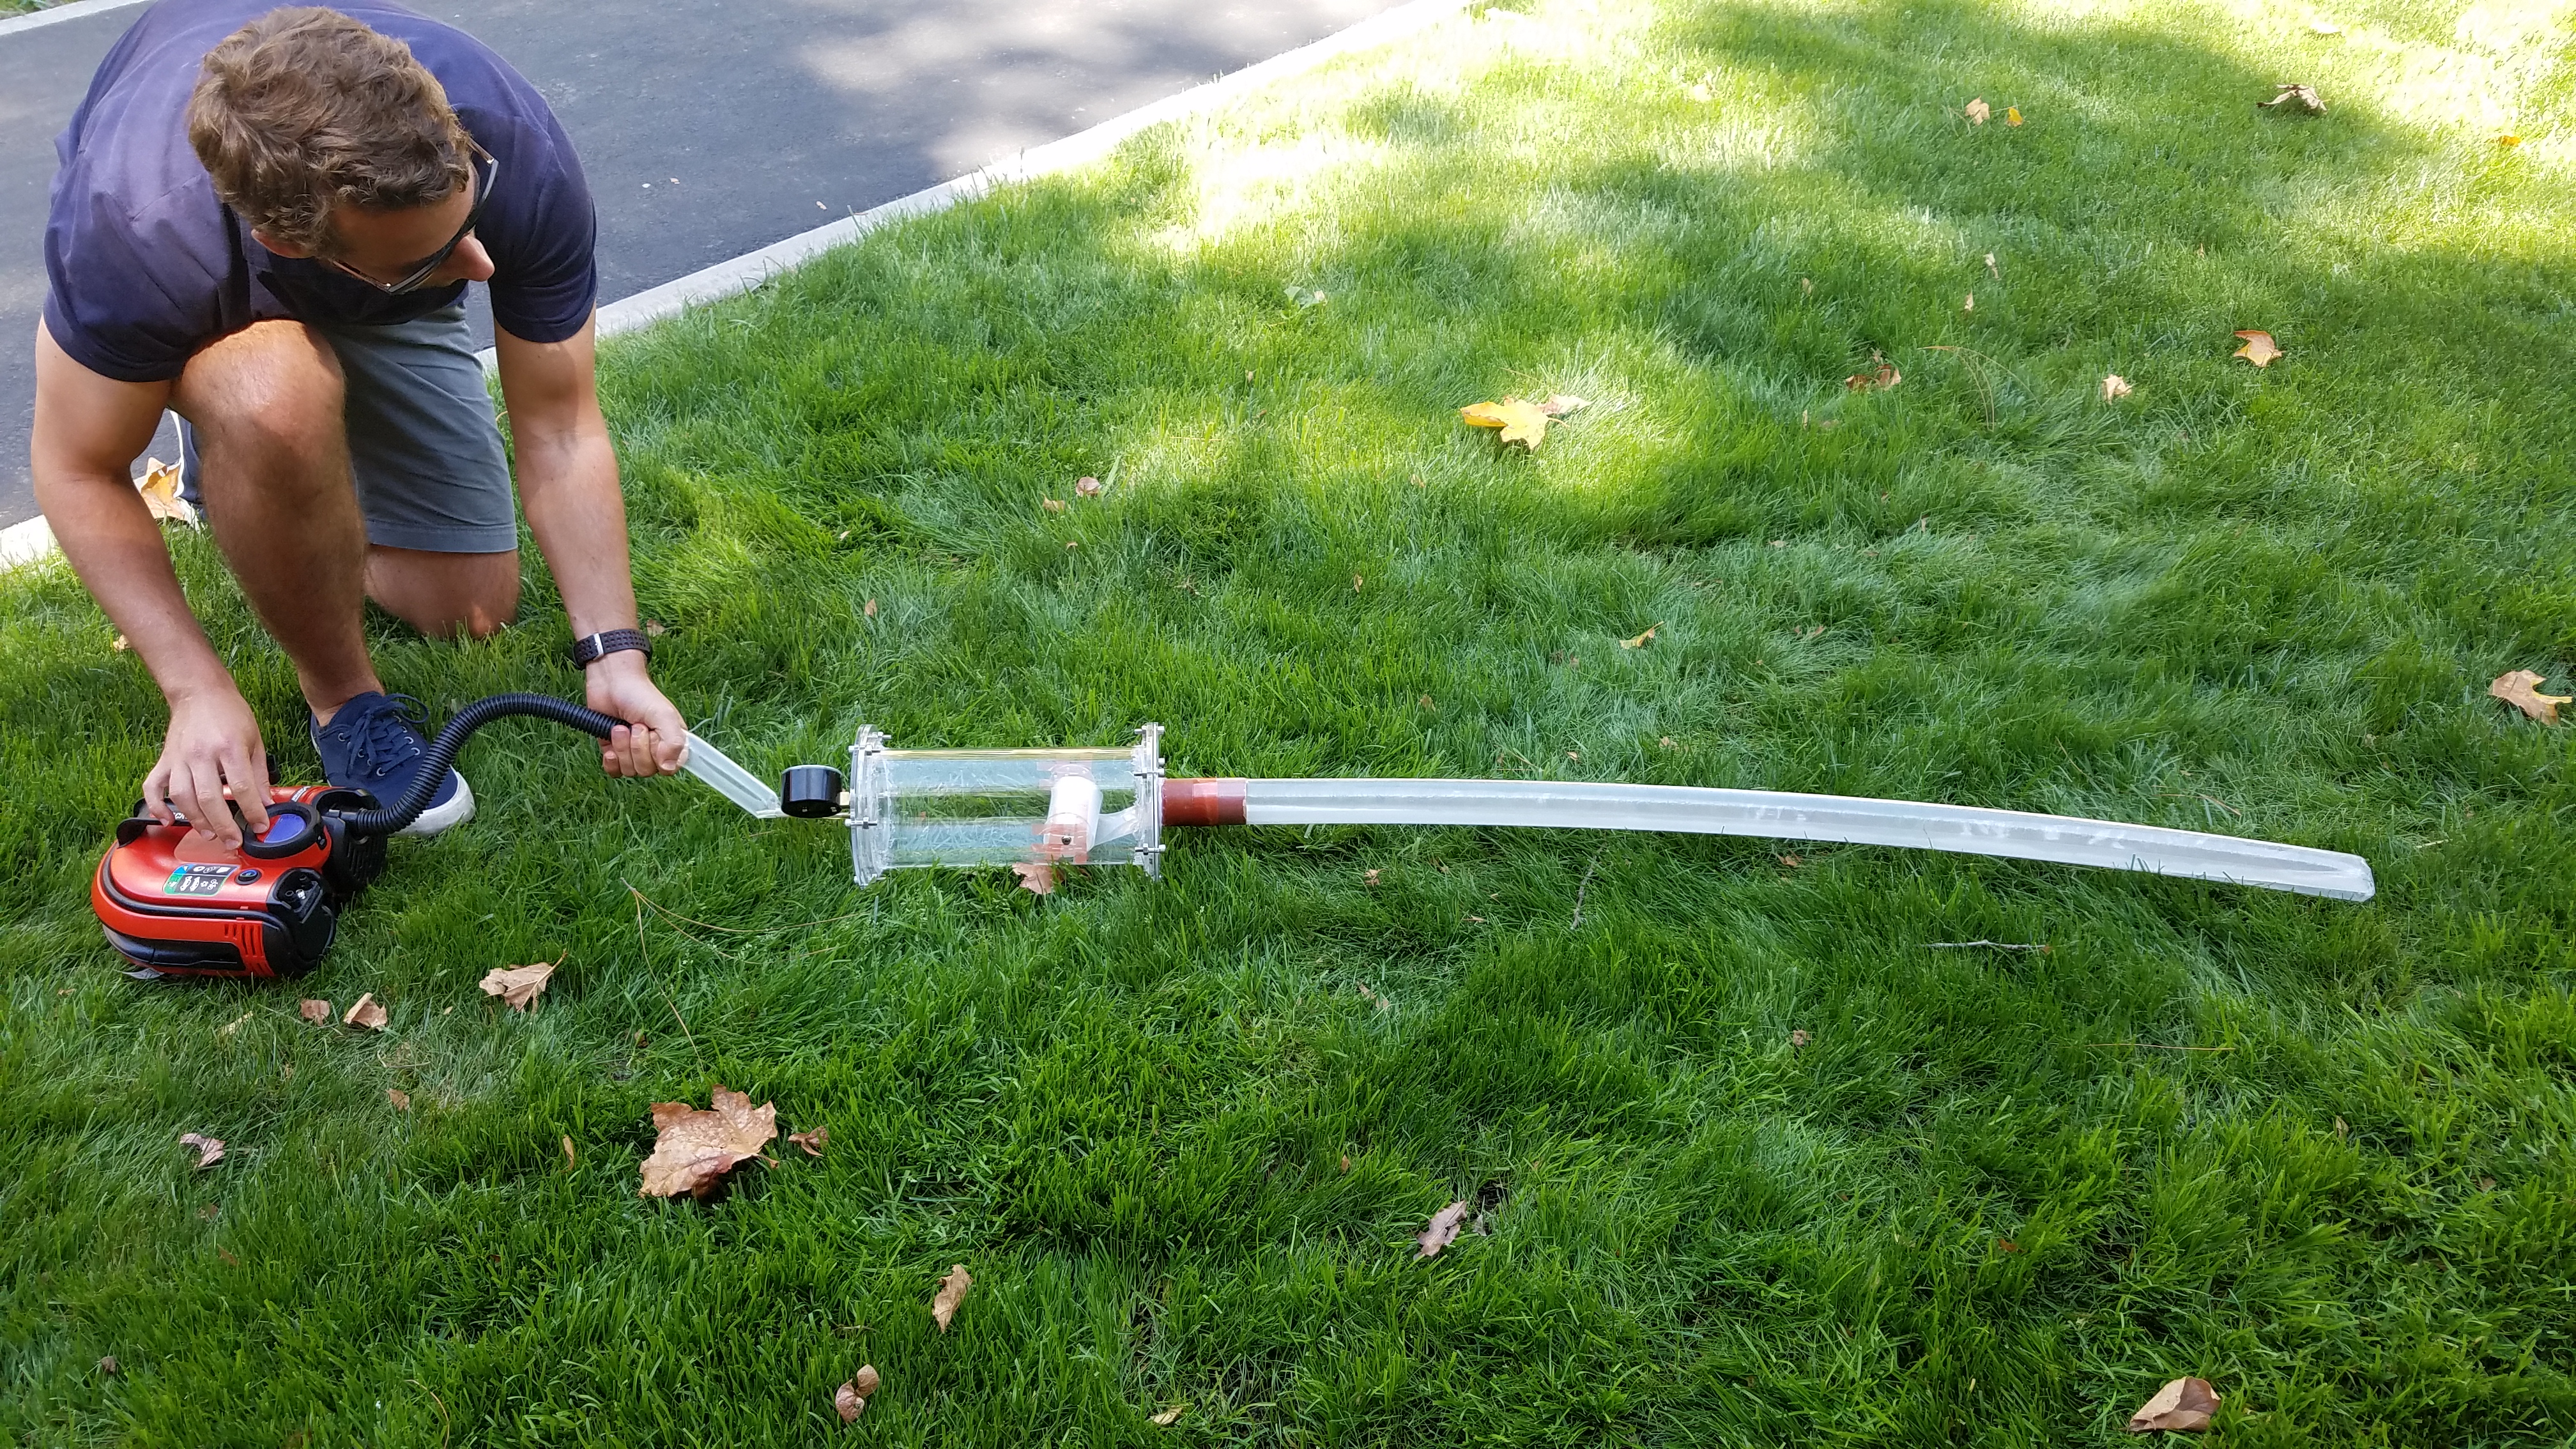
A growing robot demonstrated on grass, from the researchers’ project website.▶1080p
Stanford · Vine robot2017

Soft robot that moves by growing

A flexible tube grows by eversion at its tip, offering another way to move around obstacles.

Growth-based proof of conceptRead case
A magnetic thread inside a silicone vessel model, not an image from a patient.▶4K
MIT · Robo-thread2019

Magnetic thread through a vascular model

A magnetic field steers a slender thread, with a hydrogel coating to reduce friction.

Vascular-model experimentsRead case
INSPECT embedded-probe concept-animation preview.▶720p
Rolls-Royce · INSPECT2019

INSPECT: embedded optical probes through borescope ports

Inspect neighbouring compressor-blade edges through existing borescope ports.

Compressor-rig integration testsRead case
Rolls-Royce SWARM artist’s impression; not an operational deployment photograph.▶1080p
Rolls-Royce · SWARM2018

SWARM: miniature robots for hard-to-reach engine inspection

Inspect internal engine areas difficult to reach with conventional probes.

System concept and locomotion prototypesRead case
ReachBot prototype in Stanford’s demonstration environment.▶Video
Stanford · ReachBot2024

ReachBot: finding anchors with extendable booms

Microspine grippers at the ends of extendable booms find anchors on rock surfaces.

Lab prototypes and single-boom field testsRead case
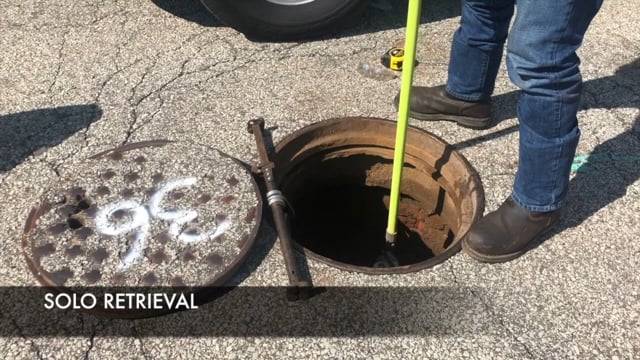
From the manhole into the pipe▶720p
RedZone · SOLO2020

From the manhole into the pipe

The tracked SOLO robot is deployed through a manhole to collect interior imagery for sewer assessment.

Manufacturer deployment demonstrationRead case
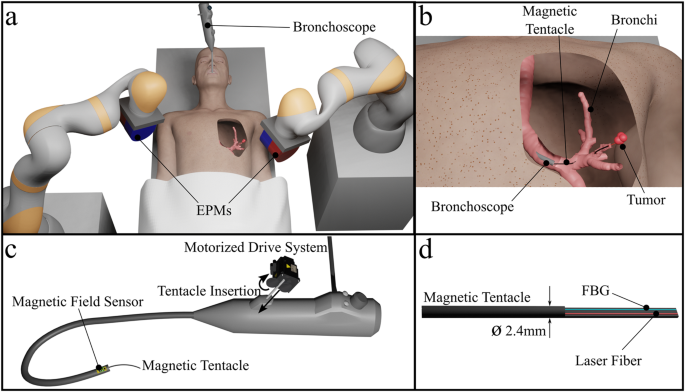
Platform concept and experimental setup, Fig. 1 of the paper.▶1080p
Leeds · Magnetic tentacles2023

Magnetic tentacles for deeper lung access

A 2.4 mm magnetic catheter combines shape sensing and an optical fiber for peripheral-airway navigation.

Phantom and ex-vivo validationRead case
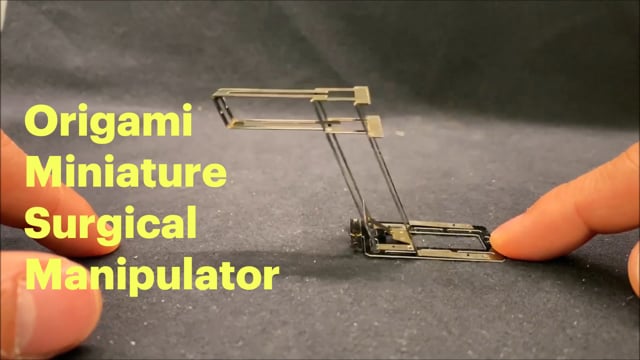
Origami mechanisms for smaller manipulation▶1080p
Harvard · mini-RCM2020

Origami mechanisms for smaller manipulation

The miniature teleoperated mini-RCM demonstrates tracing and simulated retinal-vein cannulation.

Bench-top micromanipulationRead case
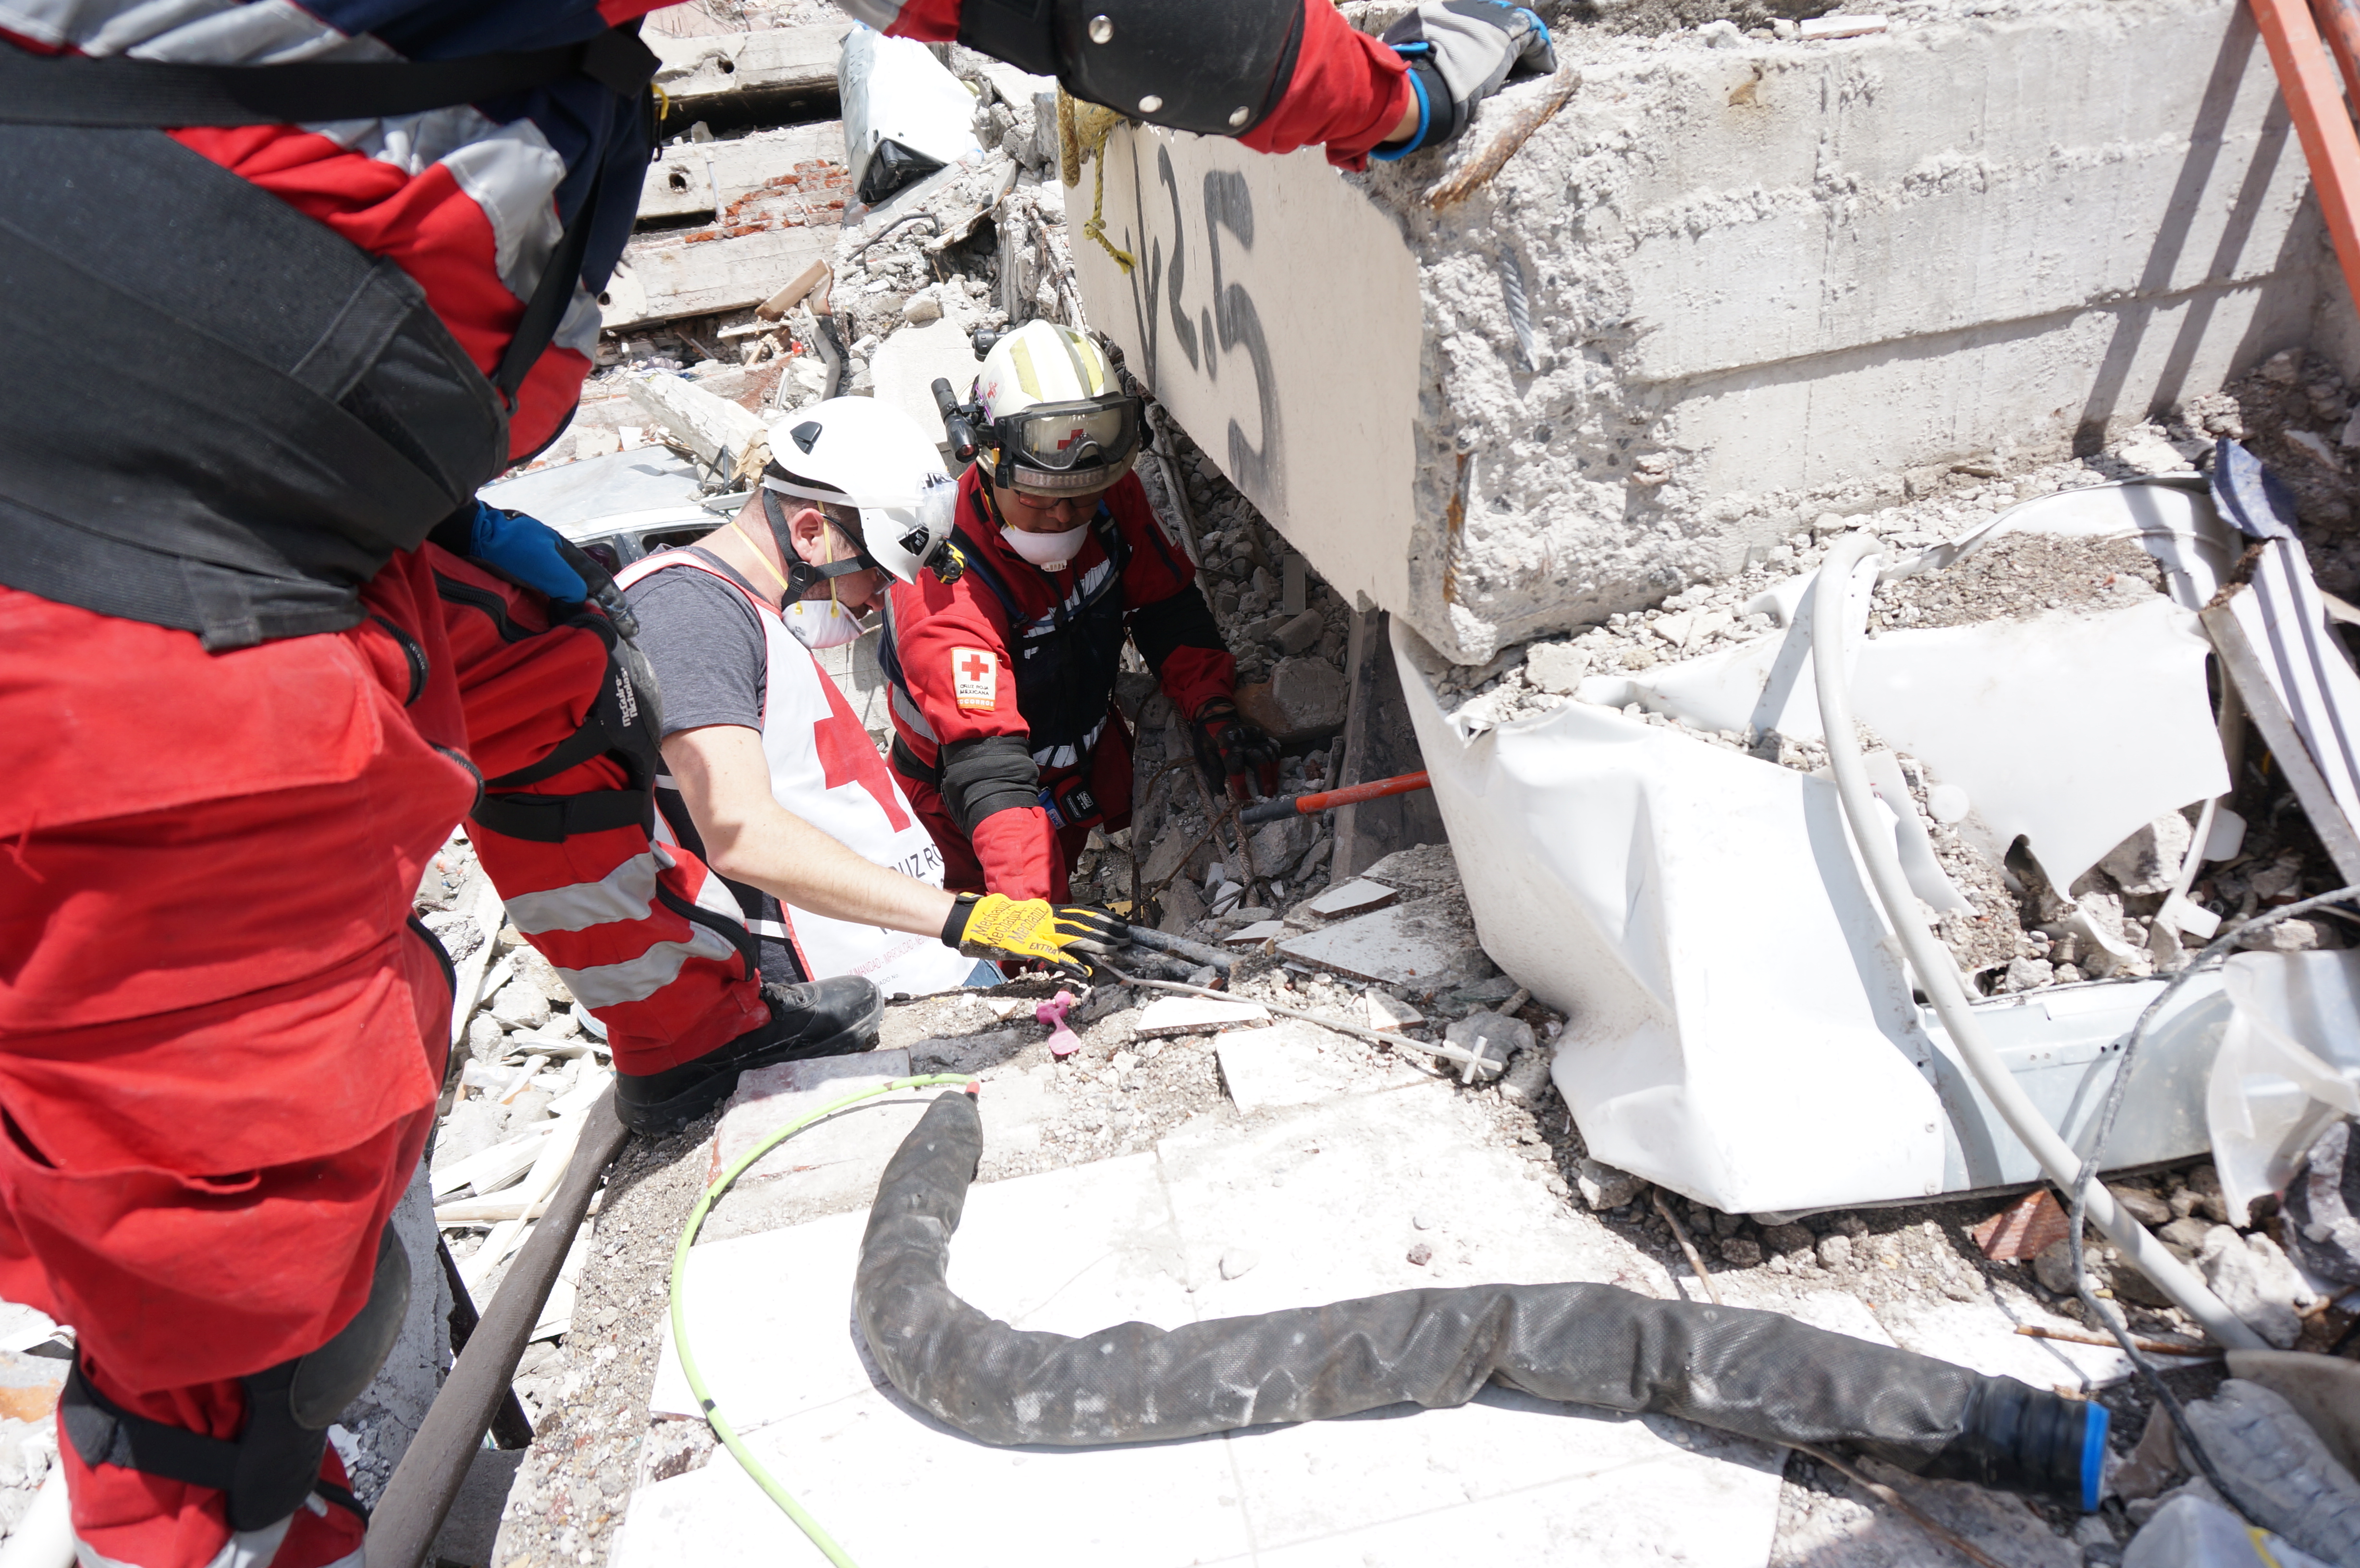
Snake-robot deployment after the 2017 Mexico City earthquake.
CMU · Snake robot2018

Snake robot in earthquake rubble

After the 2017 Mexico City earthquake, a snake robot provided camera views inside gaps inaccessible to conventional cameras.

Documented earthquake deploymentRead case
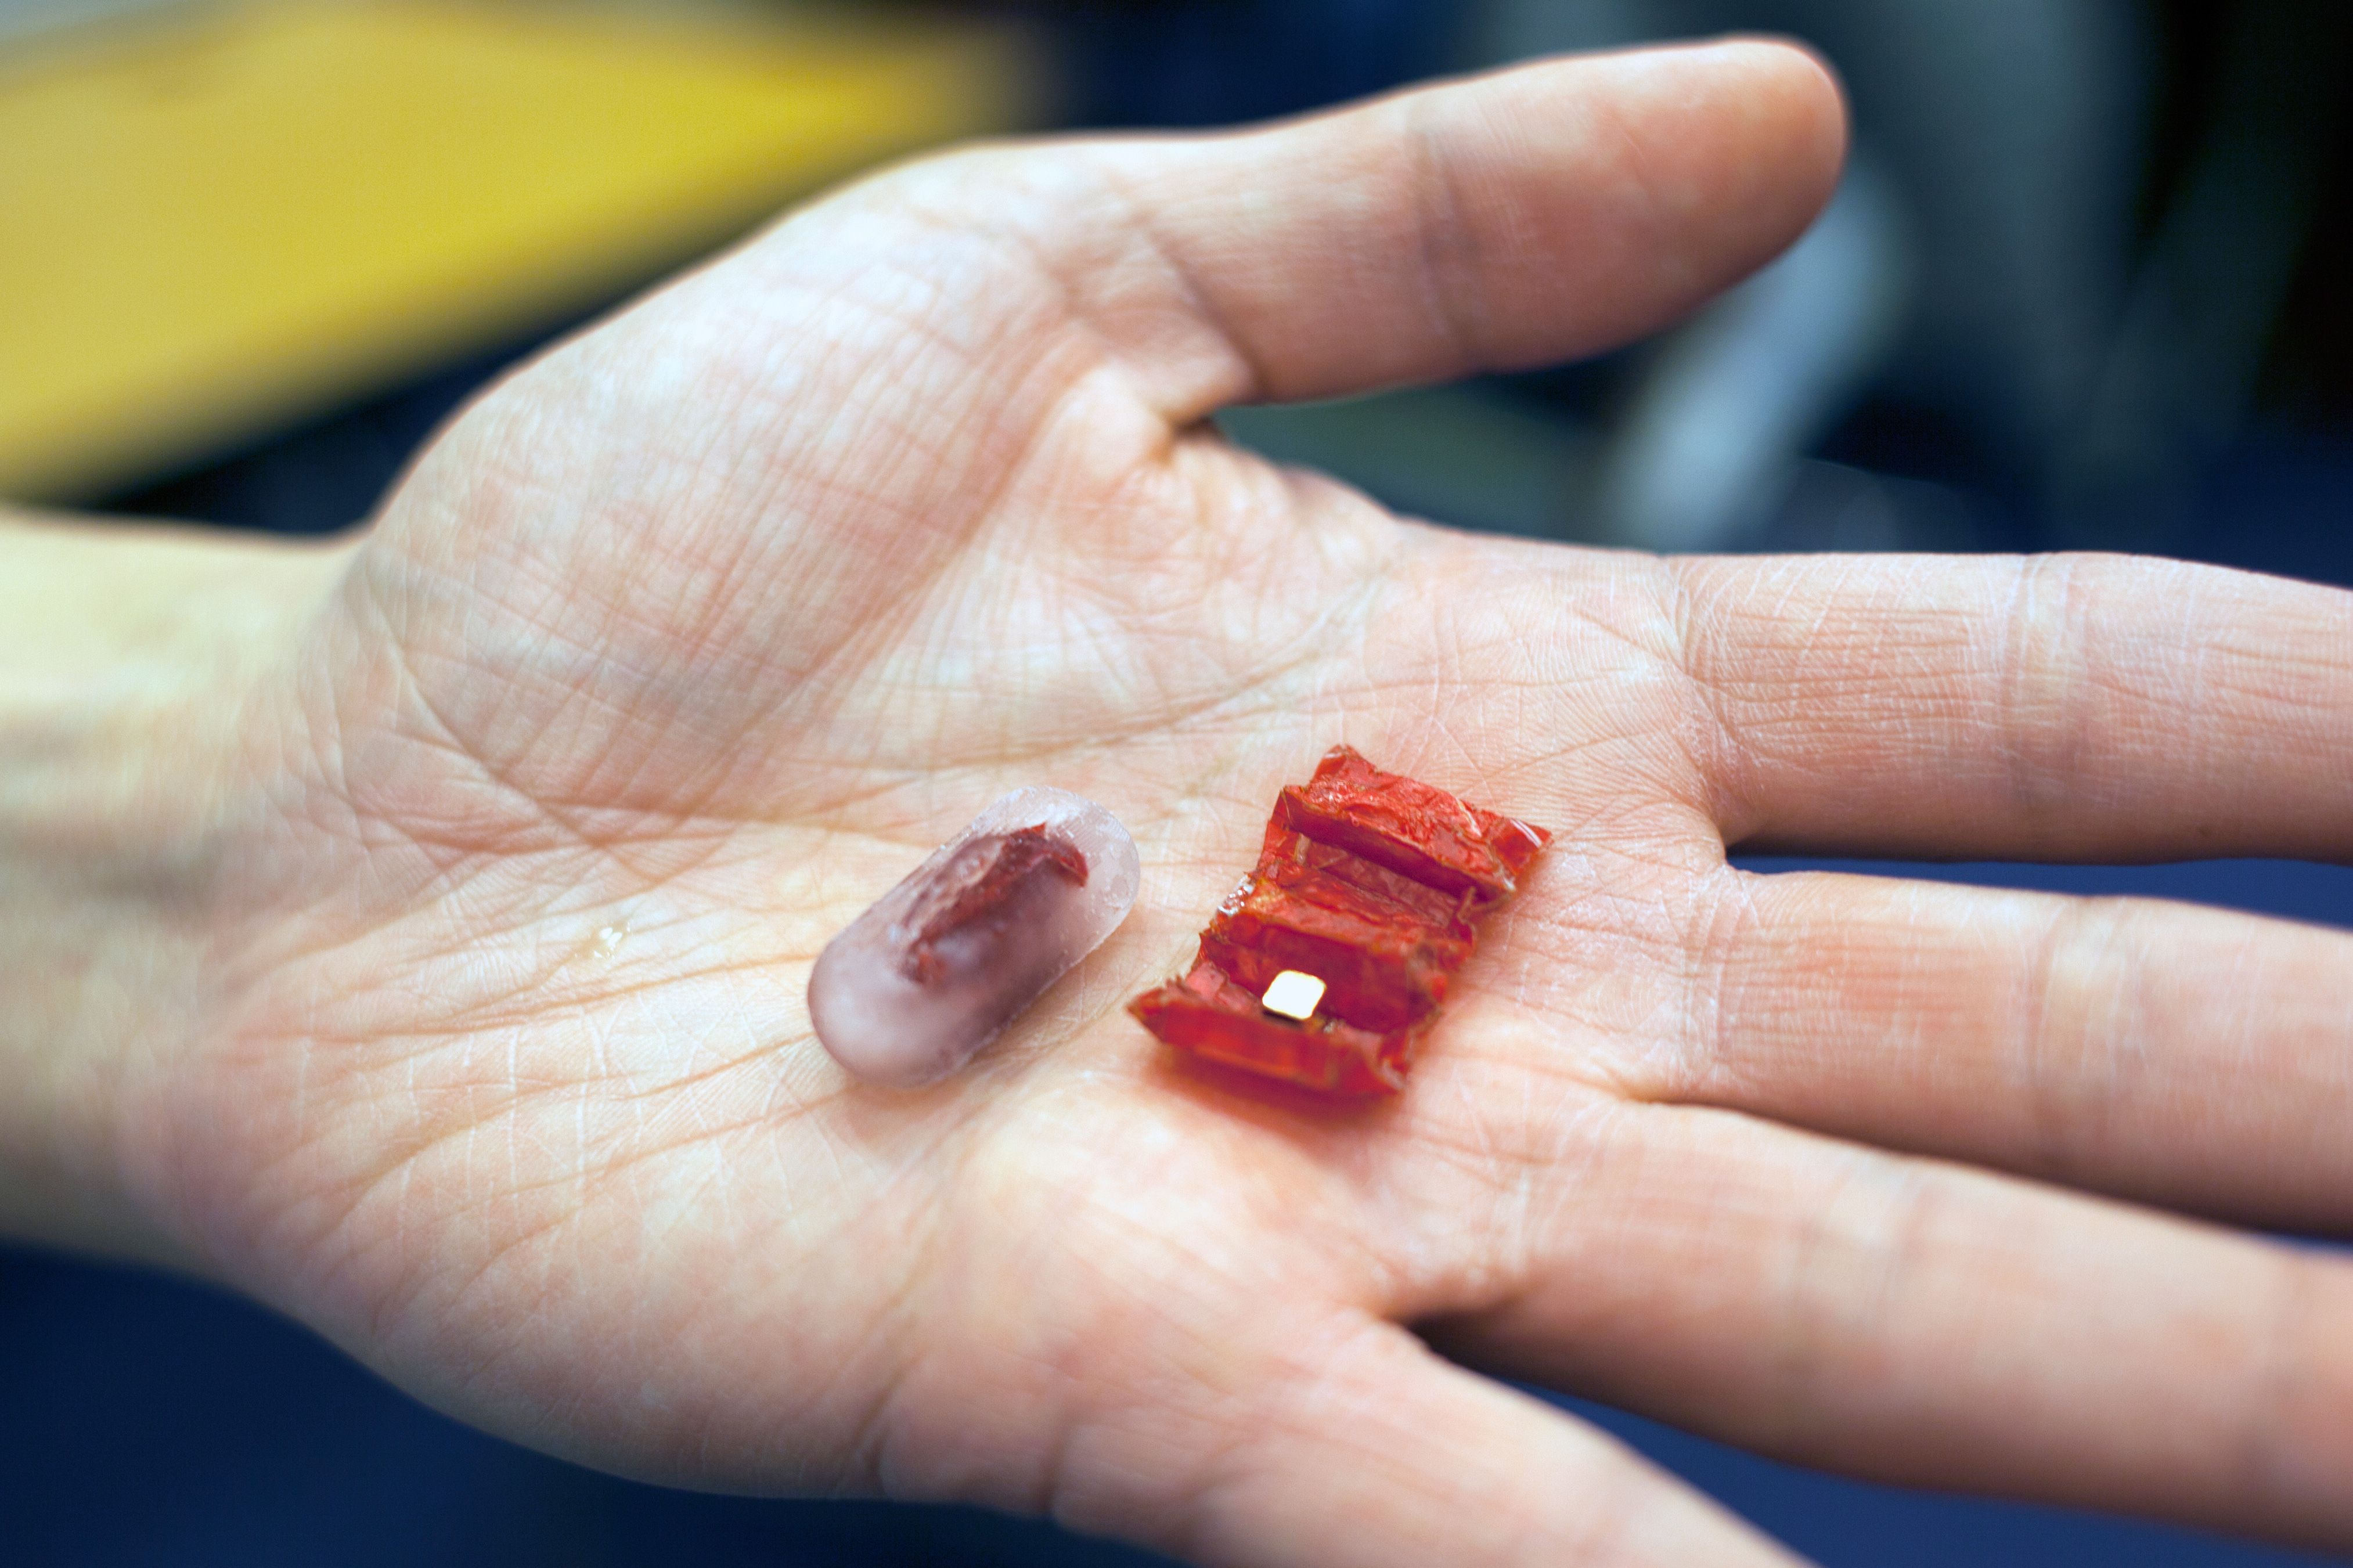
The capsule and unfolded origami robot.▶1080p
MIT · Origami robot2016

An ingestible origami robot unfolds

A robot unfolds from a capsule and uses magnetic guidance to remove a button battery in a simulated stomach.

Simulated-stomach proof of conceptRead case
Elios 3Infrastructure
▶Video
Flyability · Elios 3—

A protected drone for enclosed facilities

Elios 3 combines a protective cage, visual inspection and LiDAR sensing for enclosed facilities.

Manufacturer product demonstrationRead case
MillirobotMedical
Stanford · Millirobot2022

Millirobots and precision delivery

Magnetically actuated miniature robots explore movement and precision delivery inside the body.

Research prototype for medical useRead case
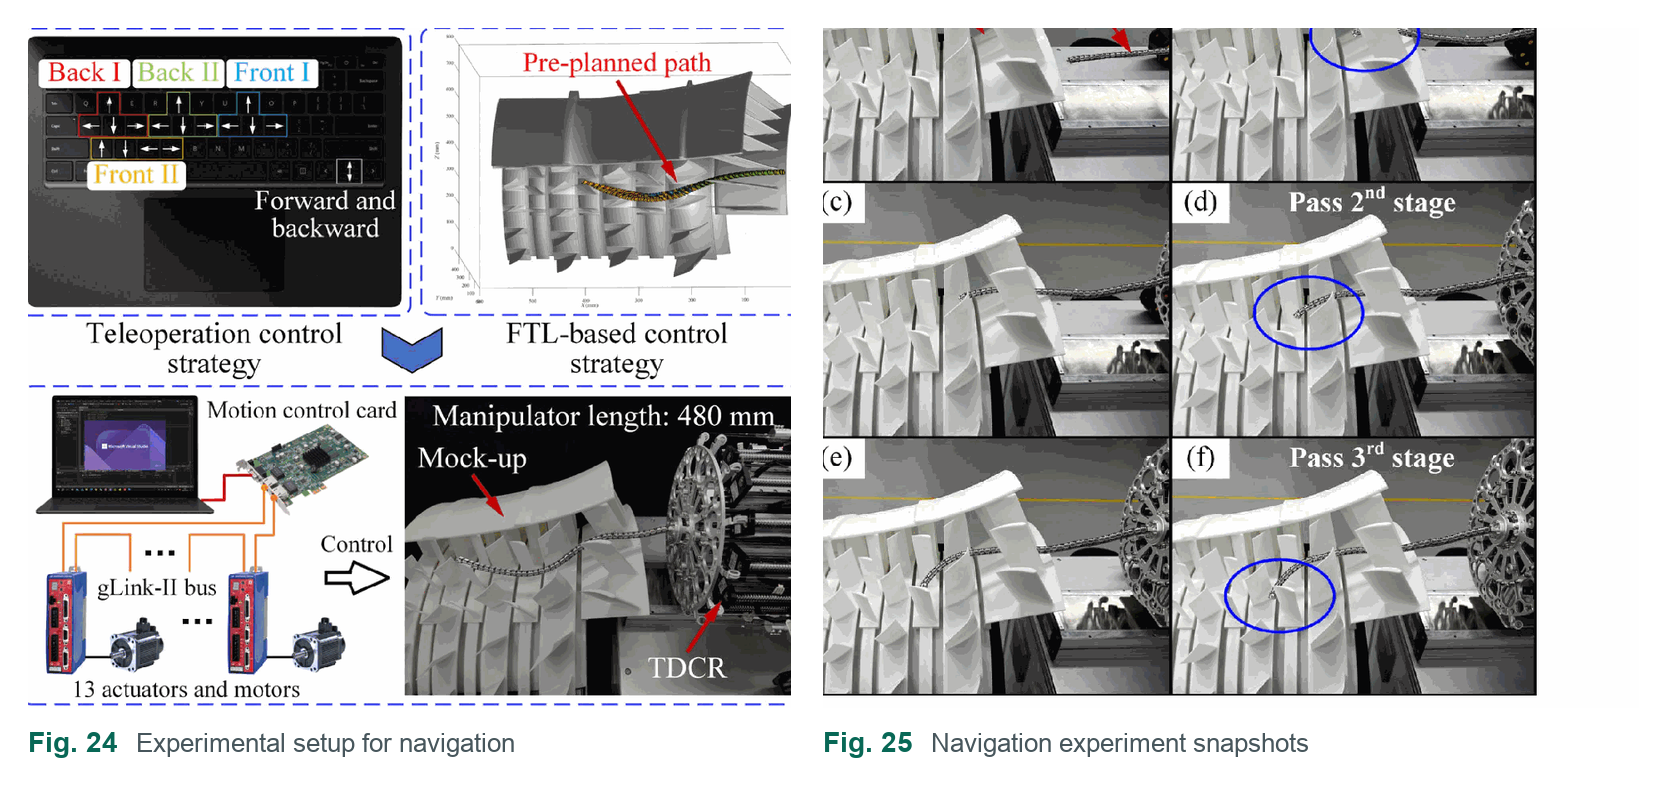
Yang et al., 2024, Figs. 24–25: experimental setup and navigation through an aero-engine blade mock-up.▶480p
CACM2024

Contact-aided continuum robot

A slender manipulator uses contact-aided compliant mechanisms to resist twisting and compression buckling.

Laboratory validationRead case
Nested continuumMechanisms
Nested continuum2026

Nested continuum robot

Nested structures with axial sliding explore coordinated changes in geometry and stiffness.

Design, modeling and experimentsRead case
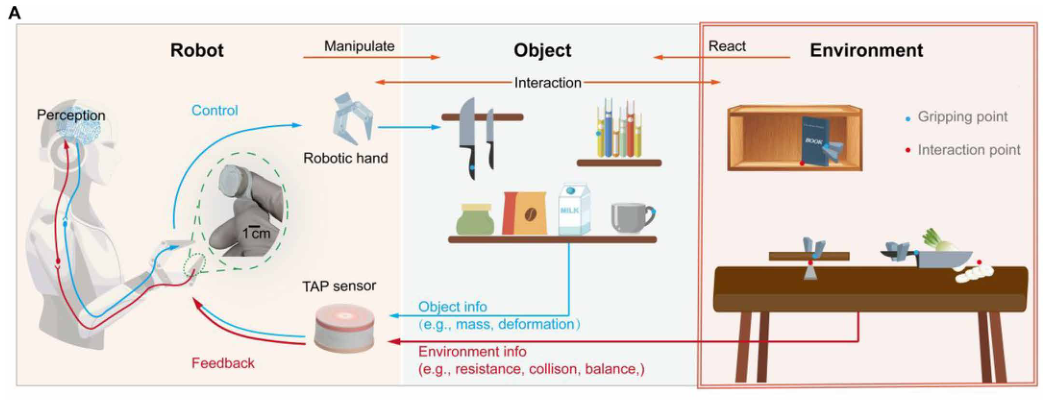
Wang et al., 2026, Fig. 1A: contact feedback for environment-in-the-loop manipulation.▶540p
TAP2026

Torque touch and environment-in-the-loop manipulation

Torque, angle and pressure feedback support specific dexterous manipulation tasks without vision.

Manipulation experimentsRead case
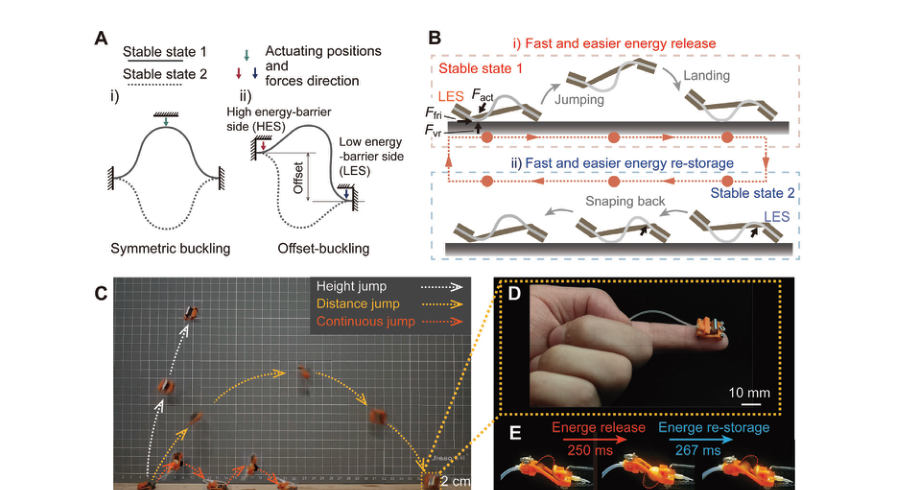
Guo et al., 2024, Fig. 1A–E: bistable mechanism, motion sequences and a fingertip-scale prototype.▶540p
BATE2024

Insect-scale bistable jumper

Tunable energy barriers control storage and release to produce multiple jumping modes at insect scale.

Laboratory prototypeRead case
No matching cases. Try another keyword or adjust the filters.

Each case links to its paper or official source, where you can check experimental conditions and how to use the images and code.

入微OPENRUWEI

A community for robotics in constrained spaces, with research and cases in maintenance, medical intervention, rescue, exploration and infrastructure.

Contribute a resourceCommunity principlesopenruwei@163.com
© 2026 OpenRuwei · Robotics in constrained spacesCase images, videos and papers remain the property of their rights holders.